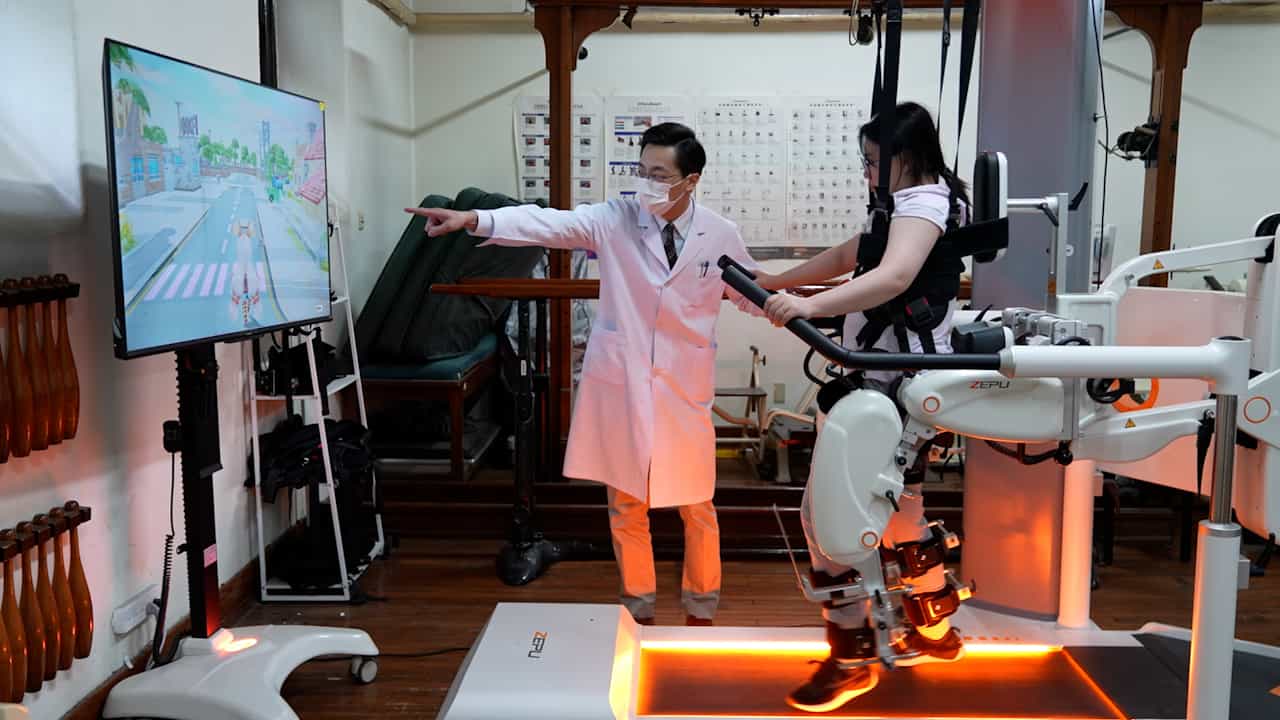
Related Experiment Video
Updated: Feb 24, 2026


Author Spotlight: Assessing Brain Activity in Robotic-Assisted Lower Limb Rehabilitation Using fNIRS
Published on: June 7, 2024
A hybrid active force control of a lower limb exoskeleton for gait rehabilitation
Zahari Taha1, Anwar P P Abdul Majeed2, Amar Faiz Zainal Abidin3
1Innovative Manufacturing, Mechatronics and Sports Laboratory (iMAMS), Faculty of Manufacturing Engineering, Universiti Malaysia Pahang, 26600 Pekan, Pahang, Malaysia.

Abstract:
Owing to the increasing demand for rehabilitation services, robotics have been engaged in addressing the drawbacks of conventional rehabilitation therapy. This paper focuses on the modelling and control of a three-link lower limb exoskeleton for gait rehabilitation that is restricted to the sagittal plane. The exoskeleton that is modelled together with a human lower limb model is subjected to a number of excitations at its joints while performing a joint space trajectory tracking, to investigate the effectiveness of the proposed controller in compensating disturbances. A particle swarm optimised active force control strategy is proposed to facilitate disturbance rejection of a conventional proportional-derivative (PD) control algorithm. The simulation study provides considerable insight into the robustness of the proposed method in attenuating the disturbance effect as compared to the conventional PD counterpart without compromising its tracking performance. The findings from the study further suggest its potential employment on a lower limb exoskeleton.