Related Experiment Video
Updated: Feb 18, 2026


Manufacturing, Control, and Performance Evaluation of a Gecko-Inspired Soft Robot
Published on: June 10, 2020
Studying slippage on pushing applications with snake robots
1Department of Robotics, Ritsumeikan University, Kusatsu, Shiga 525-8577 Japan.

Abstract:
In this paper, a framework for analyzing the motion resulting from the interaction between a snake robot and an object is shown. Metrics are derived to study the motion of the object and robot, showing that the addition of passive wheels to the snake robot helps to minimize slippage. However, the passive wheels do not have a significant impact on the force exerted onto the object. This puts snake robots in a similar framework as robotic arms, while considering special properties exclusive to snake robots (e.g., lack of a fixed-base, interaction with the environment through friction). It is also shown that the configuration (shape) of the snake robot, parameterized with the polar coordinates of the robot's COM, plays an important role in the interaction with the object. Two examples, a snake robot with two joints and another with three joints, are studied to show the applicability of the model.
Related Concept Videos
 01:11
Design Example: Forces in Sluice Gate
Key variables in...
 01:14
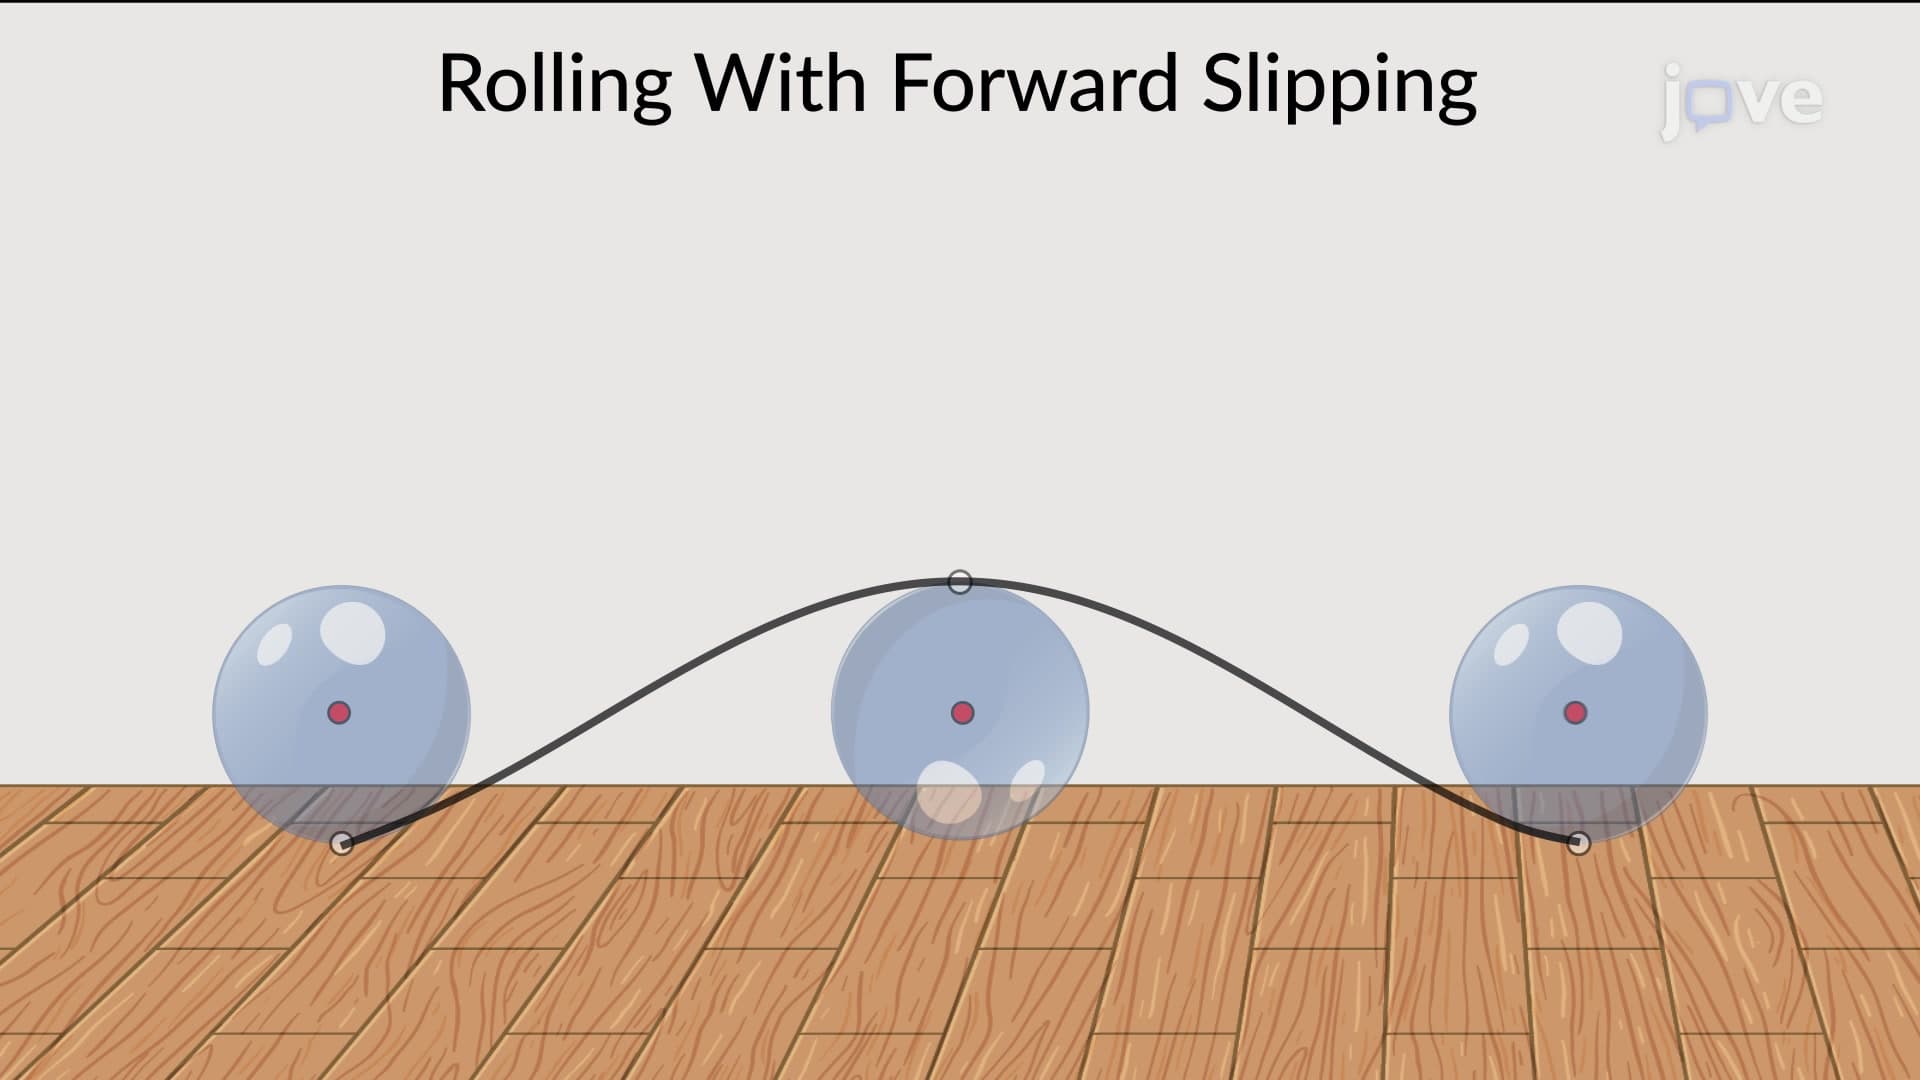
Rolling With Slipping
An object's rolling motion is characterized by its rotation around its axis, while linear motion refers to the object's translational motion along a surface. Frictional forces can...
 01:16
Hydraulic Jump: Problem Solving
 01:17
Rolling Resistance: Problem Solving