Related Experiment Video
Updated: Feb 17, 2026

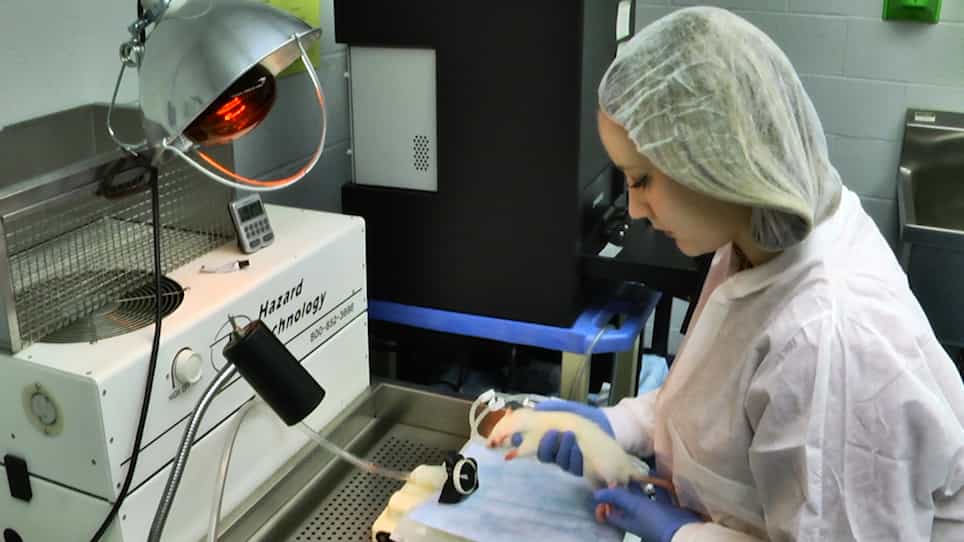
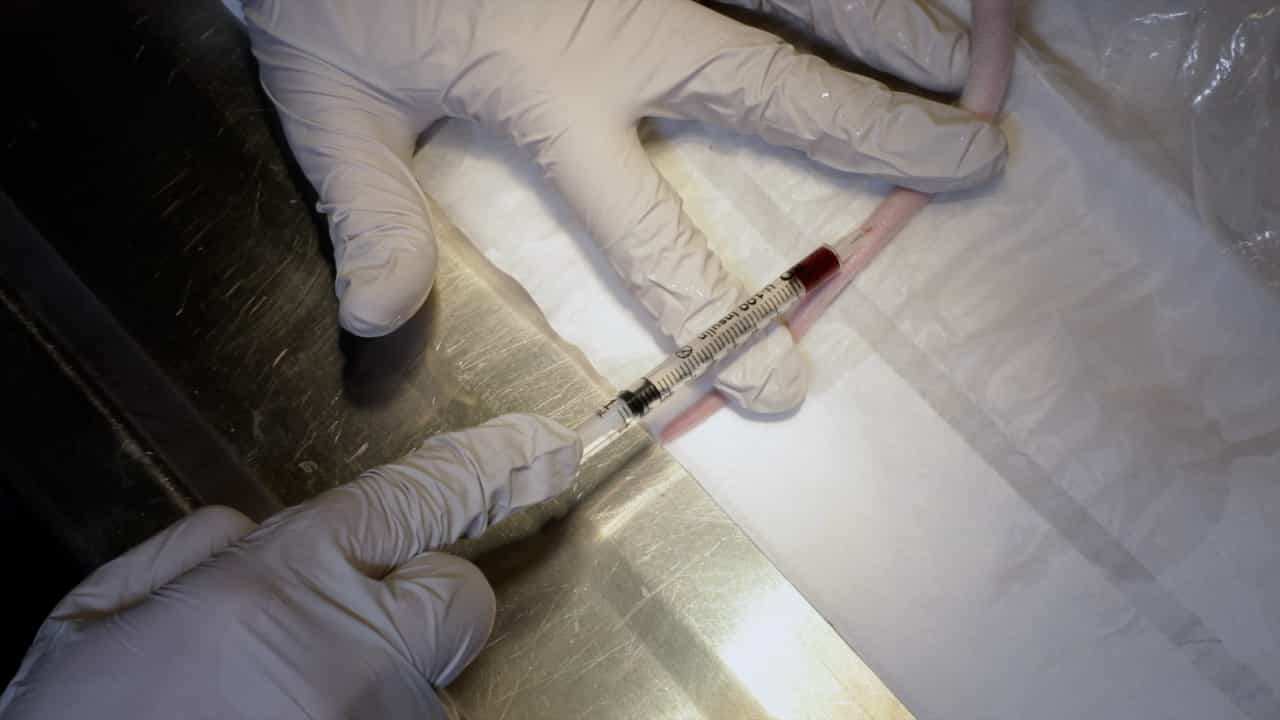
A Contemporary Warming/Restraining Device for Efficient Tail Vein Injections in a Murine Fungal Sepsis Model
Published on: November 6, 2020
Design and Evaluation of a Robotic Device for Automated Tail Vein Cannulations in Rodent Models
Alex Fromholtz1, Max L Balter1, Alvin I Chen1
1Department of Biomedical Engineering, Rutgers University, Piscataway, NJ 08854

Abstract:
Preclinical testing in rodent models is a ubiquitous part of modern biomedical research and commonly involves accessing the venous bloodstream for blood sampling and drug delivery. Manual tail vein cannulation is a time-consuming process and requires significant skill and training, particularly since improperly inserted needles can affect the experimental results and study outcomes. In this paper, we present a miniaturized, robotic medical device for automated, image-guided tail vein cannulations in rodent models. The device is composed of an actuated three degrees-of-freedom (DOFs) needle manipulator, three-dimensional (3D) near-infrared (NIR) stereo cameras, and an animal holding platform. Evaluating the system through a series of workspace simulations and free-space positioning tests, the device exhibited a sufficient work volume for the needle insertion task and submillimeter accuracy over the calibration targets. The results indicate that the device is capable of cannulating tail veins in rodent models as small as 0.3 mm in diameter, the smallest diameter vein required to target.