Related Experiment Video
Updated: Feb 15, 2026

Insect-controlled Robot: A Mobile Robot Platform to Evaluate the Odor-tracking Capability of an Insect
Published on: December 19, 2016
Using optical tracking for kinematic testing of medical robots
Changhan Jun1, Ryan Decker1, Dan Stoianovici1
1Robotics Laboratory, Urology Department, Johns Hopkins University, Baltimore, Maryland, USA.

Background:
In image-guided robotic interventions, an error component is related to the positioning error of the manipulator. Therefore, measuring the kinematic error is required during robot development. However, no specialized measurement device exists for this task. This study explores the possibility of using optical tracking for robot measurement.
Methods:
A CNC machine is used to position an optical marker, generating a gold standard reference. Repeated position measurements are acquired with an NDI Polaris Hybrid® optical tracker at each static location, and averaged. These measurements are compared to the reference set.
Results:
Averaging repeated static position measurements improves precision (200-500 samples). Measurement accuracy ranges between 44 μm and 137 μm in close proximity of the tracker.
Conclusions:
Repeated static position measurements in the near field of view enable the optical tracker to outperform its general-purpose accuracy specification. Optical tracking may be used to test robot kinematics with a high degree of accuracy.
Related Concept Videos
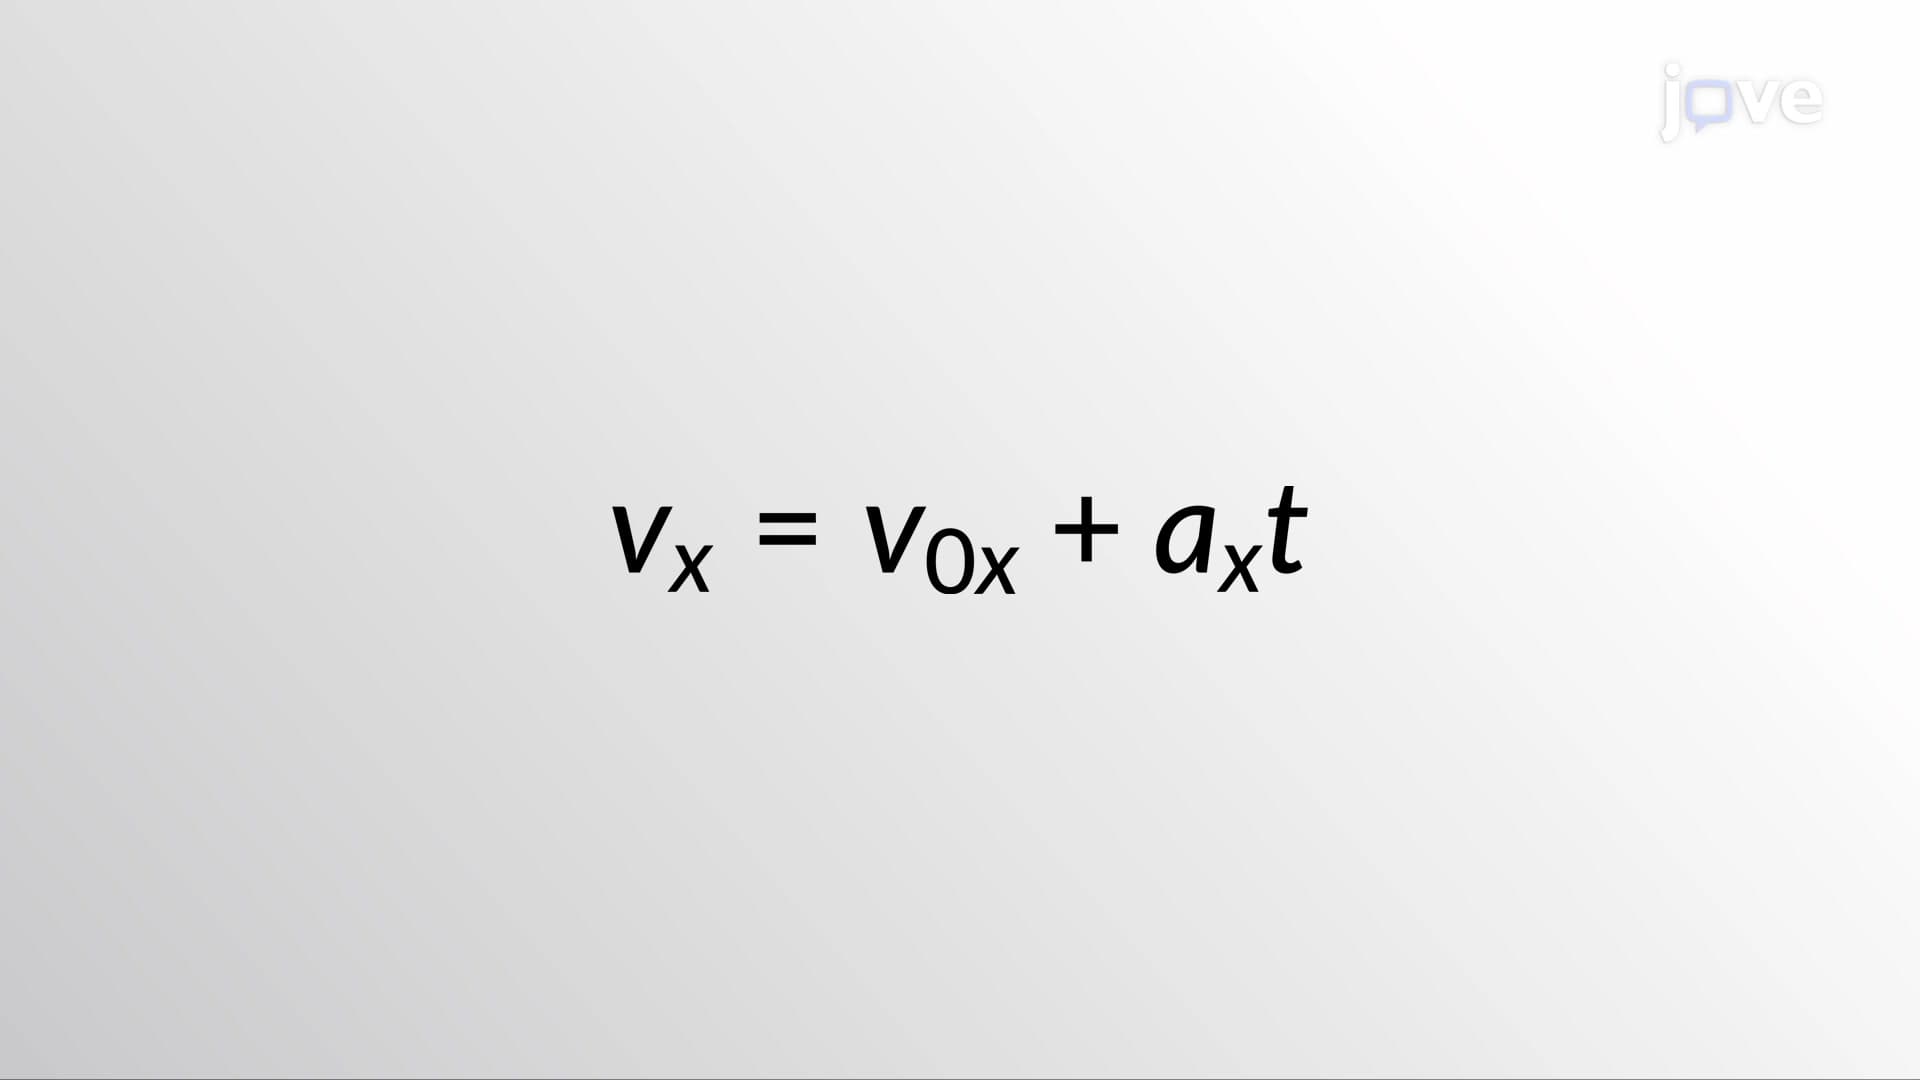 01:26
Kinematic Equations - I
 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:23
Inhaled Medications
 01:18
Kinematic Equations - III
Using the kinematic equations,...
 01:15
Kinematic Equations: Problem Solving