A Method on Dynamic Path Planning for Robotic Manipulator Autonomous Obstacle Avoidance Based on an Improved RRT Algorithm
Related Experiment Video
Updated: Feb 14, 2026
Rod-based Fabrication of Customizable Soft Robotic Pneumatic Gripper Devices for Delicate Tissue Manipulation
Published on: August 2, 2016
1School of Mechatronics Engineering, Harbin Institute of Technology, Harbin 150001, China. weikun@hit.edu.cn.

Abstract:
In a future intelligent factory, a robotic manipulator must work efficiently and safely in a Human-Robot collaborative and dynamic unstructured environment. Autonomous path planning is the most important issue which must be resolved first in the process of improving robotic manipulator intelligence. Among the path-planning methods, the Rapidly Exploring Random Tree (RRT) algorithm based on random sampling has been widely applied in dynamic path planning for a high-dimensional robotic manipulator, especially in a complex environment because of its probability completeness, perfect expansion, and fast exploring speed over other planning methods. However, the existing RRT algorithm has a limitation in path planning for a robotic manipulator in a dynamic unstructured environment. Therefore, an autonomous obstacle avoidance dynamic path-planning method for a robotic manipulator based on an improved RRT algorithm, called Smoothly RRT (S-RRT), is proposed. This method that targets a directional node extends and can increase the sampling speed and efficiency of RRT dramatically. A path optimization strategy based on the maximum curvature constraint is presented to generate a smooth and curved continuous executable path for a robotic manipulator. Finally, the correctness, effectiveness, and practicability of the proposed method are demonstrated and validated via a MATLAB static simulation and a Robot Operating System (ROS) dynamic simulation environment as well as a real autonomous obstacle avoidance experiment in a dynamic unstructured environment for a robotic manipulator. The proposed method not only provides great practical engineering significance for a robotic manipulator's obstacle avoidance in an intelligent factory, but also theoretical reference value for other type of robots' path planning.

Related Concept Videos
 01:22
Mean free path and Mean free time
 01:14
Frustration and Conflict: Avoidance-Avoidance, Double-Approach Avoidance
 01:21
Path Between Thermodynamics States
 01:22
Autonomic Nervous System
The ANS comprises two main divisions: the sympathetic and parasympathetic divisions. These divisions function antagonistically to maintain a dynamic...
 01:10
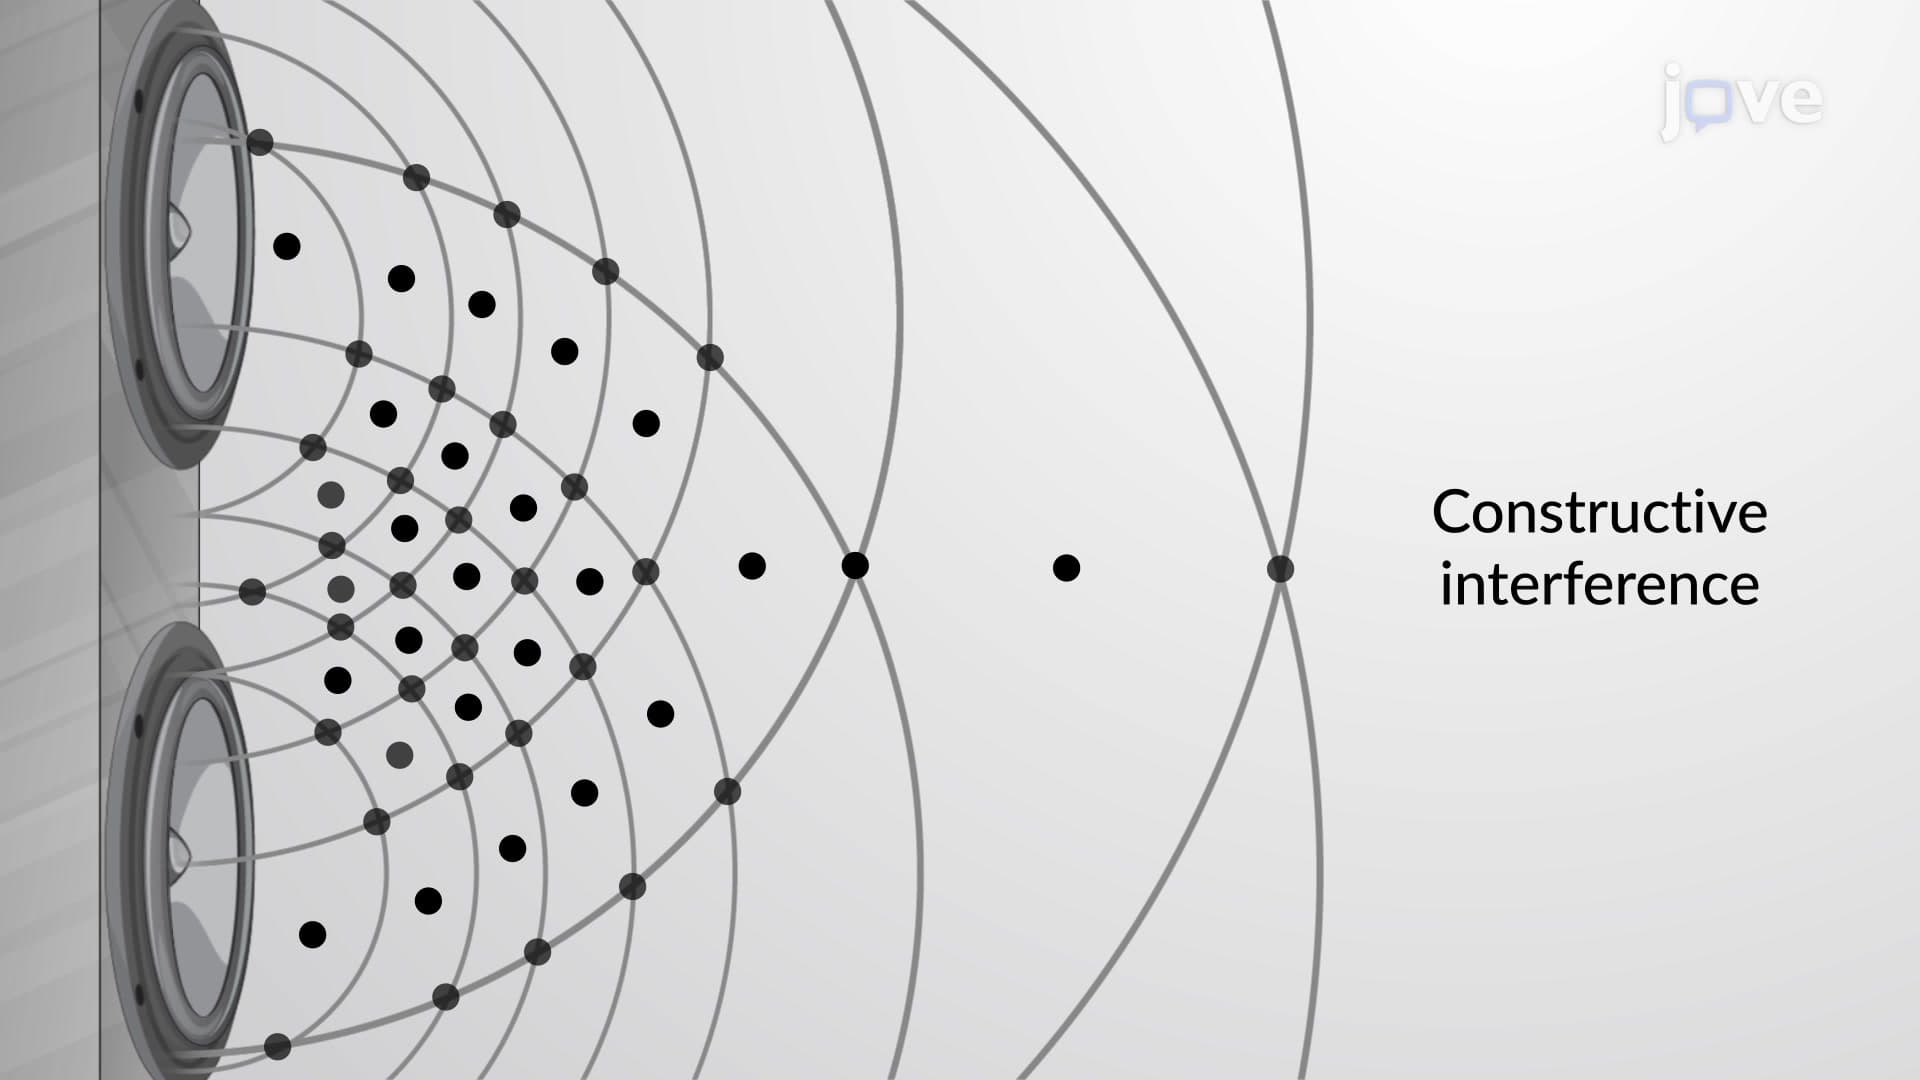
Interference: Path Lengths
Two special sources may be considered when they are in phase. This can be easily achieved by feeding the two sources from the same source. An example would be synchronizing the two speakers by feeding them with the same source, such as the sound waves produced by a tuning fork. This setup ensures that the two sources have the same frequency and are...
 03:48
Behavior of Gas Molecules: Molecular Diffusion, Mean Free Path, and Effusion