Design and evaluation of a deformable wing configuration for economical hovering flight of an insect-like tailless flying robot
Related Experiment Video
Updated: Feb 13, 2026
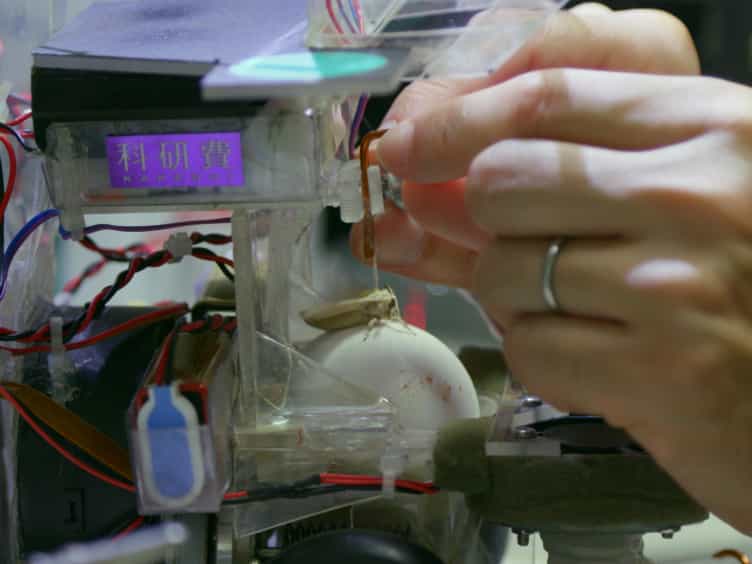
Insect-controlled Robot: A Mobile Robot Platform to Evaluate the Odor-tracking Capability of an Insect
Published on: December 19, 2016
Hoang Vu Phan1, Hoon Cheol Park
1Artificial Muscle Research Center and Department of Smart Vehicle Engineering, Konkuk University, Seoul 05029, Republic of Korea.

Abstract:
Studies on wing kinematics indicate that flapping insect wings operate at higher angles of attack (AoAs) than conventional rotary wings. Thus, effectively flying an insect-like flapping-wing micro air vehicle (FW-MAV) requires appropriate wing design for achieving low power consumption and high force generation. Even though theoretical studies can be performed to identify appropriate geometric AoAs for a wing for achieving efficient hovering flight, designing an actual wing by implementing these angles into a real flying robot is challenging. In this work, we investigated the wing morphology of an insect-like tailless FW-MAV, which was named KUBeetle, for obtaining high vertical force/power ratio or power loading. Several deformable wing configurations with various vein structures were designed, and their characteristics of vertical force generation and power requirement were theoretically and experimentally investigated. The results of the theoretical study based on the unsteady blade element theory (UBET) were validated with reference data to prove the accuracy of power estimation. A good agreement between estimated and measured results indicated that the proposed UBET model can be used to effectively estimate the power requirement and force generation of an FW-MAV. Among the investigated wing configurations operating at flapping frequencies of 23 Hz to 29 Hz, estimated results showed that the wing with a suitable vein placed outboard exhibited an increase of approximately 23.7% ± 0.5% in vertical force and approximately 10.2% ± 1.0% in force/power ratio. The estimation was supported by experimental results, which showed that the suggested wing enhanced vertical force by approximately 21.8% ± 3.6% and force/power ratio by 6.8% ± 1.6%. In addition, wing kinematics during flapping motion was analyzed to determine the reason for the observed improvement.
Related Concept Videos
 01:47
Osmoregulation in Insects
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 02:46
Electron Configurations
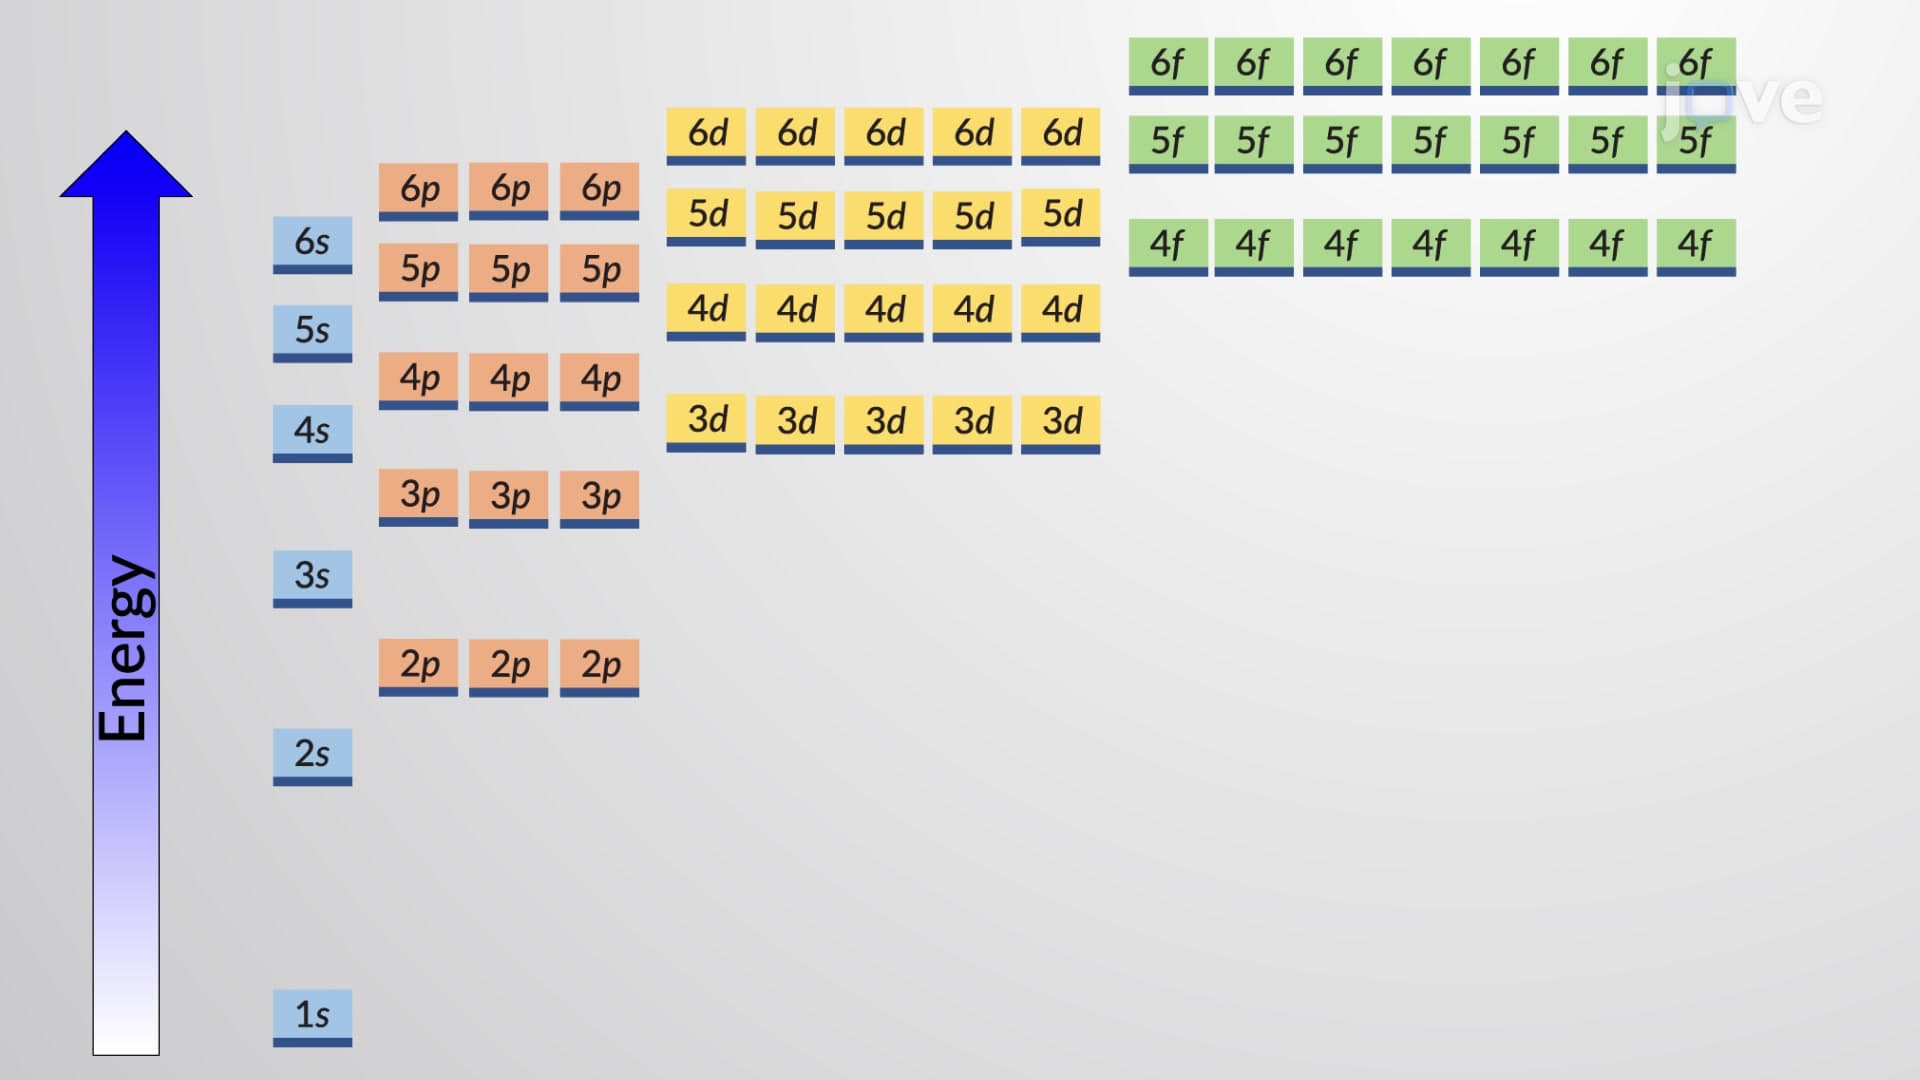
The relative energies of the subshells determine the order in which atomic orbitals are filled (1s, 2s, 2p, 3s, 3p,...
 03:26
Electron Configuration of Multielectron Atoms
 01:16
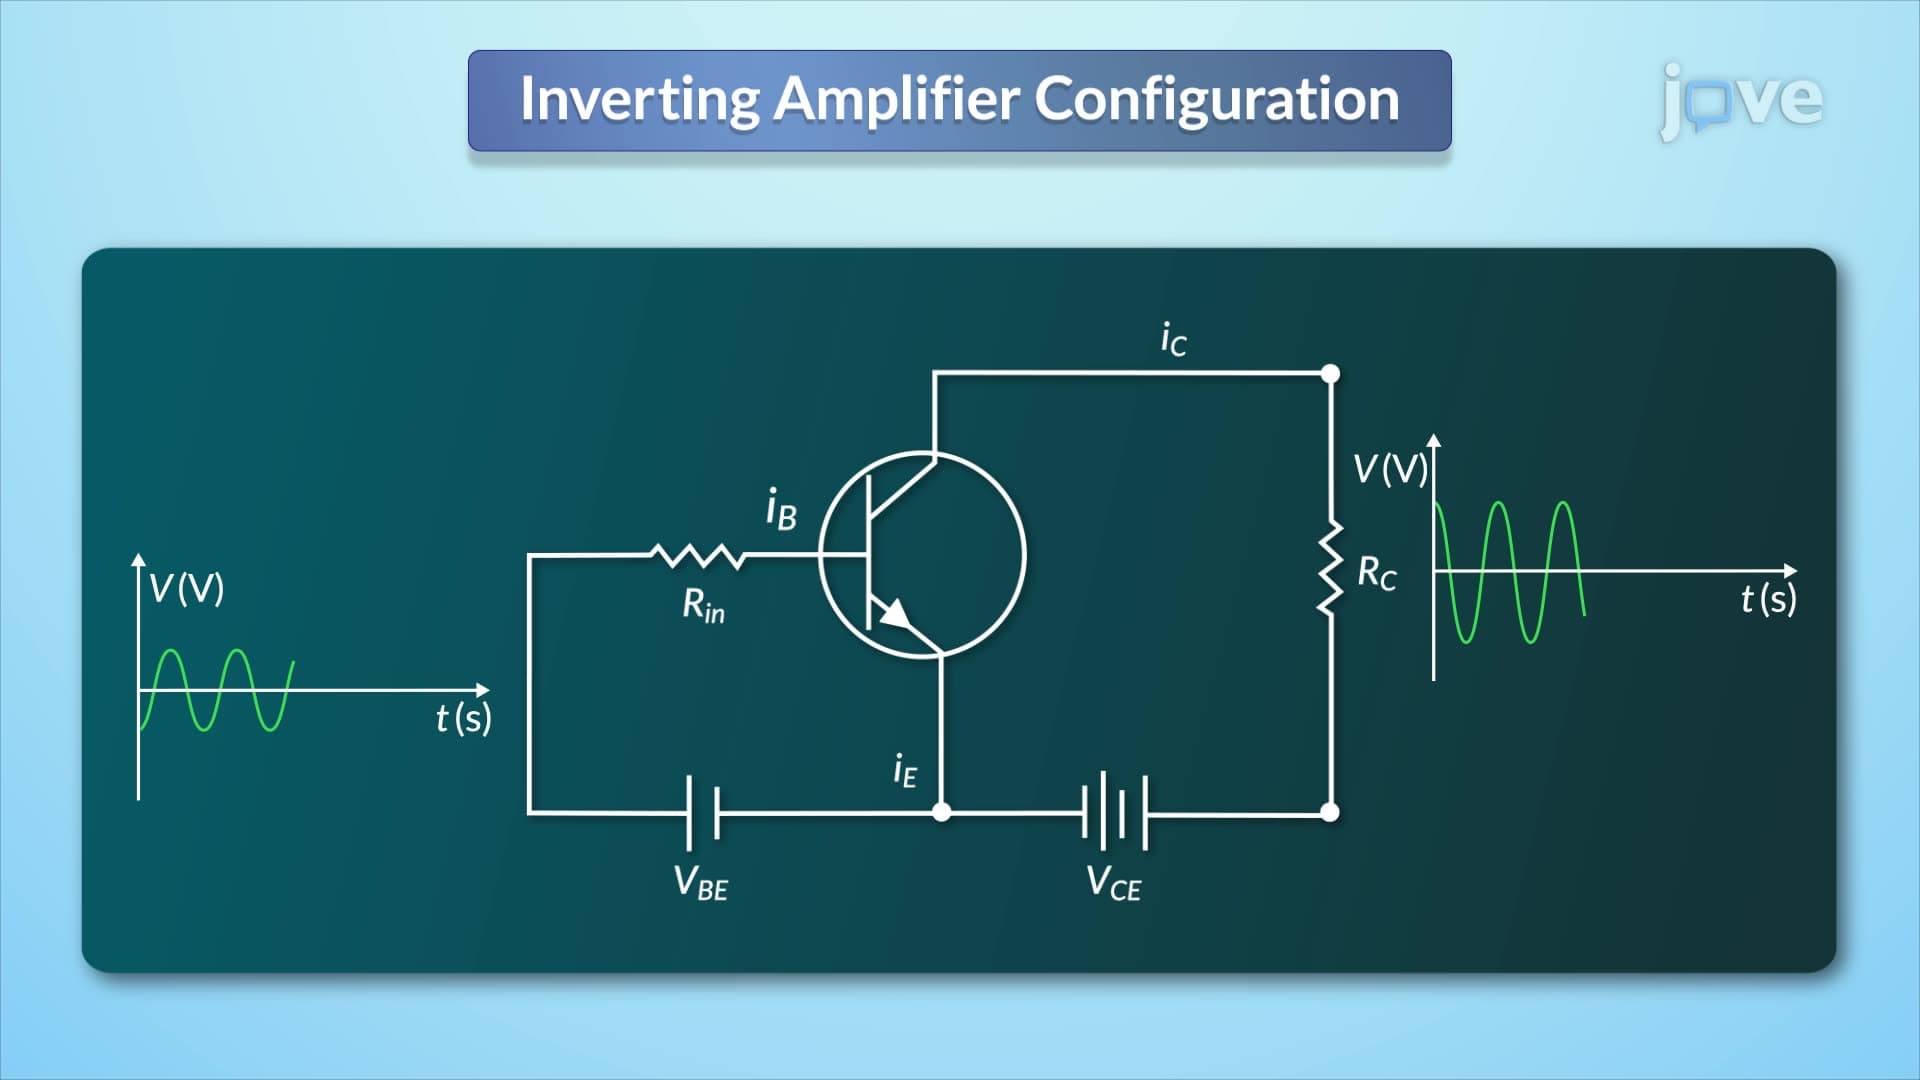
Configurations of BJT
The common base configuration is noted for its high voltage gain, positioning it as an ideal choice for single-stage amplifier circuits, such as microphone pre-amplifiers. A notable...
 01:19
Plastic Deformations