Related Experiment Video
Updated: Feb 12, 2026
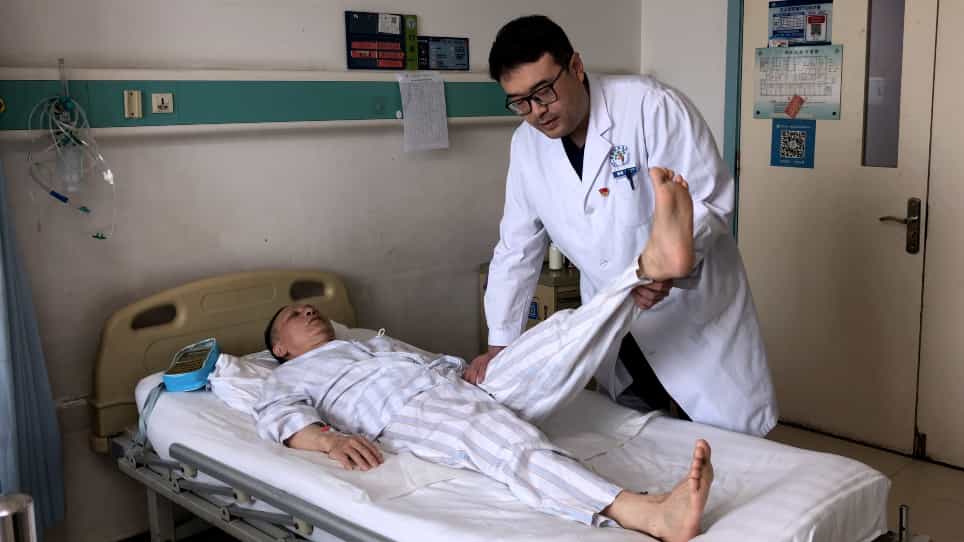
Orthopedic Robot-Assisted Femoral Neck System in the Treatment of Femoral Neck Fracture
Published on: March 3, 2023
Analysis and optimization of bone machining for robotic orthopedic surgeries
Derek J Pell1, Masakazu Soshi1
1Department of Mechanical and Aerospace Engineering, Advanced Research for Manufacturing Systems Laboratory, University of California Davis, California, USA.

Background:
Robot-assisted joint replacement surgery is becoming increasingly more common worldwide, therefore it is important to characterize and improve the bone-cutting mechanics of surgical tools.
Methods:
Linear coefficients relating cutting force and chip thickness were derived for a surgical spindle. The cutting coefficients were integrated into an analytical simulation which calculated cutting forces, torque, and power consumption. An optimization experiment was performed. High speed video was taken at various tool parameter settings.
Results:
Varying machining parameters resulted in lower cutting forces. The surgical spindle stalled at the current spindle speed used in surgery, but did not for the new, optimized conditions. Multiple anomalies were identified in the videos that confirmed observations from the cutting force data.
Conclusions:
Improved surgical performance and accuracy were achieved using slower spindle speeds, decreased cutting depth, and increased feed rates, as well as improving motor torque to ensure a smooth cutting process.
Related Concept Videos
 01:19
Machines
A free-body diagram of the...
 01:30
Machines: Problem Solving II
 01:22
Machines: Problem Solving I
The toggle clamp system is a machine structure consisting of movable, pin-connected multi-force members that form a stabilized system to transmit forces. The...
 00:48
Optimal Foraging
 01:26
Optimization Problems
 01:14
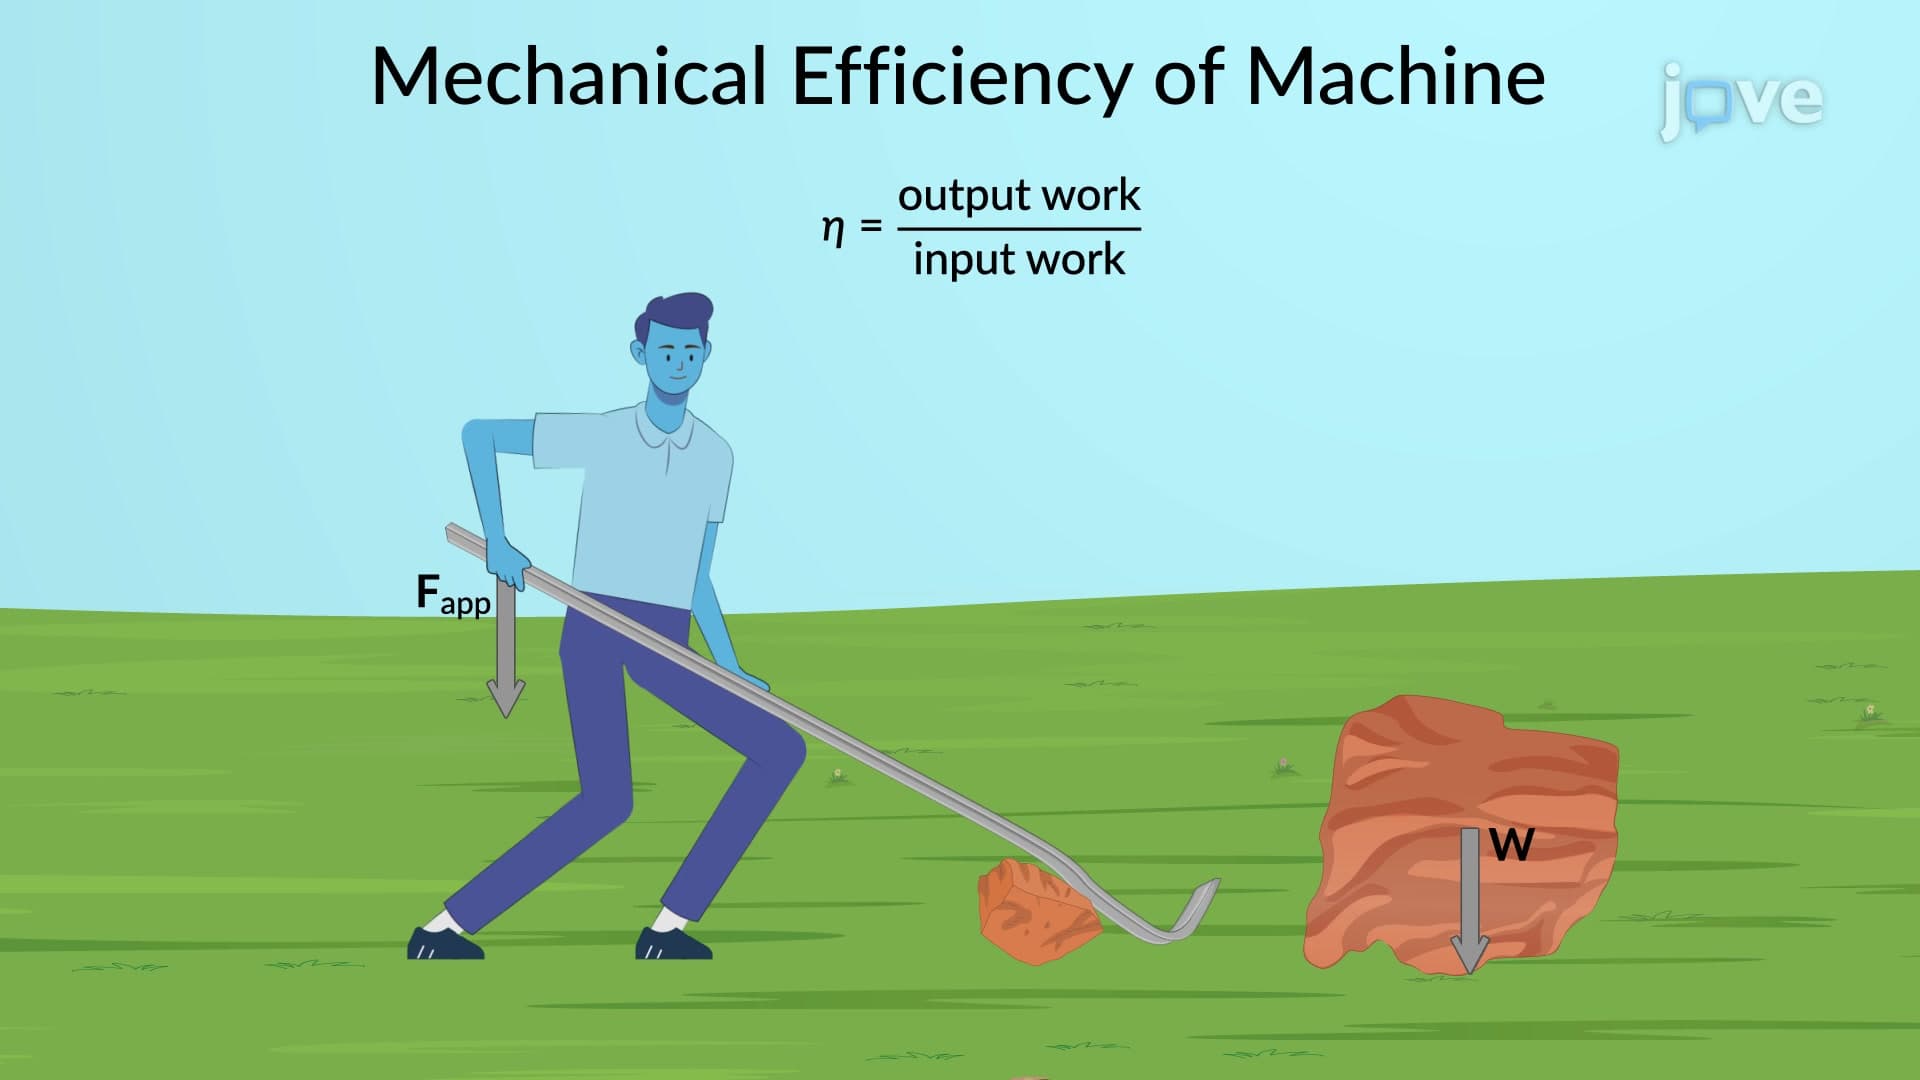
Mechanical Efficiency of Real Machines
However, in reality, no machine can be truly ideal, and all of them experience some...