

Adaptive super-twisting observer for fault reconstruction in electro-hydraulic systems
Mohamad Bahrami1, Mahyar Naraghi1, Mohammad Zareinejad2
1Mechanical Engineering Department, Amirkabir University of Technology, Tehran, Iran.

Abstract:
An adaptive-gain super-twisting sliding mode observer is proposed for fault reconstruction in electro-hydraulic servo systems (EHSS) receiving bounded perturbations with unknown bounds. The objective is to address challenging problems in classic sliding mode observers: chattering effect, conservatism of observer gains, strong condition on the distribution of faults and uncertainties. In this paper, the proposed super-twisting sliding mode observer relaxes the condition on the distribution of uncertainties and faults, and the gain adaptation law leads to eliminate observer gain overestimation and attenuate chattering effects. After using the equivalent output-error-injection feature of sliding mode techniques, a fault reconstruction strategy is proposed. The experimental results are presented, confirming the effectiveness of the proposed adaptive super-twisting observer for precise fault reconstruction in electro-hydraulic servo systems.
Related Concept Videos
 01:19
Electro-mechanical Systems
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...
 01:18
Fault Types
For line-to-line faults occurring between phases B and C, the...
 01:16
Hydraulic Jump: Problem Solving
 01:29
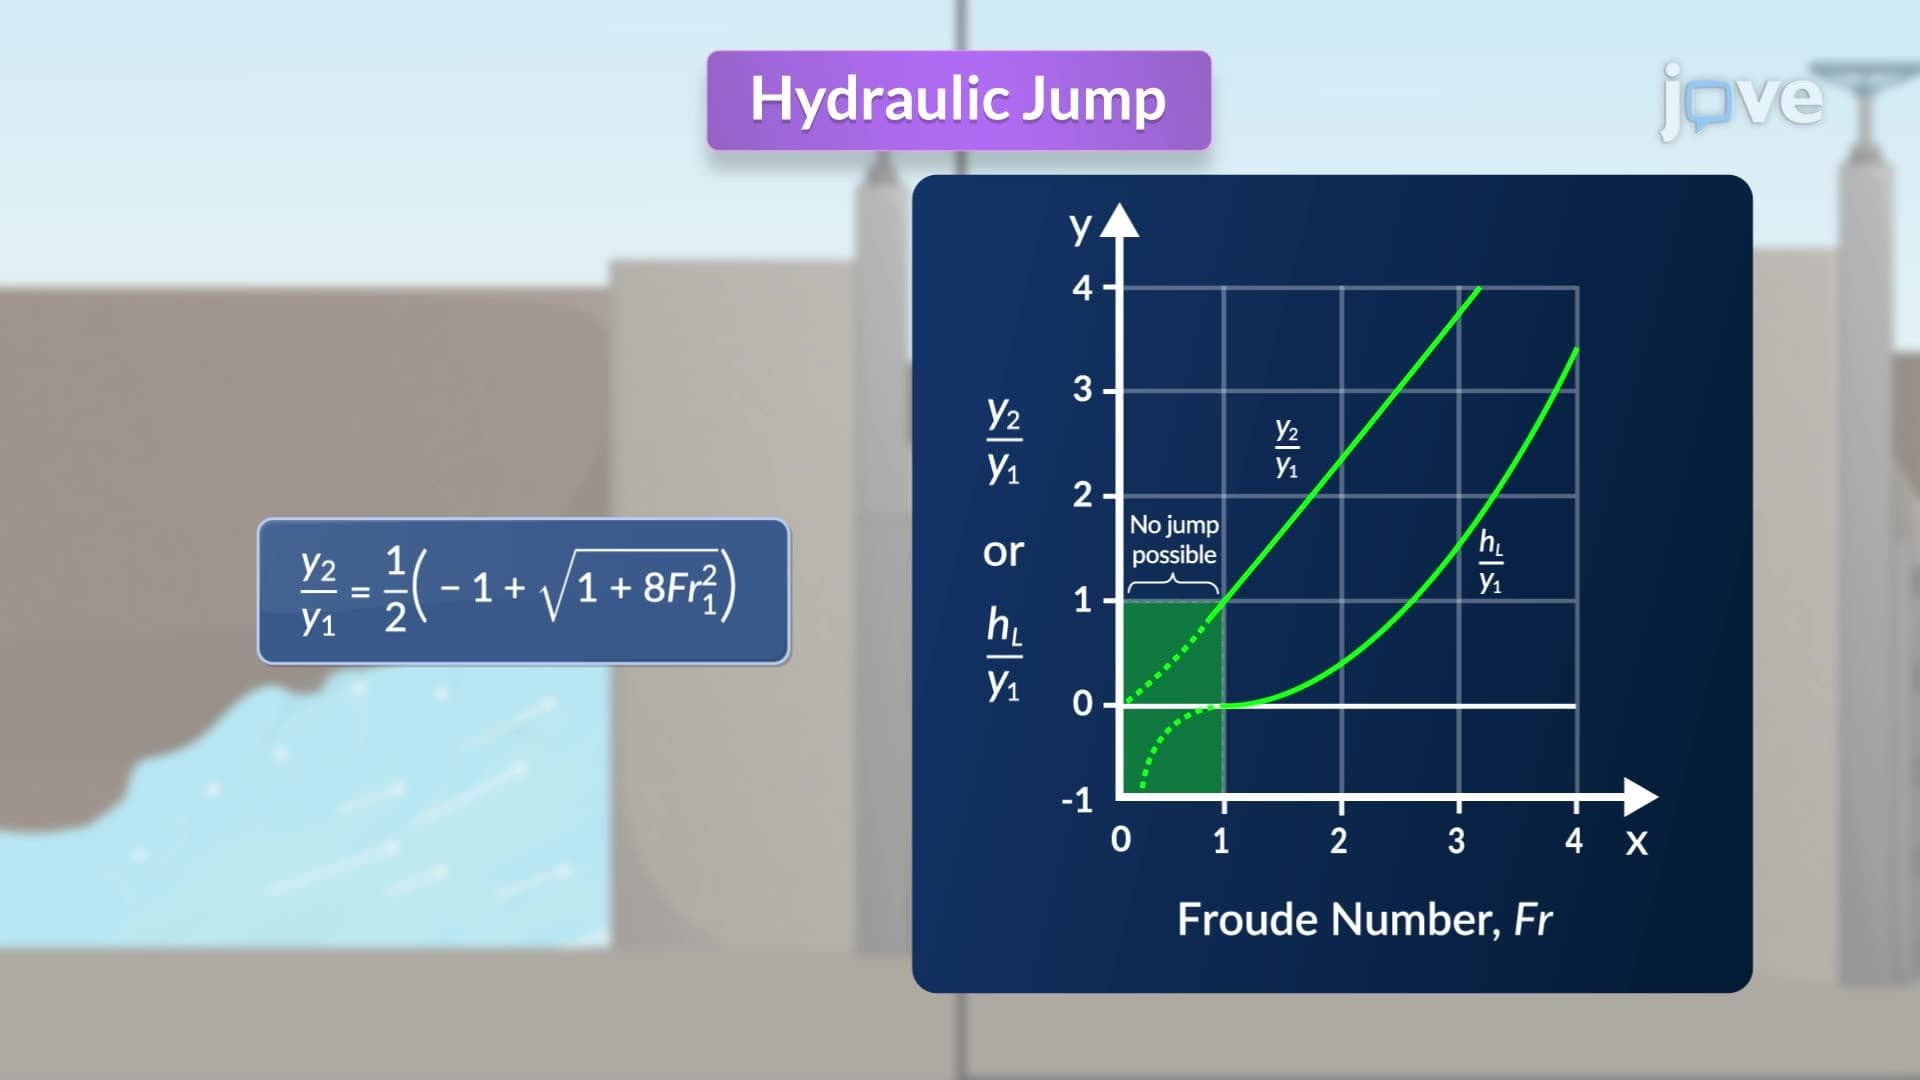
Hydraulic Jump
 01:13
Angle of Twist: Problem Solving
 01:27
Energy Line and Hydraulic Gradient Line