H∞ observer-based event-triggered sliding mode control for a class of discrete-time nonlinear networked systems with quantizations
Related Experiment Video
Updated: Feb 10, 2026
Microwave Photonics Systems Based on Whispering-gallery-mode Resonators
Published on: August 5, 2013
1Faculty of Electronic Information and Electrical Engineering, Dalian University of Technology, Dalian 116023, China; State Key Laboratory of Coastal and Offshore Engineering, Dalian University of Technology, Dalian 116023, China.

Abstract:
This paper investigates the problem of H∞ observer-based event-triggered sliding mode control (SMC) for a class of uncertain discrete-time Lipschitz nonlinear networked systems with quantizations occurring in both input and output channels. The event-triggered strategy is used to save the limited network bandwidth. Then, based on the zero-order-hold (ZOH) measurement, a state observer is designed to reconstruct the system state, which facilitates the design of the discrete-time sliding surface. Considering the effects of quantizations, networked-induced constraints and event-triggered scheme, the nonlinear state error dynamics and sliding mode dynamics are converted into a unified linear parameter varying (LPV) time-delay system with the aid of a reformulated Lipschitz property. By using the Lyapunov-Krasovskii functional and free weighting matrix, a new sufficient condition is derived to guarantee the robust asymptotic stability of the resulting closed-loop system with prescribed H∞ performance. And then the observer gain, event-triggering parameter and sliding mode parameter are co-designed. Furthermore, a novel SMC law is synthesized to force the trajectories of the observer system onto a pre-specified sliding mode region in a finite time. Finally, a single-link flexible joint robot example is utilized to demonstrate the effectiveness of the proposed method.
More Related Videos
 12:09
Network Analysis of the Default Mode Network Using Functional Connectivity MRI in Temporal Lobe Epilepsy
Published on: August 5, 2014
 10:43
Developing Neuroimaging Phenotypes of the Default Mode Network in PTSD: Integrating the Resting State, Working Memory, and Structural Connectivity
Published on: July 1, 2014
Related Concept Videos
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
 01:26
Discrete-time Fourier transform
One of the notable...
 01:16
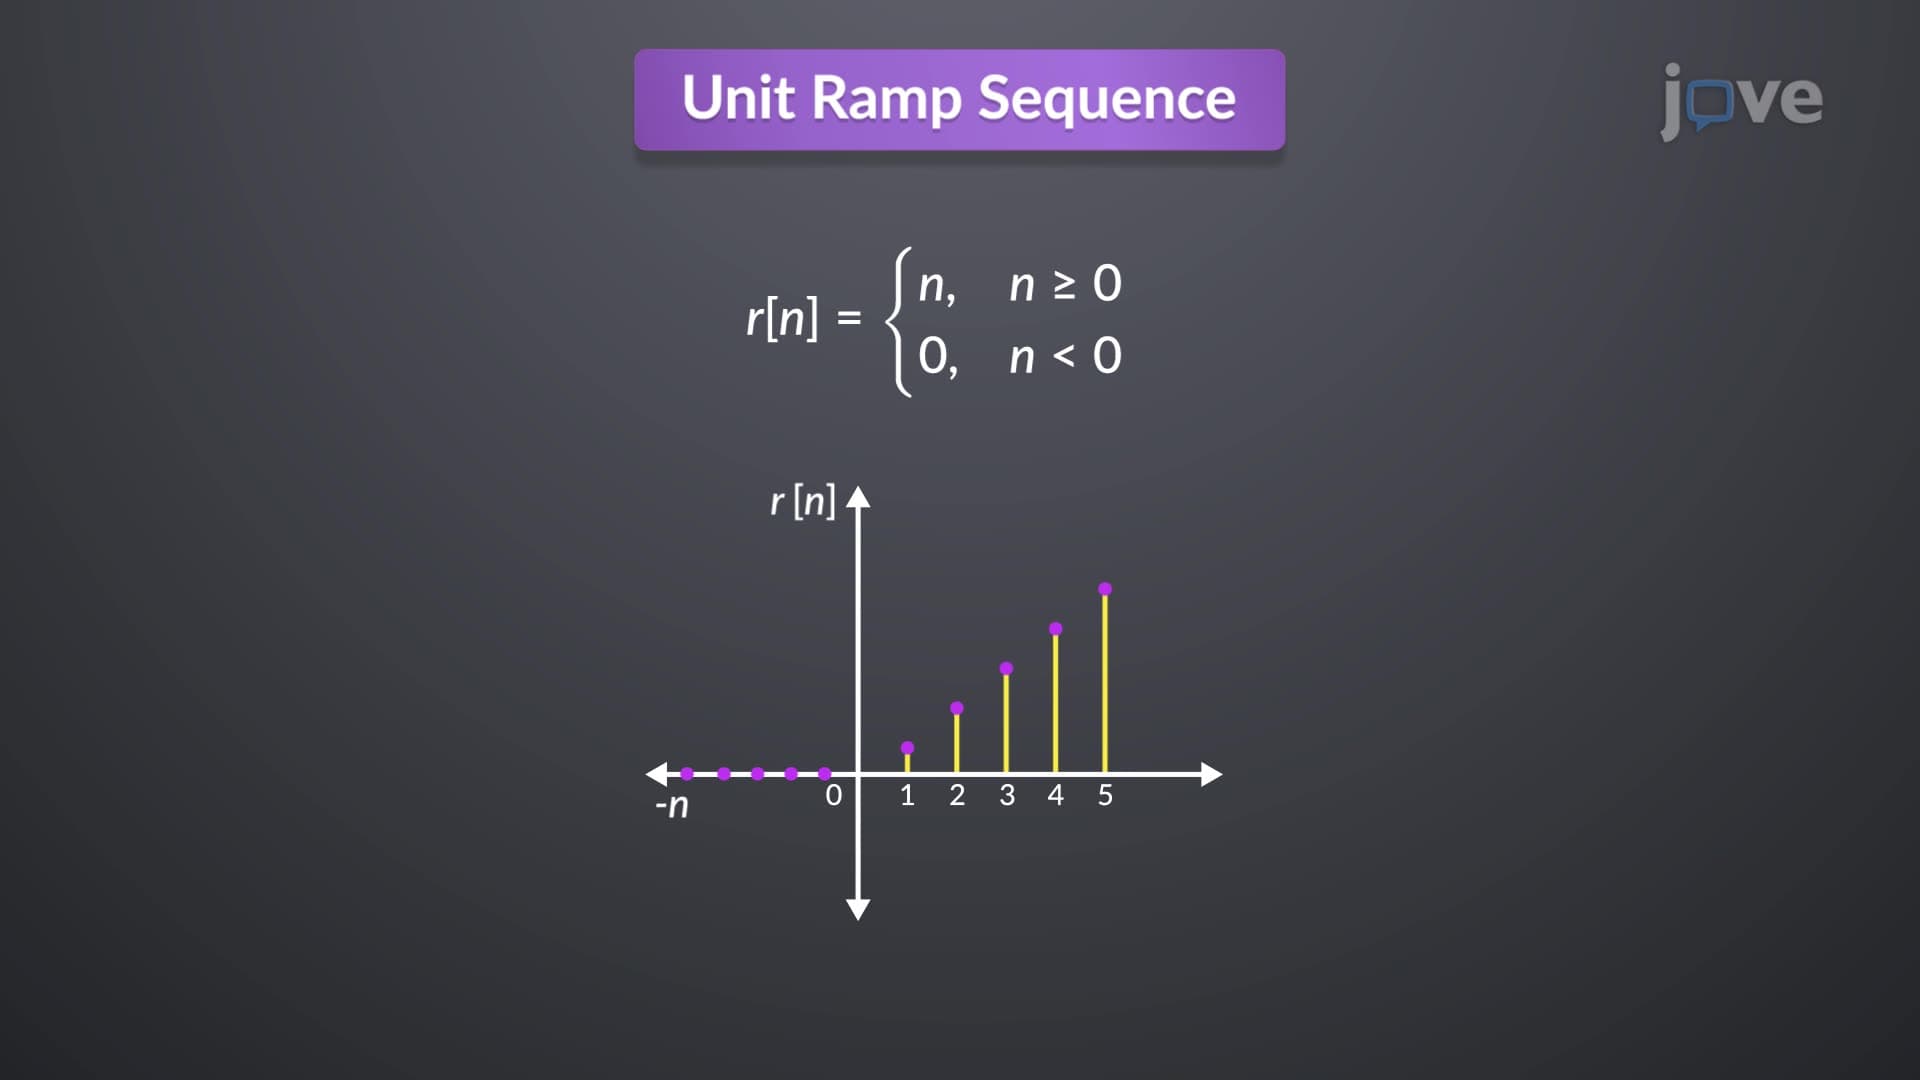
Basic Discrete Time Signals
The unit impulse or sample sequence is mathematically expressed as zero for all n values except at n=0, where it is one. The unit impulse sequence, denoted by δ(n), is the first difference of the unit step sequence, while the unit step sequence u(n) is the...
 01:20
Discrete-Time Fourier Series
For a discrete-time periodic signal x[n]...
 01:10
Control Systems
At the heart...
 01:24
Limits at Infinity