Related Experiment Video
Updated: Feb 9, 2026

A Modeling and Simulation Method for Preliminary Design of an Electro-Variable Displacement Pump
Published on: June 1, 2022
Precise position control of an electro-hydraulic servo system via robust linear approximation
M Fallahi1, M Zareinejad2, K Baghestan1
1Department of Mechanical Engineering, Amirkabir University of Technology, Tehran, Iran.

Abstract:
This paper presents a study on electro-hydraulic servo system for the purpose of position control using a compatible linear model. The system has high level of nonlinearity and linearization introduces extra error in system model. In order to reduce this error several methods of linearization uncertainty are discussed. In spite of applying Taylor's series for all methods, several procedures are used for considering uncertainty on linearization constants. In the first procedure, a simple bound is considered for each linearization constant. In the second procedure, a polytope is extracted for the uncertainty by a graphical method. Finally, a procedure with less conservativeness and less restriction is proposed. This procedure is used to extract the linear model of the electro-hydraulic servo system for the task of position control. The resulting model is used to synthesize an output-feedback H∞ controller for the EHSS using a Linear Matrix Inequality (LMI)-based approach. The effectiveness of the proposed method is demonstrated by simulation and experimental results. The results showed that the procedure is less conservative and has the fastest operation without any overshoot.
More Related Videos

Related Concept Videos
 01:26
Linearization and Approximation
 01:29
Application of Linearization and Approximation
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:13
Linear Momentum in Control Volume
 01:24
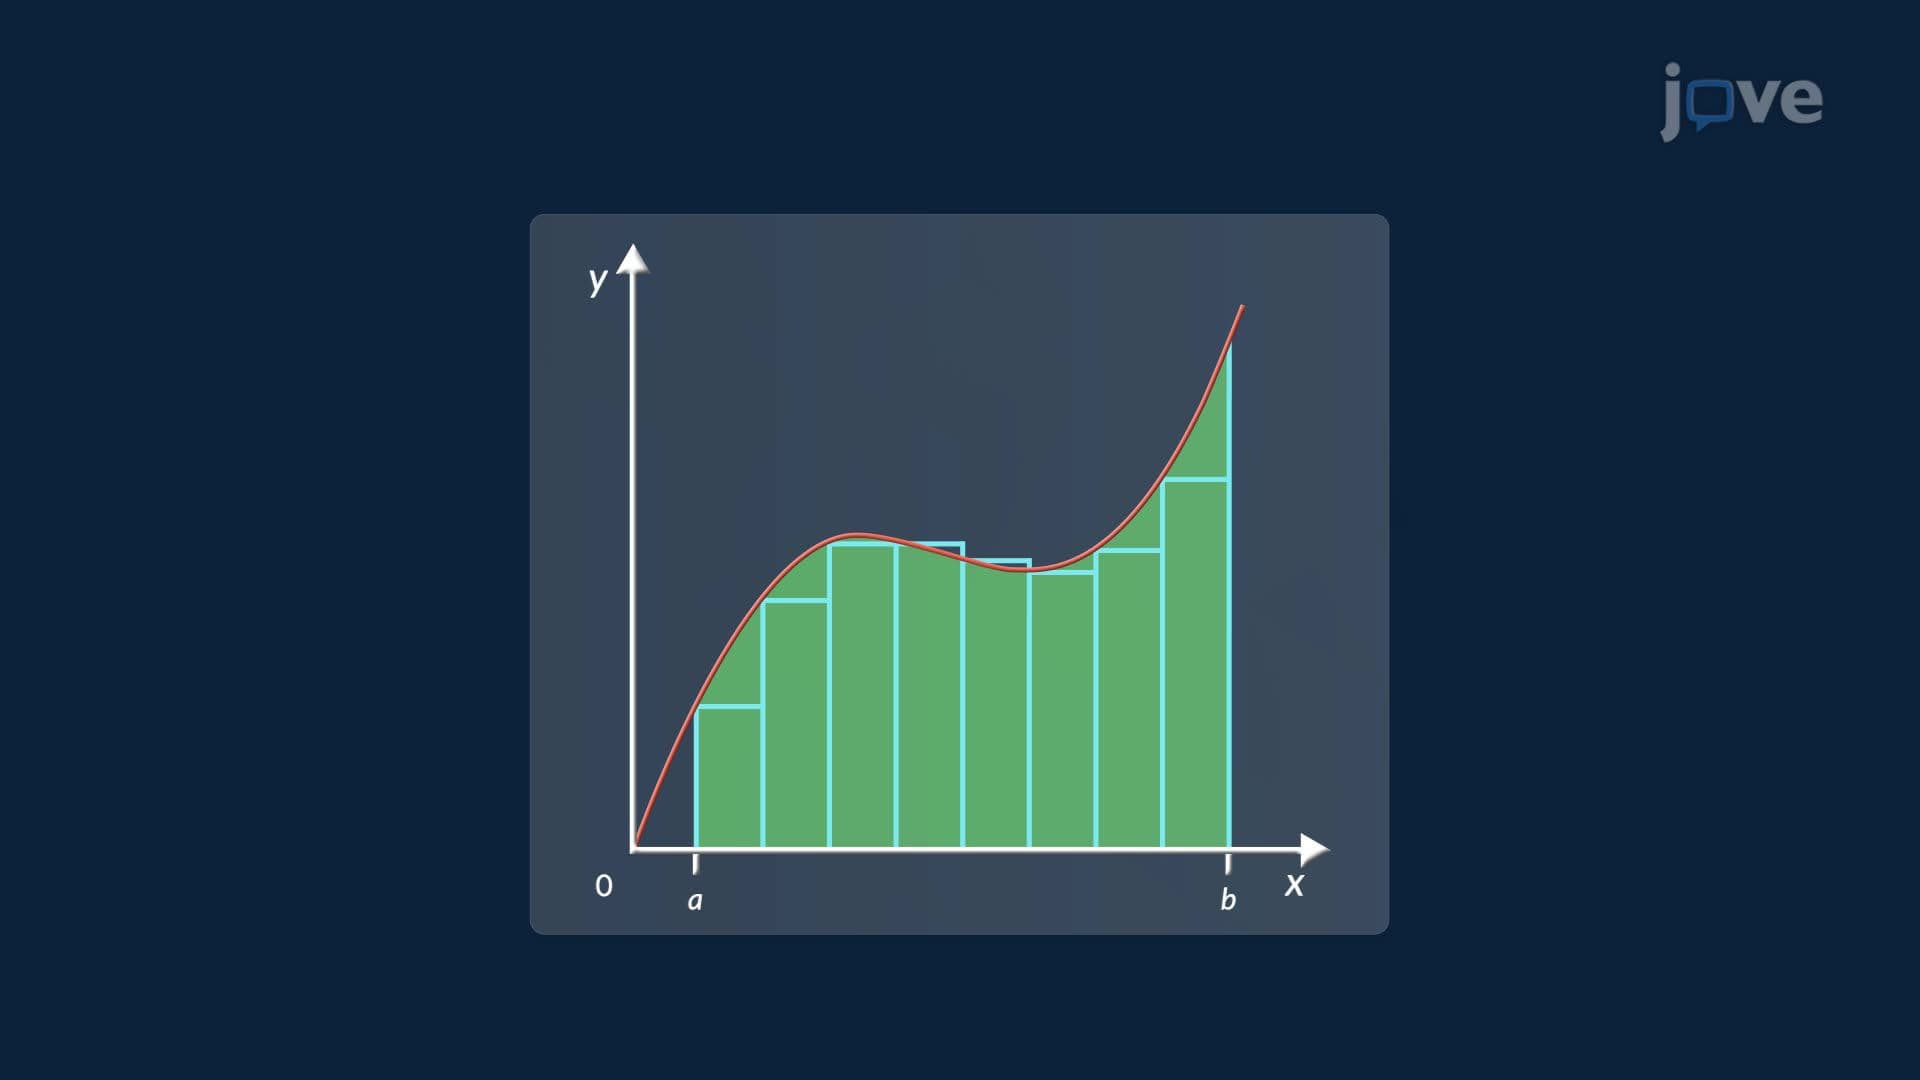
Approximate Integration