Finite-time decentralized adaptive neural constrained control for interconnected nonlinear time-delay systems with dynamics couplings among subsystems
Related Experiment Video
Updated: Feb 7, 2026
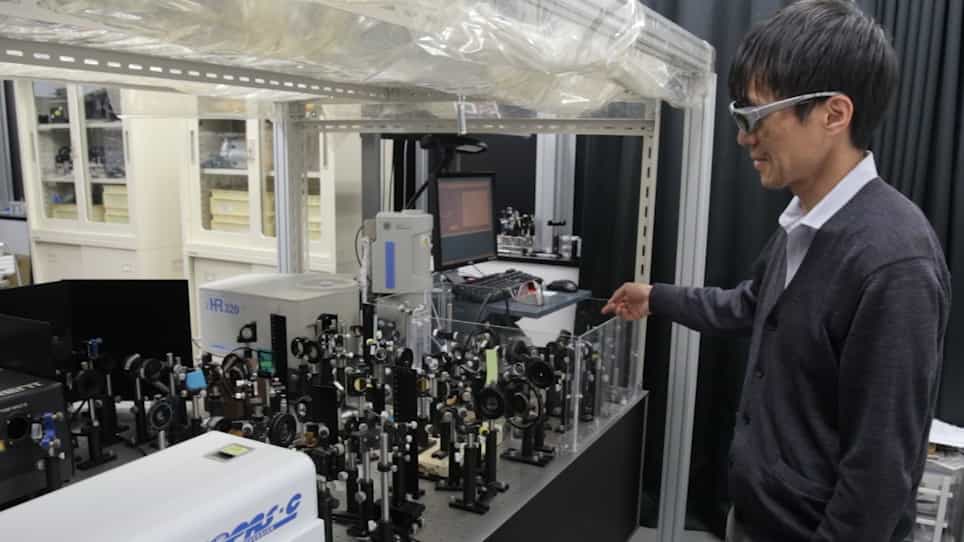
Ultrafast Time-resolved Near-IR Stimulated Raman Measurements of Functional π-conjugate Systems
Published on: February 10, 2020
1School of Electrical and Control Engineering, Henan University of Urban Construction, Pingdingshan, 467036, China.

Abstract:
The problem of finite-time decentralized neural adaptive constrained control is studied for large-scale nonlinear time-delay systems in the non-affine form. The main features of the considered system are that 1) unknown unmatched time-delay interactions are considered, 2) the couplings among the nested subsystems are involved in uncertain nonlinear systems, 3) based on finite-time stability approach, asymmetric saturation actuators and output constraints are studied in large-scale systems. First, the smooth asymmetric saturation nonlinearity and barrier Lyapunov functions are used to achieve the input and output constraints. Second, the appropriately designed Lyapunov-Krasovskii functional and the property of hyperbolic tangent functions are used to deal with the unknown unmatched time-delay interactions, and the neural networks are employed to approximate the unknown nonlinearities. Note that, due to unknown time-delay interactions and the couplings among subsystems, the controller design is more meaningful and challenging. At last, based on finite-time stability theory and Lyapunov stability theory, a decentralized adaptive controller is proposed, which decreases the number of learning parameters. It is shown that the designed controller can ensure that all closed-loop signals are bounded and the tracking error converges to a small neighborhood of the origin. The simulation studies are presented to show the effectiveness of the proposed method.

Related Concept Videos
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
 01:27
Time and frequency -Domain Interpretation of PI Control
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires...
 01:10
Control Systems
At the heart...
 01:24
Time and frequency -Domain Interpretation of Phase-lead Control
The design of phase-lead control involves the strategic placement of poles and zeros to balance steady-state error and system...