Related Experiment Video
Updated: Feb 6, 2026

Author Spotlight: Enhancement of Salient Object Detection for Smart Grid Applications
Published on: December 15, 2023
Recurrent Neural Network for Kinematic Control of Redundant Manipulators With Periodic Input Disturbance and Physical

Abstract:
Input disturbances and physical constraints are important issues in the kinematic control of redundant manipulators. In this paper, we propose a novel recurrent neural network to simultaneously address the periodic input disturbance, joint angle constraint, and joint velocity constraint, and optimize a general quadratic performance index. The proposed recurrent neural network applies to both regulation and tracking tasks. Theoretical analysis shows that, with the proposed neural network, the end-effector tracking and regulation errors asymptotically converge to zero in the presence of both input disturbance and the two constraints. Simulation examples and comparisons with an existing controller are also presented to validate the effectiveness and superiority of the proposed controller.
Related Concept Videos
 02:26
Ecological Disturbance
 01:18
Neural Control of Respiration
Respiratory Centers in the Brainstem
Two primary areas comprise the respiratory center: the medullary respiratory center in the medulla oblongata and the pontine respiratory group in the pons. The...
 01:23
Physical Methods for Controlling Microbial Growth: Temperature
 01:29
Disturbances in Heart Rhythm
Arrhythmias are categorized by their speed, rhythm, and origin. A slow heart...
 03:25
The Periodic Table
 01:26
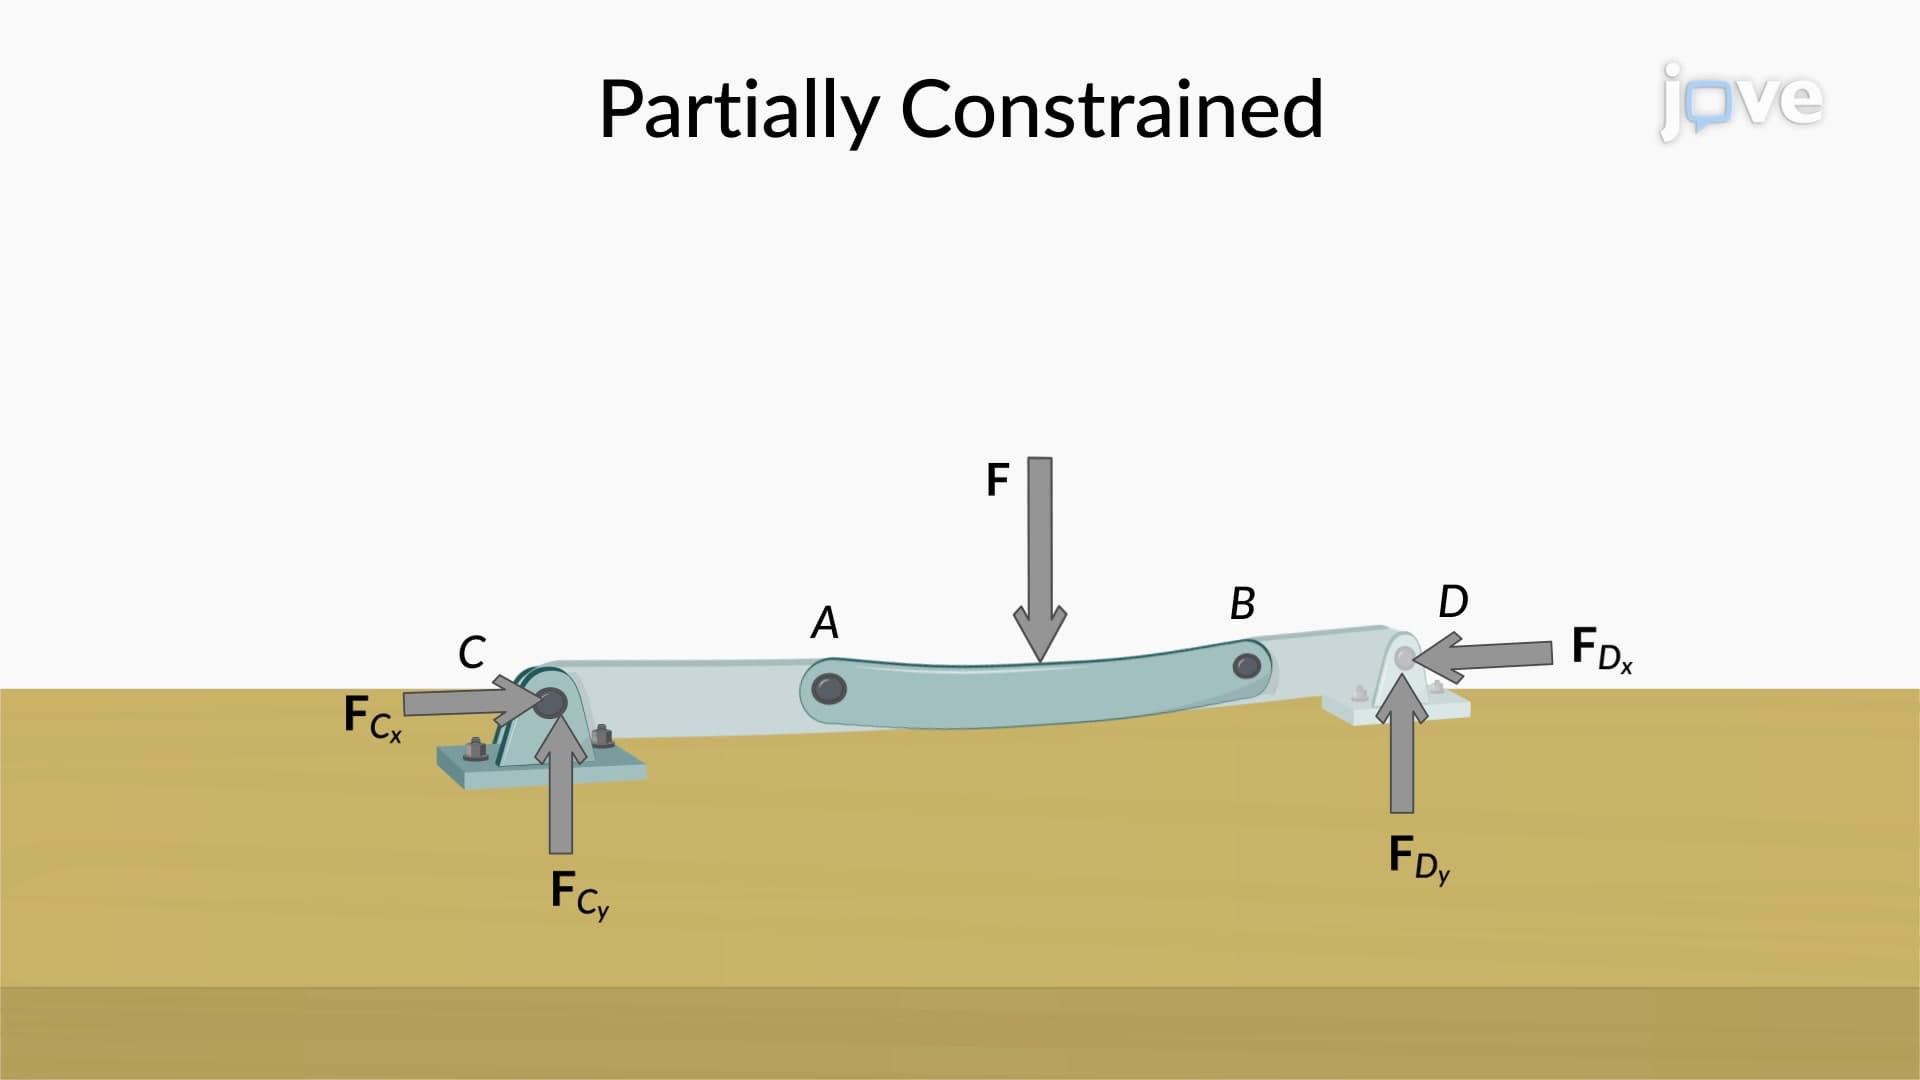
Constraints and Statical Determinacy