Related Experiment Video
Updated: Feb 4, 2026

The Use of Chemostats in Microbial Systems Biology
Published on: October 14, 2013
Multipoint Rendezvous in Multirobot Systems

Abstract:
Multirobot rendezvous control and coordination strategies have garnered significant interest in recent years because of their potential applications in decentralized tasks. In this paper, we introduce a coordinate-free rendezvous control strategy to enable multiple robots to gather at different locations (dynamic leader robots) by tracking their hierarchy in a connected interaction graph. A key novelty in this strategy is the gathering of robots in different groups rather than at a single consensus point, motivated by autonomous multipoint recharging and flocking control problems. We show that the proposed rendezvous strategy guarantees convergence and maintains connectivity while accounting for practical considerations such as robots with limited speeds and an obstacle-rich environment. The algorithm is distributed and handles minor faults such as a broken immobile robot and a sudden link failure. In addition, we propose an approach that determines the locations of rendezvous points based on the connected interaction topology and indirectly optimizes the total energy consumption for rendezvous in all robots. Through extensive experiments with the Robotarium multirobot testbed, we verified and demonstrated the effectiveness of our approach and its properties.
Related Concept Videos
 01:18
Second Order systems II
 01:21
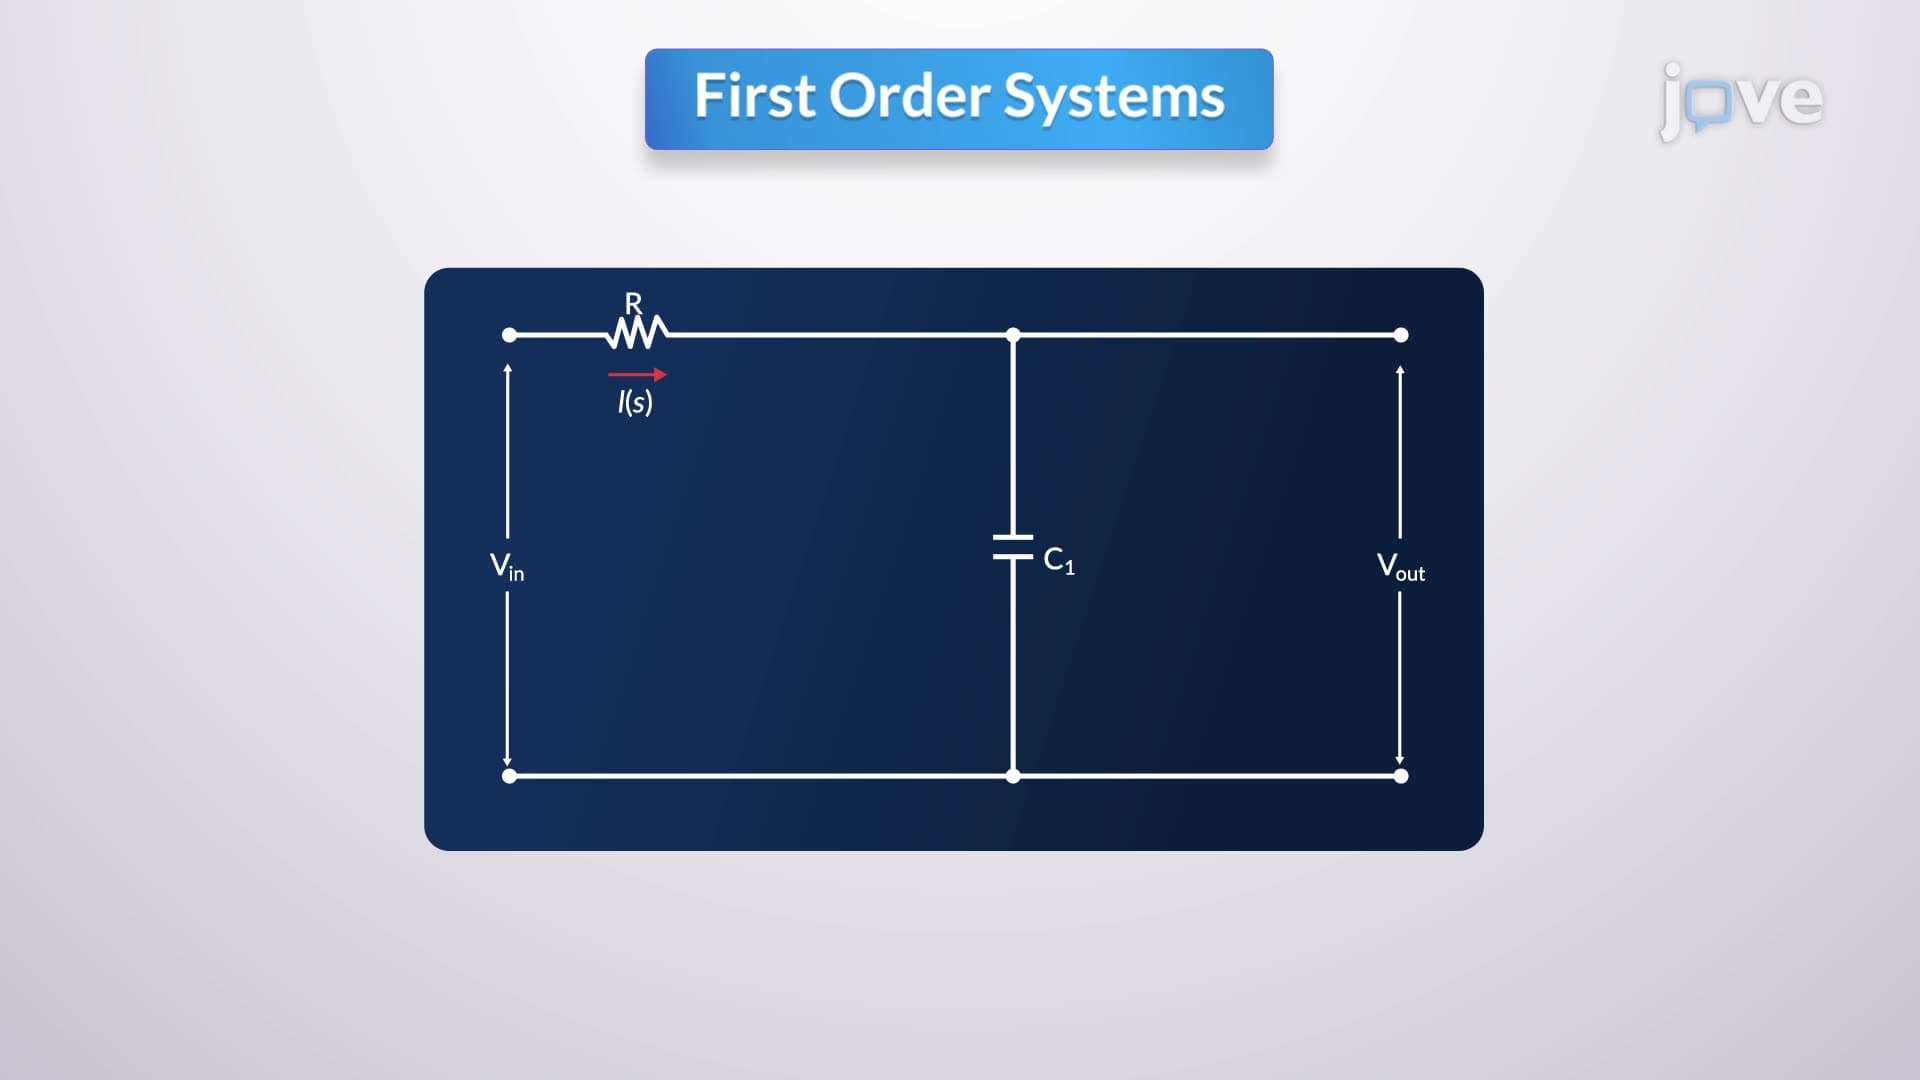
First Order Systems
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:20
Second Order systems I
By reinterpreting the system, one can derive the closed-loop transfer function, which...
 01:06
Thermodynamic Systems
Consider an example of tea boiling in a kettle. The...
 01:26
Classification of Systems-I
Homogeneity dictates that if an input x(t) is multiplied by a constant c, the output y(t) is multiplied by the same constant. Mathematically, this is expressed as:
 01:31
Classification of Systems-II