Related Experiment Video
Updated: Feb 4, 2026

A Method for Quantifying Upper Limb Performance in Daily Life Using Accelerometers
Published on: April 21, 2017
Soft Poly-Limbs: Toward a New Paradigm of Mobile Manipulation for Daily Living Tasks
Pham Huy Nguyen1, Curtis Sparks1, Sai G Nuthi2
11 The Polytechnic School, Ira A. Fulton Schools of Engineering, Arizona State University, Mesa, Arizona.

Abstract:
We present the design and development of the fluid-driven, wearable, Soft Poly-Limb (SPL), from the Greek word polys, meaning many. The SPL utilizes the numerous traits of soft robotics to enable a novel approach in providing safe and compliant mobile manipulation assistance to healthy and impaired users. This wearable system equips the user with a controllable additional limb that is capable of complex three-dimensional motion in space. Similar to an elephant trunk, the SPL is able to manipulate objects using a variety of end effectors, such as suction adhesion or a soft grasper, as well as its entire soft body to conform around an object, able to lift 2.35 times its own weight. To develop these highly articulated soft robotic limbs, we provide a novel set of systematic design rules, obtained through varying geometrical parameters of the SPL through experimentally verified finite element method models. We investigate performance of the limb by testing the lifetime of the new SPL actuators, evaluating its payload capacity, operational workspace, and capability of interacting close to a user through a spatial mobility test. Furthermore, we are able to demonstrate limb controllability through multiple user-intent detection modalities. Finally, we explore the limb's ability to assist in multitasking and pick and place scenarios with varying mounting locations of the SPL around the user's body. Our results highlight the SPL's ability to safely interact with the user while demonstrating promising performance in assisting with a wide variety of tasks, in both work and general living settings.
More Related Videos
 06:43
The Crossmodal Congruency Task as a Means to Obtain an Objective Behavioral Measure in the Rubber Hand Illusion Paradigm
Published on: July 26, 2013
 05:28
Author Spotlight: Enhancing Upper Limb Rehabilitation in Stroke Patients Through Advanced Robotic and Neuromodulation Technologies
Published on: October 11, 2024
Related Concept Videos
 01:17
Classical Conditioning in Daily Life
John B. Watson and Rosalie Rayner famously demonstrated the development of fear through classical conditioning in their experiment with Little Albert. They paired the...
 01:20
Arteries of Lower Limbs
 01:15
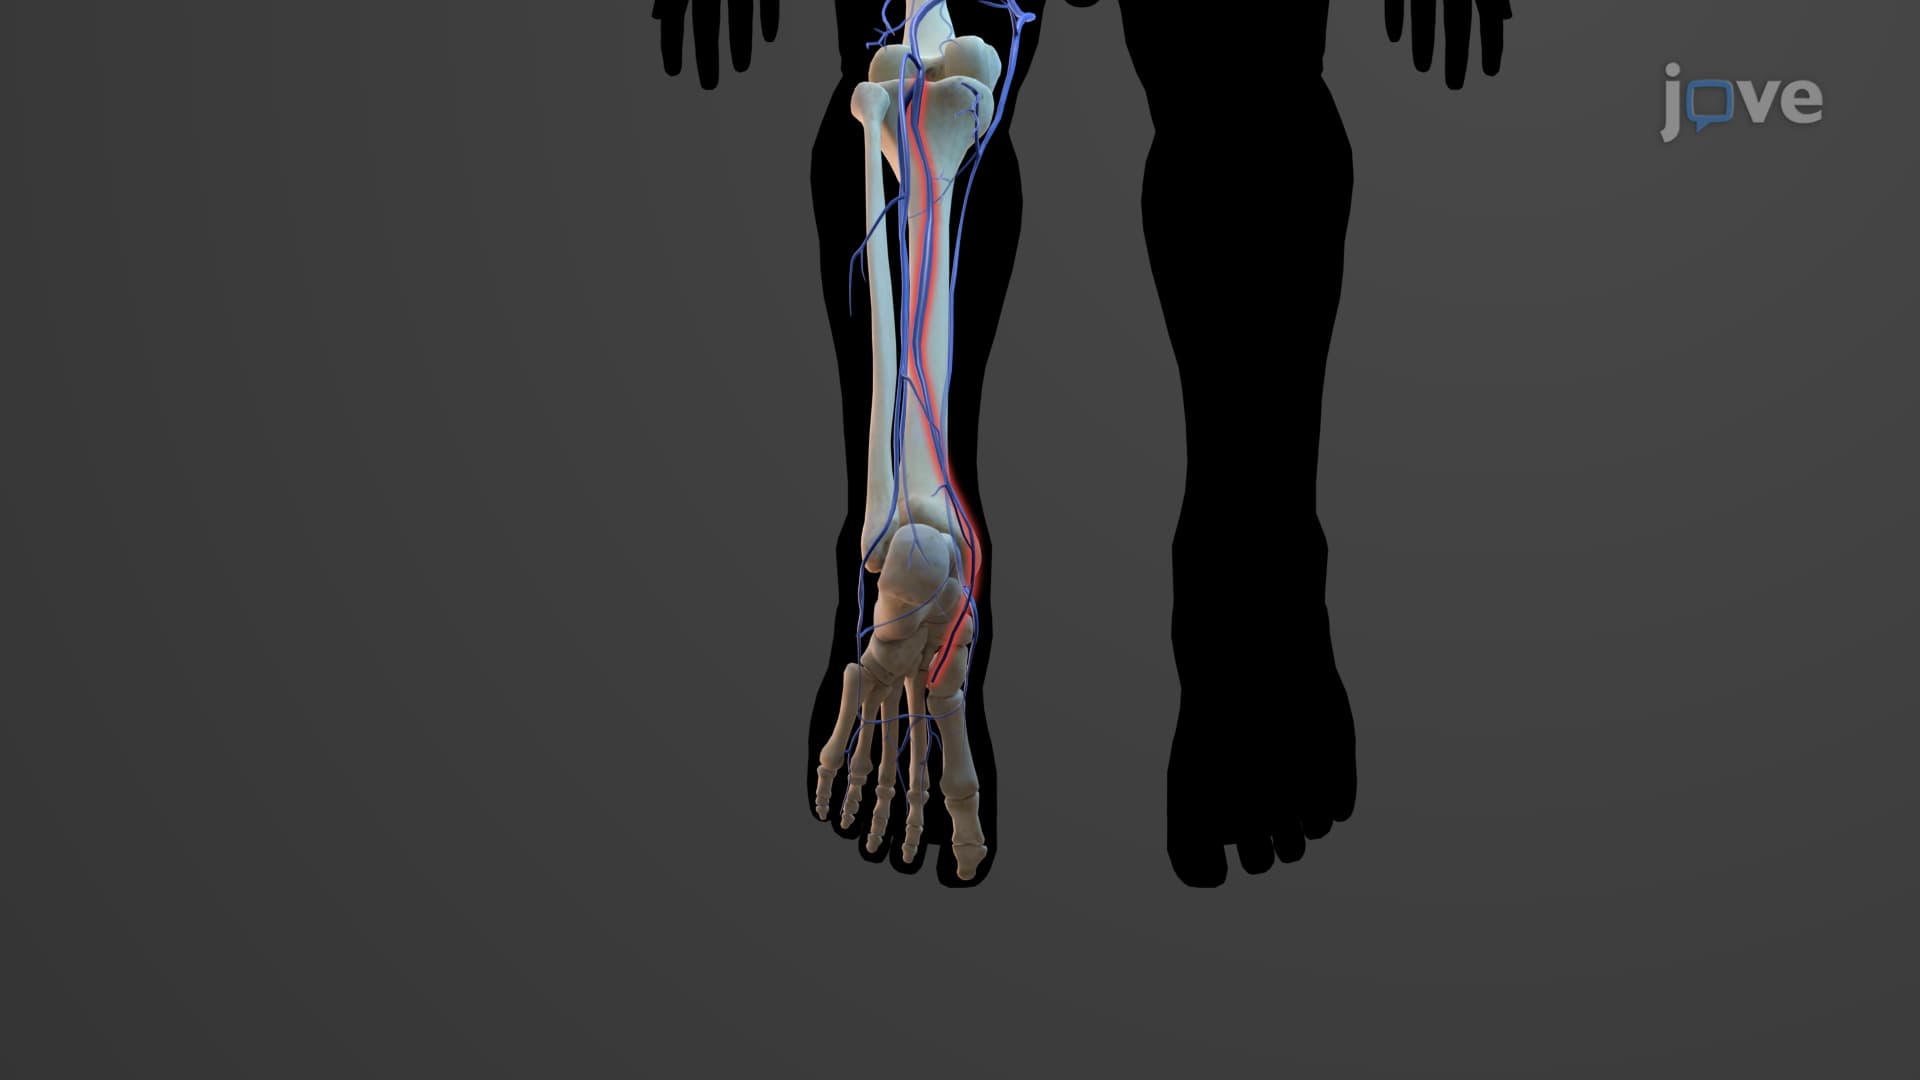
Veins of Lower Limbs
Formed by the union of the medial and lateral plantar veins, the posterior tibial vein, rising through the calf muscle, assimilates the fibular vein. The anterior tibial vein, a superior extension of the foot's dorsalis pedis vein, merges with the posterior tibial vein at the...
 01:21
Manipulation and Analysis
 01:17
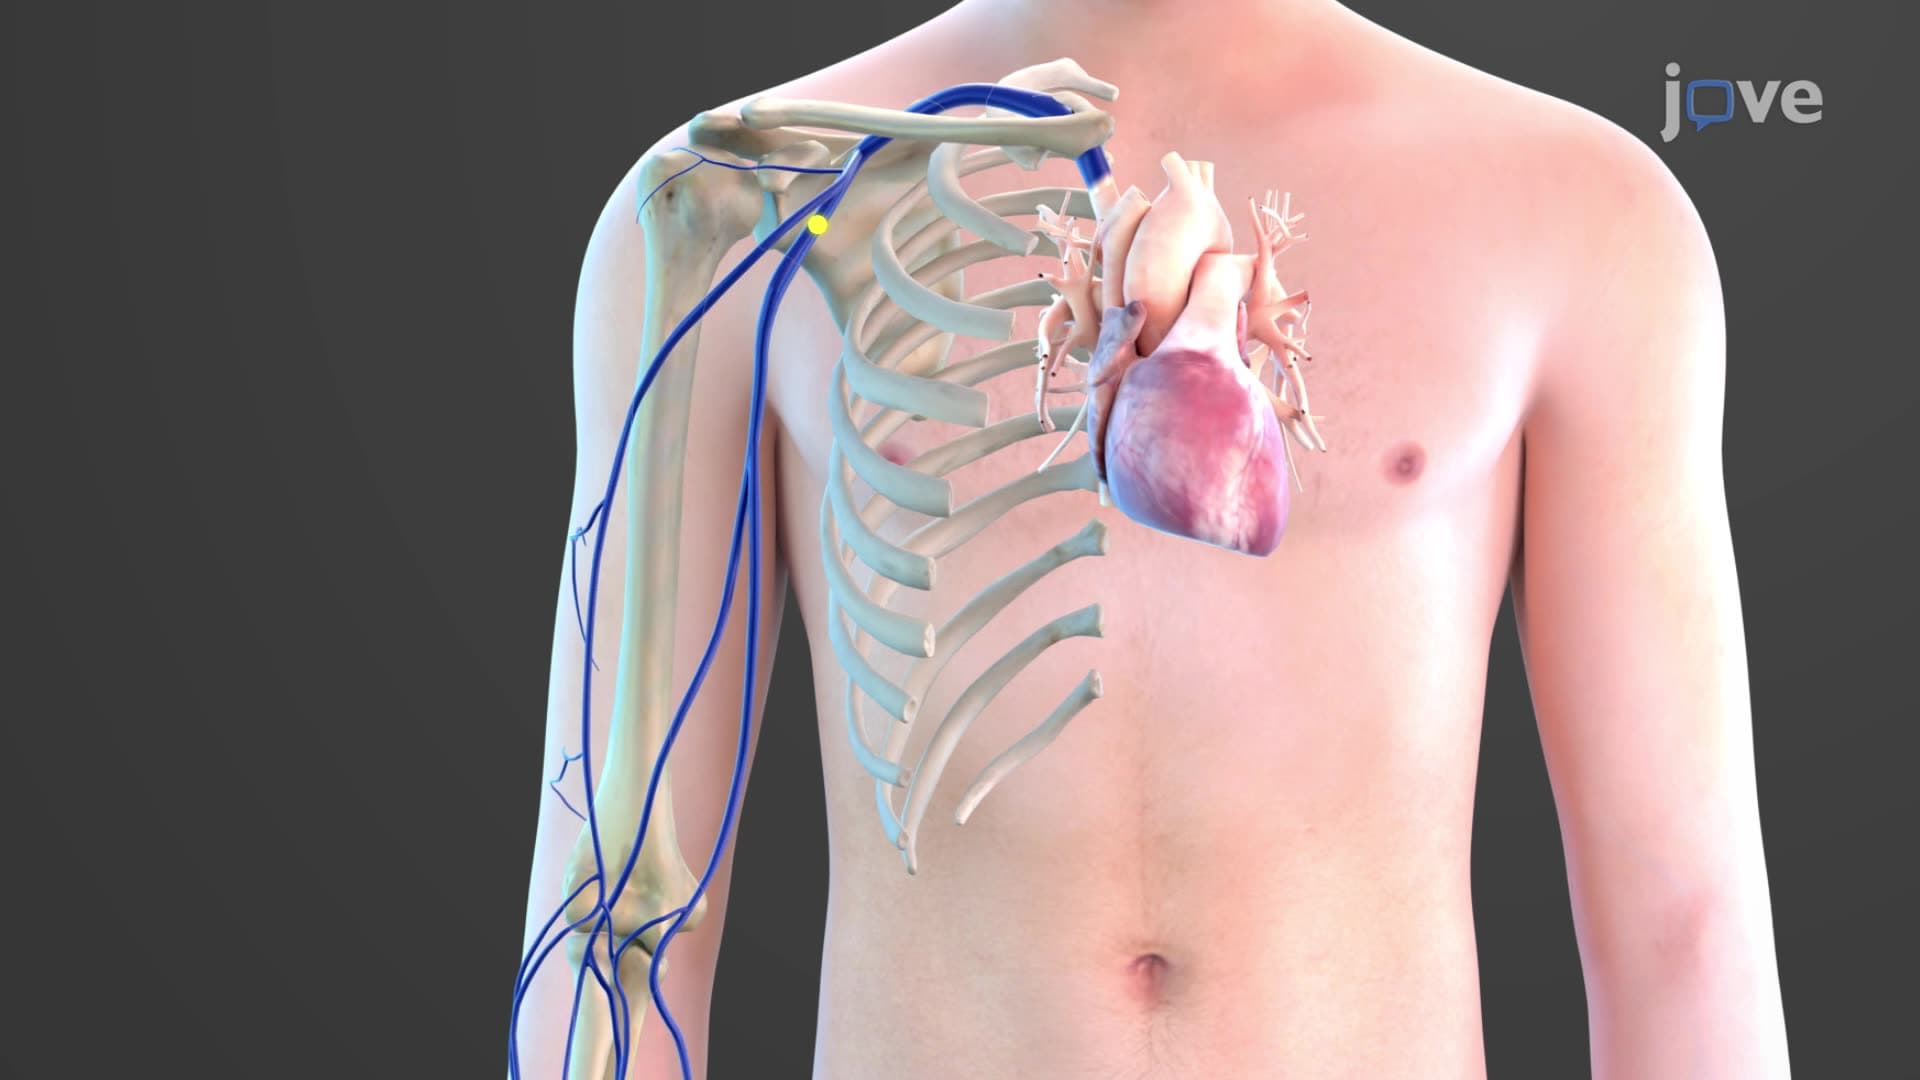
Veins of Upper Limbs
The deep venous system is primarily composed of the ulnar and radial veins. The ulnar vein, which drains the fingers through the superficial palmar venous arches, and the radial vein, which serves the palms via the deep palmar...
 01:12
Arteries of the Upper Limbs