Energy efficient walking control for biped robots using interval type-2 fuzzy logic systems and optimized iteration algorithm
Related Experiment Video
Updated: Feb 1, 2026

Manufacturing, Control, and Performance Evaluation of a Gecko-Inspired Soft Robot
Published on: June 10, 2020
Liang Yang1, Zhi Liu2, Yong Chen3
1School of Computer Engineering, University of Electronic Science and Technology of China, Zhongshan Institute, Zhongshan, Guangdong 528402, China; School of Automation Engineering, University of Electronic Science and Technology of China, Chendu, Sichuan 611731, China.

Abstract:
An energy efficient approach is proposed for the walking control of bipedal robots. To compensate the ZMP error caused by model uncertainties and external disturbances, we design a new walking controller in this paper. Different from currently available control schemes for cancelling ZMP error, our newly proposed one additionally incorporates a fuzzy logic systems(FLSs) mechanism and an iterative mechanism. By employing FLSs to deduce Center of Mass(CoM) correction according to ZMP error and designing iterative mechanism to compute the optimal joint position, the newly proposed controller exhibits an excellent performance. To tackle the control difficulties arising from physical constraints of actuators and hard-to-stabilization of biped robot, an optimized control algorithm is included in the iterative mechanism to guarantee the convergence to the optimal solution. Moreover, the interval type-2 FLSs are adopted to handle the uncertainties. Finally, the experiment results are provided to validate the proposed control scheme.
More Related Videos
 11:53
Spatial Multiobjective Optimization of Agricultural Conservation Practices using a SWAT Model and an Evolutionary Algorithm
Published on: December 9, 2012
 09:00
Insect-controlled Robot: A Mobile Robot Platform to Evaluate the Odor-tracking Capability of an Insect
Published on: December 19, 2016
Related Concept Videos
 01:10
Control Systems
At the heart...
 01:25
Control Systems: Applications
In modern vehicles, control systems manage various functions to enhance performance and safety. The steering wheel and accelerator are primary inputs in a car's control system. The...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:14
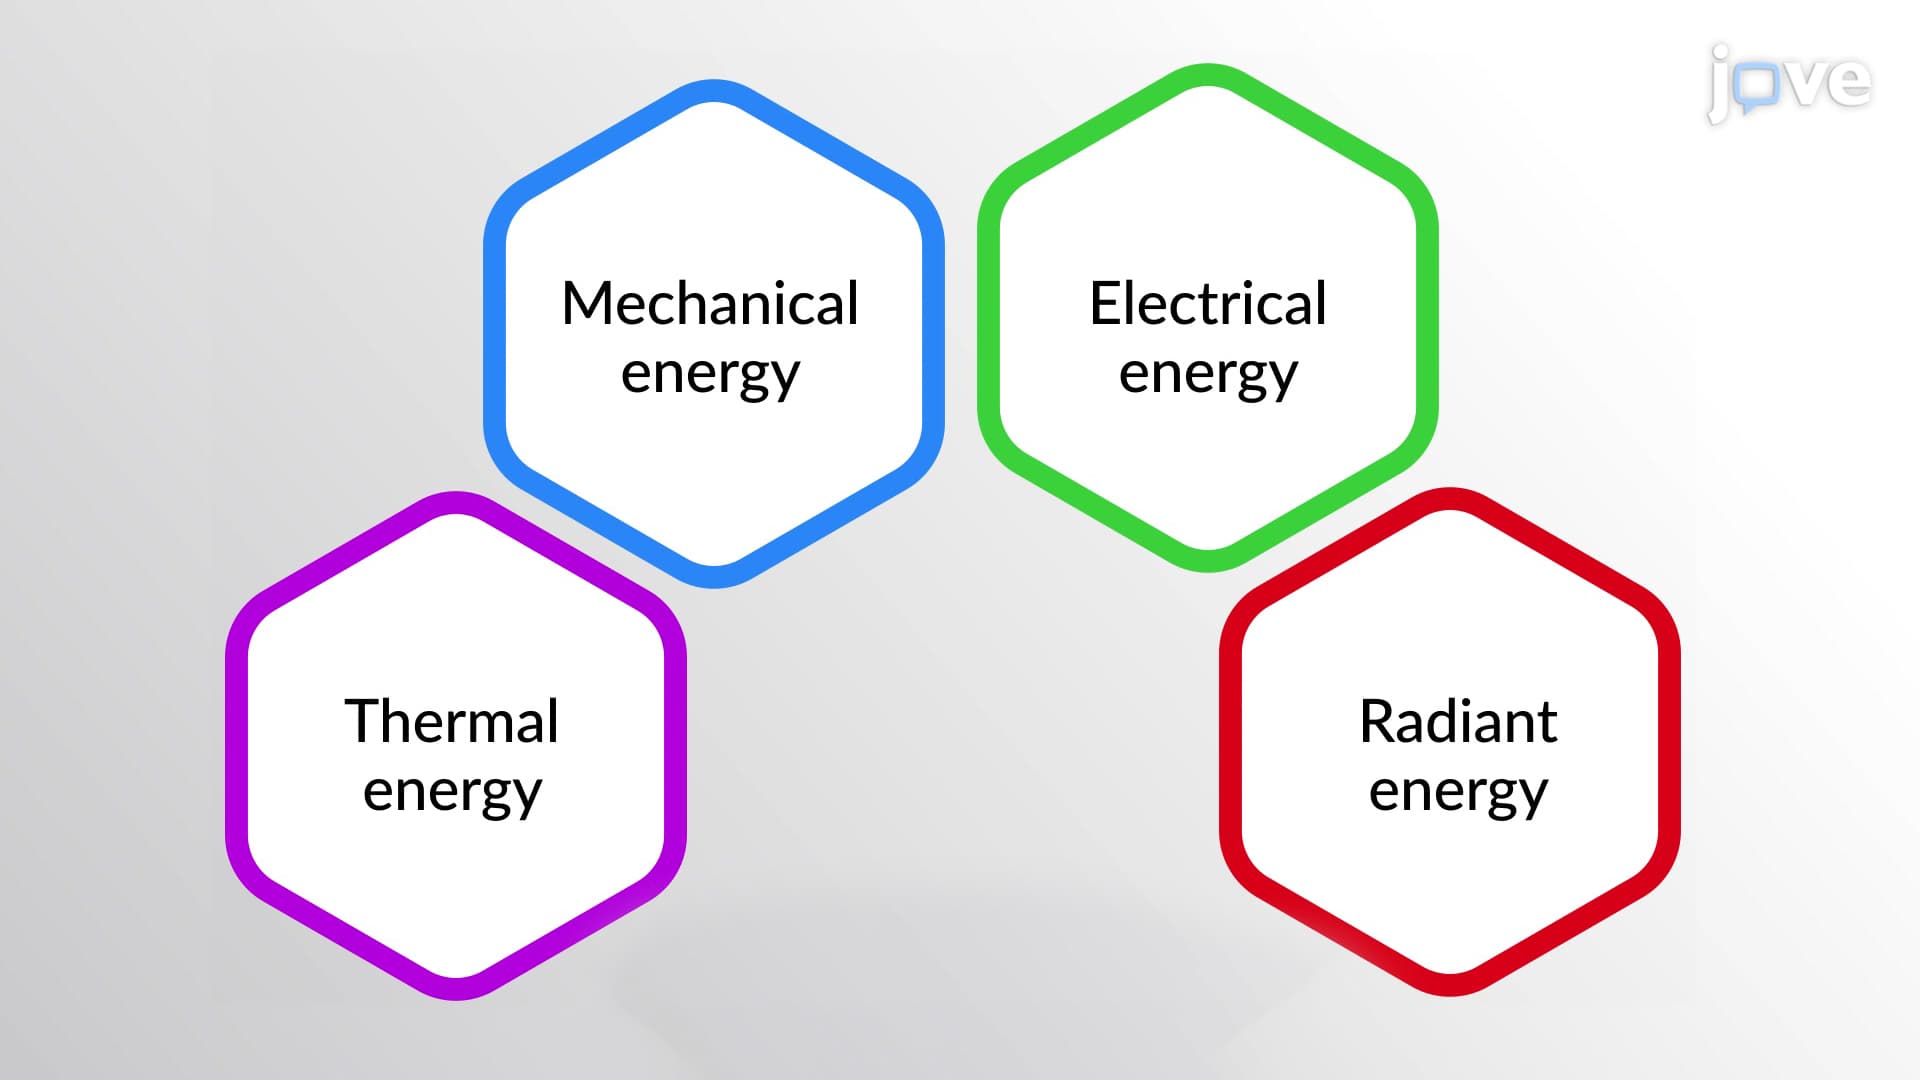
Types of Kinetic Energy
There are several different forms of kinetic energy, including mechanical, electrical, radiant, and thermal energy. Mechanical energy is...
 01:16
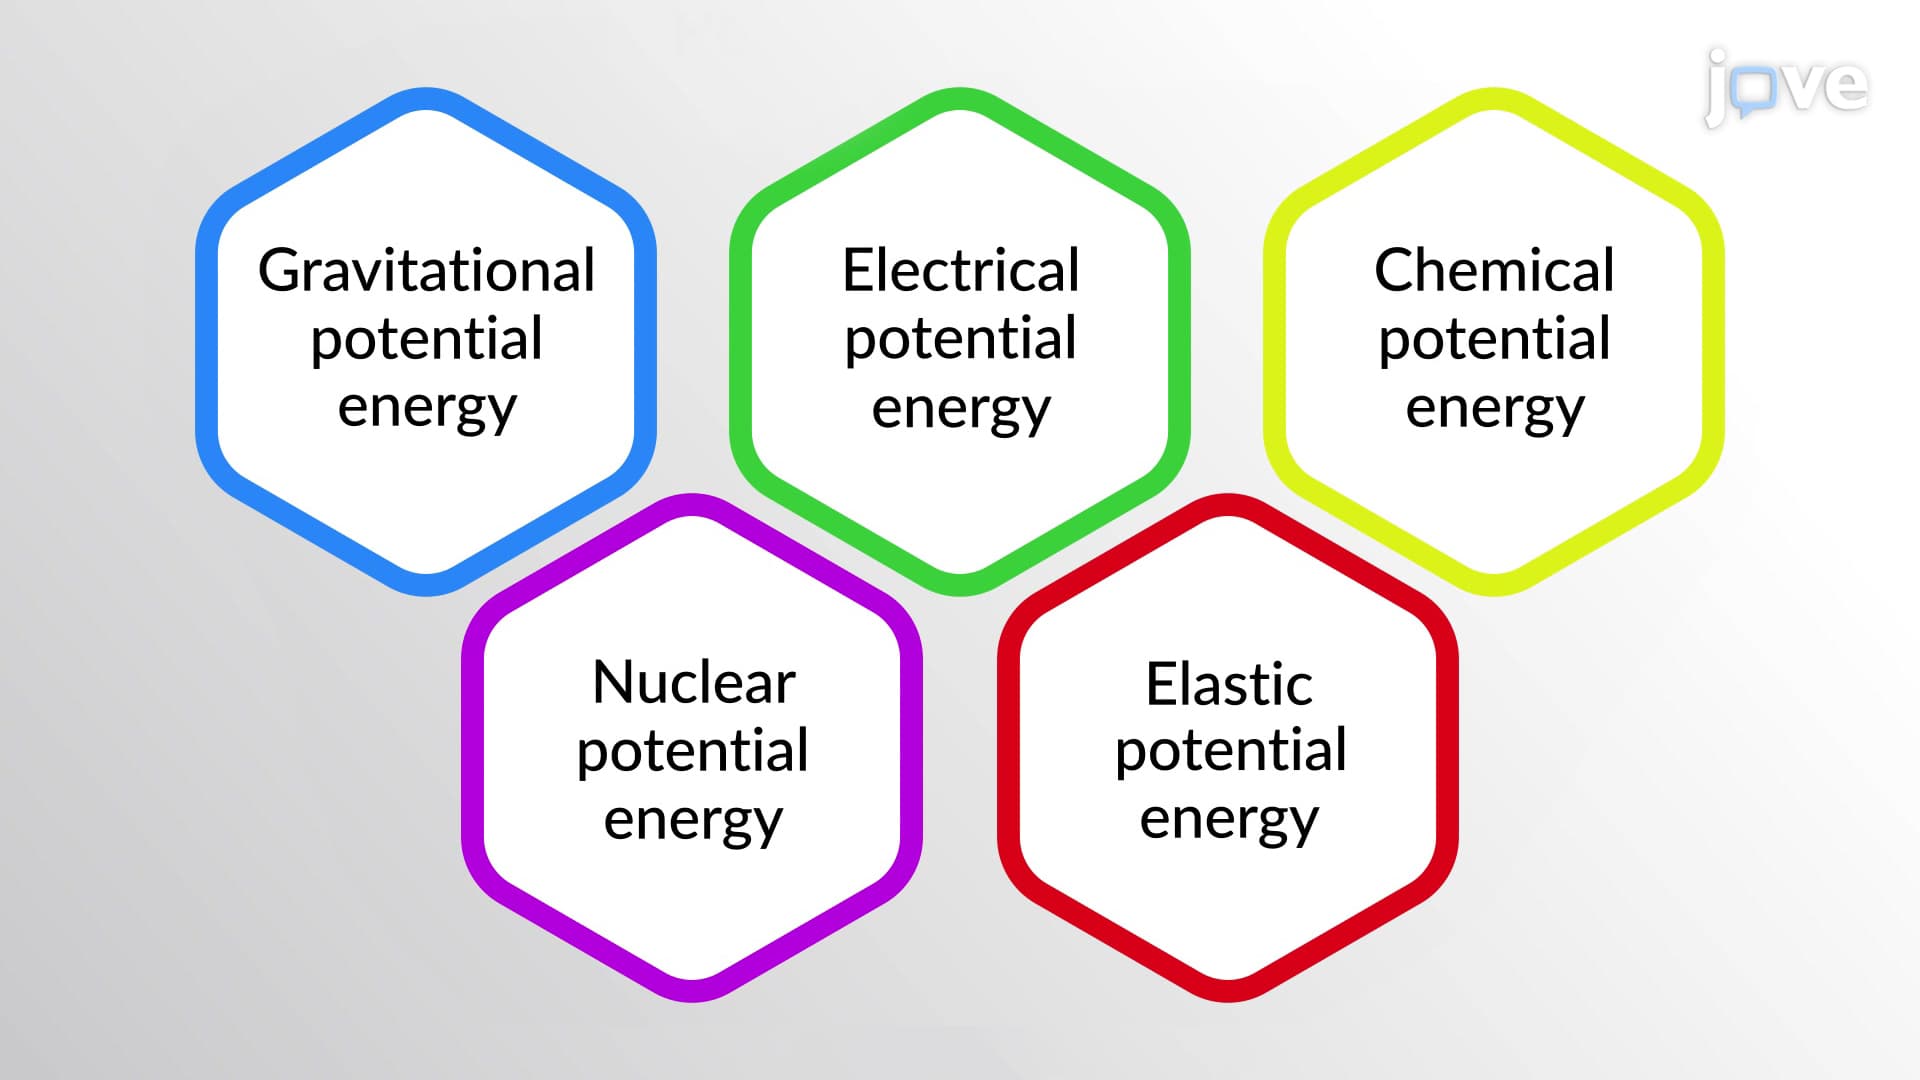
Types of Potential Energy
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...