Related Experiment Video
Updated: Feb 1, 2026
Network Analysis of the Default Mode Network Using Functional Connectivity MRI in Temporal Lobe Epilepsy
Published on: August 5, 2014
Development of an adaptive radial basis function neural network estimator-based continuous sliding mode control for
Nada M Moawad1, Wael M Elawady2, Amany M Sarhan2
1Faculty of Engineering, Kafrelshiekh University, Egypt.

Abstract:
In this paper an adaptive neural network (NN)-based nonlinear controller is proposed for trajectory tracking of uncertain nonlinear systems. The adopted control algorithm combines a continuous second-order sliding mode control (CSOSMC), the radial basis function neural network (RBFNN) and the adaptive control methodology. First, a second-order sliding mode control scheme (SOSMC), which is published recently in literature for linear uncertain systems, is extended for nonlinear uncertain systems. Second, an adaptive radial basis function neural network estimator-based continuous second order sliding mode control algorithm (CSOSMC-ANNE) is adopted. In CSOSMC-ANNE control methodology, a radial basis function neural network with adaptive parameters is exploited to approximate the unknown system parameters and improve performance against perturbations. Also, the discontinuous switching control of SOSMC is supplanted with a smooth continuous control action to completely eliminate the chattering phenomenon. The convergence and global stability of the closed-loop system are proved using Lyapunov stability method. Numerical computer simulations, with dynamical model of the nonlinear inverted pendulum system, are presented to demonstrate the effectiveness and advantages of the presented control scheme.
Related Concept Videos
 01:21
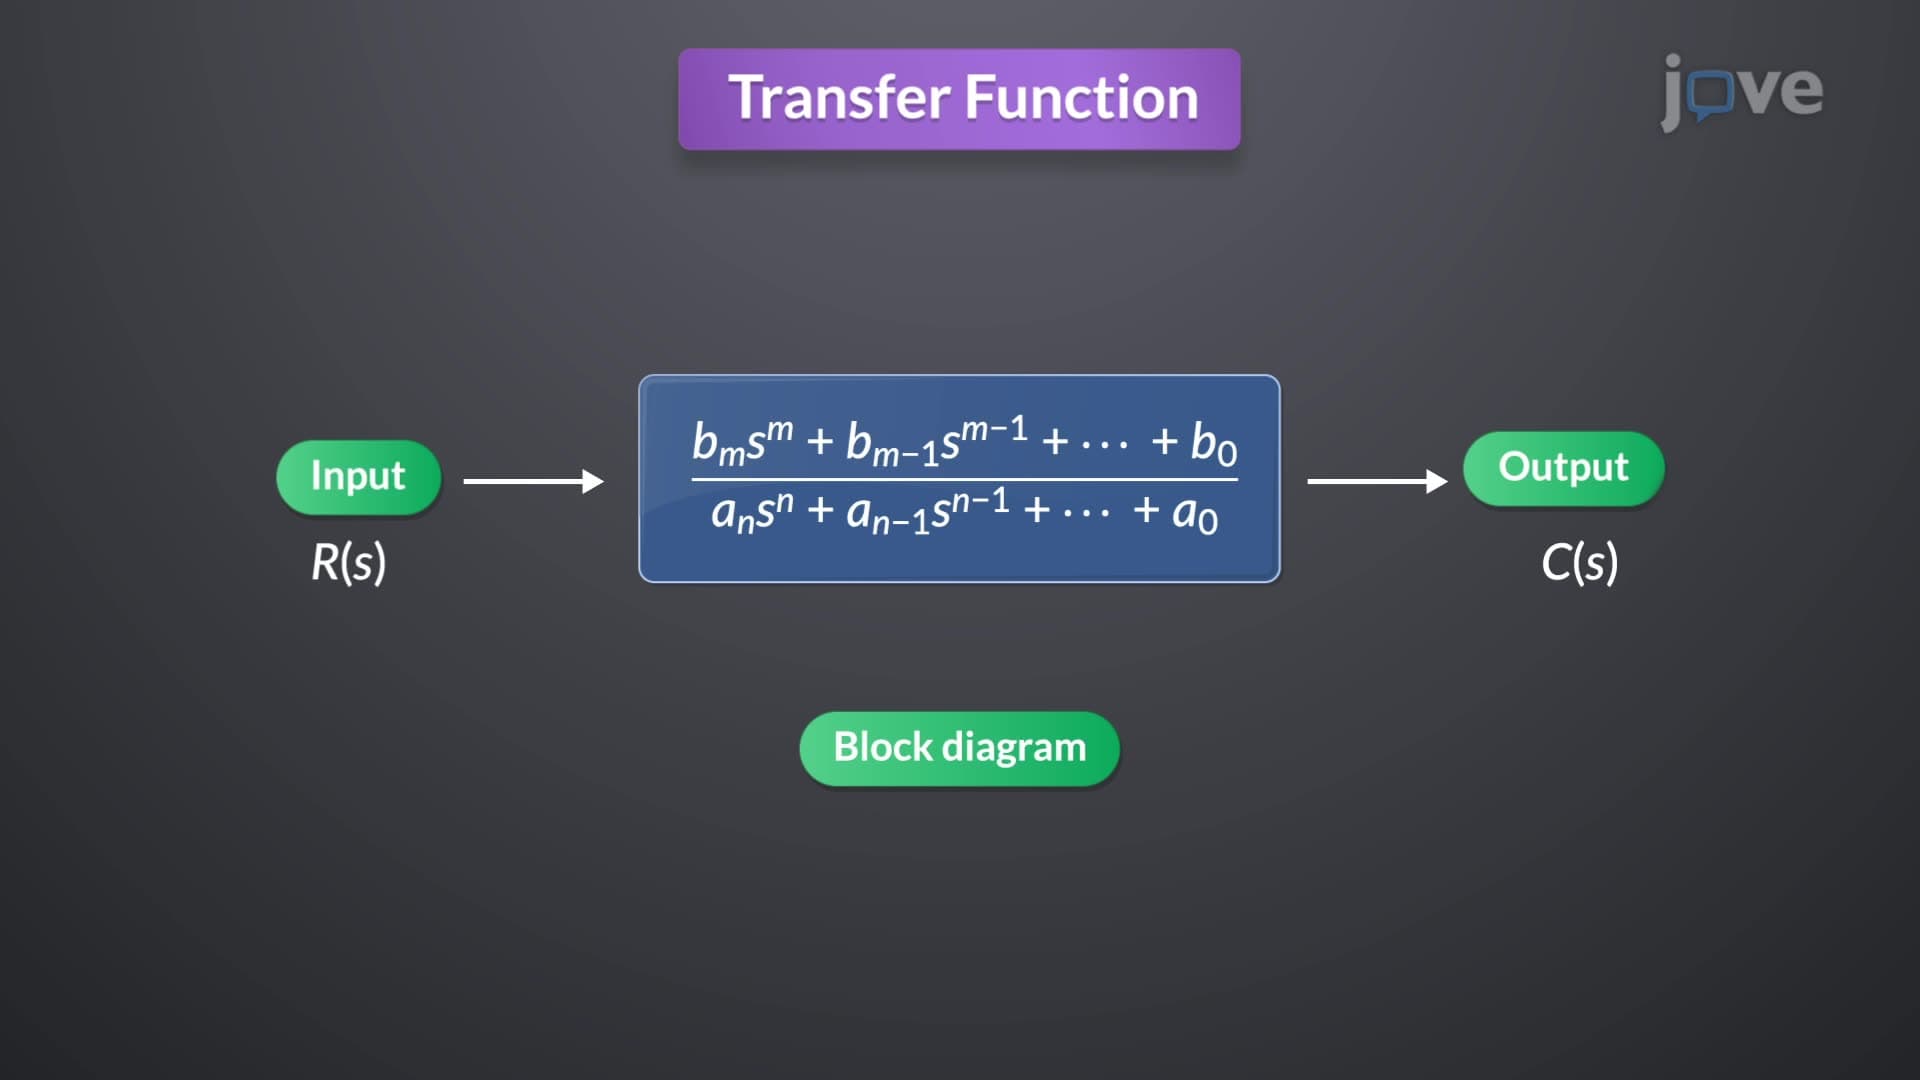
Transfer Function in Control Systems
To derive the transfer function, consider a general nth-order linear time-invariant...
 01:10
Control Systems
At the heart...
 01:23
Continuity of a Function
 01:25
Control Systems: Applications
In modern vehicles, control systems manage various functions to enhance performance and safety. The steering wheel and accelerator are primary inputs in a car's control system. The...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:29
Properties of Continuous Functions