Finite time parameter estimation-based adaptive predefined performance control for servo mechanisms

Shubo Wang1, Jing Na2, Haisheng Yu1
1School of Automation, Qingdao University, Qingdao, 266071, China.

Abstract:
This paper proposes an adaptive funnel control scheme for two-inertia servo systems with unknown parameters (e.g., inertia and stiffness coefficient). To improve the transient and steady-state performance, a modified funnel variable, which relaxes the limitation of the original funnel control, is developed by using the tracking error to replace the scaling factor. Then, an error transformation with the new funnel variable is introduced and used in the controller design. An auxiliary filter operation is designed to derive the information of parameter estimation error, which is used as a new leakage term in the parameter update law. Then a sliding mode technique is introduced in the adaption law to achieve finite-time convergence. Appropriate comparison to the gradient descent method is provided concerning with the estimation convergence. Simulation and experimental results are used to illustrate the effectiveness of the devised control scheme.
Related Concept Videos
 01:26
Distributions to Estimate Population Parameter
 02:53
Adaptive Mechanisms in Cancer Cells
Some of the advantages that cancer cells have on normal cells include - enhanced ability to divide without terminally differentiating, induce new blood vessel formation,...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:27
Time and frequency -Domain Interpretation of PI Control
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires...
 01:06
What are Estimates?
The estimate for the mean of a sample is denoted by ͞x, whereas the mean of the population is designated as μ. Further, parameters such...
 01:16
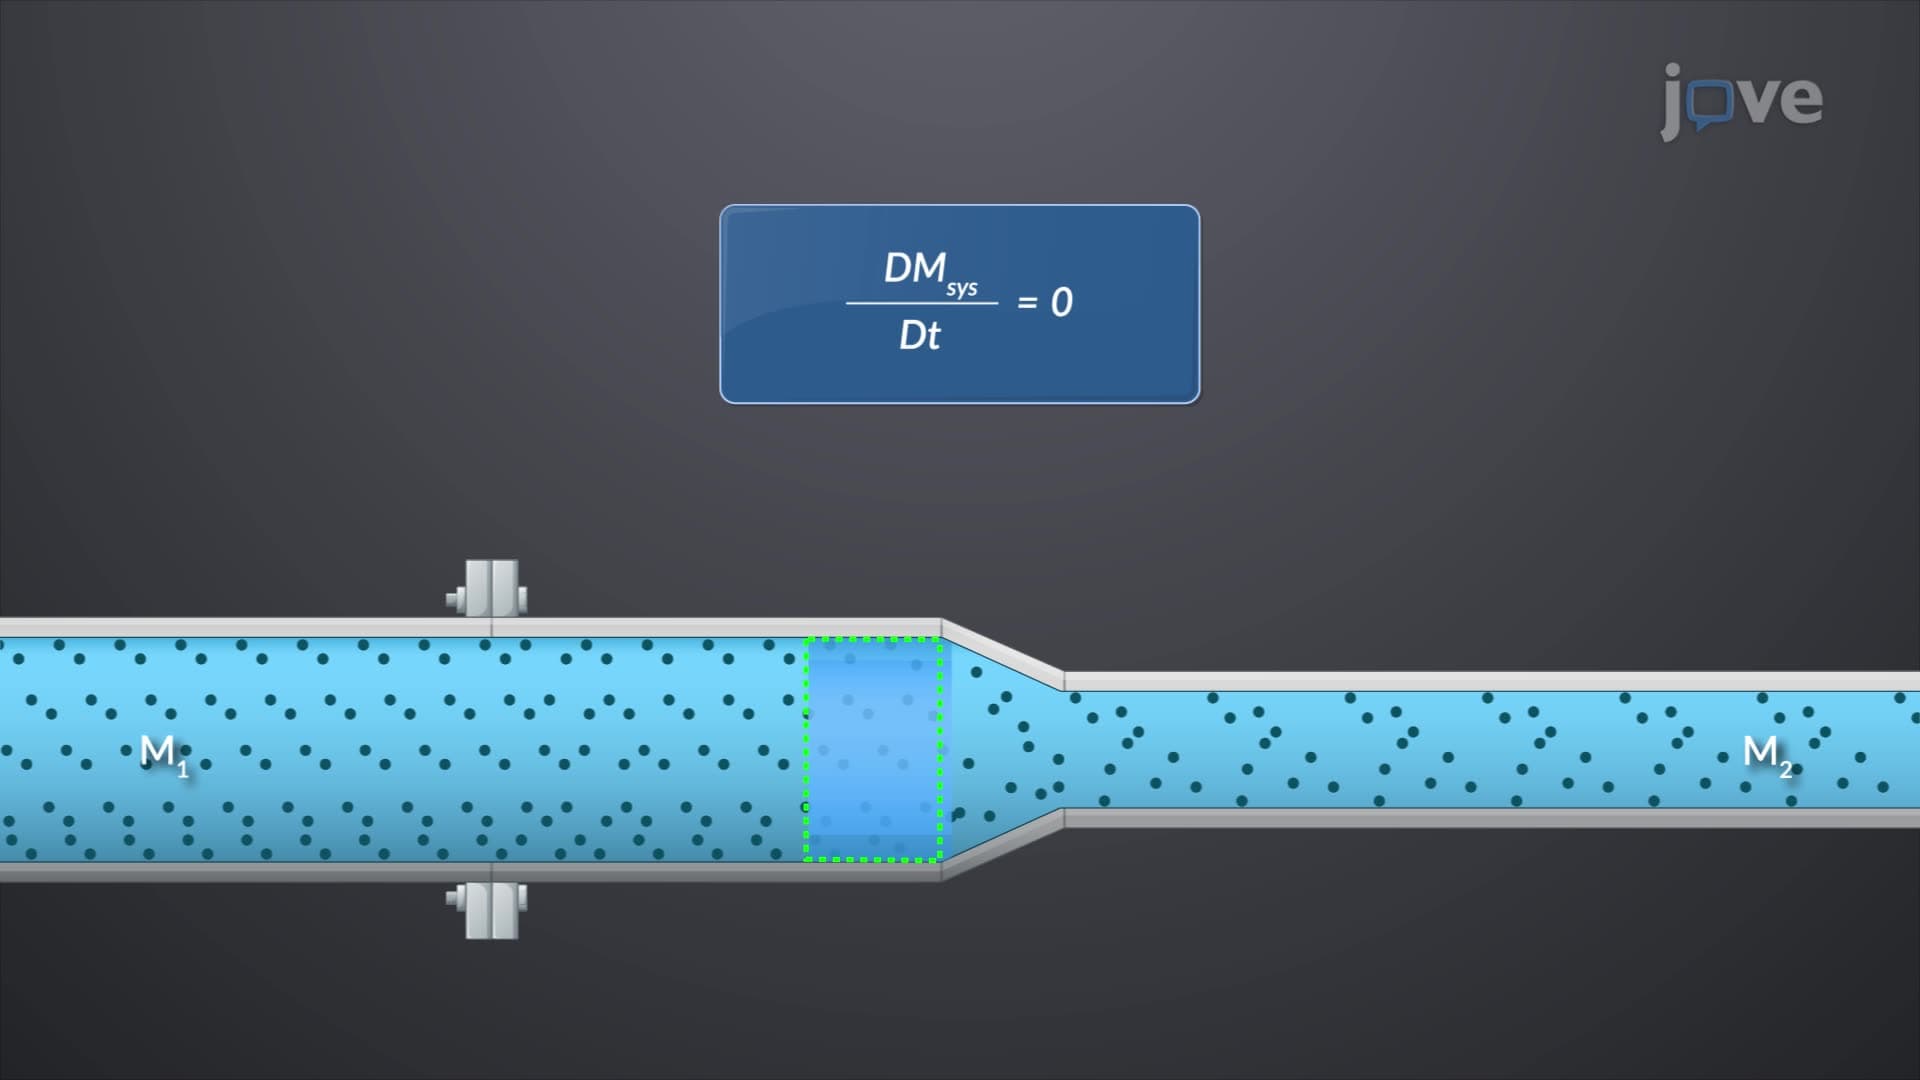
Conservation of Mass in Finite Cotrol Volume
A system is defined as a collection of unchanging contents, and the conservation of mass states that a system's mass is constant.