Related Experiment Video
Updated: Jan 31, 2026
Dynamic Lung Tumor Tracking for Stereotactic Ablative Body Radiation Therapy
Published on: June 7, 2015
Velocity-Free Leader-Follower Cooperative Attitude Tracking of Multiple Rigid Bodies on SO(3)

Abstract:
A distributed control algorithm is proposed in this paper to achieve the leader-follower cooperative attitude tracking of multiple rigid bodies without using absolute and relative angular velocity information. The nonlinear manifold SO(3) is applied to represent the attitude of each rigid body. By considering the case of limited information exchange, i.e., not all the rigid bodies have access to the leader's information, a novel continuous nonlinear distributed estimator satisfying the rotation matrix dynamics is first introduced for each rigid body to estimate the leader's information asymptotically. Then, two auxiliary systems driven by proper inputs are designed such that the issues due to the angular velocity unavailability are effectively solved. Next, a feasible distributed protocol is designed by implementing the outputs from the distributed estimator and the auxiliary systems. It is demonstrated in terms of Lyapunov theory that, the developed distributed control algorithm ensures the asymptotically stable cooperative attitude tracking of multiple rigid bodies under the weak tree connectivity assumption. Finally, illustrative examples are provided to validate and highlight the proposed results.
Related Concept Videos
 01:54
Attitudes
 00:49
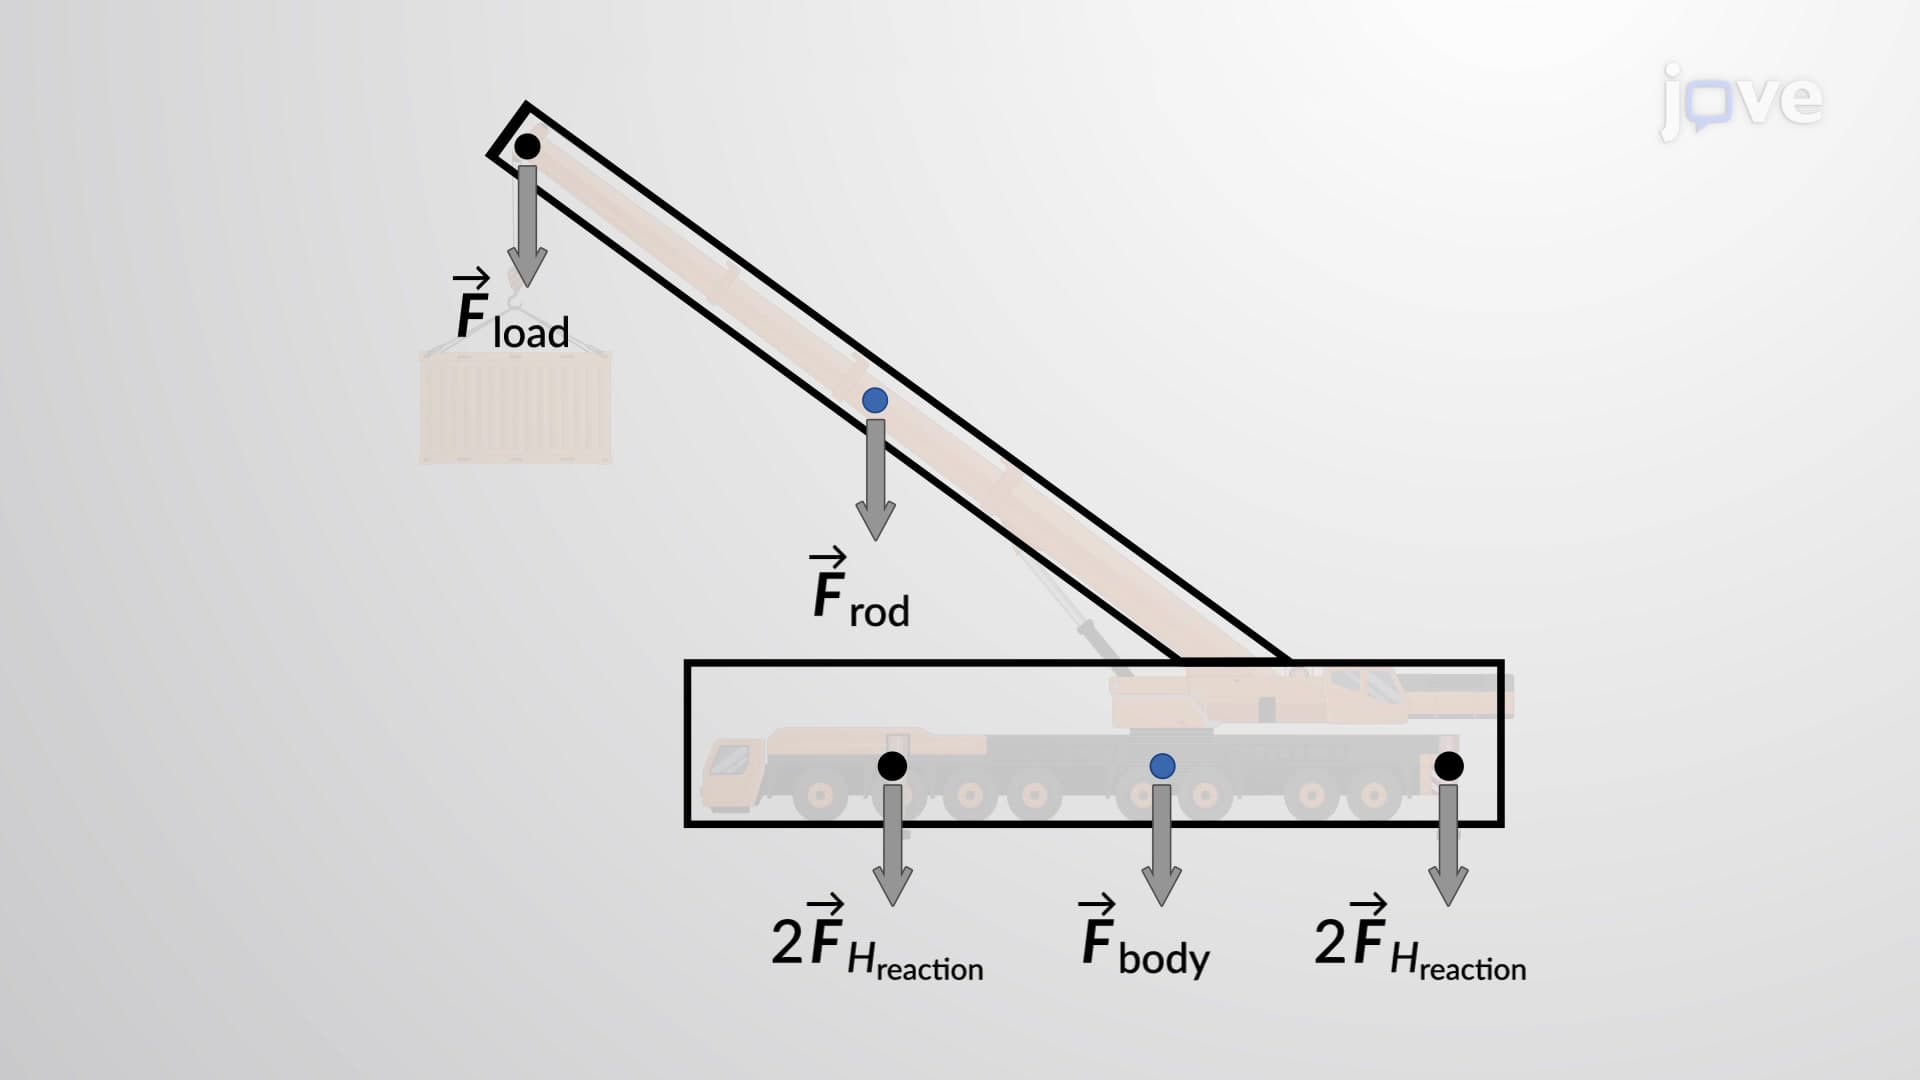
Rigid Body Equilibrium Problems - I
 01:21
Rigid Body Equilibrium Problems - II
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
 01:11
Angular Momentum: Rigid Body
This calculation can get complicated when tiny particles within the rigid body are not rotating in the same plane but have...
 01:06
Virtual Work for a System of Connected Rigid Bodies
Next,...
 01:13
Kinetic Energy for a Rigid Body