Linear estimation for discrete-time periodic systems with unknown measurement input and missing measurements
Related Experiment Video
Updated: Jan 31, 2026
Power Input Measurements in Stirred Bioreactors at Laboratory Scale
Published on: May 16, 2018
1School of Information Science and Engineering, Shandong Normal University, Jinan, Shandong, 250014, PR China; School of Computing, Engineering and Mathematics, Western Sydney University, Sydney NSW 2751, Australia.

Abstract:
This paper considers the estimation problem for periodic systems with unknown measurement input and missing measurements. The missing measurements phenomenon is described by an independent and identically distributed Bernoulli process. The quality of the estimation achieved by an admissible filter is measured by a performance criterion described by the Cesaro limit of the mean square of the deviation between the remote signal and the estimated signal. By employing the minimum variance unbiased estimation technique, the periodic unbiased estimator is obtained, where the estimator gain is designed in terms of the unique periodic solution of a Lyapunov equation together with the periodic stabilizing solution of a Riccati equation. Finally, a numerical example is provided to show the effectiveness of the proposed estimation approach.
Related Concept Videos
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
 01:22
Estimating Population Mean with Unknown Standard Deviation
William S. Gosset (1876–1937) of the...
 01:26
Discrete-time Fourier transform
One of the notable...
 01:16
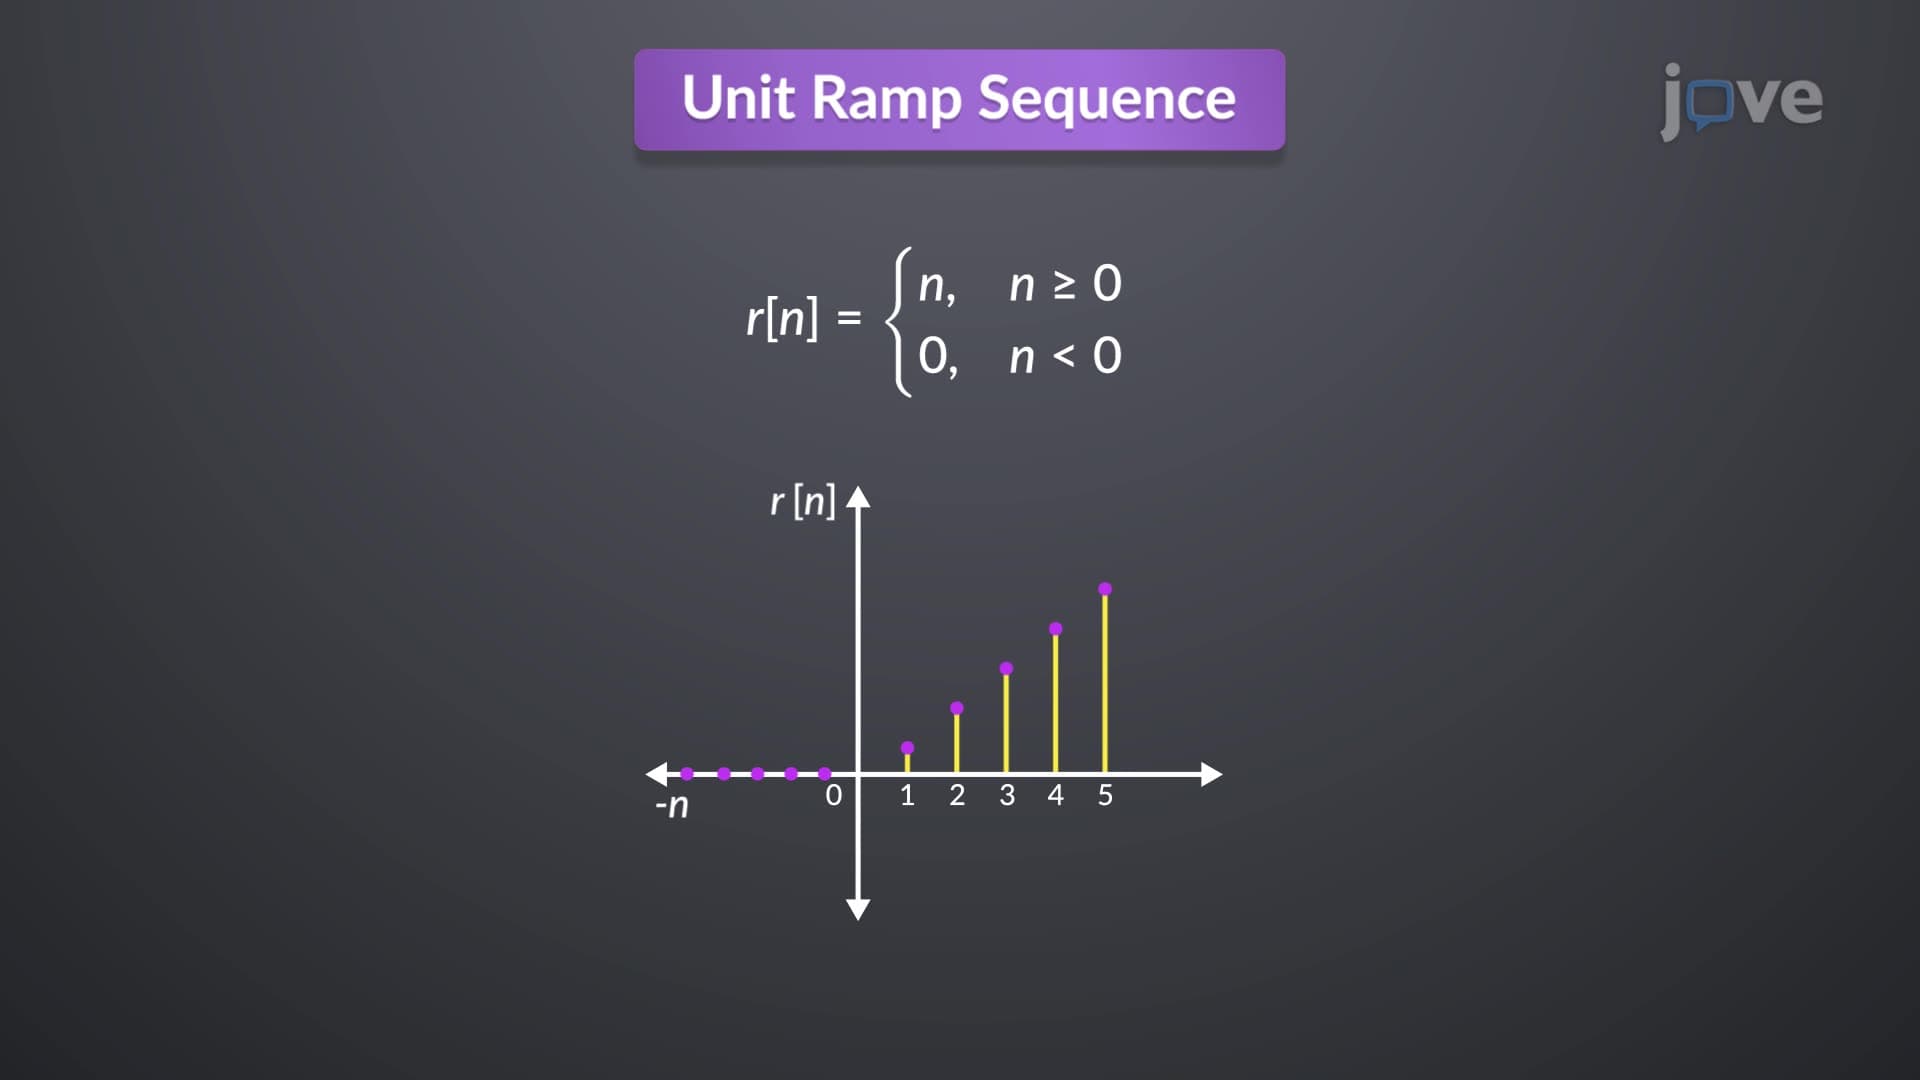
Basic Discrete Time Signals
The unit impulse or sample sequence is mathematically expressed as zero for all n values except at n=0, where it is one. The unit impulse sequence, denoted by δ(n), is the first difference of the unit step sequence, while the unit step sequence u(n) is the...
 01:20
Discrete-Time Fourier Series
For a discrete-time periodic signal x[n]...