Distributed optimal coordination control for nonlinear multi-agent systems using event-triggered adaptive dynamic programming method
Related Experiment Video
Updated: Jan 29, 2026
Multi-timescale Microscopy Methods for the Characterization of Fluorescently-labeled Microbubbles for Ultrasound-Triggered Drug Release
Published on: June 12, 2021
1School of Mathematics, Southeast University, Nanjing, 210096, PR China.

Abstract:
This paper is concerned with the design of distributed optimal coordination control for nonlinear multi-agent systems (NMASs) based on event-triggered adaptive dynamic programming (ETADP) method. The method is firstly introduced to design the distributed coordination controllers for NMASs, which not only avoids the transmission of redundant data compared with traditional time-triggered adaptive dynamic programming (TTADP) strategy and minimizes the performance function of each agent. The event-triggered conditions are proposed based on Lyapunov functional method, which is deduced by guaranteeing the stability of NMASs. Then a new adaptive policy iteration algorithm is presented to obtain the online solutions of the Hamiton-Jocabi-Bellman (HJB) equations. In order to implement the proposed ETADP method, the fuzzy hyperbolic model based critic neural networks (NN) are utilized to approximate the value functions and help calculate the control policies. In critic NNs, the NN weight estimations are updated at the event-triggered instants leading to aperiodic weight tuning laws so that computation cost is reduced. It is proved that the weight estimation errors and the local neighborhood coordination errors is uniformly ultimately bounded (UUB). Finally, two simulation examples are provided to show the effectiveness of the proposed ETADP method.
More Related Videos
Related Concept Videos
 01:10
Control Systems
At the heart...
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:16
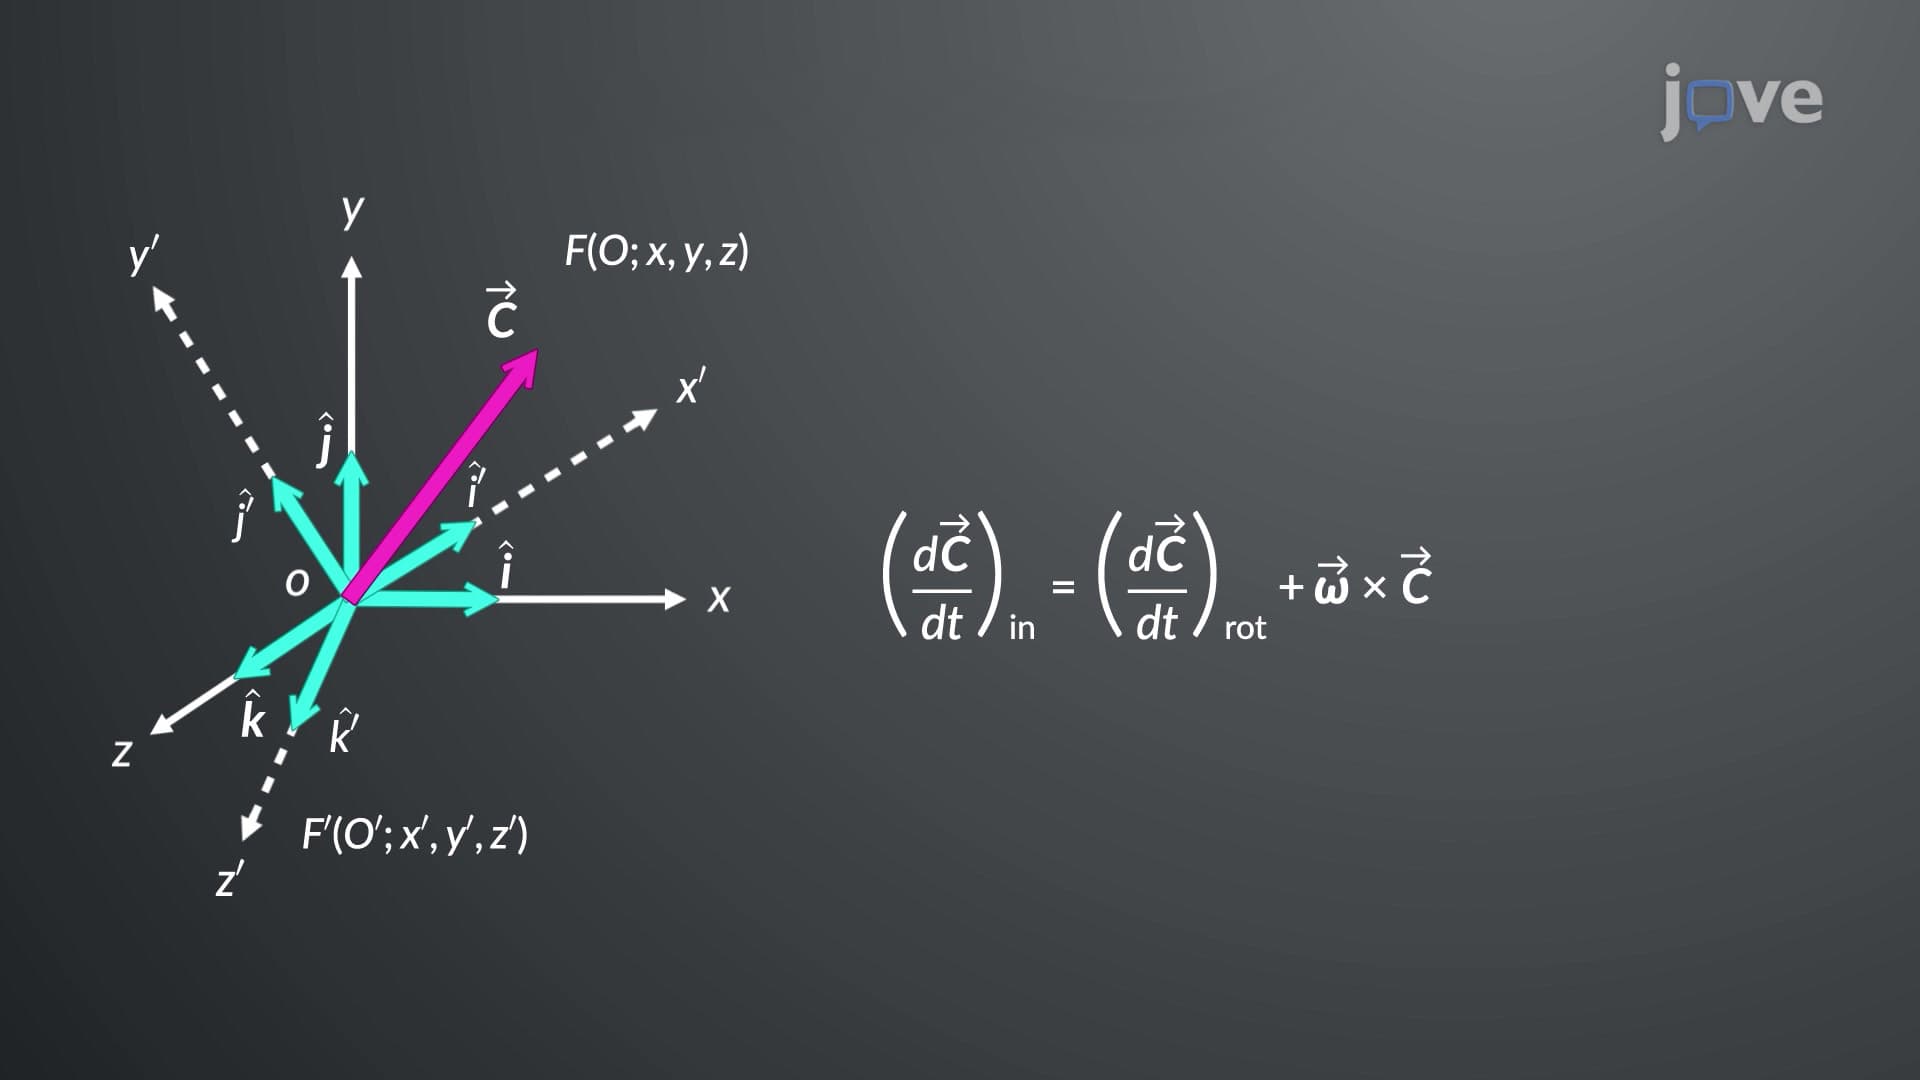
Vector Transformation in Rotating Coordinate Systems
 01:25
Control Systems: Applications
In modern vehicles, control systems manage various functions to enhance performance and safety. The steering wheel and accelerator are primary inputs in a car's control system. The...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:27
Chemical Agents for Microbial Control