Adaptive sliding mode disturbance rejection control with prescribed performance for robotic manipulators
Related Experiment Video
Updated: Jan 29, 2026
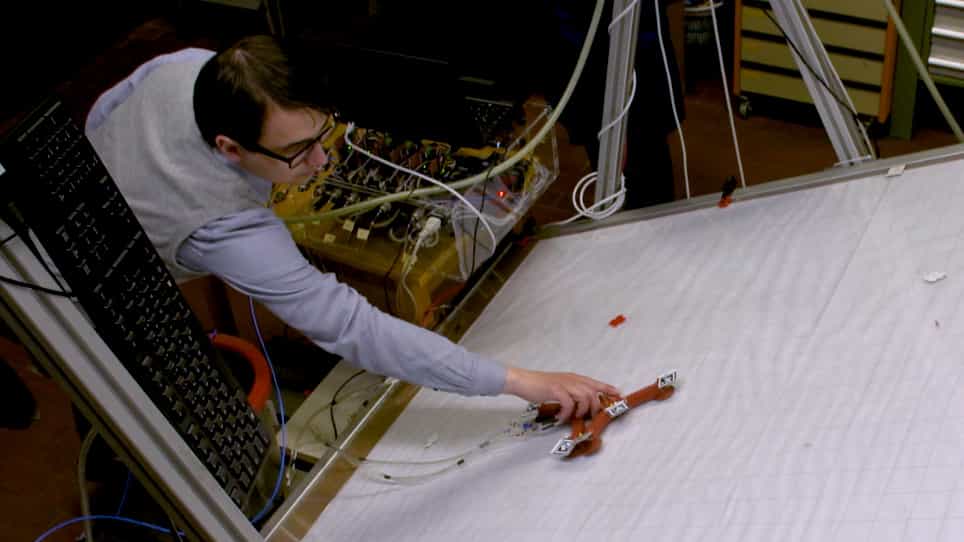
Manufacturing, Control, and Performance Evaluation of a Gecko-Inspired Soft Robot
Published on: June 10, 2020
Chenghu Jing1, Hongguang Xu1, Xinjian Niu1
1Department of Fluid Control and Automation, Harbin Institute of Technology, Harbin, China.

Abstract:
This study proposes an adaptive sliding mode disturbance rejection control with prescribed performance for robotic manipulators. A transformation with respect to tracking error using certain performance functions is used to ensure the transient and steady-state performances of the trajectory tracking control for robotic manipulators. Using the transformed error, a nonsingular terminal sliding mode surface is proposed. A continuous terminal sliding mode control (SMC) is presented to stabilize the system. To compensate for the uncertainty and external disturbance, a novel sliding mode disturbance observer is proposed. Considering the unknown boundary of the derivative of a lumped disturbance, an adaptive law based on the idea of equivalent control is designed. Combining the adaptive law, continuous nonsingular terminal SMC, and sliding mode disturbance observer, the adaptive sliding mode disturbance rejection control with prescribed performance is developed. Simulations are carried out to demonstrate the effectiveness of the proposed approach.
Related Concept Videos
 02:26
Ecological Disturbance
 01:29
Disturbances in Heart Rhythm
Arrhythmias are categorized by their speed, rhythm, and origin. A slow heart...
 01:07
What is a Mode?
There can be more than one mode in a data set if multiple values have the same highest frequency. For instance, suppose that the Statistics exam scores of 20 students are: 50; 53; 59; 59; 63; 63; 72; 72; 72; 72; 72; 76; 78; 81; 83; 84; 84; 84; 90; 93. Here, the mode is 72, as it occurs most frequently, five times.
A data set with two modes is called bimodal. For example,...
 01:14
Ventilatory Modes
There are three ventilatory modes: full support, partial support, and spontaneous. These are described below.
Full Support Modes
Full support modes include controlled mechanical ventilation, continuous mandatory...
 01:18
Design Example: Designing Water Slide
Bernoulli's principle determines the water's velocity along the slide....
 01:17
Hypothesis: Accept or Fail to Reject?
There are two ways to indicate that the null hypothesis is not rejected. 'Accept' the null...