Related Experiment Video
Updated: Jan 26, 2026
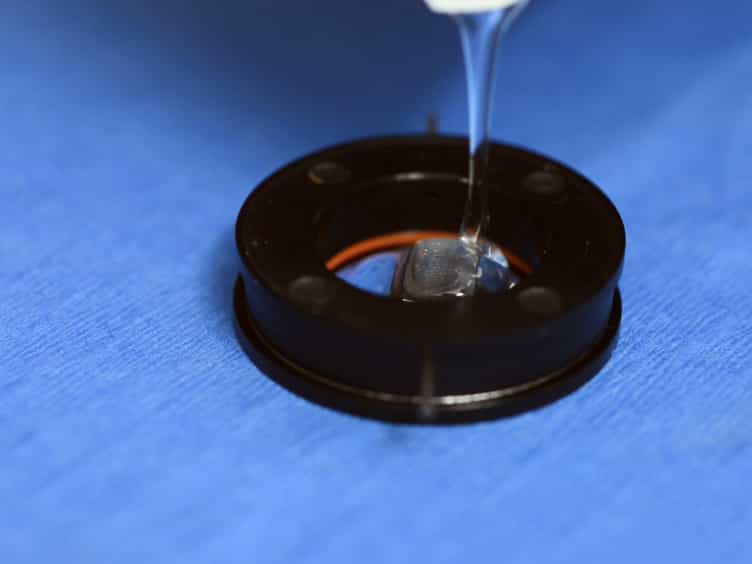
Planar Gradient Diffusion System to Investigate Chemotaxis in a 3D Collagen Matrix
Published on: June 12, 2015
State Transition for Statistical SLAM Using Planar Features in 3D Point Clouds
Amirali Khodadadian Gostar1, Chunyun Fu2, Weiqin Chuah3
1School of Engineering, RMIT University, Melbourne VIC 3001, Australia. amirali.khodadadian@rmit.edu.au.

Abstract:
There is a large body of literature on solving the SLAM problem for various autonomous vehicle applications. A substantial part of the solutions is formulated based on using statistical (mainly Bayesian) filters such as Kalman filter and its extended version. In such solutions, the measurements are commonly some point features or detections collected by the sensor(s) on board the autonomous vehicle. With the increasing utilization of scanners with common autonomous cars, and availability of 3D point clouds in real-time and at fast rates, it is now possible to use more sophisticated features extracted from the point clouds for filtering. This paper presents the idea of using planar features with multi-object Bayesian filters for SLAM. With Bayesian filters, the first step is prediction, where the object states are propagated to the next time based on a stochastic transition model. We first present how such a transition model can be developed, and then propose a solution for state prediction. In the simulation studies, using a dataset of measurements acquired from real vehicle sensors, we apply the proposed model to predict the next planar features and vehicle states. The results show reasonable accuracy and efficiency for statistical filtering-based SLAM applications.
Related Concept Videos
 02:46
Crystal Field Theory - Tetrahedral and Square Planar Complexes
Crystal field theory (CFT) is applicable to molecules in geometries other than octahedral. In octahedral complexes, the lobes of the dx2−y2 and dz2 orbitals point directly at the ligands. For tetrahedral complexes, the d orbitals remain in place, but with only four ligands located between the axes. None of the orbitals points directly at the tetrahedral ligands. However, the dx2−y2 and dz2 orbitals (along the Cartesian axes) overlap with the ligands less than the dxy,...
 01:50
Statistical Significance
 02:31
Phase Transitions
 02:58
Properties of Transition Metals
 01:14
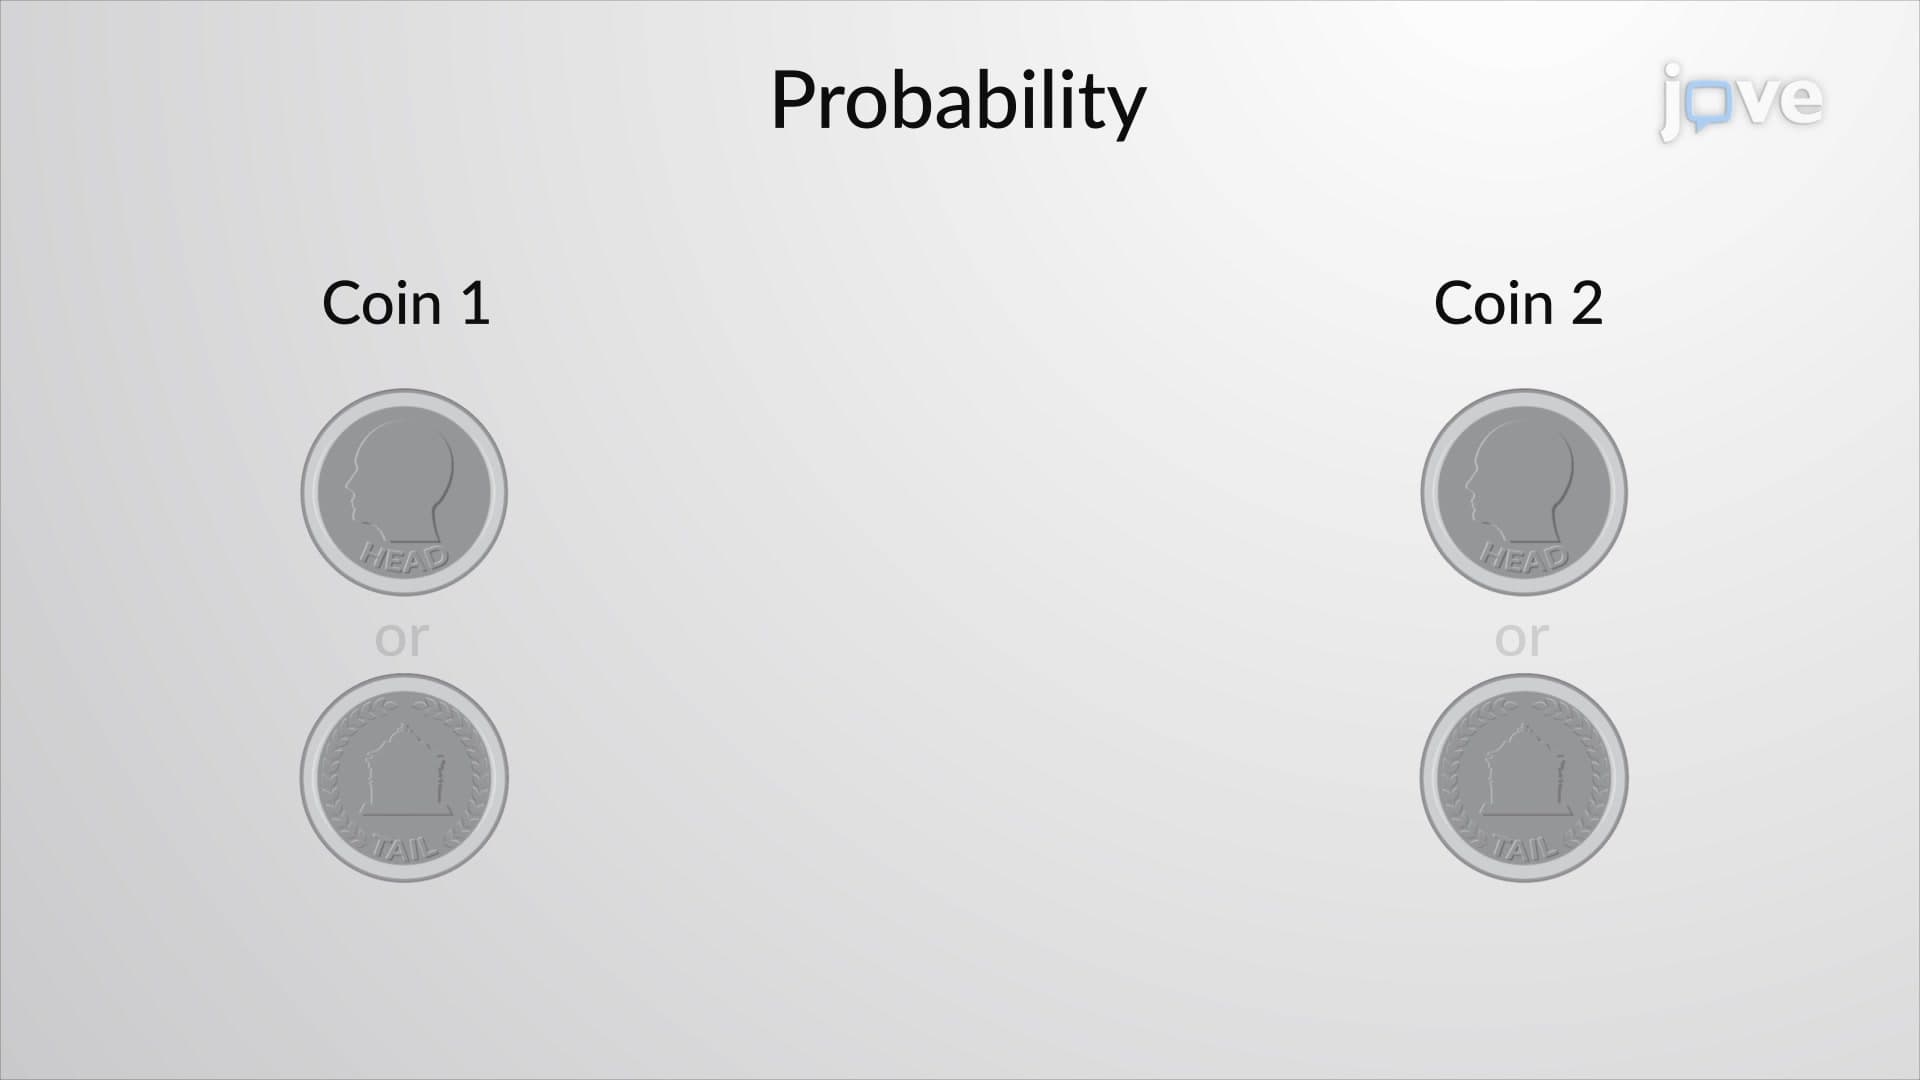
Probability in Statistics
An example of a simple event is a coin toss. The result of a coin toss is either a head or a tail. Here, head and tail are two simple events. These two simple events make up the sample space. Further, the probability of an event occurring falls within the range of 0 to 1. The probability of an...
 01:58
Cooperative Allosteric Transitions