Event-triggered active disturbance rejection control for nonlinear network control systems subject to DoS and physical attacks
Related Experiment Video
Updated: Jan 24, 2026
Author Spotlight: Enhancing Engineering Education via WebVR-Based Online Laboratories
Published on: February 23, 2024
1School of Astronautics, Northwestern Polytechnical University, Xi'an 710072, China.

Abstract:
This paper investigates the problem of event-triggered active disturbance rejection control of nonlinear network control system in simultaneous presence of unknown dynamics, physical attacks and denial-of-service attacks. Considering the network congestion, an event-triggered communication mechanism is adopted, where the measurements are transmitted only when an 'event' occurs. An indicator obeying the Markov jump rule is introduced to characterize the randomly occurring denial-of-service attacks. In virtue of the extended state observer (ESO), the states and the total disturbance which involves both unknown dynamics and physical attacks are estimated. Then, the composite controller is designed which could stabilize the overall controlled system and eliminate the so-called total disturbance. Sufficient conditions are established to guarantee the stability of the observer system and overall controlled system. The cone-complementarity linearization algorithm is adopted to obtain the parameters of the extended state observer and the controller. Finally, both numerical and application design examples demonstrate the feasibility and efficacy of the proposed method. Simulation results show that the steady-state error within 0.02 can be achieved within 3 s.
Related Concept Videos
 01:10
Control Systems
At the heart...
 01:25
Control Systems: Applications
In modern vehicles, control systems manage various functions to enhance performance and safety. The steering wheel and accelerator are primary inputs in a car's control system. The...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
 01:21
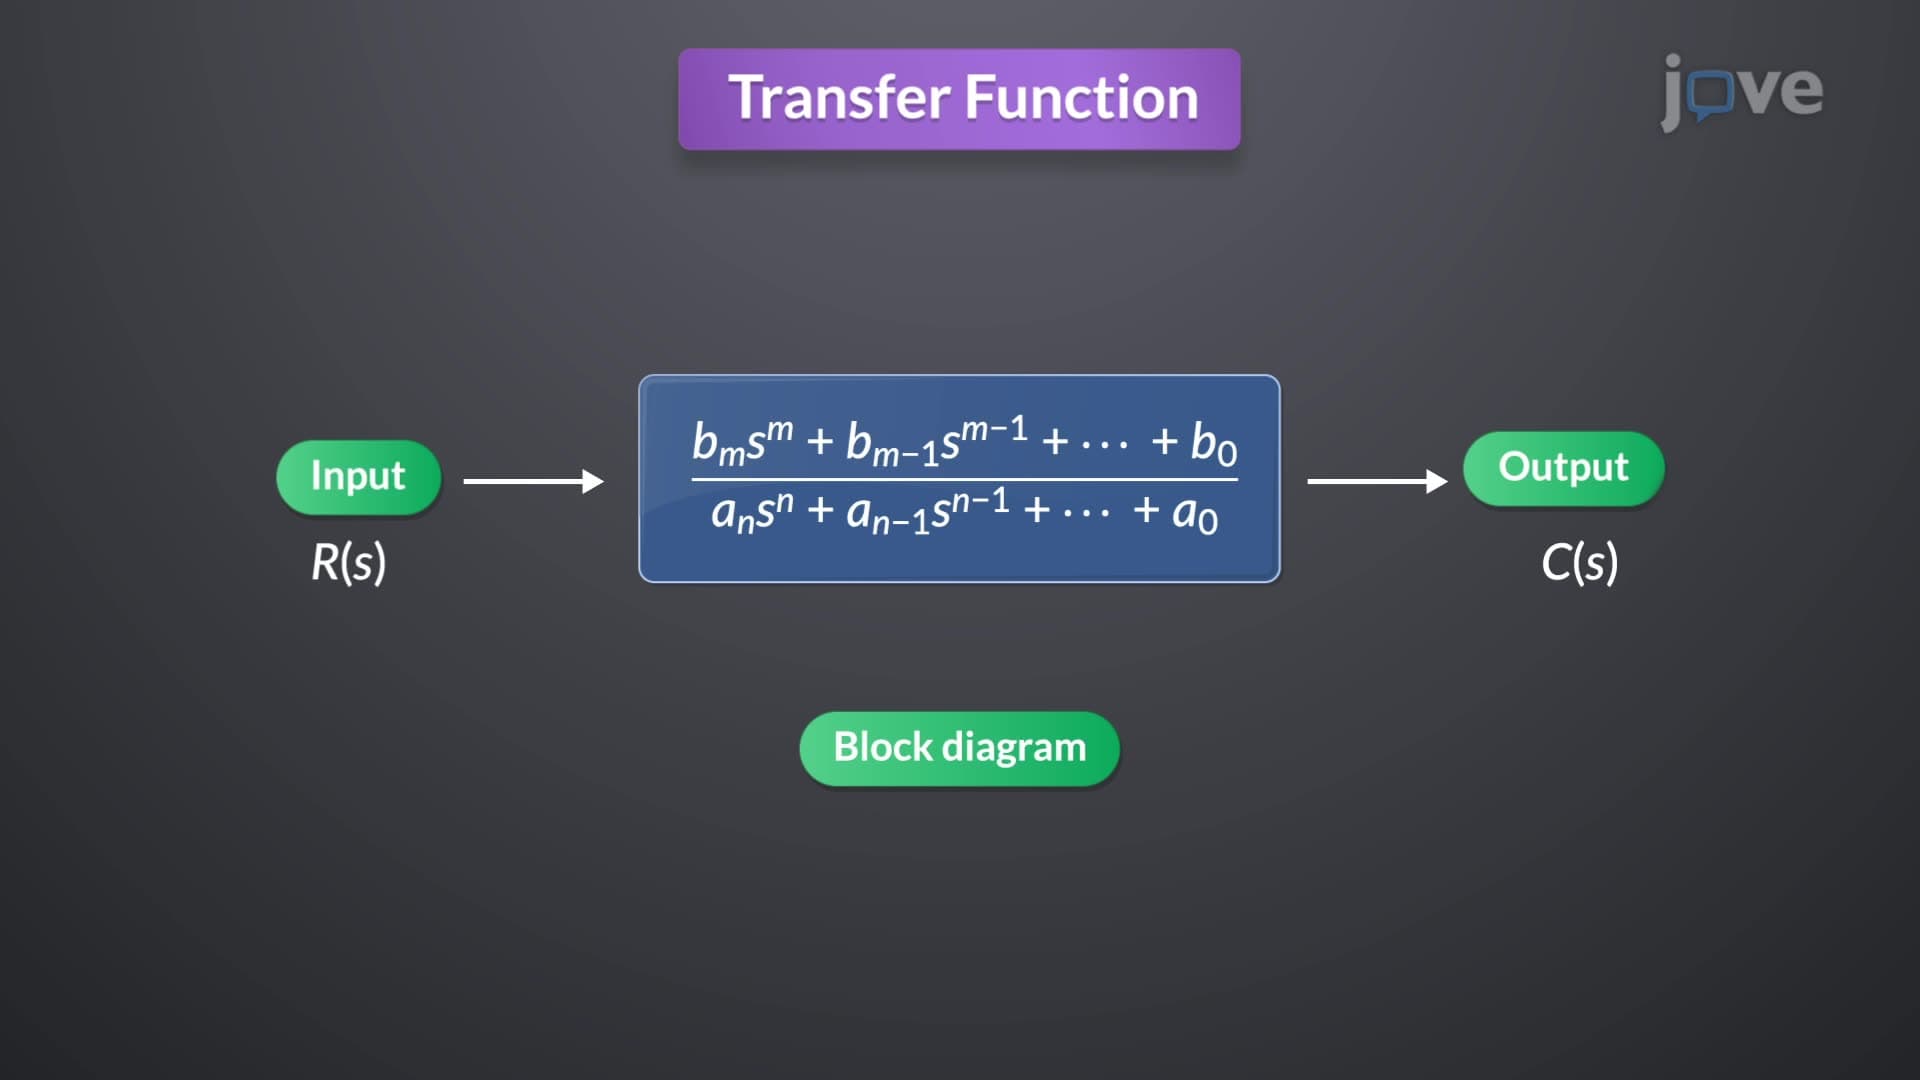
Transfer Function in Control Systems
To derive the transfer function, consider a general nth-order linear time-invariant...
 02:26
Ecological Disturbance