Related Experiment Video
Updated: Jan 23, 2026
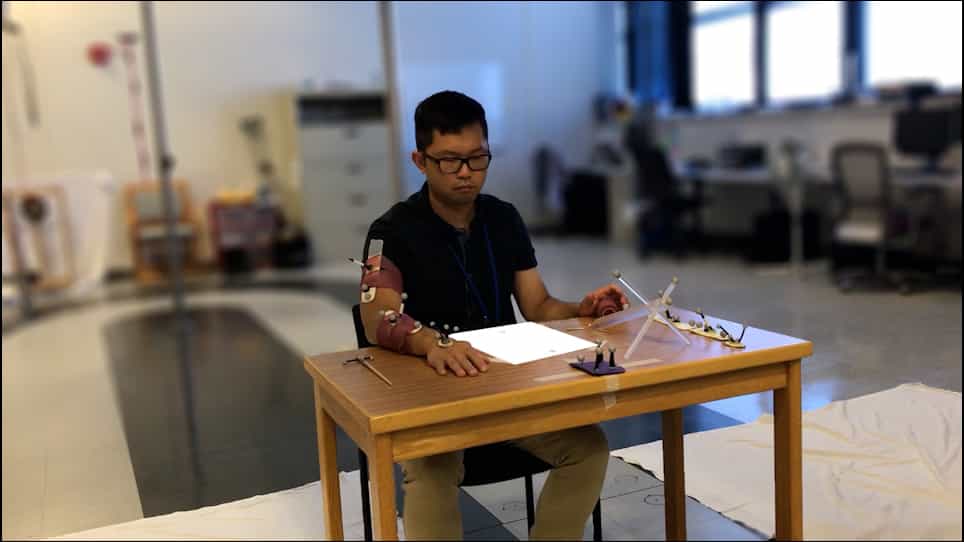
The Impact of Motor Task Conditions on Goal-Directed Arm Reaching Kinematics and Trunk Compensation in Chronic Stroke Survivors
Published on: May 2, 2021
An exoskeleton arm optimal configuration determination using inverse kinematics and genetic algorithm
Sebastian Głowiński1, Andrzej Błażejewski1
1Koszalin University of Technology, Faculty of Technology and Education, Department of Mechatronics and Applied Mechanics, Koszalin, Poland.

Purpose:
This paper deals with the kinematic modelling of an arm exoskeleton used for human rehabilitation. The biomechanics of the arm was studied and the 9 Degrees of Freedom model was obtained. The particular (optimal) exoskeleton arm configuration is needed, depending on patient abilities and possibility or other users activity.
Methods:
The model of upper arm was obtained by using Denavit-Hartenberg notation. The exoskeleton human arm was modelled in MathWorks package. The multicriteria optimization procedure was formulated to plan the motion of trajectory. In order to find the problem solution, an artificial intelligence method was used.
Results:
The optimal solutions were found applying a genetic algorithm. Two variants of motion with and the visualization of the change of joints angles were shown. By the use of genetic algorithms, movement trajectory with the Pareto-optimum solutions has been presented as well. Creating a utopia point, it was possible to select only one solution from Pareto-optimum results.
Conclusions:
The obtained results demonstrate the efficiency of the proposed approach that can be utilized to analyse the kinematics and dynamics of exoskeletons using the dedicated design process. Genetic algorithm solution could be implemented to command actuators, especially in the case of multi-criteria problems. Moreover, the effectiveness of this method should be evaluated in the future by real experiments.
Related Concept Videos
 02:46
Electron Configurations
The relative energies of the subshells determine the order in which atomic orbitals are filled (1s, 2s, 2p, 3s, 3p,...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 03:26
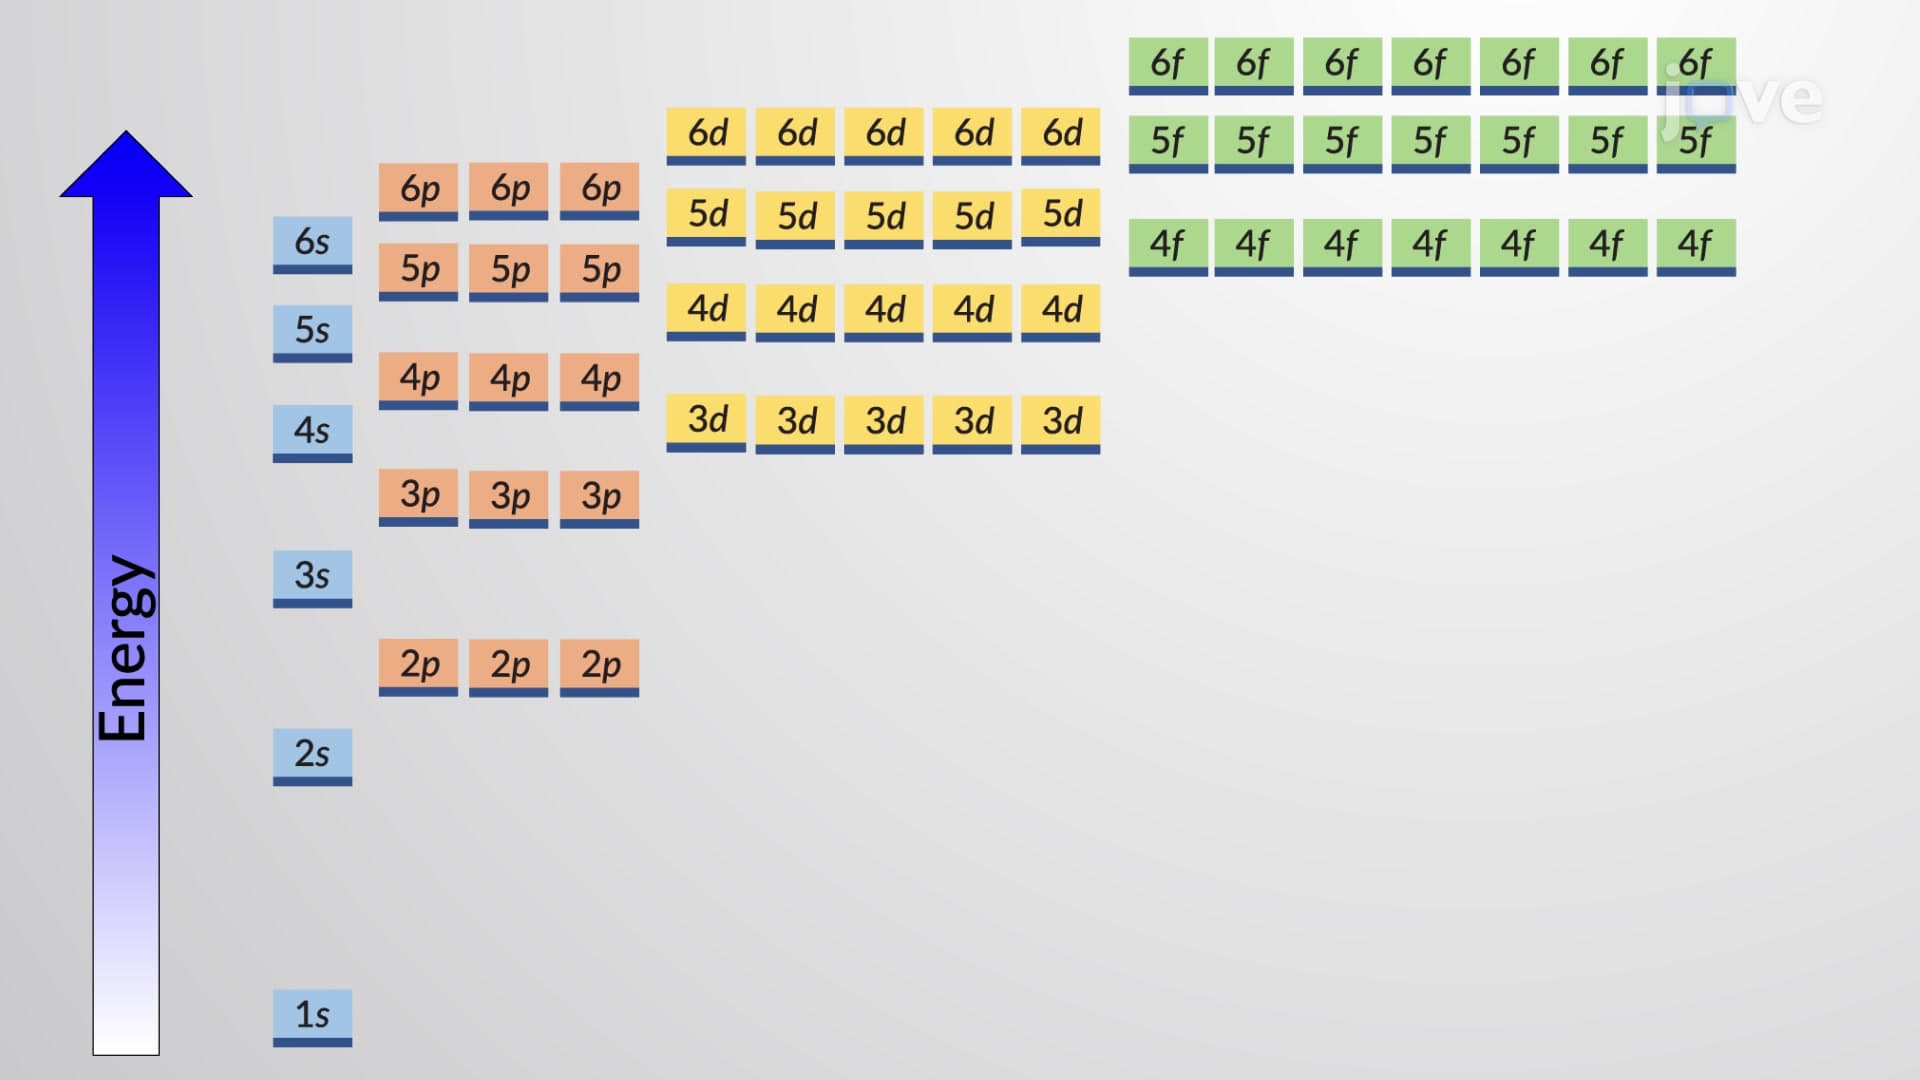
Electron Configuration of Multielectron Atoms
 01:23
Stability of Equilibrium Configuration
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
 01:16
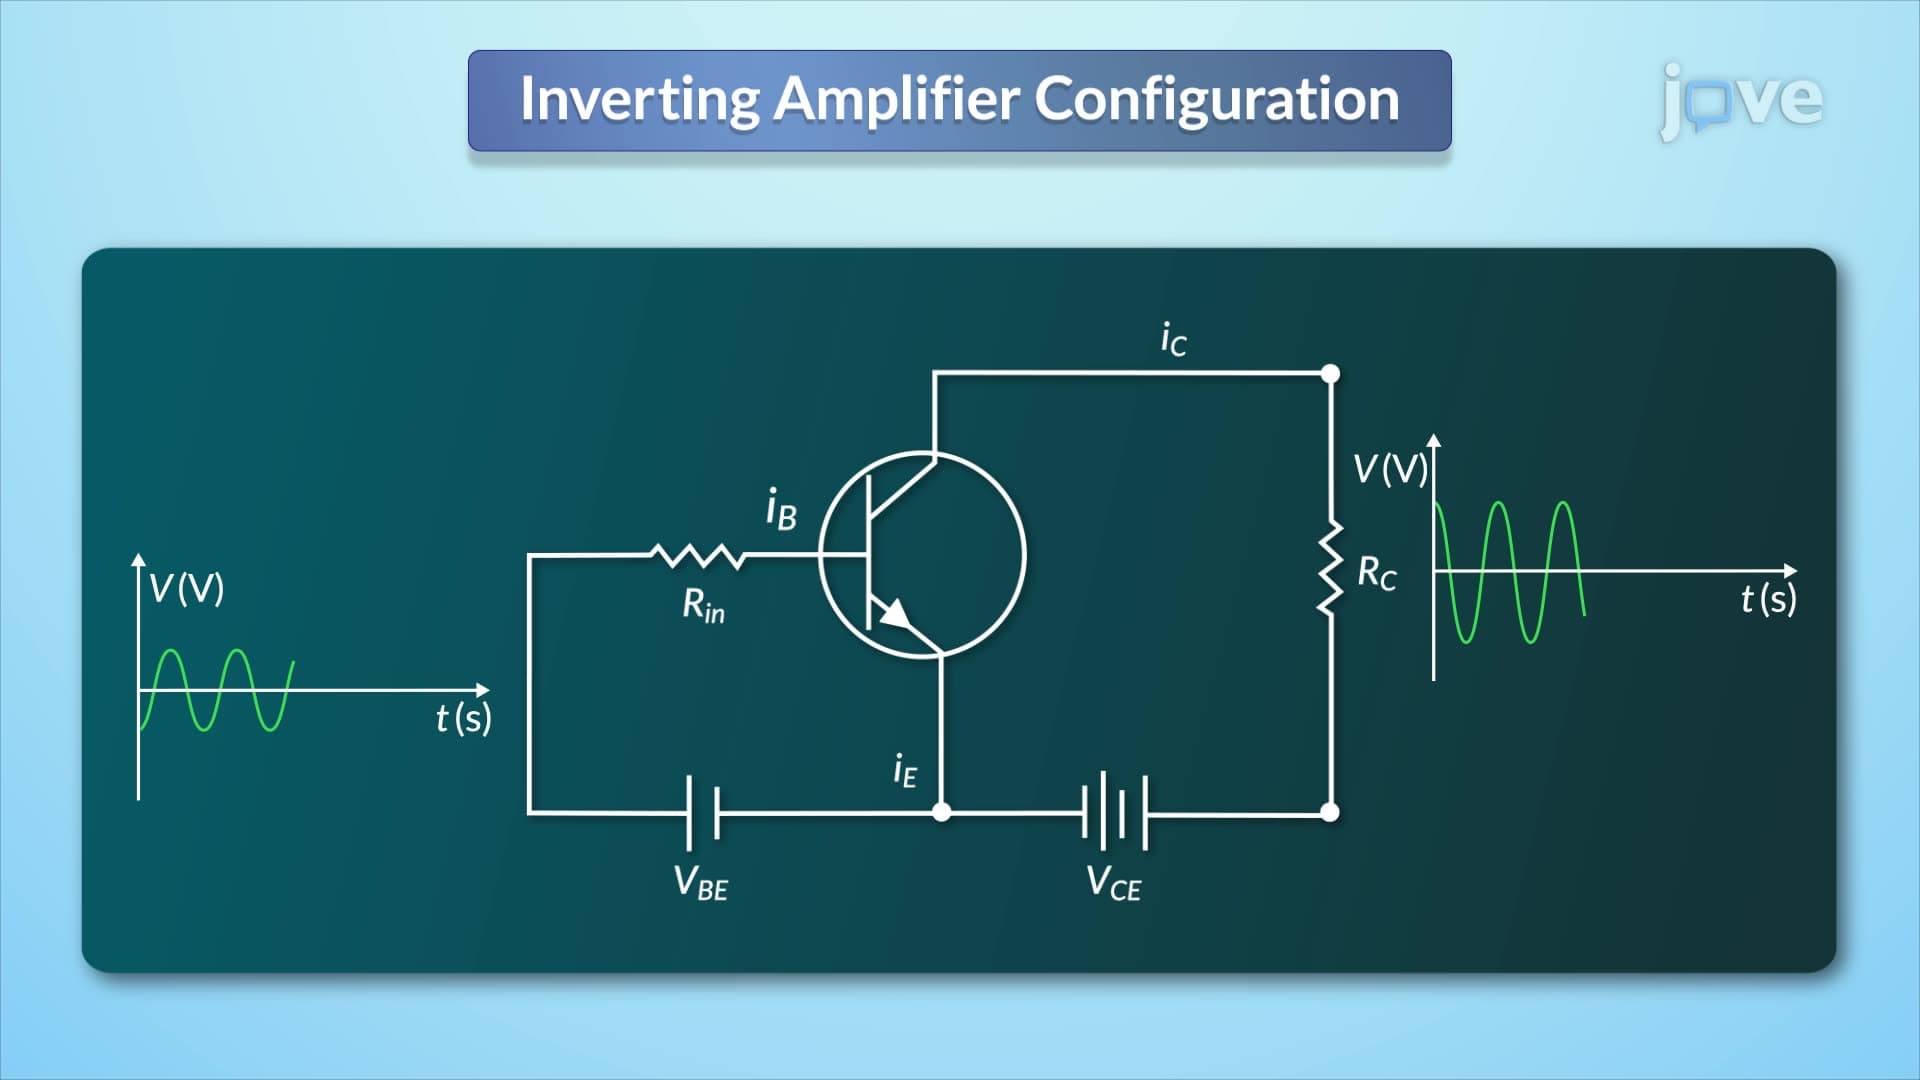
Configurations of BJT
The common base configuration is noted for its high voltage gain, positioning it as an ideal choice for single-stage amplifier circuits, such as microphone pre-amplifiers. A notable...
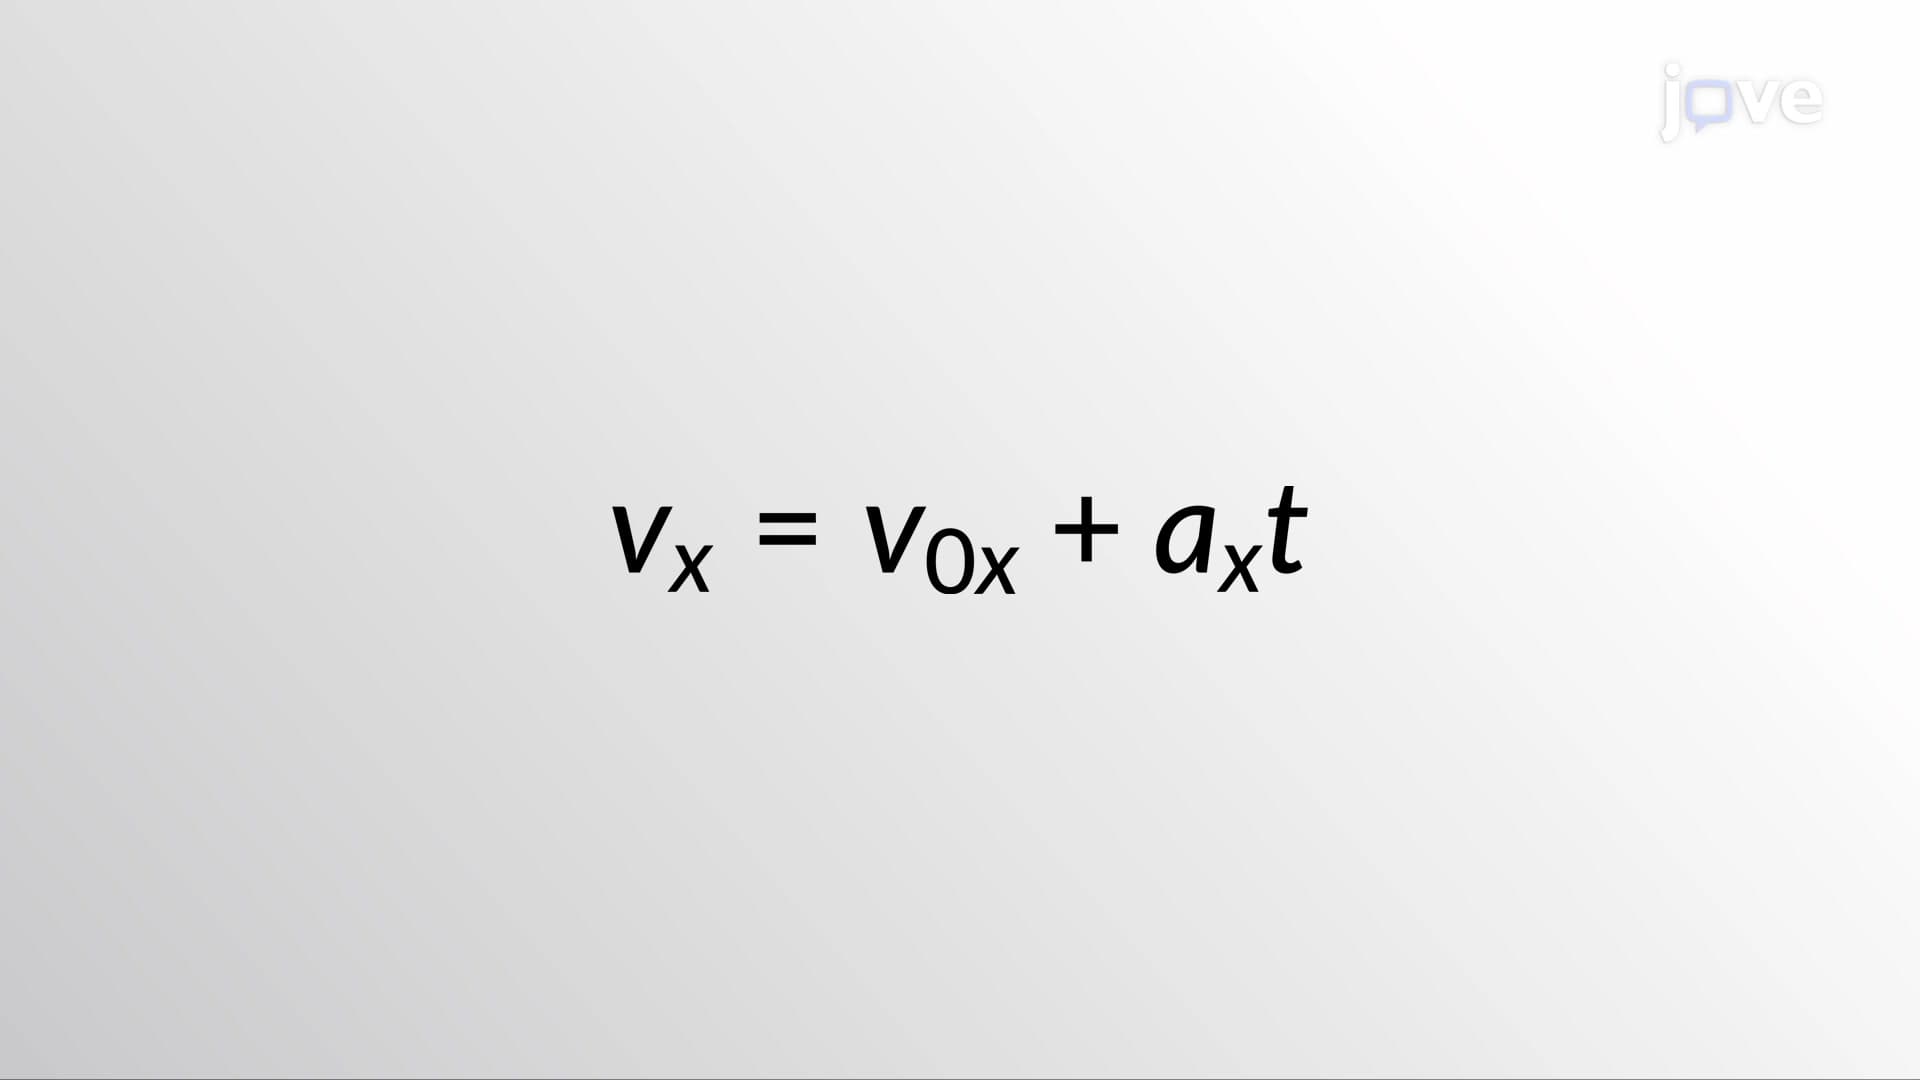 01:26
Kinematic Equations - I