Related Experiment Video
Updated: Jan 20, 2026

In Vivo Imaging of Muscle-tendon Morphogenesis in Drosophila Pupae
Published on: February 6, 2018
Series Elastic Behavior of Biarticular Muscle-Tendon Structure in a Robotic Leg
Felix Ruppert1, Alexander Badri-Spröwitz1
1Dynamic Locomotion Group, Max Planck Institute for Intelligent Systems, Stuttgart, Germany.

Abstract:
We investigate the role of lower leg muscle-tendon structures in providing serial elastic behavior to the hip actuator. We present a leg design with physical elastic elements in leg angle and virtual leg axis direction, and its impact onto energy efficient legged locomotion. By testing and comparing two robotic lower leg spring configurations, we can provide potential explanations of the functionality of similar animal leg morphologies with lower leg muscle-tendon network structures. We investigate the effects of leg angle compliance during locomotion. In a proof of concept, we show that a leg with a gastrocnemius inspired elasticity possesses elastic components that deflect in leg angle directions. The leg design with elastic elements in leg angle direction can store hip actuator energy in the series elastic element. We then show the leg's advantages in mechanical design in a vertical drop experiment. In the drop experiments the biarticular leg requires 46% less power. During drop loading, the leg adapts its posture and stores the energy in its springs. The increased energy storing capacity in leg angle direction reduces energy requirements and cost of transport by 31% during dynamic hopping to a cost of transport of 1.2 at 0.9 kg body weight. The biarticular robot leg design has major advantages, especially compared to more traditional robot designs. Despite its high degree of under-actuation, it is easy to converge into and maintain dynamic hopping locomotion. The presented control is based on a simple-to-implement, feed-forward pattern generator. The biarticular legs lightweight design can be rapidly assembled and is largely made from elements created by rapid prototyping. At the same time it is robust, and passively withstands drops from 200% body height. The biarticular leg shows, to the best of the authors' knowledge, the lowest achieved relative cost of transport documented for all dynamically hopping and running robots of 64% of a comparable natural runner's COT.
Related Concept Videos
 01:23
Muscles that Move the Leg
Anterior Compartment
The quadriceps femoris, the most visible muscle of the anterior compartment, is integral for leg extension and thigh flexion. It is formed by merging four distinct muscles — the vastus lateralis, vastus medialis, vastus intermedius, and rectus femoris. The quadriceps tendon, a shared tendon of the four quadriceps muscles, is affixed...
 01:28
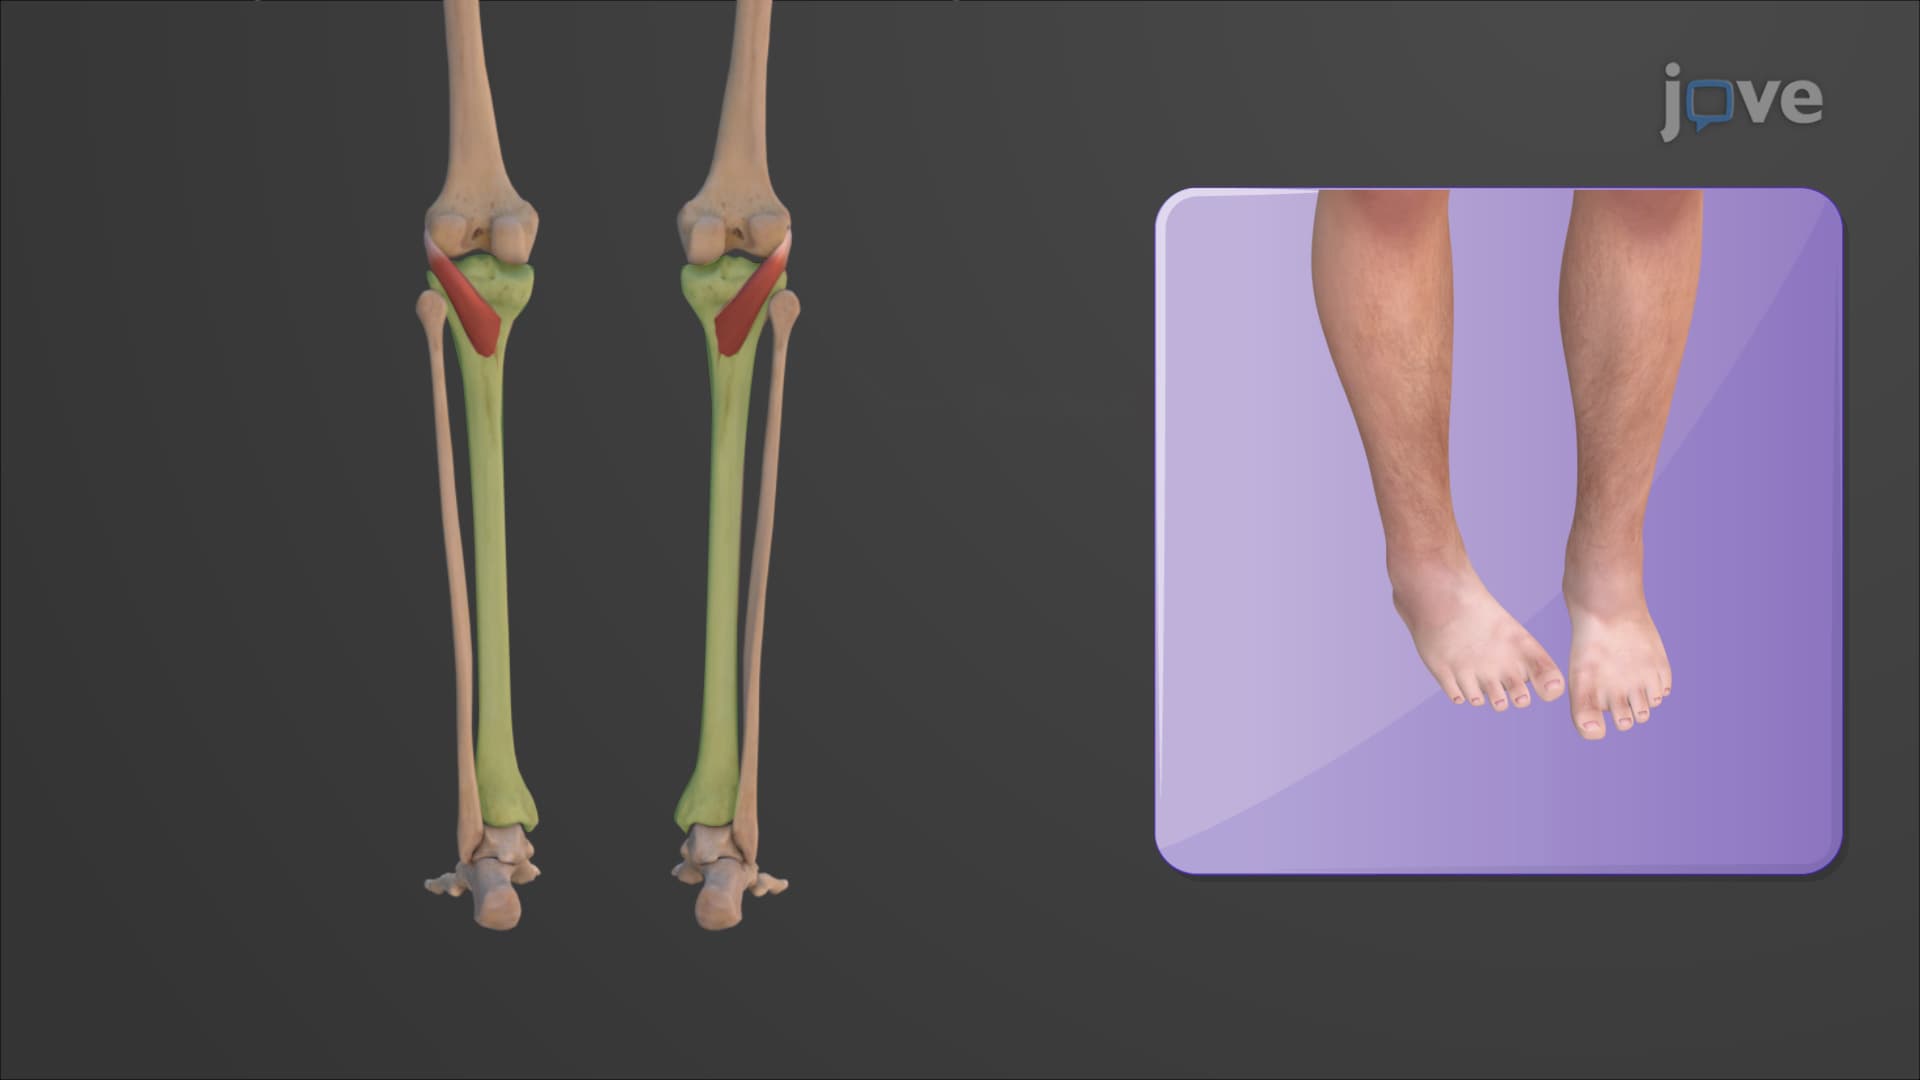
Muscles of the Leg that Move the Foot and Toes
Anterior Compartment
The anterior compartment includes muscles that contribute to the dorsiflexion of the foot. This compartment houses the tibialis anterior, extensor hallucis longus, and extensor digitorum longus muscles....
 01:13
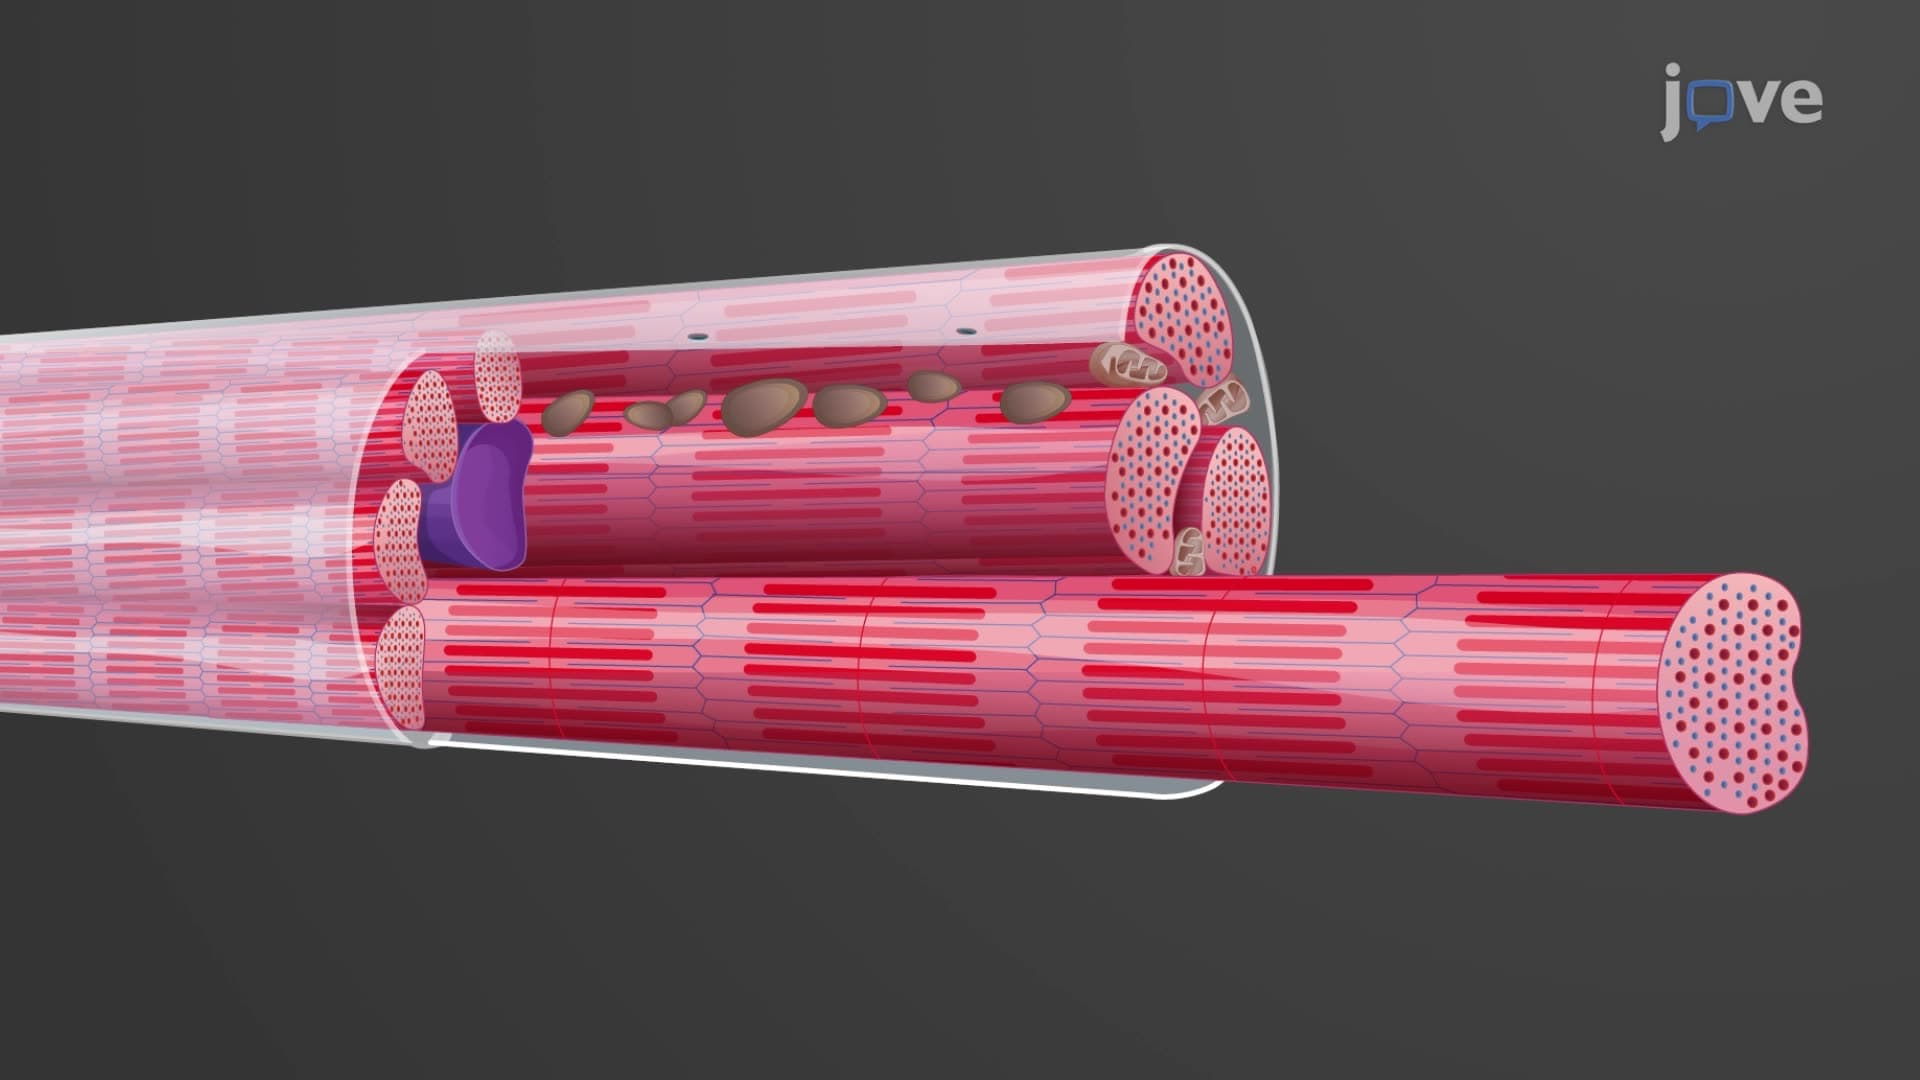
Structure of Cardiac Muscles
Compared to skeletal muscles, cardiac muscle cells are small and mostly have a single nucleus. Additionally, they are usually...
 01:13
Structure and Organization of Smooth Muscles
Structure of smooth muscle cell
Smooth muscle cells are spindle-shaped with tapering ends and a...
 01:12
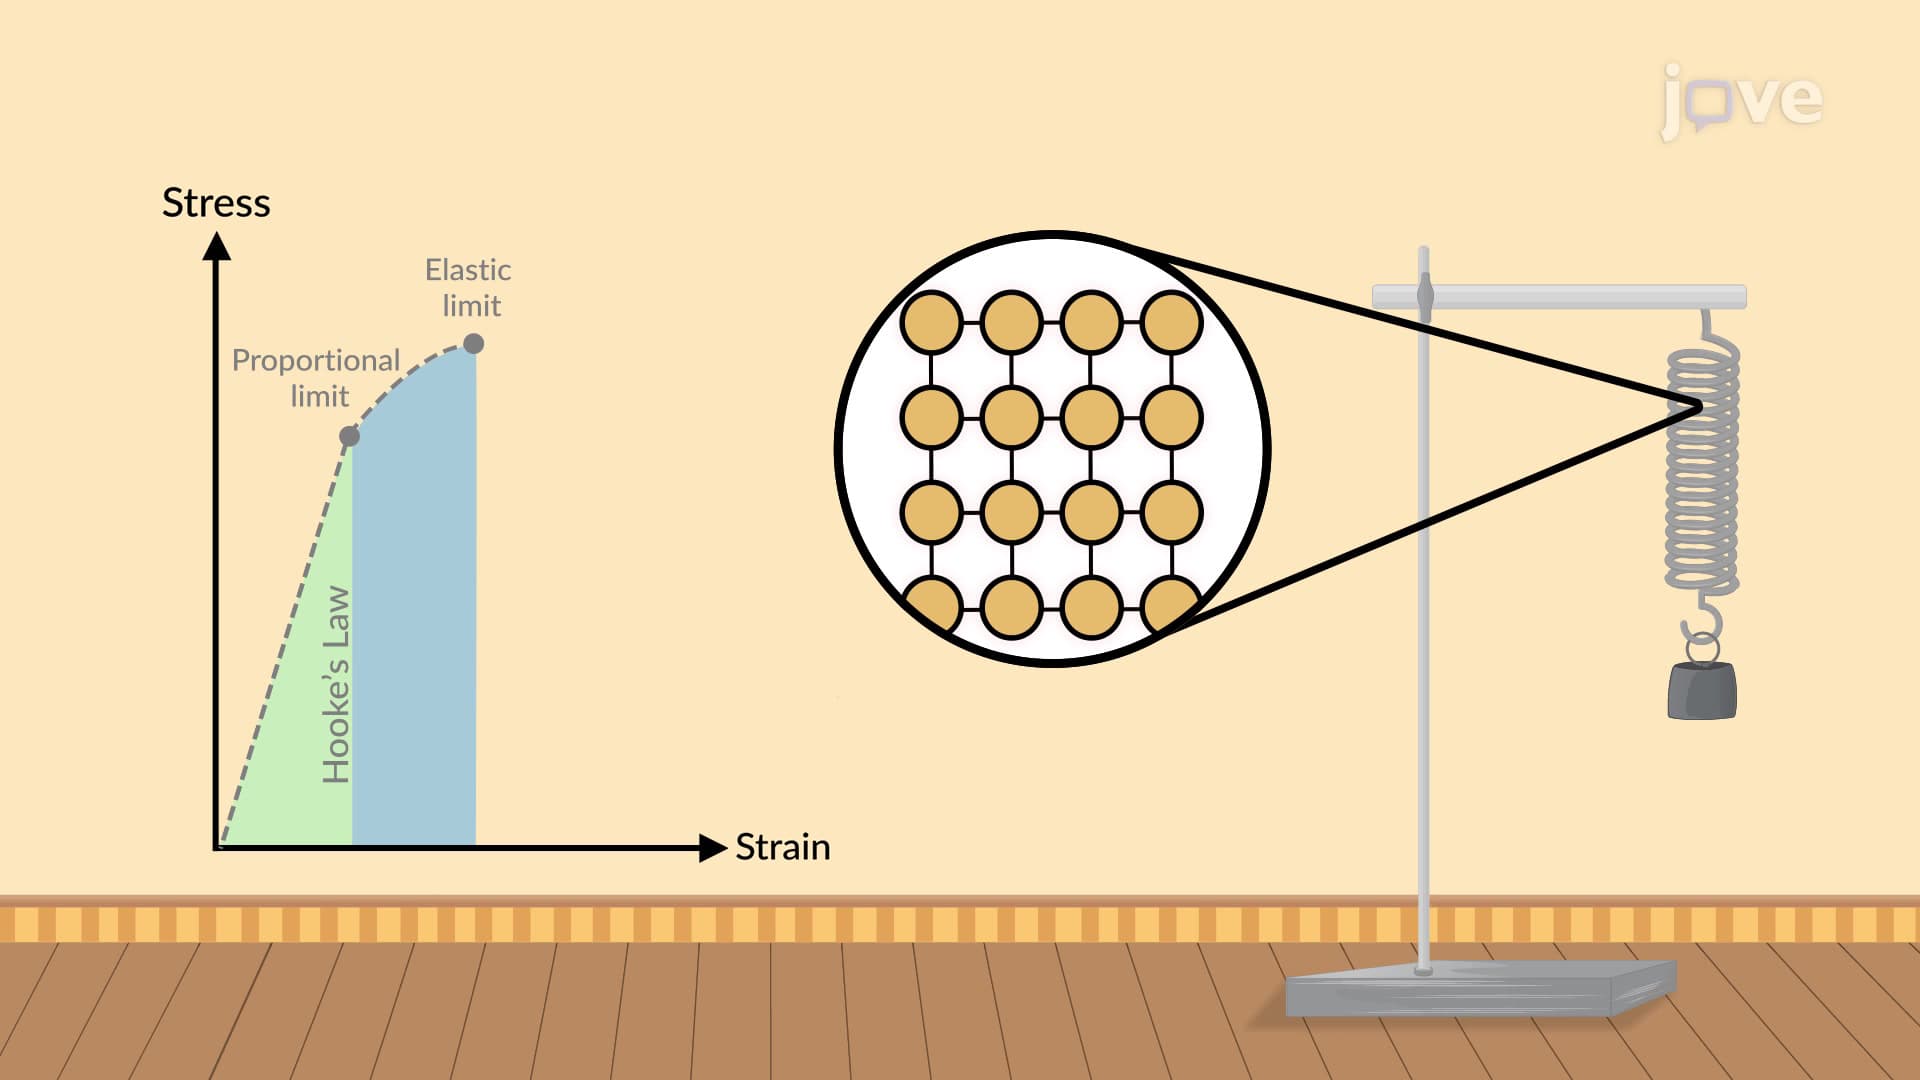
Elasticity
The elasticity of an object can be described by a stress-strain curve, which represents the relationship between stress...
 01:10
Resistors In Series
In a series circuit, the...