Related Experiment Video
Updated: Jan 20, 2026


BIBO stability of continuous and discrete -time systems
Networked controller and observer design of discrete-time systems with inaccurate model parameters
Jinna Li1, Zhenfei Xiao2, Ping Li2
1School of Information and Control Engineering, Liaoning Shihua University, Liaoning 113001, PR China; State Key Laboratory of Synthetical Automation for Process Industries, Northeastern University, Shenyang 110819, PR China.

Abstract:
This paper develops a novel off-policy Q-learning method to find the optimal observer gain and the optimal controller for achieving optimality of network-communication based linear discrete-time systems using only measured data. The primary advantage of this off-policy Q-learning method is that it can work for the linear discrete-time systems with inaccurate system model, unmeasurable system states and network-induced delays. To this end, an optimization problem for networked control systems composed of a plant, a state observer and a Smith predictor is formulated first. The Smith predictor is employed to not only compensate network-induced delays, but also make the separation principle hold, thus the observer and controller can be designed separately. Then, the off-policy Q-learning is implemented for learning the optimal observer gain and the optimal controller combined with the Smith predictor, such that a novel off-policy Q-learning algorithm is derived using only input, output and delayed estimated state of systems, not the inaccurate system matrices. The convergences of the iterative observer gain and the iterative controller gain are rigorously proven. Finally, simulation results are given to verify the effectiveness of the proposed method.
Related Concept Videos
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
 01:26
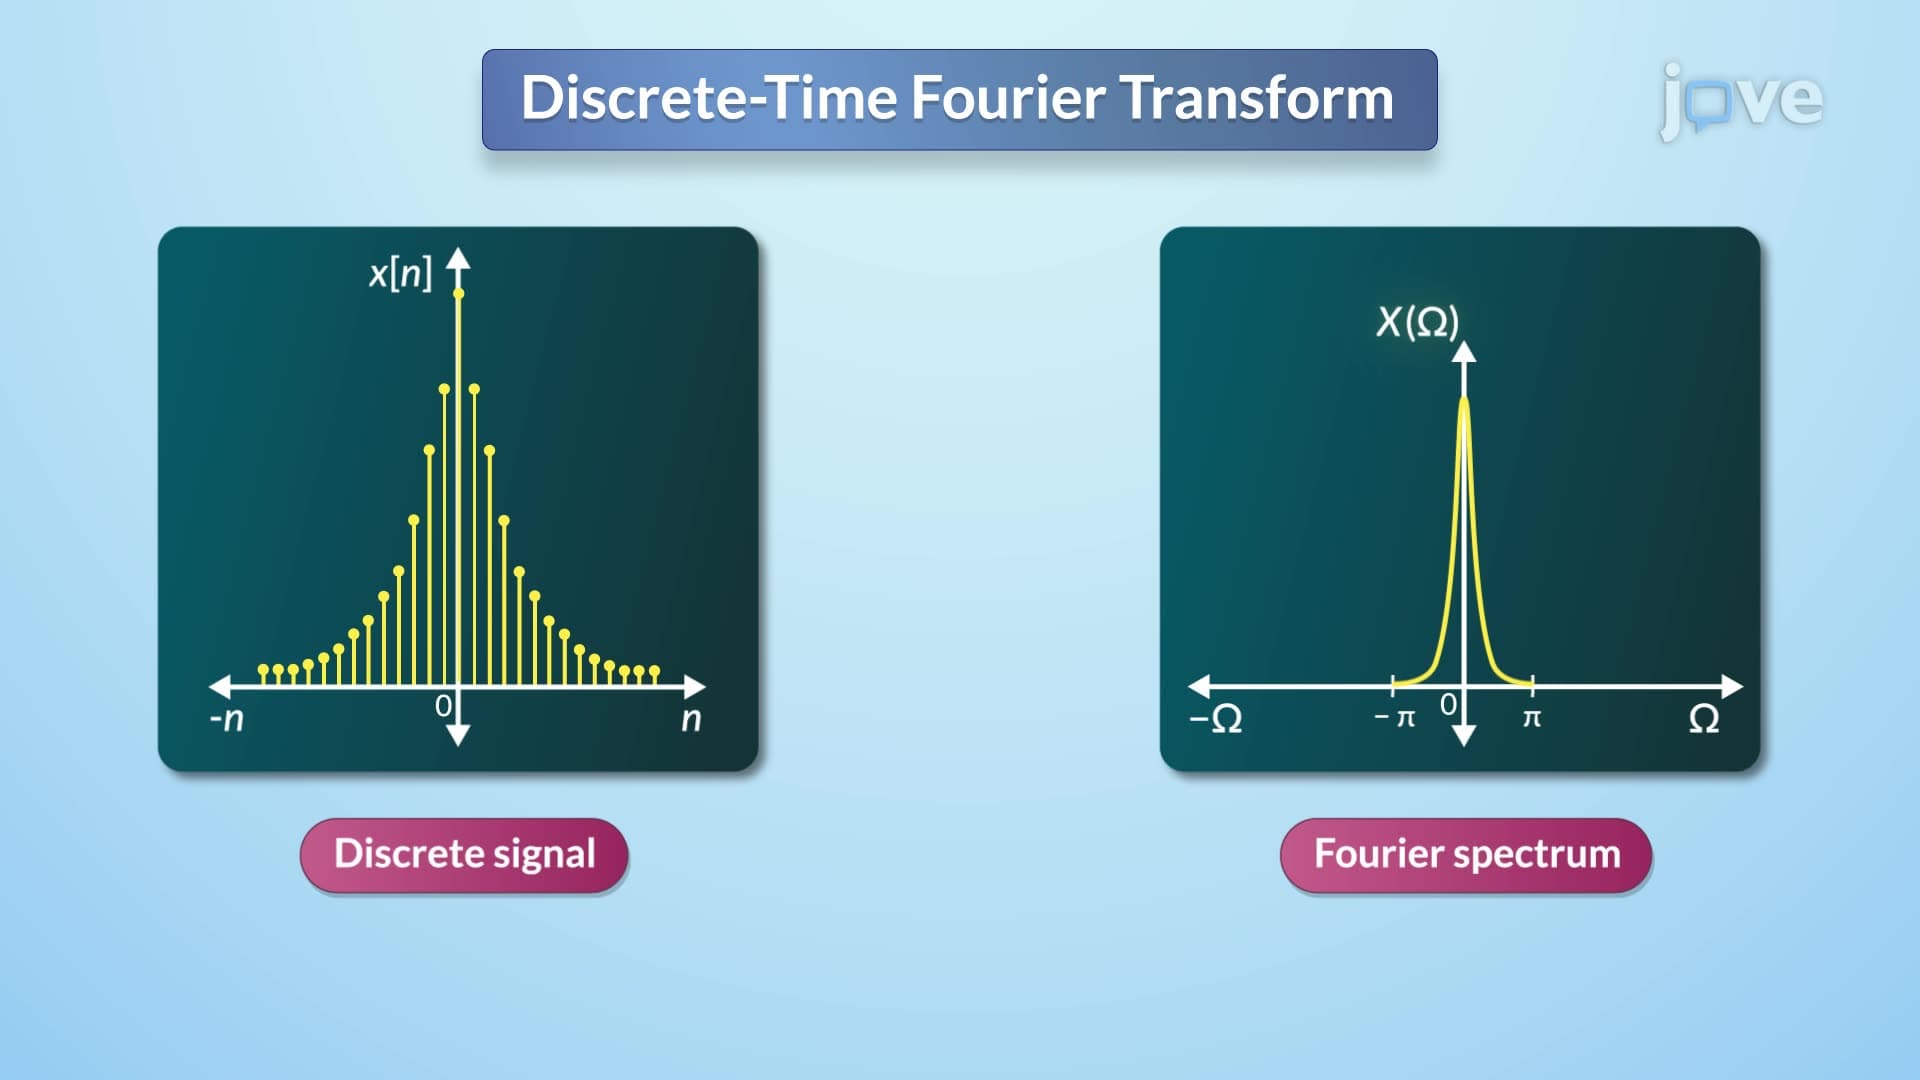
Discrete-time Fourier transform
One of the notable...
 01:16
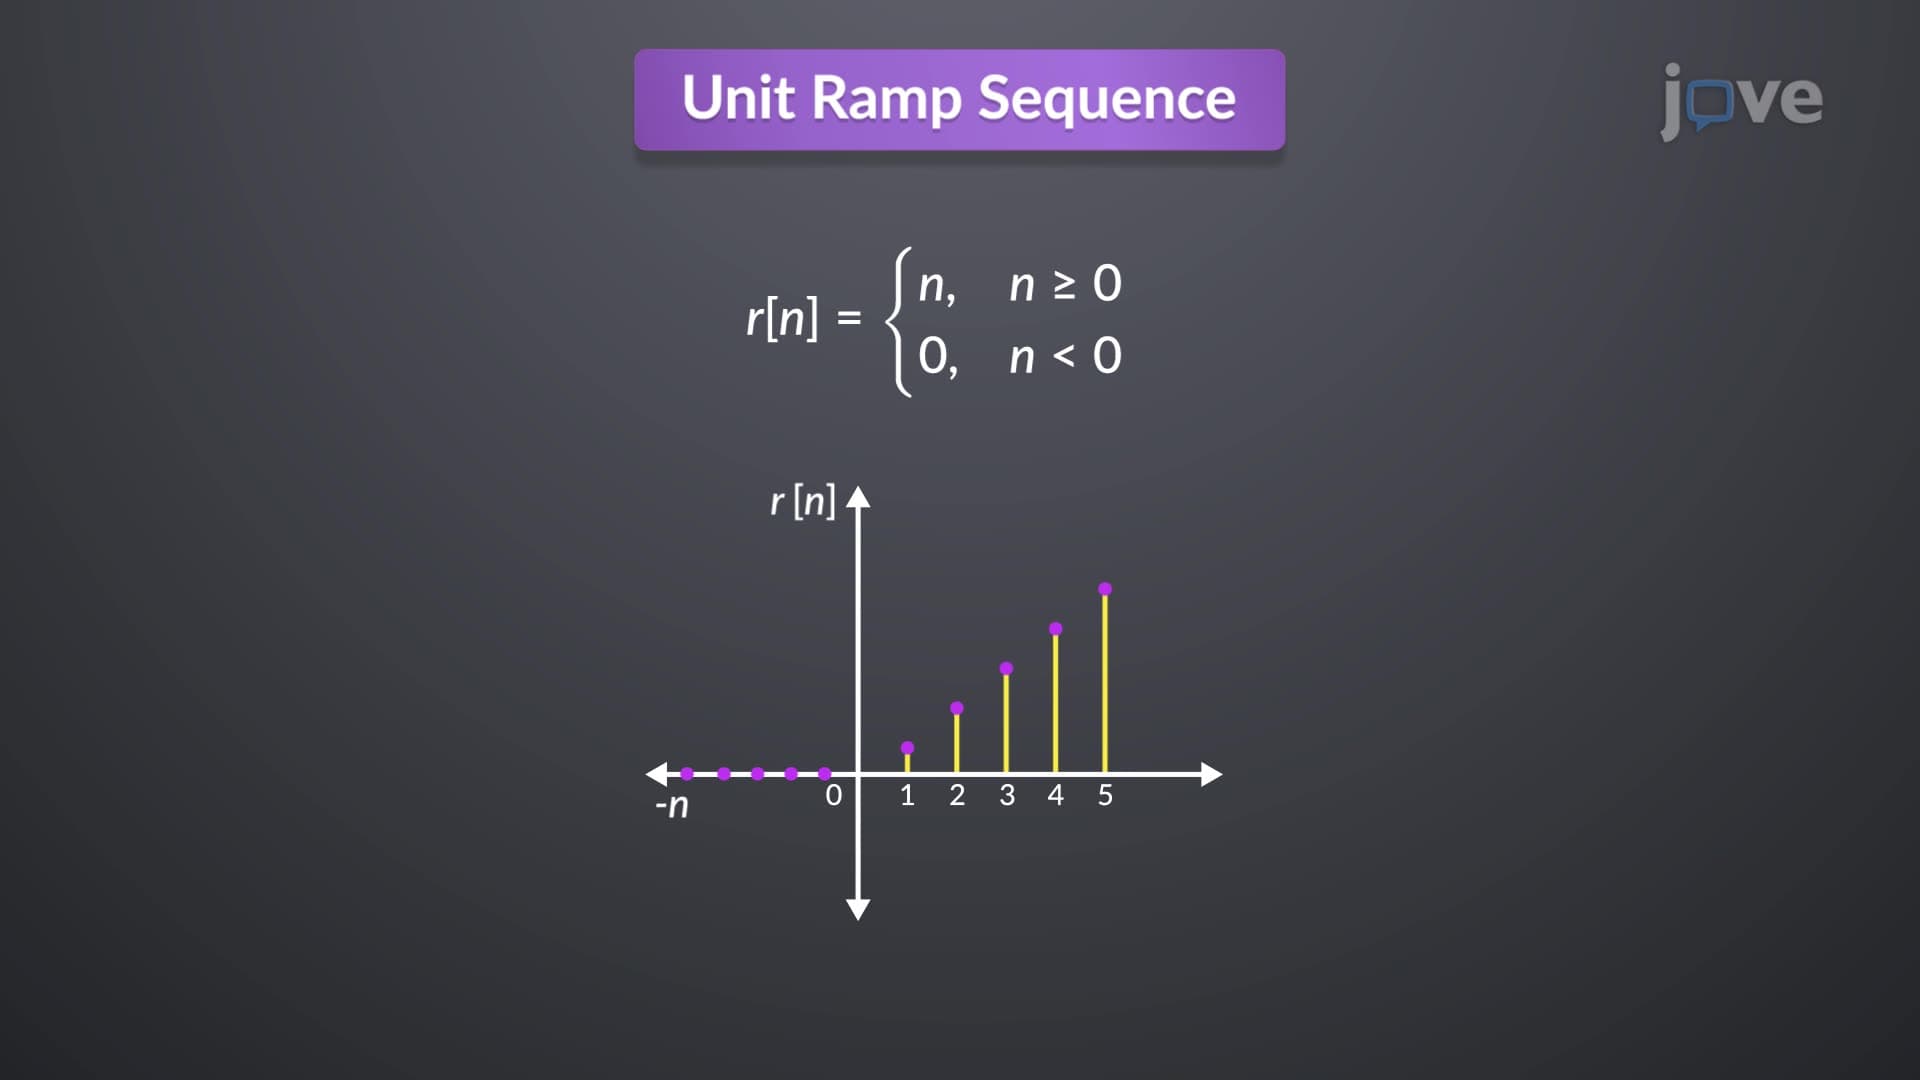
Basic Discrete Time Signals
The unit impulse or sample sequence is mathematically expressed as zero for all n values except at n=0, where it is one. The unit impulse sequence, denoted by δ(n), is the first difference of the unit step sequence, while the unit step sequence u(n) is the...
 01:20
Discrete-Time Fourier Series
For a discrete-time periodic signal x[n]...
 01:10
Control Systems
At the heart...
 09:04
A Modeling and Simulation Method for Preliminary Design of an Electro-Variable Displacement Pump