Related Experiment Video
Updated: Jan 19, 2026
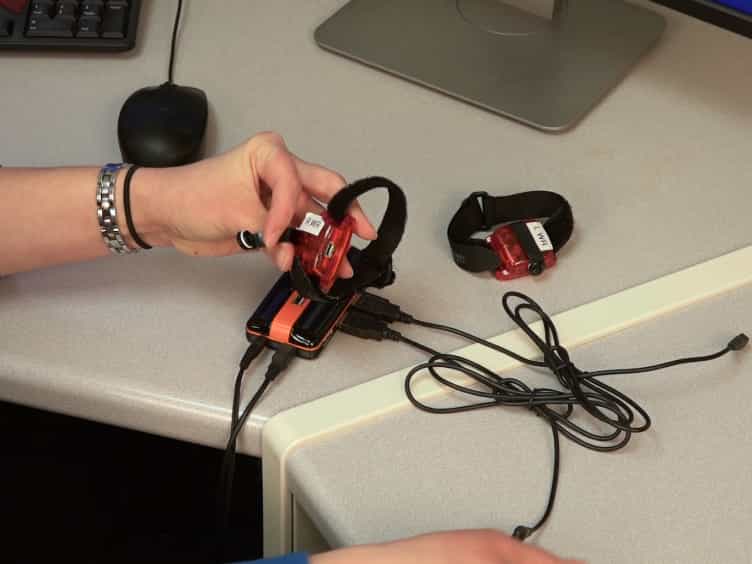

A Method for Quantifying Upper Limb Performance in Daily Life Using Accelerometers
Published on: April 21, 2017
Radial Basis Functions Intended to Determine the Upper Bound of Absolute Dynamic Error at the Output of Voltage-Mode
Krzysztof Tomczyk1, Marcin Piekarczyk2, Grzegorz Sokal3
1Faculty of Electrical and Computer Engineering, Cracow University of Technology, Warszawska 24, 31-155 Krakow, Poland. ktomczyk@pk.edu.pl.

Abstract:
In this paper, we propose using the radial basis functions (RBF) to determine the upper bound of absolute dynamic error (UAE) at the output of a voltage-mode accelerometer. Such functions can be obtained as a result of approximating the error values determined for the assumed-in-advance parameter variability associated with the mathematical model of an accelerometer. This approximation was carried out using the radial basis function neural network (RBF-NN) procedure for a given number of the radial neurons. The Monte Carlo (MC) method was also applied to determine the related error when considering the uncertainties associated with the parameters of an accelerometer mathematical model. The upper bound of absolute dynamic error can be a quality ratio for comparing the errors produced by different types of voltage-mode accelerometers that have the same operational frequency bandwidth. Determination of the RBFs was performed by applying the Python-related scientific packages, while the calculations related both to the UAE and the MC method were carried out using the MathCad program. Application of the RBFs represent a new approach for determining the UAE. These functions allow for the easy and quick determination of the value of such errors.

Related Concept Videos
 01:23
Radial System Protection
In a radial system with a fault downstream of the third breaker, ideally, only the third breaker will open, isolating the fault and interrupting the load connected beyond it. The second breaker has a longer delay setting,...
 01:28
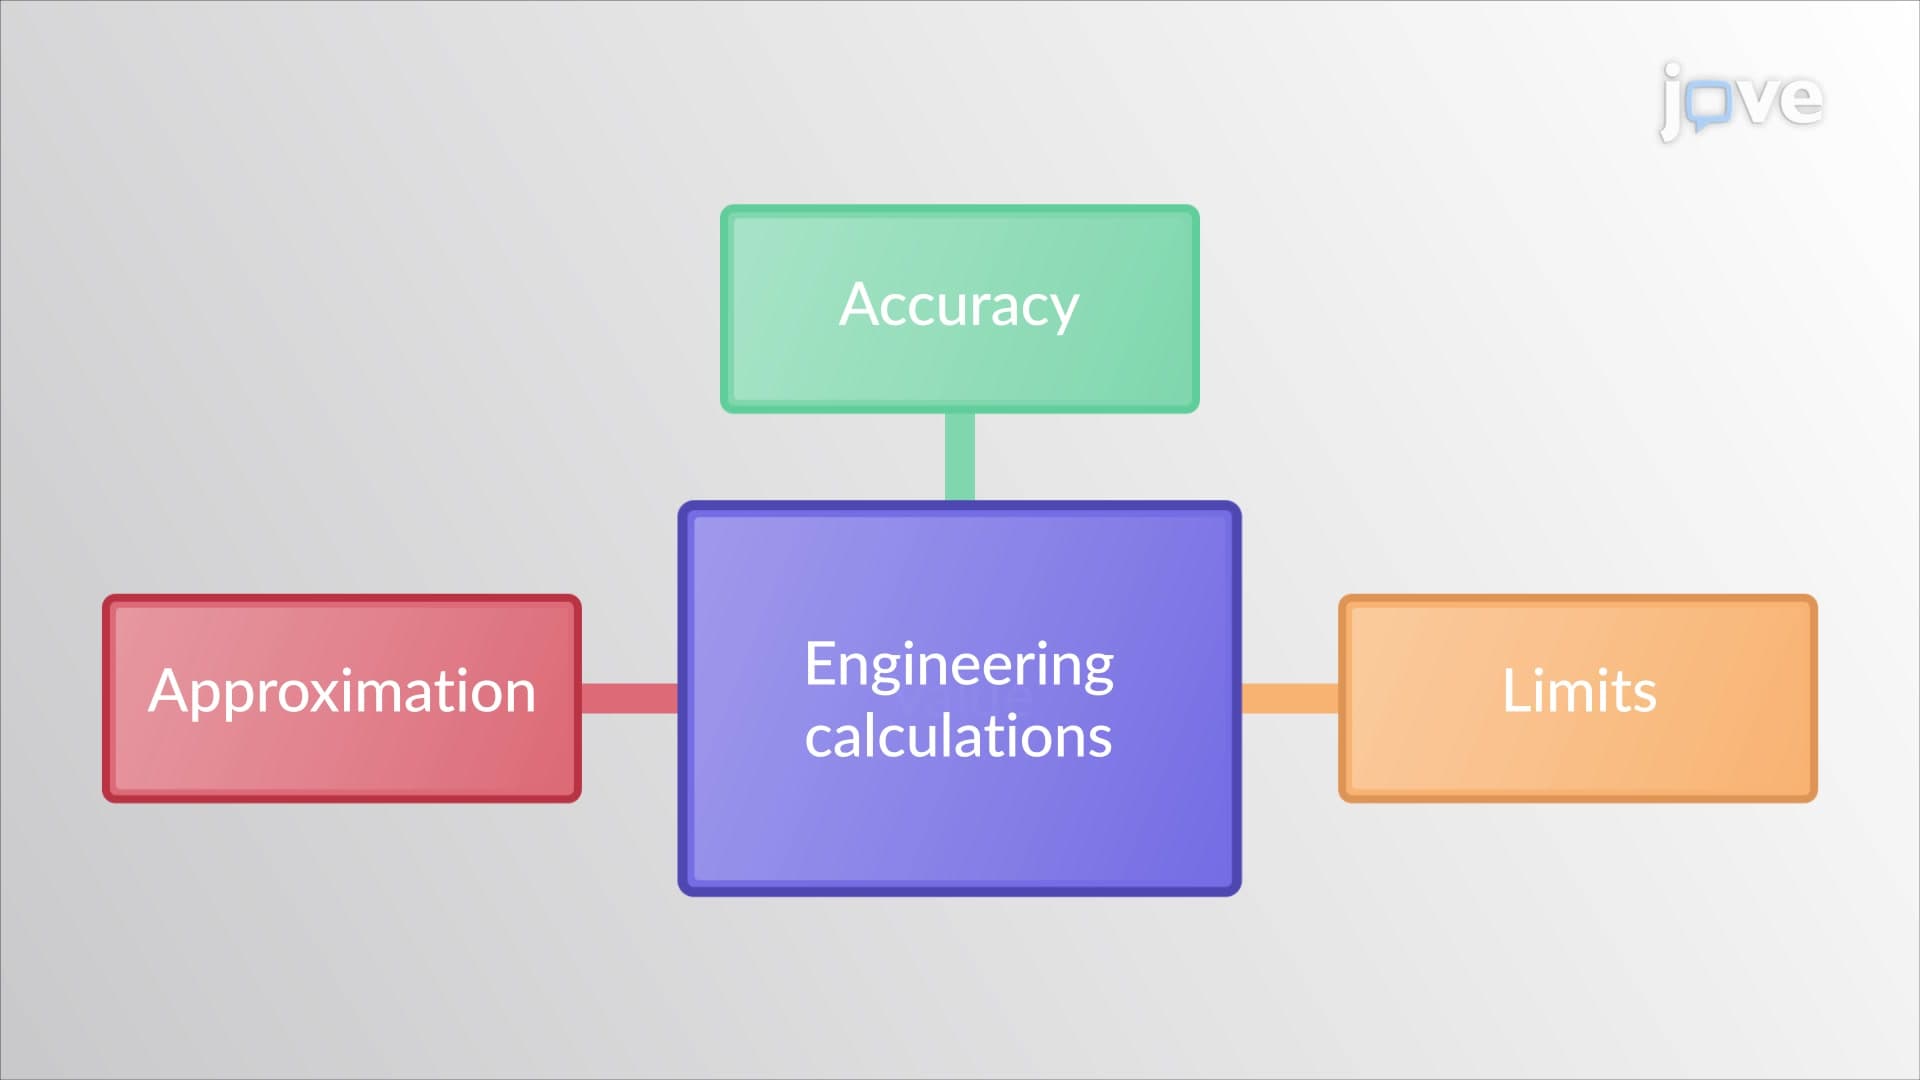
Accuracy, limits, and approximation
Accuracy is defined as the closeness of the measured value to the true or actual value. In engineering mechanics, repeated measurements are taken during theoretical or experimental analyses to ensure that the result is precise and accurate.
The accuracy of any solution is based on the...
 01:10
Relative Motion Analysis - Acceleration
 01:11
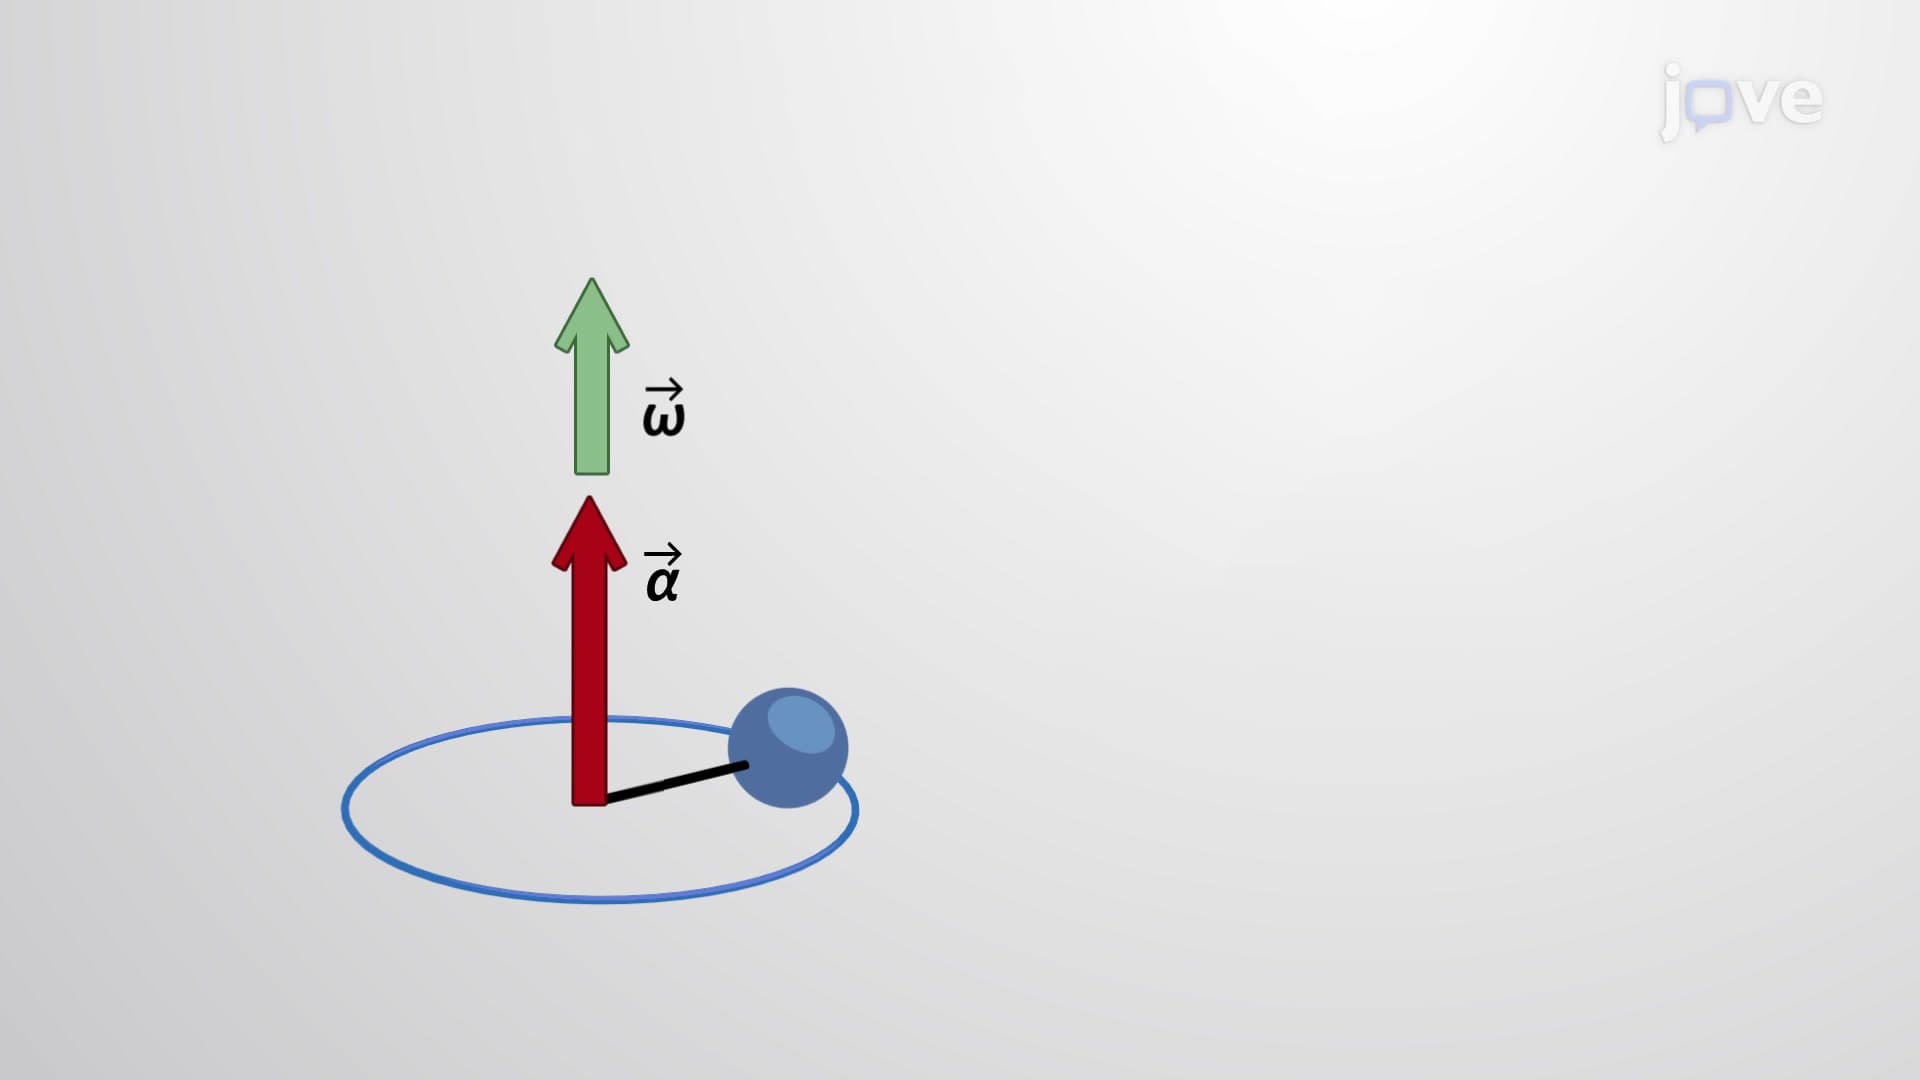
Angular Velocity and Acceleration
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Time differentiation is...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...