Related Experiment Video
Updated: Jan 5, 2026
09:59
Fabrication of Flexible Image Sensor Based on Lateral NIPIN Phototransistors
Published on: June 23, 2018
8.1K
Linear transfer function estimation using the photodiode impulse response
Optics Letters
|October 16, 2019

Abstract:
In this Letter, we implement a model-based auto-regressive estimator of the frequency response for a high-speed photodiode (PD). A transfer function is developed, and the associated coefficients representing the PD model and frequency response are solved for using a two-stage least-squares approach. The model is implemented for a modified uni-traveling carrier PD and experimentally compared to measured impulse response data.
Related Concept Videos
 01:20
Frequency Response of a Circuit
601
Inductive circuits present intriguing challenges in electrical engineering, particularly during the transition from the time domain to the frequency domain. This transformation involves converting inductors into impedances and utilizing phasor representation.
The transfer function is pivotal in characterizing how these circuits react to various frequencies, facilitating a profound understanding of their behavior. An essential parameter is the time constant, signifying the...
The transfer function is pivotal in characterizing how these circuits react to various frequencies, facilitating a profound understanding of their behavior. An essential parameter is the time constant, signifying the...
601
 01:26
Linear Approximation in Frequency Domain
325
Linear systems are characterized by two main properties: superposition and homogeneity. Superposition allows the response to multiple inputs to be the sum of the responses to each individual input. Homogeneity ensures that scaling an input by a scalar results in the response being scaled by the same scalar.
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
325
 01:21
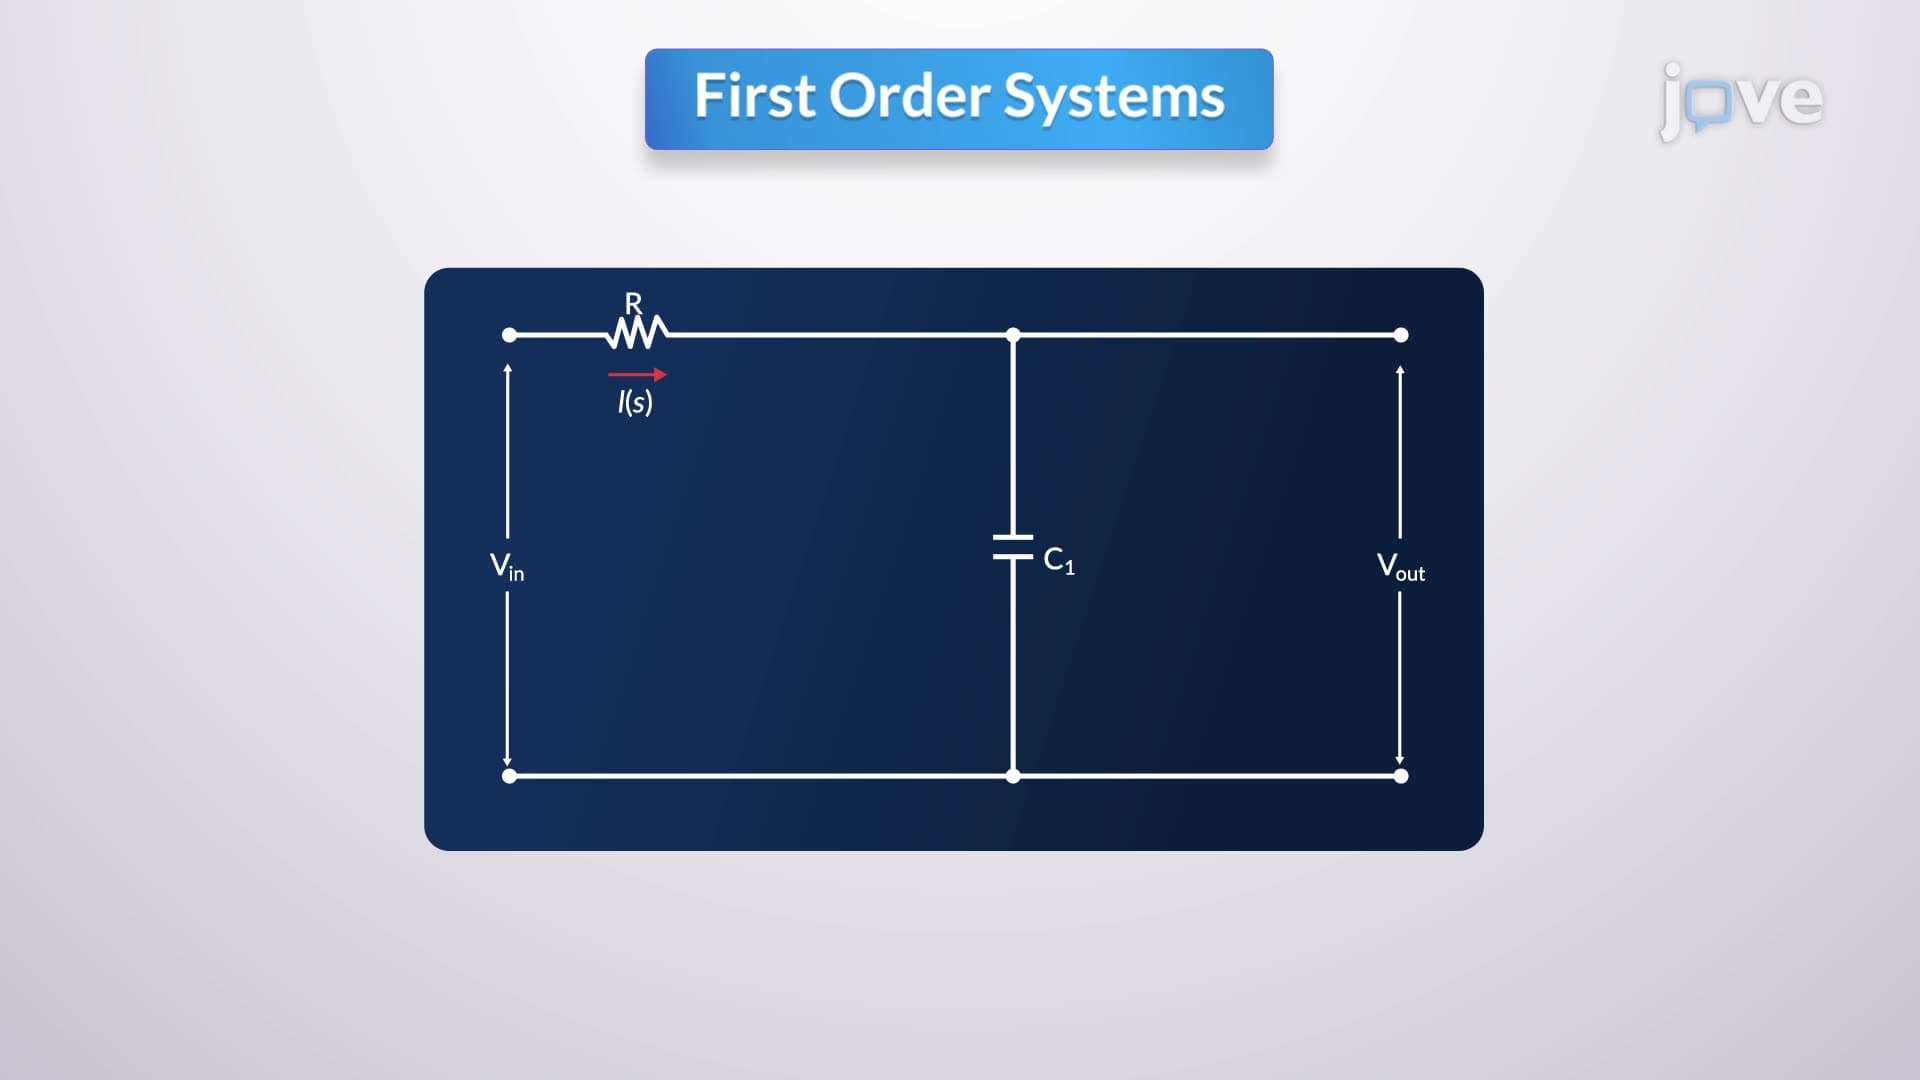
First Order Systems
341
First-order systems, such as RC circuits, are foundational in understanding dynamic systems due to their straightforward input-output relationship. Analyzing their responses to different input functions under zero initial conditions reveals significant insights into system behavior.
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
341
 01:18
Second Order systems II
363
In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
363
 01:21
Transfer Function in Control Systems
1.4K
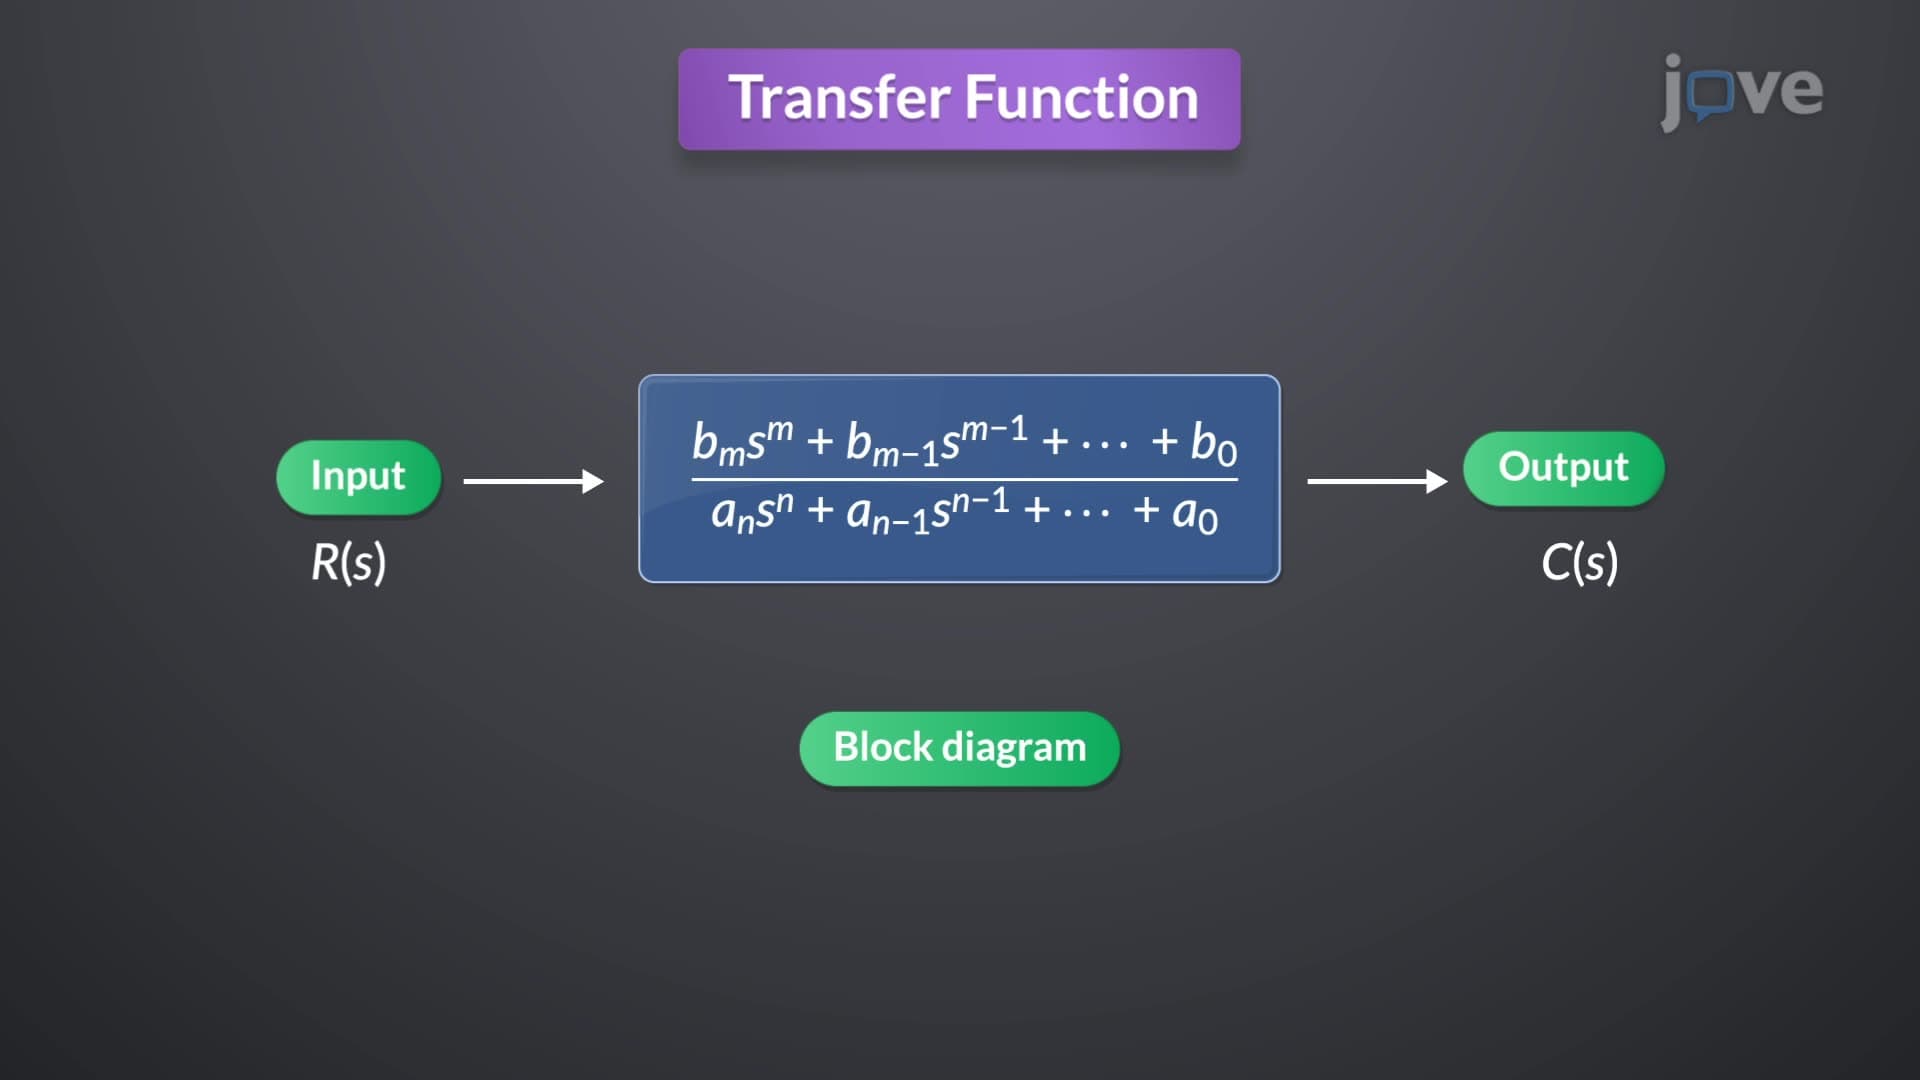
The transfer function is a fundamental concept in the analysis and design of linear time-invariant (LTI) systems. It offers a concise way to understand how a system responds to different inputs in the frequency domain. It serves as a bridge between the time-domain differential equations that describe system dynamics and the frequency-domain representation that facilitates easier manipulation and analysis.
To derive the transfer function, consider a general nth-order linear time-invariant...
To derive the transfer function, consider a general nth-order linear time-invariant...
1.4K
 01:20
Deconvolution
518
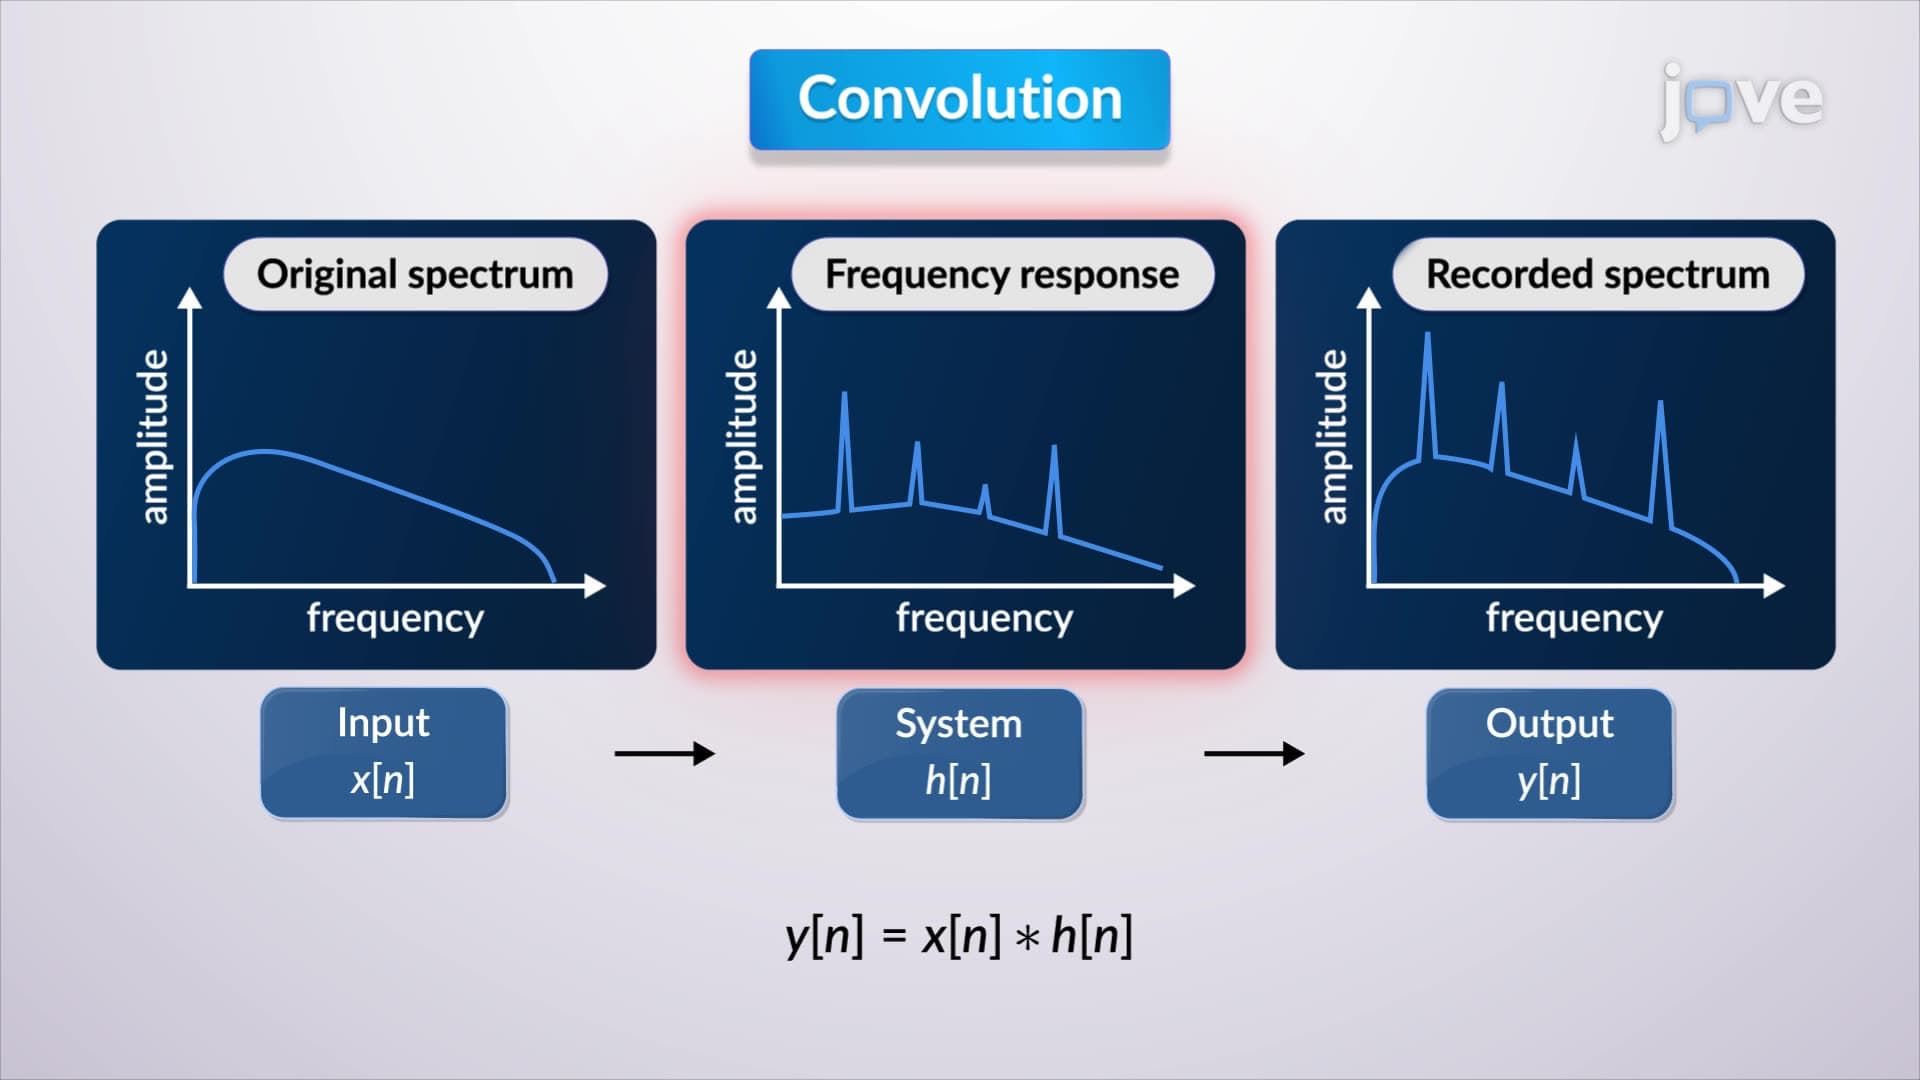
Deconvolution, also known as inverse filtering, is the process of extracting the impulse response from known input and output signals. This technique is vital in scenarios where the system's characteristics are unknown, and they must be inferred from the observable signals.
Deconvolution involves several mathematical techniques to derive the impulse response. One common approach is polynomial division. In this method, the input and output sequences are treated as coefficients of...
Deconvolution involves several mathematical techniques to derive the impulse response. One common approach is polynomial division. In this method, the input and output sequences are treated as coefficients of...
518