Related Experiment Video
Updated: Jan 5, 2026
Fabrication of Soft Pneumatic Network Actuators with Oblique Chambers
Published on: August 17, 2018
Poisson Induced Bending Actuator for Soft Robotic Systems
Alexander Hasse1, Kristian Mauser1
1Professorship Machine Elements and Product Development, Institute of Design Engineering and Drive Technology, Chemnitz University of Technology, Chemnitz, Germany.

Abstract:
This article deals with a novel active bending soft body that uses metamaterials and combines soft behavior, integrated actuation, low complexity, and a high density of producible forces and moments. The presented concept consists of a tube-like structure with tailored, unconventional material properties, which enable the generation of a bending deformation and/or moment when circumferential stress and/or strain is induced. Circumferential actuation can be generated by a difference in pressure between the internal and external surface of the tube or, alternatively, by distributed expansion actuators that act radially or tangentially (e.g., shape memory wires). In addition to an analytical model, this article also presents a design procedure and deals with the implementation of the proposed concept in a functional prototype and its experimental characterization.
Related Concept Videos
 01:15
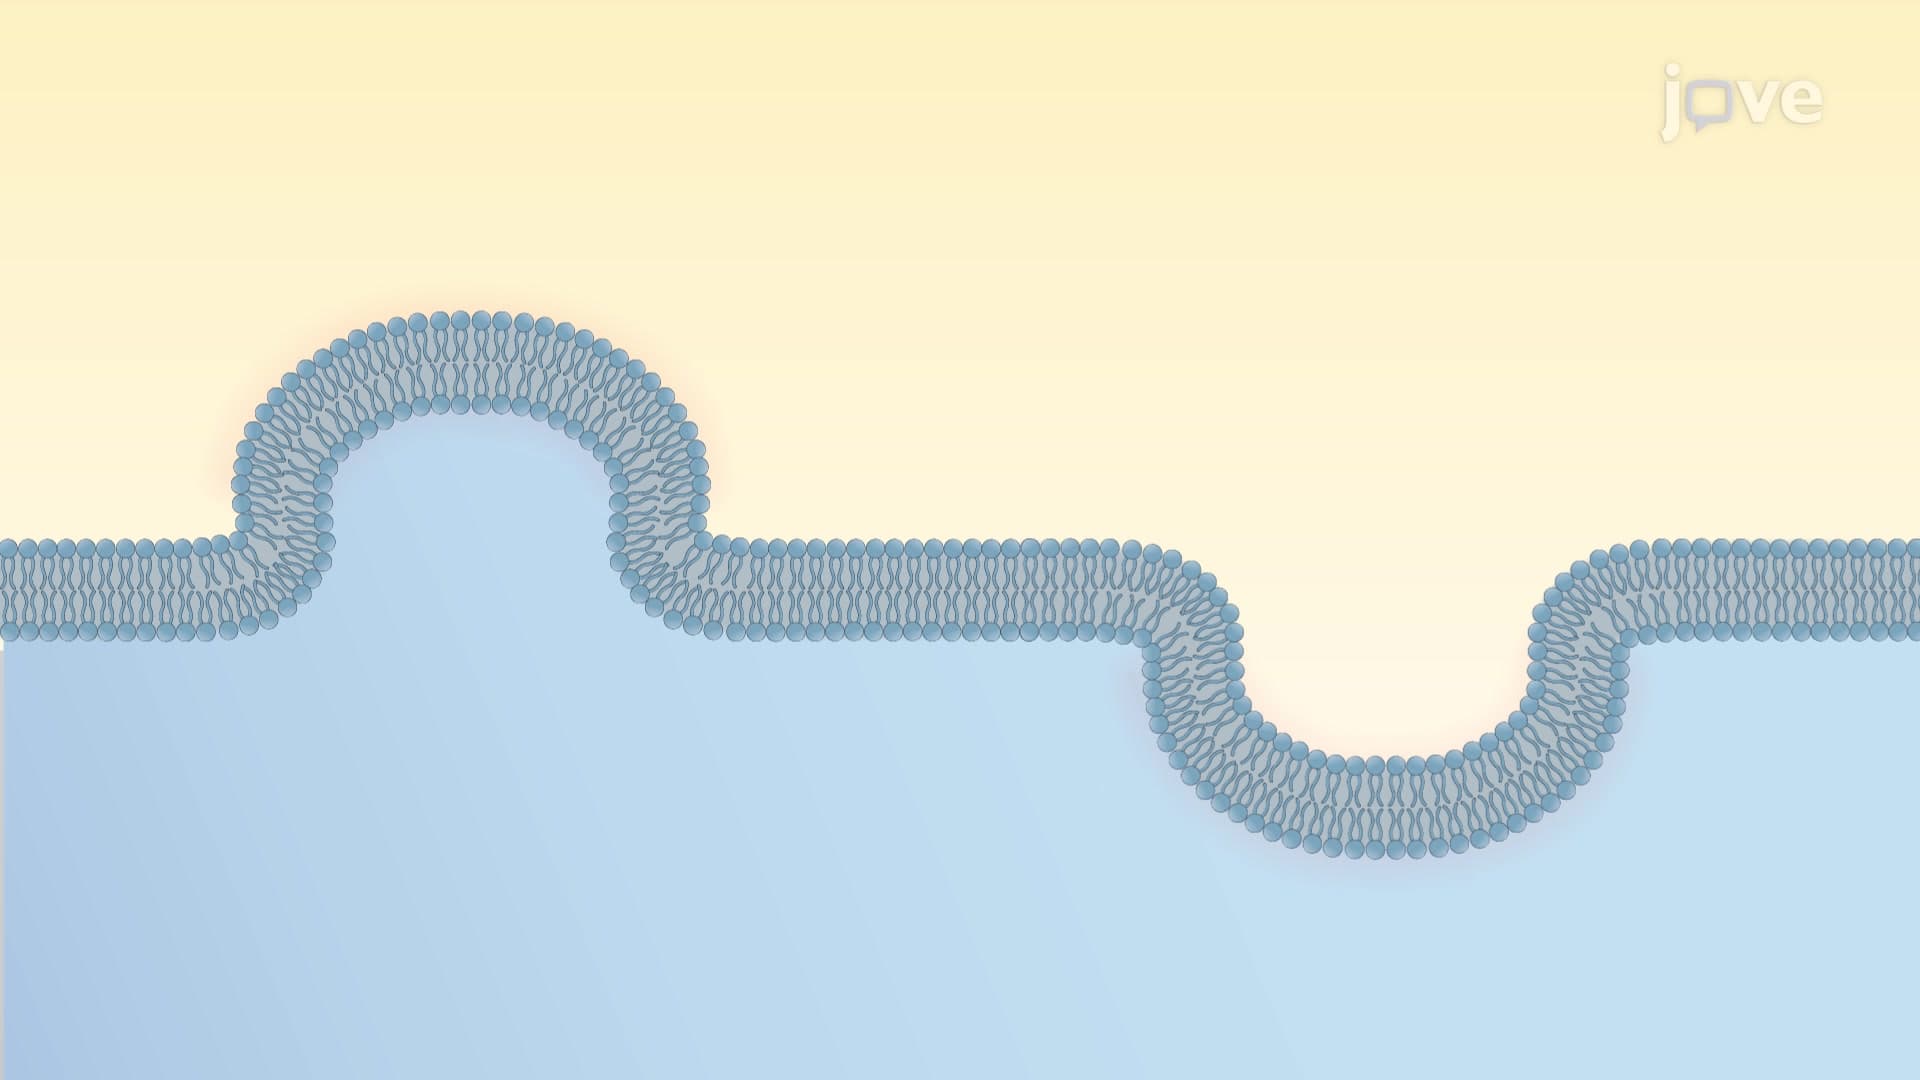
Mechanisms of Membrane-bending
Membrane bending can happen due to intrinsic changes in lipid composition or extrinsic association with different proteins. The proteins involved...
 01:20
Bending and Torsional Moments
The reaction developed in a structural element when subjected to an external force causes the element to bend. When a structural element bends upwards, it creates compressive normal forces on the top and tensile normal forces on the bottom, resulting in a couple that determines the bending...
 01:15
Unsymmetric Bending - Angle of Neutral Axis
When a bending moment is applied at an angle θ concerning the vertical axis of a symmetrical member, it can be resolved into components along the member's principal...