Related Experiment Video
Updated: Jan 3, 2026
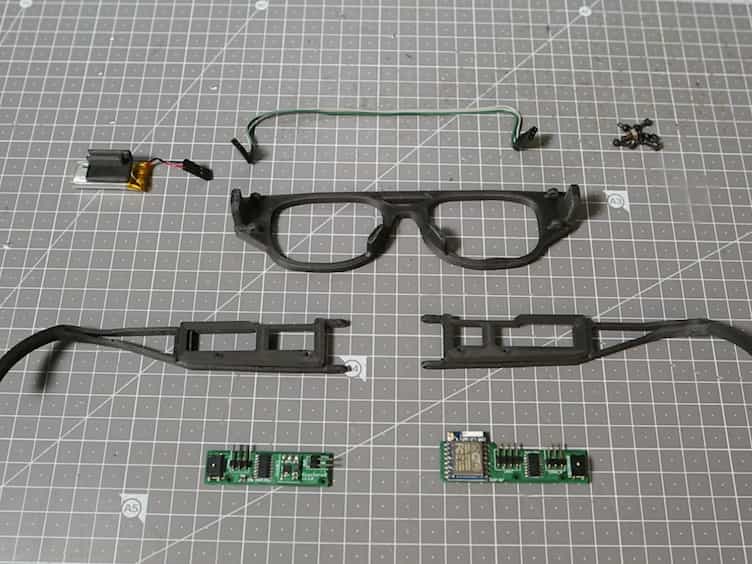

Design and Evaluation of Smart Glasses for Food Intake and Physical Activity Classification
Published on: February 14, 2018
Design of a Low-Cost Indoor Navigation System for Food Delivery Robot Based on Multi-Sensor Information Fusion
Yunlong Sun1, Lianwu Guan1, Zhanyuan Chang2
1College of Automation, Harbin Engineering University, Harbin 150001, China.

Abstract:
As the restaurant industry is facing labor shortage issues, the use of meal delivery robots instead of waiters/waitresses not only allows the customers to experience the impact of robot technology but also benefits the restaurant business financially by reducing labor costs. Most existing meal delivery robots employ magnetic navigation technologies, which require magnetic strip installation and changes to the restaurant decor. Once the moving path is changed, the magnetic strips need to be re-laid. This study proposes multisource information fusion, i.e., the fusion of ultra-wide band positioning technology with an odometer and a low-cost gyroscope accelerometer, to achieve the positioning of a non-rail meal delivery robot with navigation. By using a low-cost electronic compass and gyroscope accelerometer, the delivery robot can move along a fixed orbit in a flexible and cost-effective manner with steering control. Ultra-wide band (UWB) and track estimation algorithm are combined by extended Kalman filter (EKF), and the positioning error after fusion is about 15 cm, which is accepted by restaurants. In summary, the proposed approach has some potential for commercial applications.


Related Concept Videos
 01:30
Design Example: Identifying the Locations of Monuments in the Field Using Global Positioning System Device
 01:28
Field Application of Global Positioning System
 01:26
Errors in Global Positioning System