Related Experiment Video
Updated: Dec 29, 2025


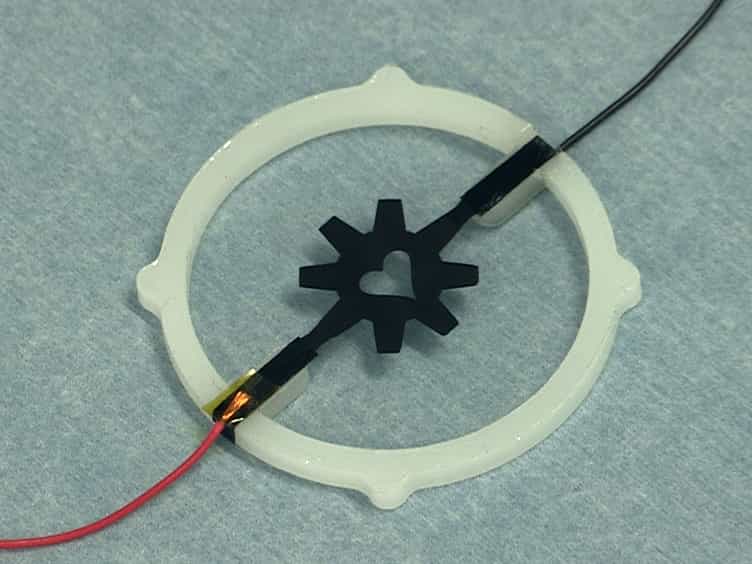
Design and Fabrication of an Elastomeric Unit for Soft Modular Robots in Minimally Invasive Surgery
Published on: November 14, 2015
Compact Series Visco-Elastic Joint (SVEJ) for Smooth Torque Control

Abstract:
The design and control of a new series-viscous-elastic joint are presented. The proposed joint consists of 3D printed parts compressing nonlinear elastic silicone springs. The use of silicone springs is the main novelty of the system; they exhibit internal damping, which enhances system performance allowing a simpler and more stable control. Their stiffness allows the system to bear a torque of about 4.5 Nm at a deformation angle of about 20 degrees. In this article, the system is modeled using the Neo-Hookean material model and then characterized through experiments to build the joint torque estimator. A proportional torque controller is implemented to evaluate bandwidth, transparency, impedance rendering, and stability, obtaining satisfactory results. The bandwidth ranges from 6.9 to 9.9 Hz depending on chirp input torque amplitude, as the system is nonlinear. The proposed solution is compact and cheap; both the design and the torque controller are suitable for future integration in an exoskeleton, or a cooperative robot, or a haptic device. SVEJ works as a torque sensor and introduces compliance between the motor and the environment, enhancing safety for robotic devices interacting with humans.

Related Concept Videos
 01:15
Torque Free Motion
 01:24
Circular Shafts - Elastoplastic Materials
As torque on the...
 01:16
Design of Transmission Shafts
 01:20
Plastic Deformation in Circular Shafts
 01:22
Mechanical Systems
 01:20
Bending and Torsional Moments
The reaction developed in a structural element when subjected to an external force causes the element to bend. When a structural element bends upwards, it creates compressive normal forces on the top and tensile normal forces on the bottom, resulting in a couple that determines the bending...