Related Experiment Video
Updated: Dec 28, 2025
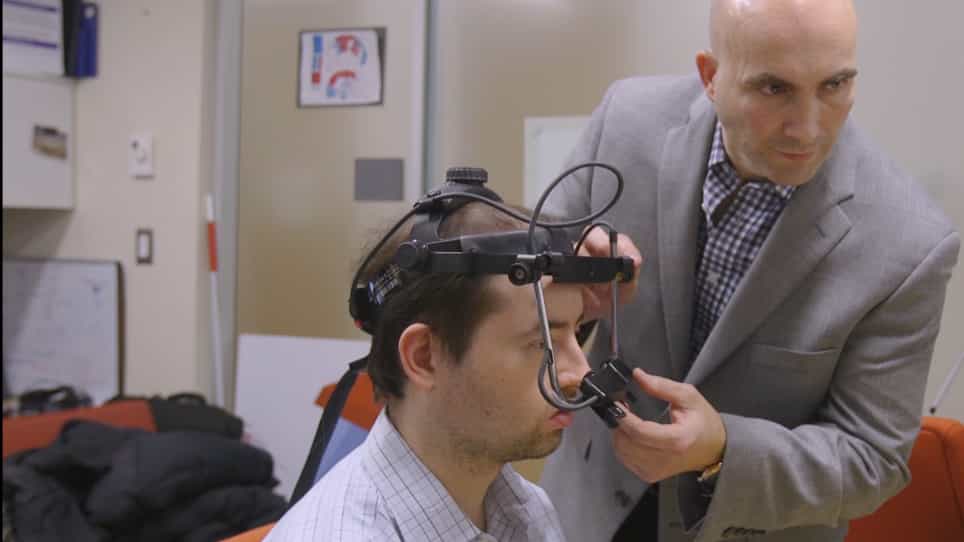

Efficiently Recording the Eye-Hand Coordination to Incoordination Spectrum
Published on: March 21, 2019
Spatiotemporal Coupling between Eye and Hand Trajectories during Curved Hand Movements
Sumitash Jana1, Aditya Murthy1
1Centre for Neuroscience, Indian Institute of Science, Bangalore, India.

Abstract:
Eye and hand movements are often made in isolation but for reaching movements they are usually coupled. Despite this, evidence for spatial coupling between the eye and hand effector is mixed and have usually been restricted to straight-line movements, while real-world hand movements have complex trajectories. Here, using a novel obstacle avoidance task where an obstacle appeared in an infrequent number of trials, we establish a stronger link between the saccade and hand trajectory during more naturalistic curved hand trajectories. We illustrate that the hand trajectory was coupled to the end-point of the saccade which was executed just prior to the hand movement onset. Interestingly, while the saccade end-point was related to whether the hand trajectory followed a straight or a curved path, the y-component of saccade end-point was related to whether the hand took a path passing from over or below the obstacle. Further, we observed a relationship between saccade locations and hand sub-movements where the number and timing of saccades and number of hand velocity peaks were related. These results illustrate a robust spatiotemporal and kinematic coupling between saccades and complex hand movement trajectories suggesting a shared kinematic representation underlying eye-hand movements.

Related Concept Videos
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:27
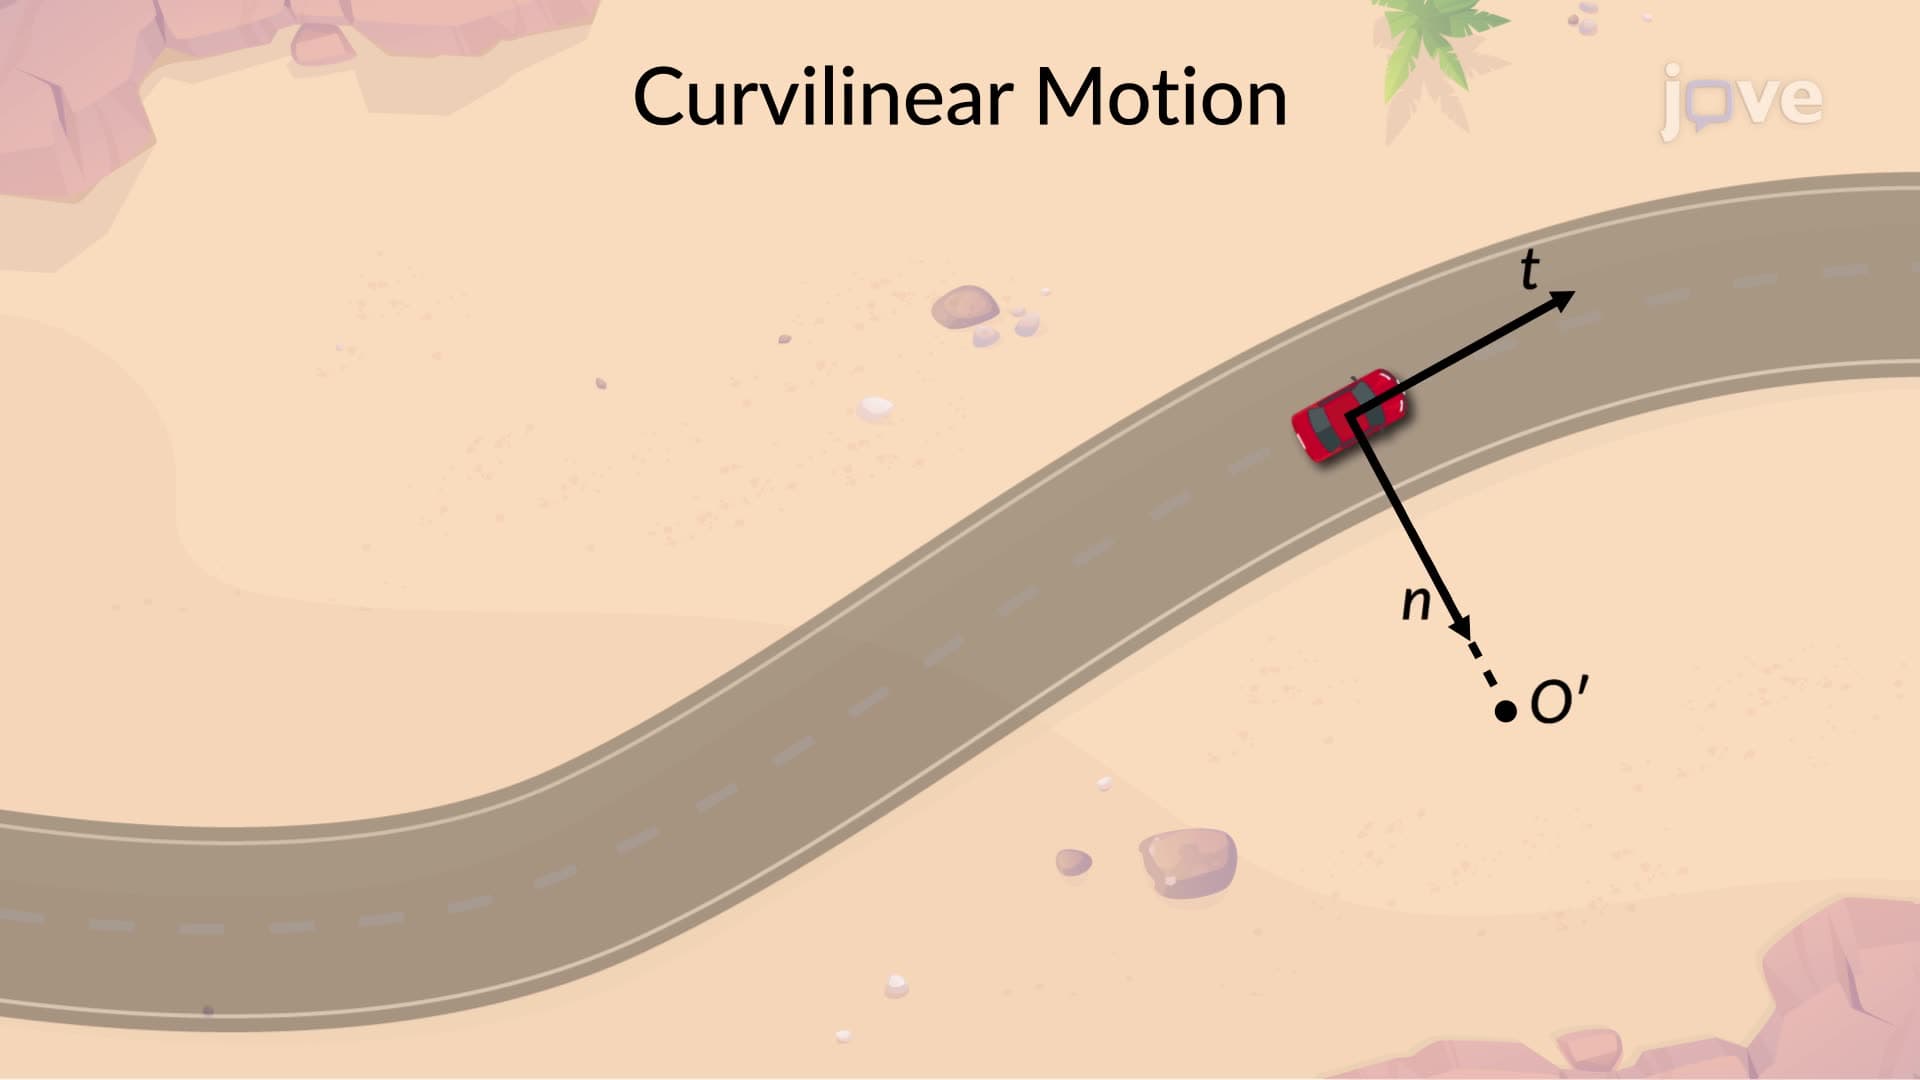
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
 01:27
Curvilinear Motion: Polar Coordinates
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:24
Gyroscope: Precession