Load swing rejection for double-pendulum tower cranes using energy-shaping-based control with actuator output limitation
Related Experiment Video
Updated: Dec 27, 2025
Author Spotlight: Enhancing Engineering Education via WebVR-Based Online Laboratories
Published on: February 23, 2024
Huimin Ouyang1, Zheng Tian1, Lili Yu1
1College of Electrical Engineering and Control Science, Nanjing Tech University, No.30, Puzhu Road(s), Nanjing, 211816, China.

Abstract:
For the controller design of tower cranes, the swing of load is always regarded the crane as a single-pendulum model, however in practical applications, such as when the hook mass can not be ignored, the tower crane dynamic system presents a double-pendulum nature. In this case, the dynamic characteristics analysis and controller design for such cranes becomes more complicated. In addition, many researches do not take into account the real situation of the actuator, that is, in actual tower cranes, the output torque/force can not be infinite due to the actual design constraints of the actuator. When the output torque reaches the limit value in some cases, the control performance is greatly reduced. According to the above, after simplifying the tower crane dynamic model, this paper presents a nonlinear controller based on energy-shaping to solve the above problems. The stability of the closed-loop system is proved by the Lyapunov technique and LaSalle's invariance theorem. Under a large number of simulation results, the proposed controller has good control performance and robustness.
More Related Videos
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
 07:19
A Modified Lean and Release Technique to Emphasize Response Inhibition and Action Selection in Reactive Balance
Published on: March 19, 2020
Related Concept Videos
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:21
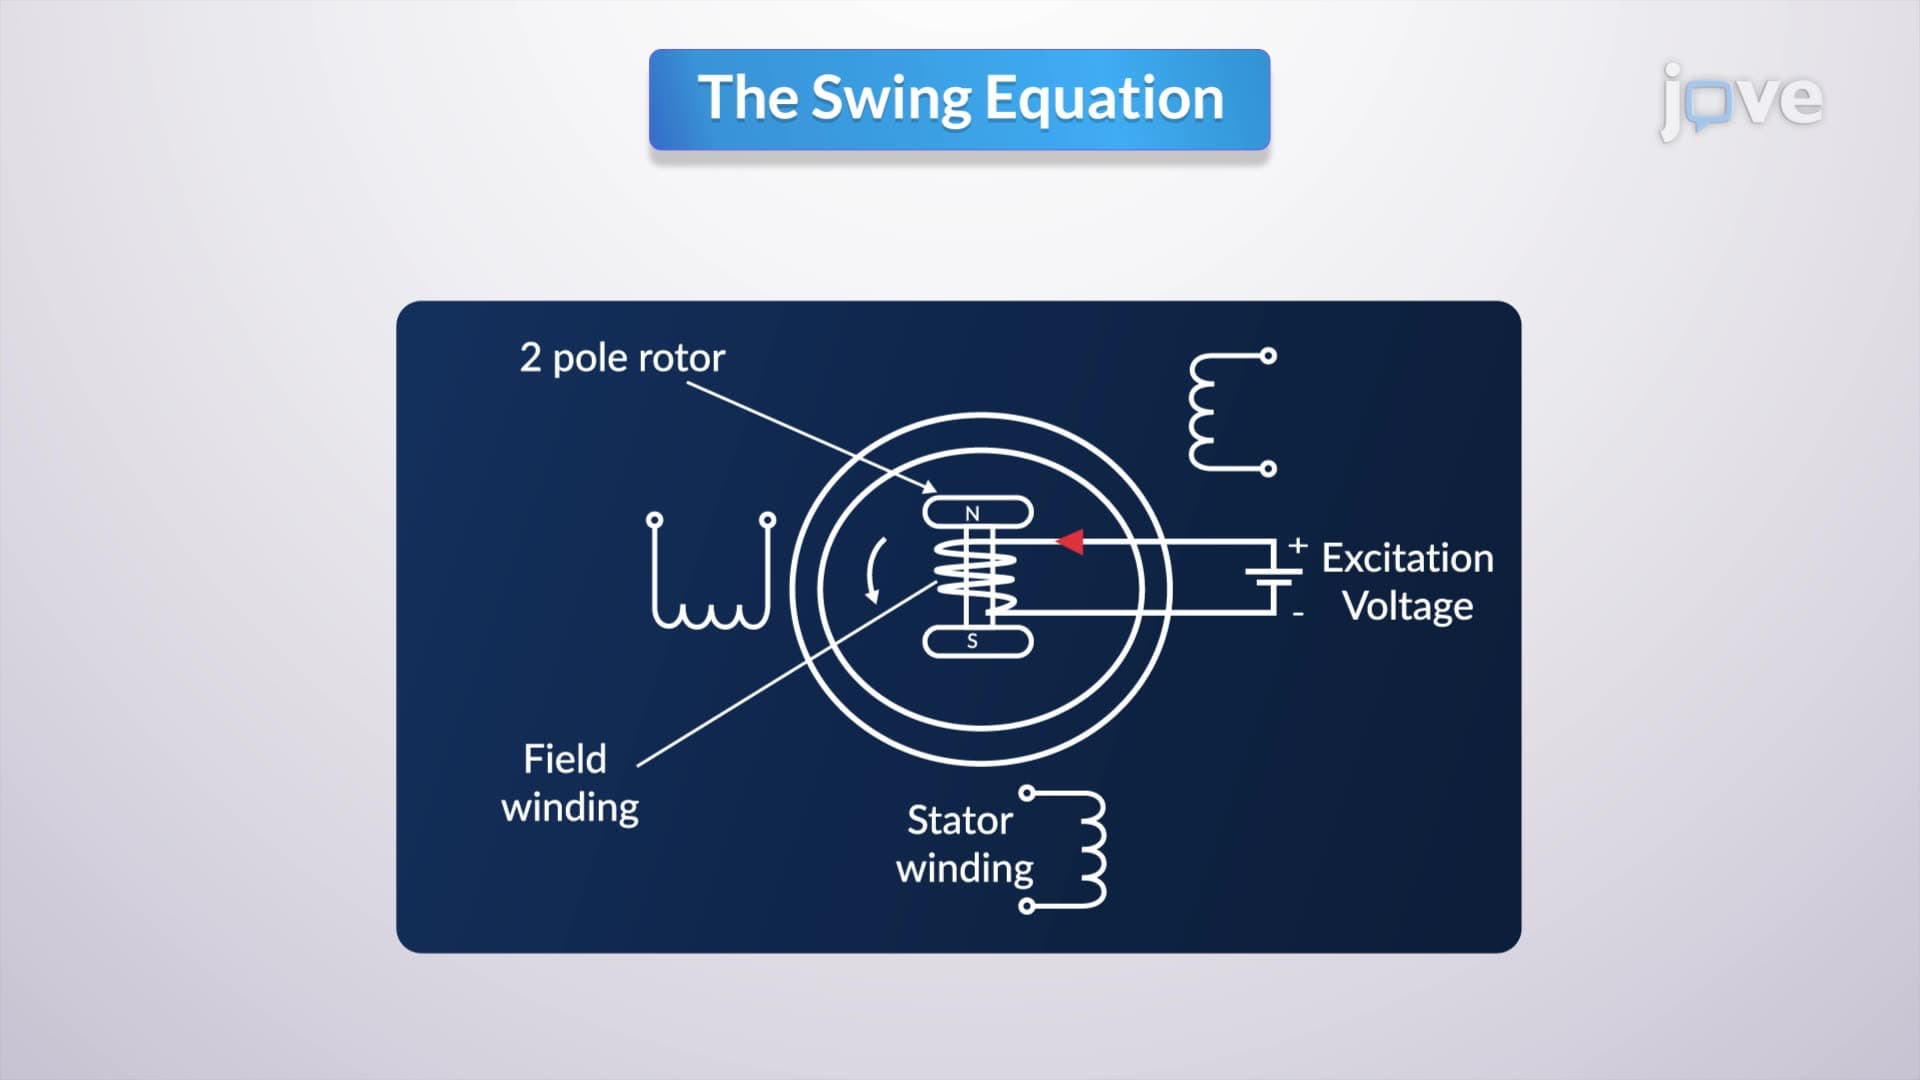
The Swing Equation
In a steady-state operation, the mechanical torque (Τm) supplied to the generator is balanced by the electrical torque (Τe)...
 01:14
Stability of structures
 01:09
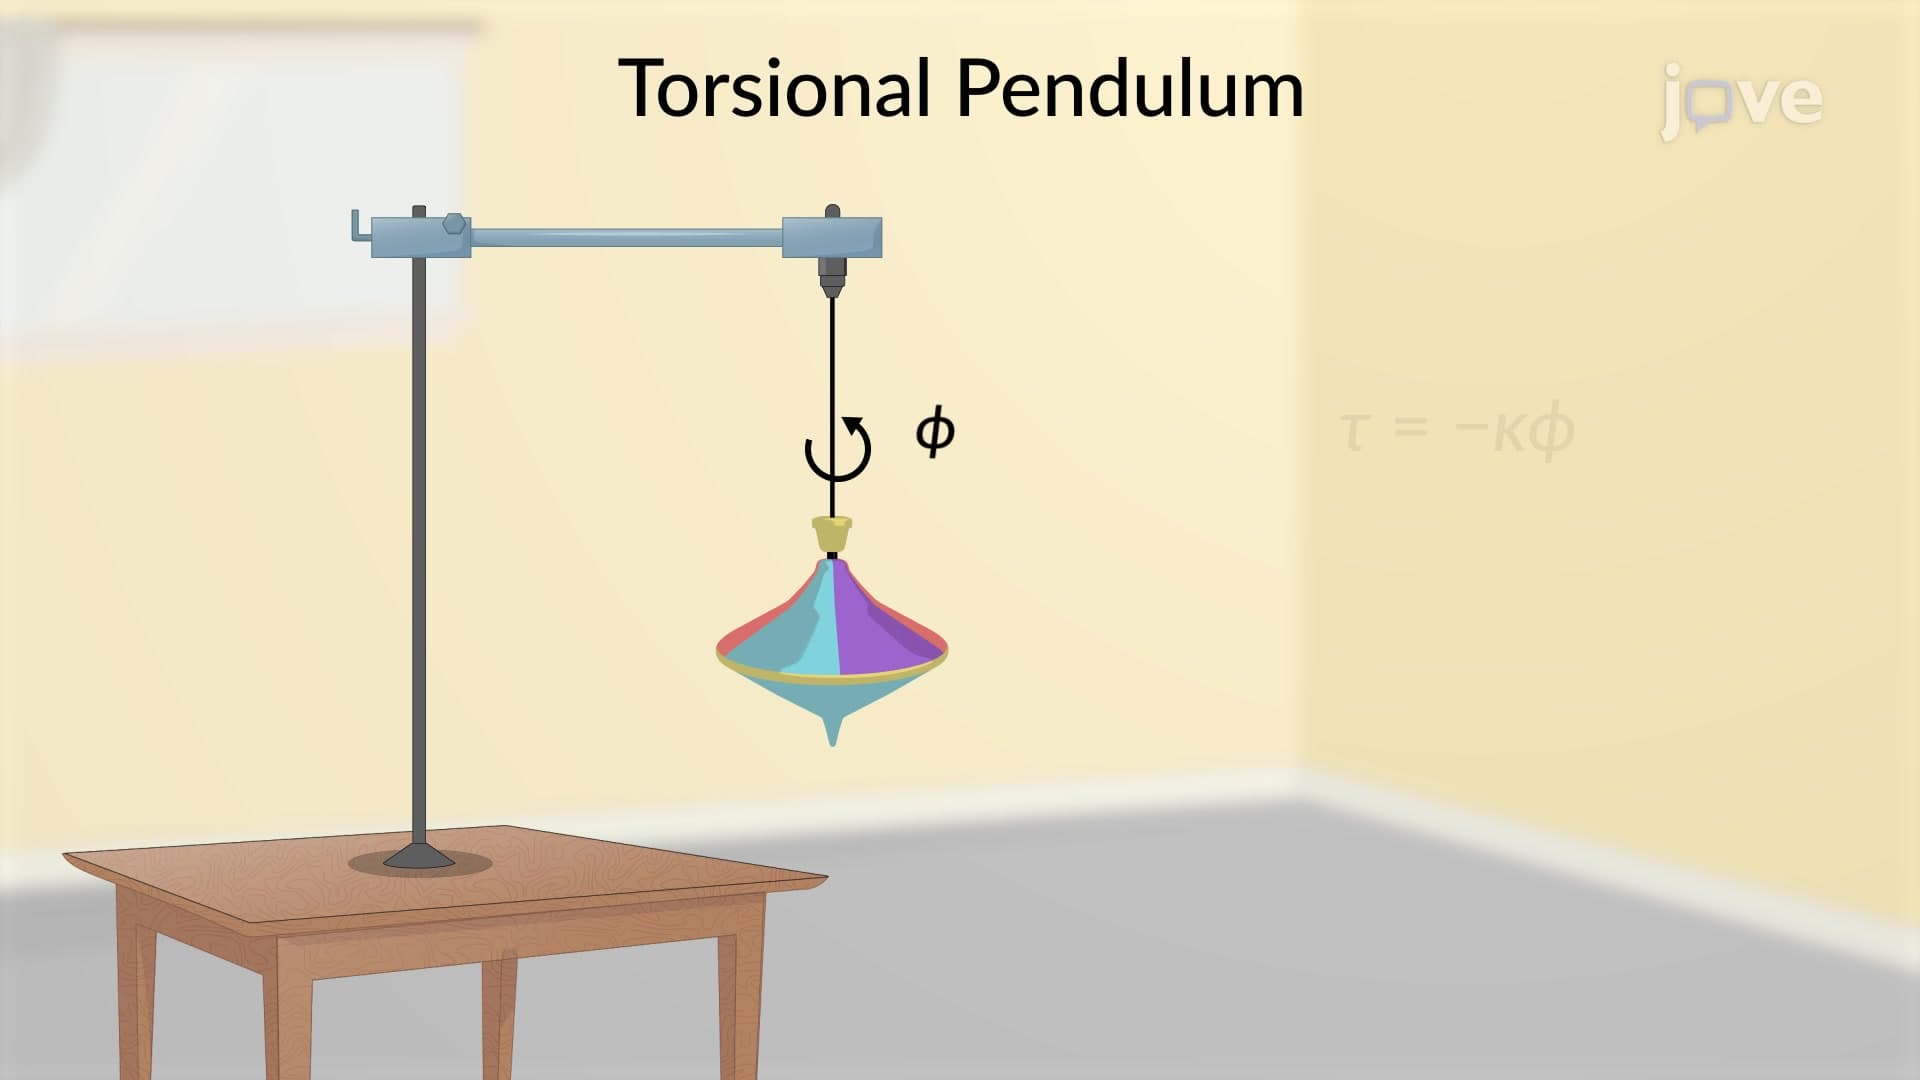
Torsional Pendulum
As long as the rigid body's angular displacement is small, its oscillation can be modeled as a linear angular oscillation. The amplitude of the oscillation is an angle. The role of mass is played...
 01:06
Physical Pendulum
When dealing with complicated systems, the mass moment of inertia is an important parameter, as it...
 01:26
PD Controller: Design
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...