Fixed-time terminal sliding mode tracking protocol design for high-order multiagent systems with directed communication topology
Related Experiment Video
Updated: Dec 27, 2025
A Protocol for Real-time 3D Single Particle Tracking
Published on: January 3, 2018
1Department of Electrical Engineering, School of Automation, Northwestern Polytechnical University, Xi'an 710072, China.

Abstract:
This paper presents a novel fixed-time consensus tracking protocol for high order multi-agent system (MAS) with directed communication topology. A new distributed observer is proposed such that fixed-time leader's state estimation can be achieved, which overcomes the difficulty arising from asymmetry of communication topology. A series of terminal sliding surfaces are constructed and a singularity-free sliding mode fixed-time tracking protocol is developed. It is proved that the proposed tracking protocol achieves fixed-time consensus tracking. Particularly, we can obtain the controller gain from the pre-specified time, which helps to tune the gain in accordance with consensus time requirement. Moreover, a less conservative convergence time bound estimation is attained. Simulation examples demonstrate the effectiveness of the presented scheme.

Related Concept Videos
 01:27
State Space Representation
Consider an RLC circuit, a...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
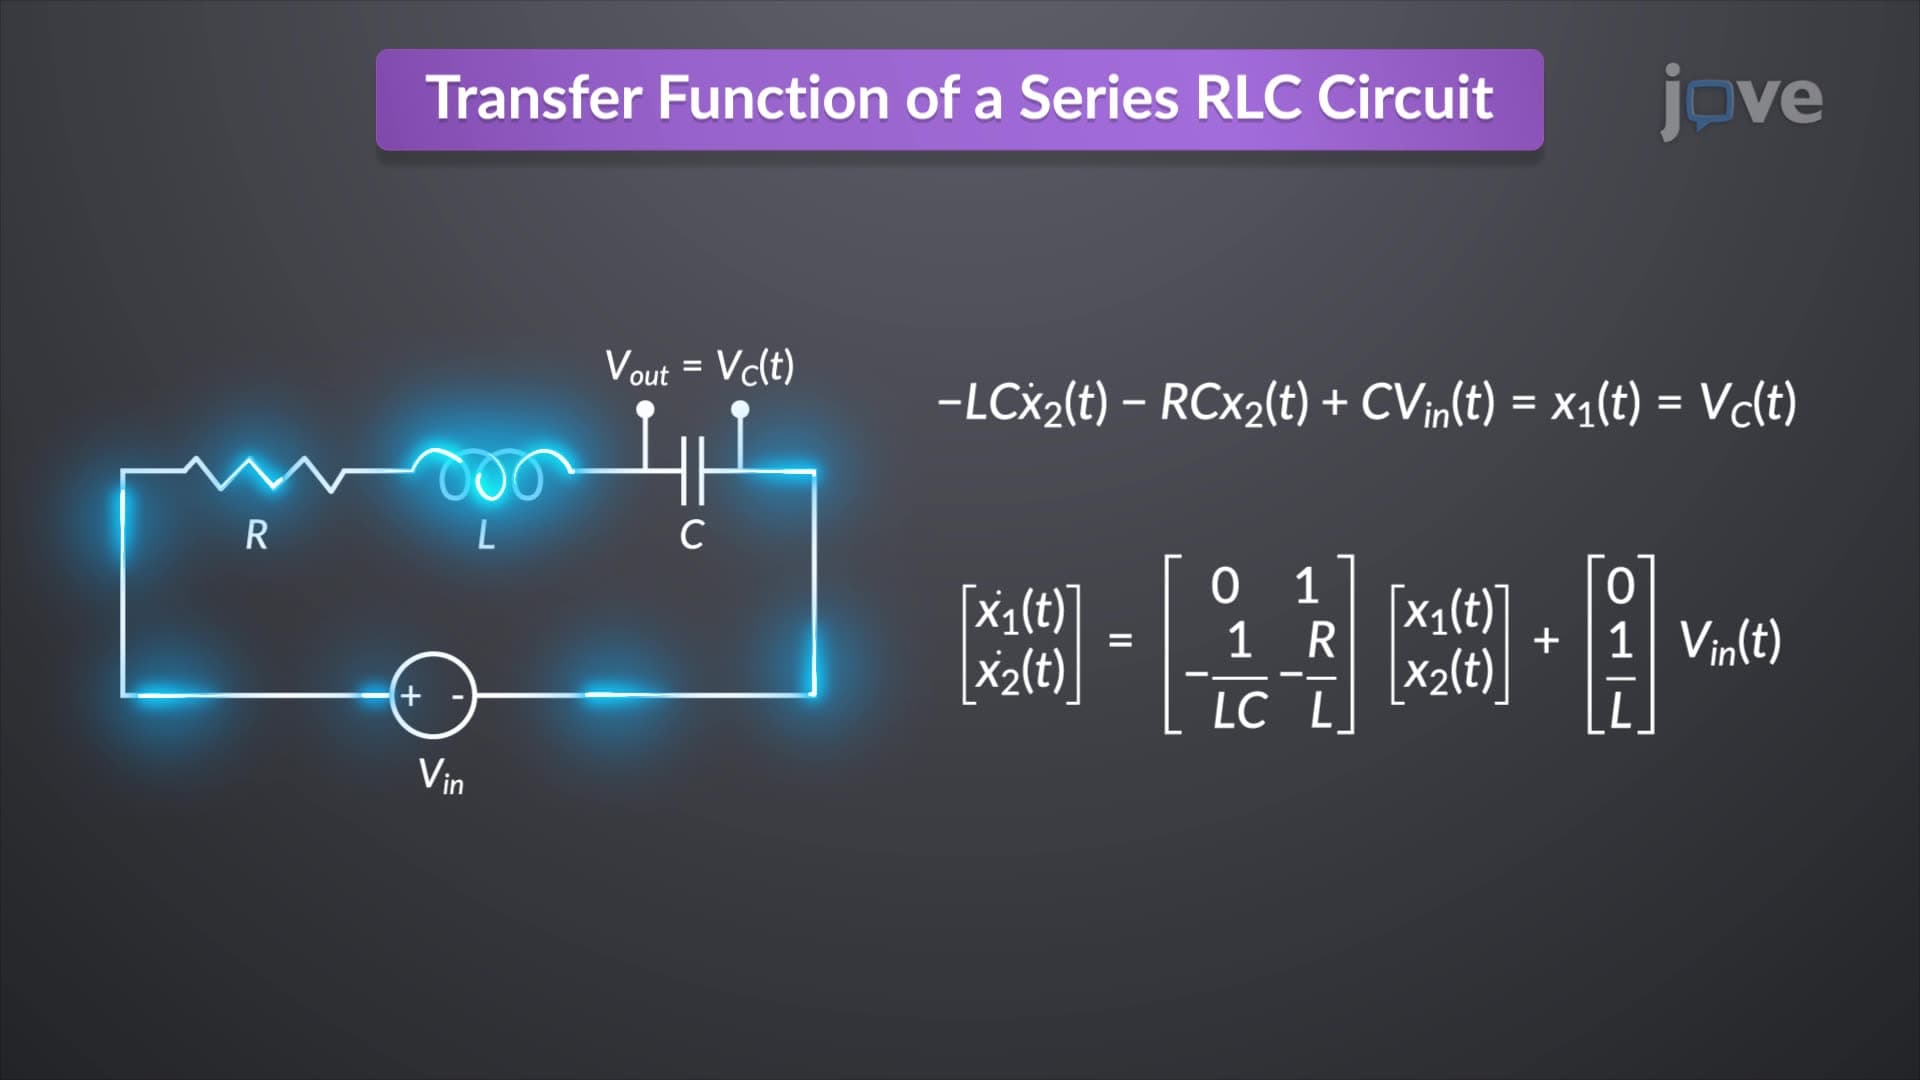 01:23
Transfer Function to State Space
In an RLC...
 01:25
Multimachine Stability
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by:
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:22
Multi-input and Multi-variable systems
In the absence of...