Related Experiment Video
Updated: Dec 27, 2025
Oscillation and Reaction Board Techniques for Estimating Inertial Properties of a Below-knee Prosthesis
Published on: May 8, 2014
An adaptive sliding mode observer for inverted pendulum under mass variation and disturbances with experimental
Ines Jmel1, Habib Dimassi2, Salim Hadj-Said1
1University of Monastir, Ecole Nationale d'Ingénieurs de Monastir, LAS2E, 5019, Monastir, Tunisia.

Abstract:
In this paper, a new robust adaptive estimation approach is designed for the inverted pendulum. The estimation scheme is composed by an auxiliary high gain observer in cascade with an adaptive sliding mode observer. The auxiliary high gain observer is designed to estimate auxiliary outputs in order to solve the dissatisfaction of observer matching condition related to the presence of disturbances. Then, using the estimated auxiliary outputs, the adaptive sliding mode observer is synthesized to estimate conjointly the states, the unknown parameter (the pendulum mass which appears nonlinearly in the dynamics of the pendulum model) and the unknown disturbances. The stability analysis is established using the Lyapunov approach. Numerical simulations are carried out to validate theoretical results. Furthermore, experimental tests are realized using a real pendulum setup (a product of Feedback Instruments) to highlight the good performances of the proposed estimation method in practice.
Related Concept Videos
 01:10
Simple Pendulum
The period of a simple pendulum depends on two factors: its length and the acceleration due to gravity. The period is completely independent of any other factors, such as mass or maximum displacement. For small displacements, a pendulum is...
 01:06
Physical Pendulum
When dealing with complicated systems, the mass moment of inertia is an important parameter, as it...
 01:09
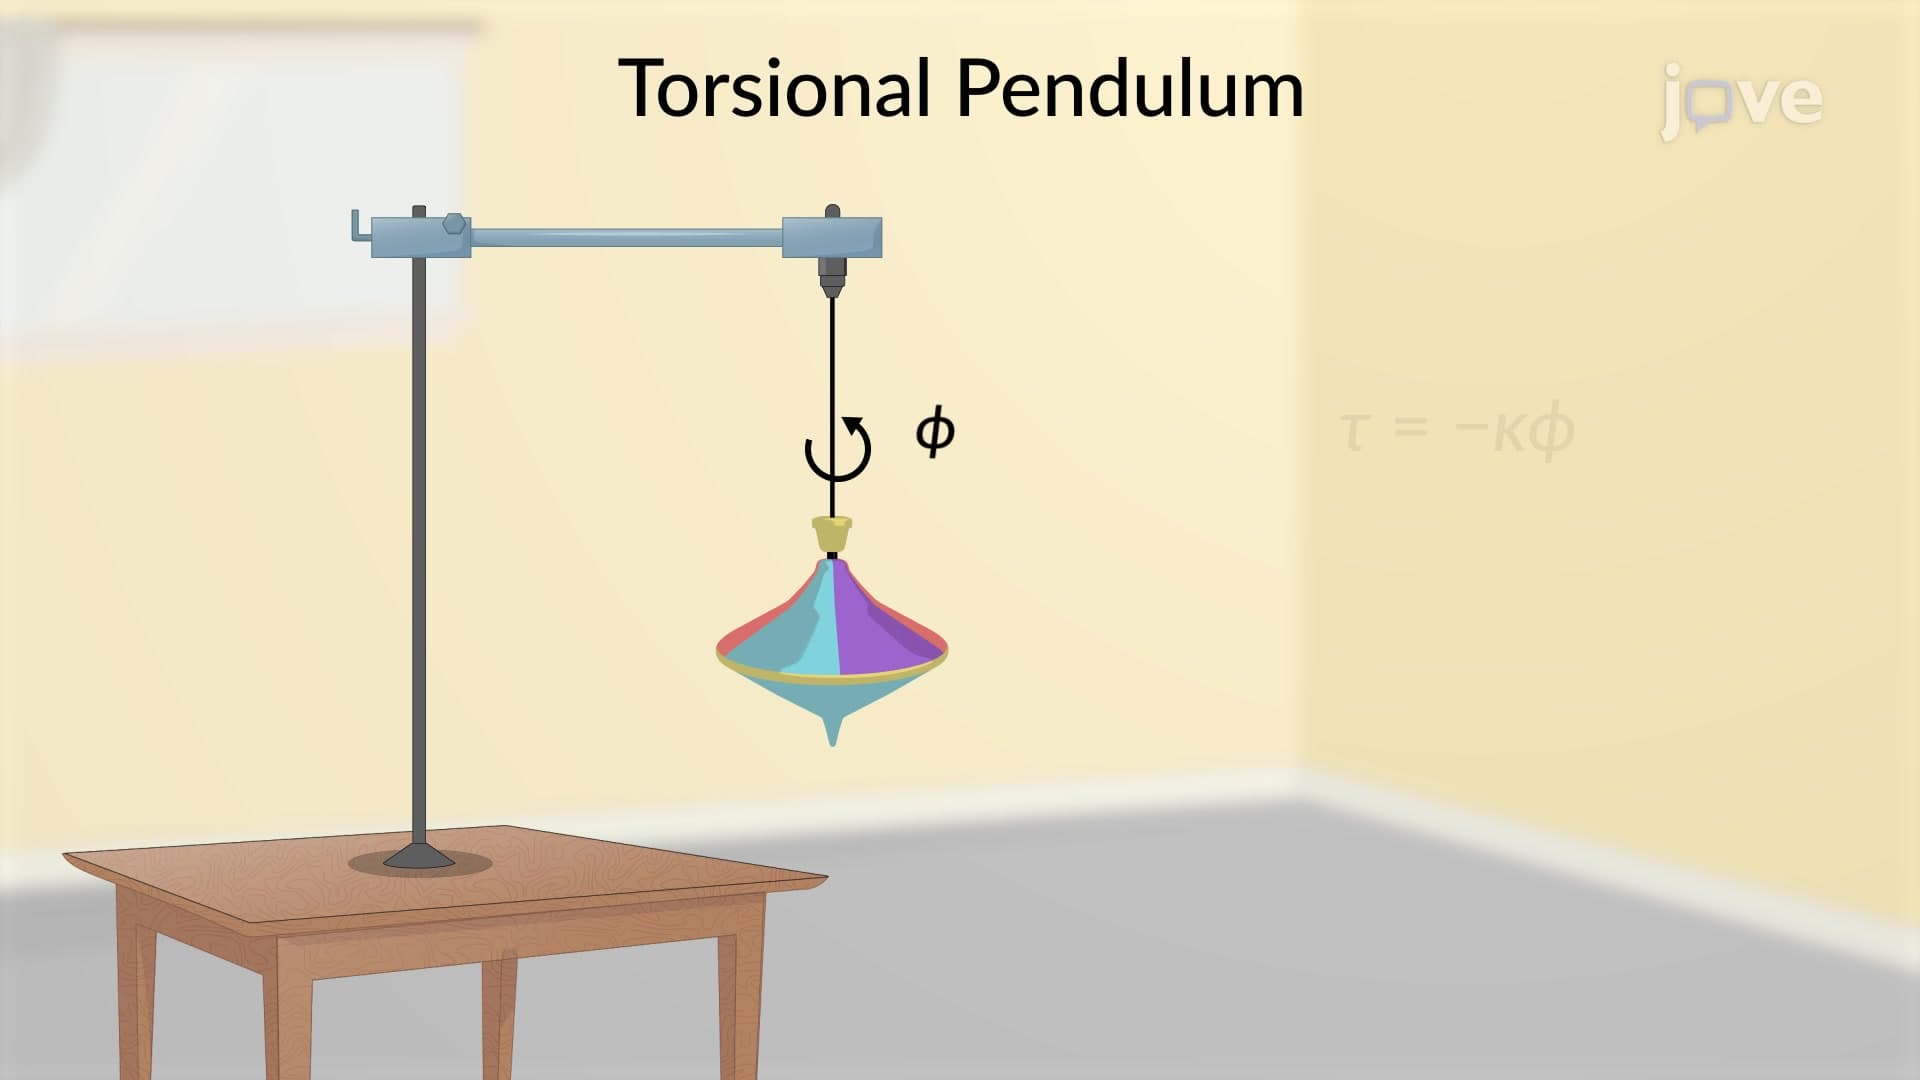
Torsional Pendulum
As long as the rigid body's angular displacement is small, its oscillation can be modeled as a linear angular oscillation. The amplitude of the oscillation is an angle. The role of mass is played...
 01:06
Forced Oscillations
 01:12
Measuring Acceleration Due to Gravity
A simple pendulum can be described as a point mass and a string. Meanwhile, a physical pendulum is any object whose oscillations are similar to a simple pendulum, but cannot be modeled as a point mass on a string because its mass is distributed over a larger area. The behavior of a physical pendulum can be modeled using the principles of...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...