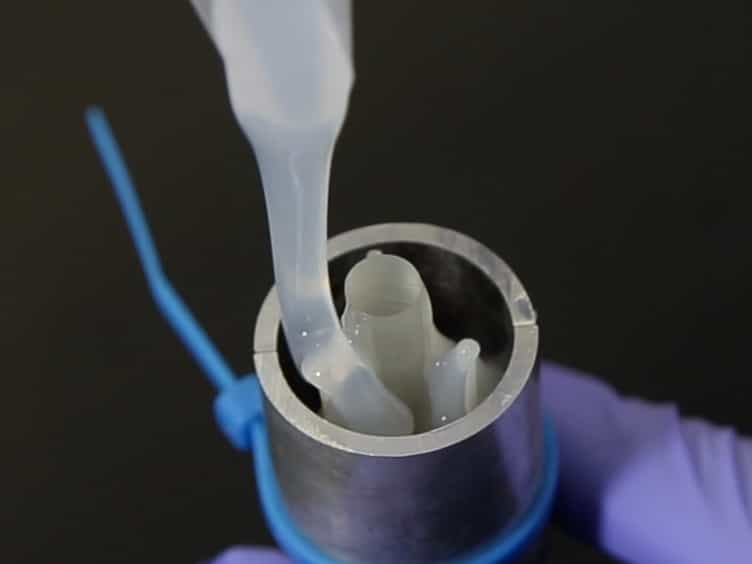
A novel compliant surgical robot: Preliminary design analysis
Related Experiment Video
Updated: Dec 25, 2025
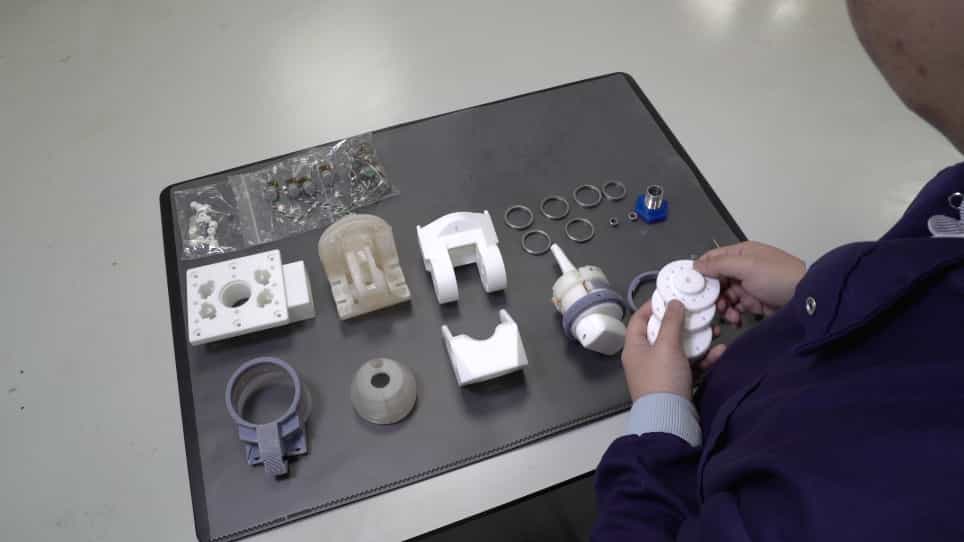
Design and Implementation of a Bespoke Robotic Manipulator for Extra-corporeal Ultrasound
Published on: January 7, 2019
Akim Kapsalyamov1, Shahid Hussain2, Prashant K Jamwal1
1Department of Electrical and Computer Engineering, Nazarbayev University, Astana, Kazakhstan.

Abstract:
A robotic surgical system capable of performing minimally invasive surgery (MIS) is proposed in this paper. Based on the requirements of MIS, a compliant, seven- degrees of freedom (7-DOF) pneumatically actuated mechanism is designed. A remote center of motion (RCM) as a parallelogram mechanism for holding the laparoscopic camera is also developed. The operating workspace of robotic surgical system is determined considering the physical constraints imposed by mechanical joints. The simulation results show that the robotic system meets the design requirement. This research will lay a good foundation for the development of a compliant surgical robot to assist in MIS.