Related Experiment Video
Updated: Dec 24, 2025
A Protocol for Bioinspired Design: A Ground Sampler Based on Sea Urchin Jaws
Published on: April 24, 2016
SBOR: a minimalistic soft self-burrowing-out robot inspired by razor clams
Junliang Julian Tao1, Sichuan Huang, Yong Tang
1Associate Professor, School of Sustainability and the Built Environment, Center for Bio-mediated and Bio-inspired Geotechnics, Arizona State Univ., Tempe, AZ, 85287, United States of America.

Abstract:
We observe that the Atlantic razor clam (Ensis directus) burrows out of sand rapidly by simply extending and contracting its muscular foot. This is notably different from its well-known downward burrowing strategy or the dual-anchor mechanism, where closing/opening of the shell and dilation of the foot are also involved. Inspired by this burrowing-out strategy, we design a simple self-burrowing-out robot (SBOR) consisting of a single segment of fiber-reinforced silicone tube actuator and an external control board. The reinforcing fibers limit the motion of the actuator to axial extension/contraction under inflation/deflation. For an actuator that is vertically buried in the sand, cyclic inflation and deflation naturally drives it out of the sand, mimicking the motion of a razor clam. We characterize the burrowing-out behavior of the actuator by varying the actuation period and the relative density (packing) of the sand. Each burrowing cycle features an initial upward advancement during inflation, followed by a downward slip during deflation, resulting in a net upward stride. During the burrowing-out process, the stride length first increases due to a drop in the overburden pressure, the end pull-out resistance, and the side frictional resistance; the stride length then decreases after the top of the actuator moves out of the sand layer, due to a reduction in the effective length of the actuator. The results also indicate that the average burrowing-out speed decreases with the relative density of the sand and changes with the actuation pressure. We developed a simplified model based on soil mechanics to predict the burrowing-out processes in relatively loose dry sands, and the modeling results match well with the experiment results. From this model, the burrowing-out behavior is readily explained by the asymmetric nature of the resistant forces on the two ends of the actuator and the flowing nature of sand upon yielding. Our findings imply that razor clams leverage the natural stress gradient of sand deposits to burrow upward. Another insight is that in order to burrow downward into the sand, additional symmetry-breaking features such as asymmetric geometry, friction, stress state or external load are needed to increase the resistant force (anchorage) in the upward direction and to reduce the resistant force (drag) in the downward direction.
Related Concept Videos
 01:22
Mechanical Systems
 01:14
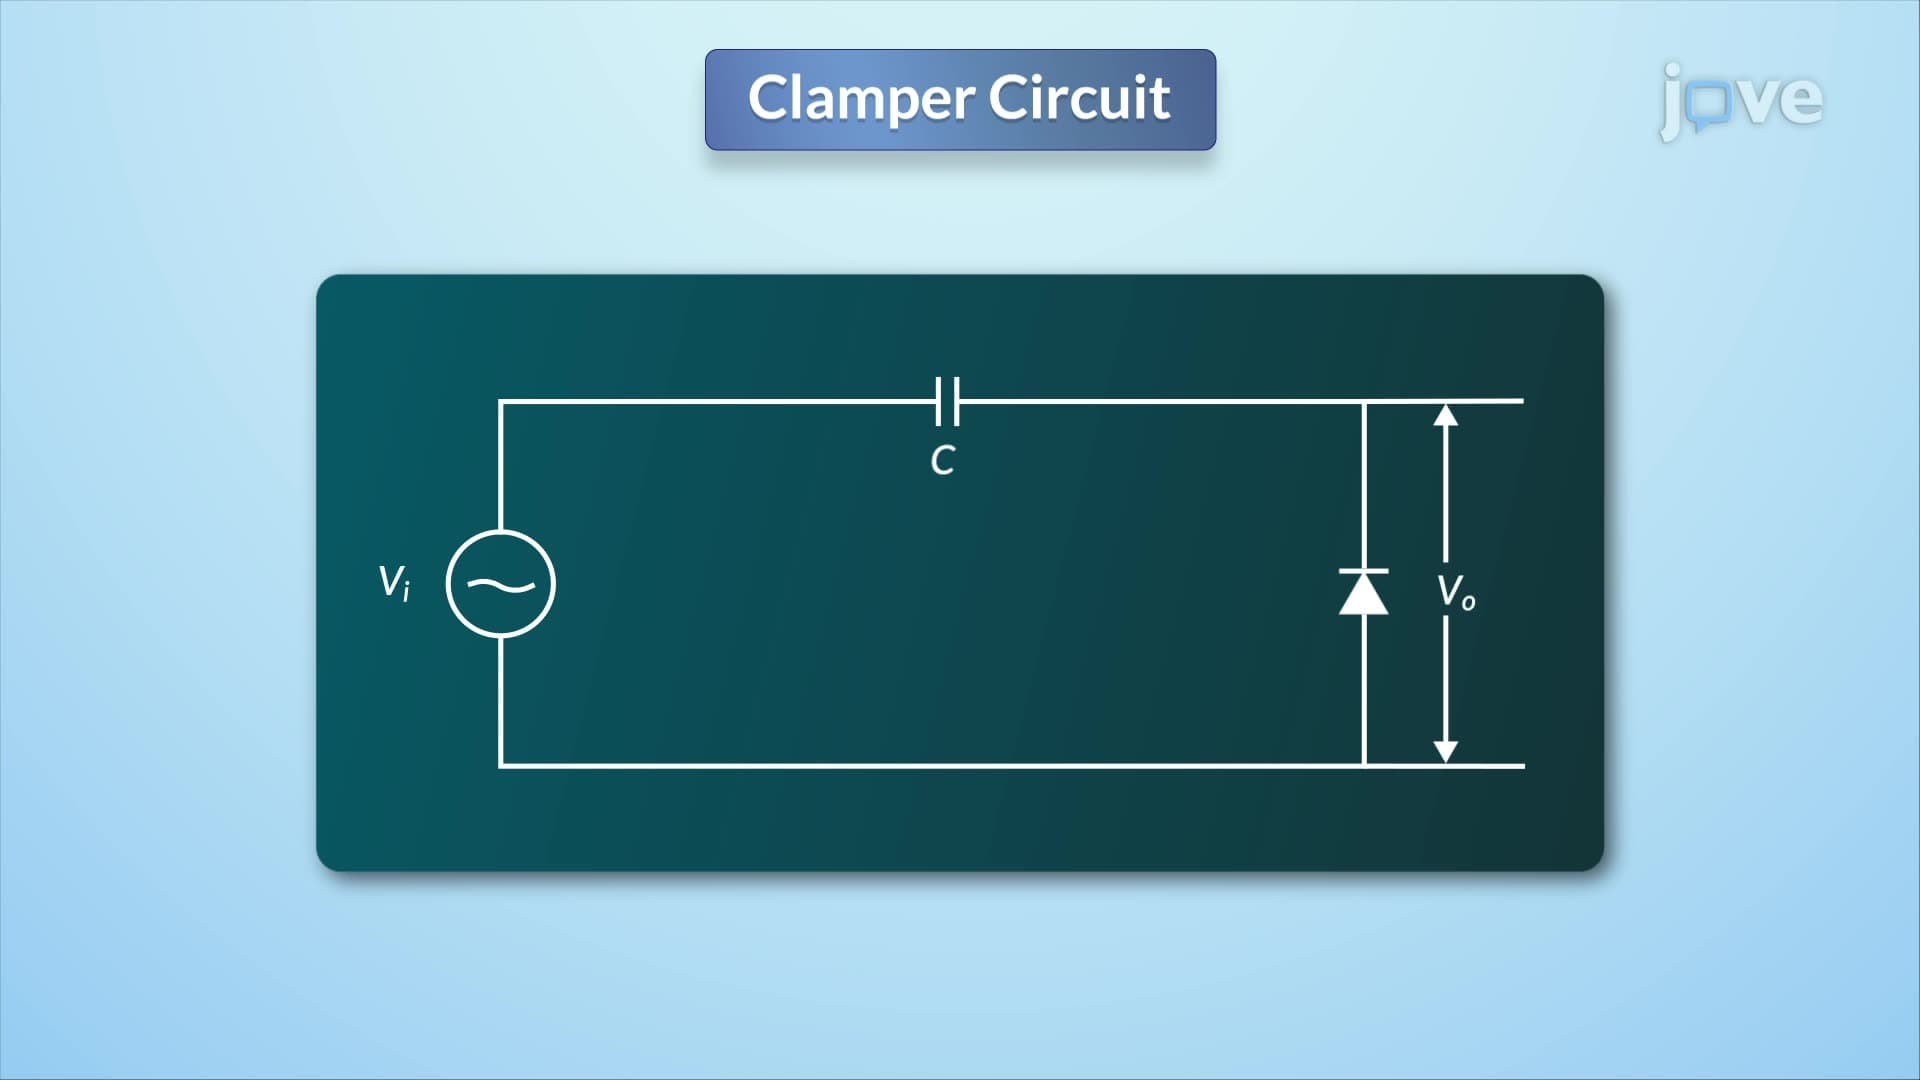
Clamper Circuit
Within this circuit, the diode's orientation prompts the capacitor to charge up to the level of the most negative peak of the input signal. Upon reaching this state, the diode ceases to...
 01:39
Mechanism of Filopodia Formation
Their main function is to guide migrating cells during normal tissue morphogenesis or cancer metastasis by recognizing and making initial contacts with the extracellular matrix. However, they can also act as stationary cell anchors or help to establish communication...
 01:08
Brick Cutting Techniques
Cut bricks are categorized by size. Bricks cut to half their original length are called half-bats, while those cut to three-fourths their length are known as three-fourth bats.
Special types of...
 01:31
Mechanism of Lamellipodia Formation
 01:30
Ferrocement