Related Experiment Video
Updated: Dec 24, 2025
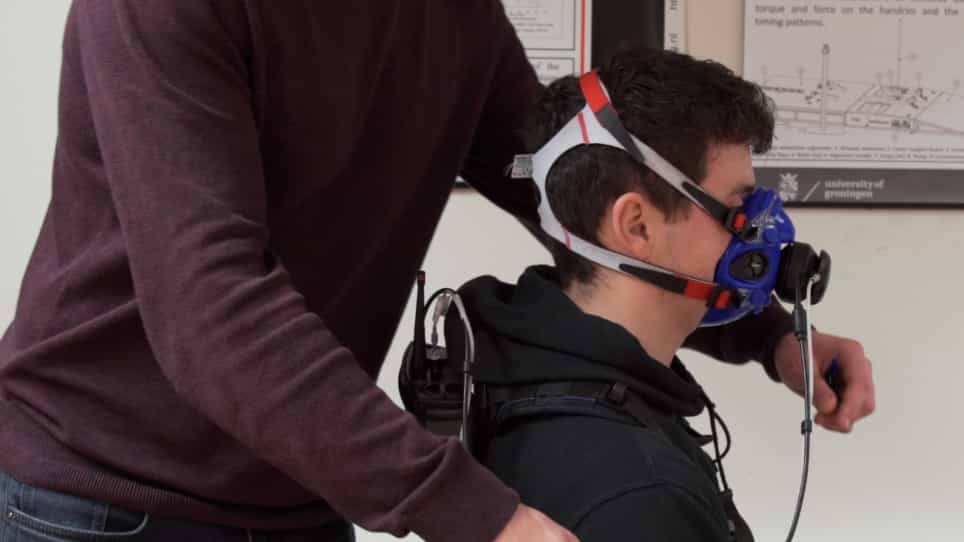

Determining and Controlling External Power Output During Regular Handrim Wheelchair Propulsion
Published on: February 5, 2020
Manual wheelchair propulsion cost across different components and configurations during straight and turning
Stephen Sprigle1, Morris Huang2
1Rehabilitation Engineering and Applied Research Lab, Georgia Institute of Technology, Atlanta, GA, USA.

Aim:
Maneuvering manual wheelchairs is defined by changes in momentum. The amount of effort required to maneuver a wheelchair is dependent on many factors, some of which reflect the design and configuration of the wheelchair.
Objective:
The objective of this study was to measure the work required to propel a manual wheelchair configured with three weight distributions, three drive wheels and four casters.
Methods:
A novel wheelchair-propelling robot was used as the test platform to measure work while traversing two surfaces using three different maneuvers which were defined to highlight different kinetic energies and energy loss mechanisms.
Results:
Overall, propulsion cost decreased with an increase in load on the drive wheels. Pneumatic drive wheels exhibited lower propulsion costs compared to a solid tire. Two casters, a 4″ dia × 1.5″ and a 5″ dia × 1″, exhibited better overall performance compared to 5″ dia × 1.5″ solid and 6″ dia × 1″ pneumatic casters.
Discussion:
The results indicate that drive wheel load and types of drive wheels and casters impact propulsion cost and their influences differ across maneuvers and surfaces. The approach is well suited to assess equivalency in components and configurations. Assessment of performance equivalency would empower clinicians and users with important knowledge when selecting components.
More Related Videos


Related Concept Videos
 01:17
Rolling Resistance: Problem Solving
 01:16
Equation of Motion: General Plane motion - Problem Solving
The friction between the roller and the ground is characterized by two coefficients. The static friction coefficient is 0.15, while the kinetic friction coefficient is 0.1. These values are crucial in understanding the interaction between...
 01:17
Dynamics Of Circular Motion: Applications
 01:24
Normal and Tangetial Components: Problem Solving
 01:09
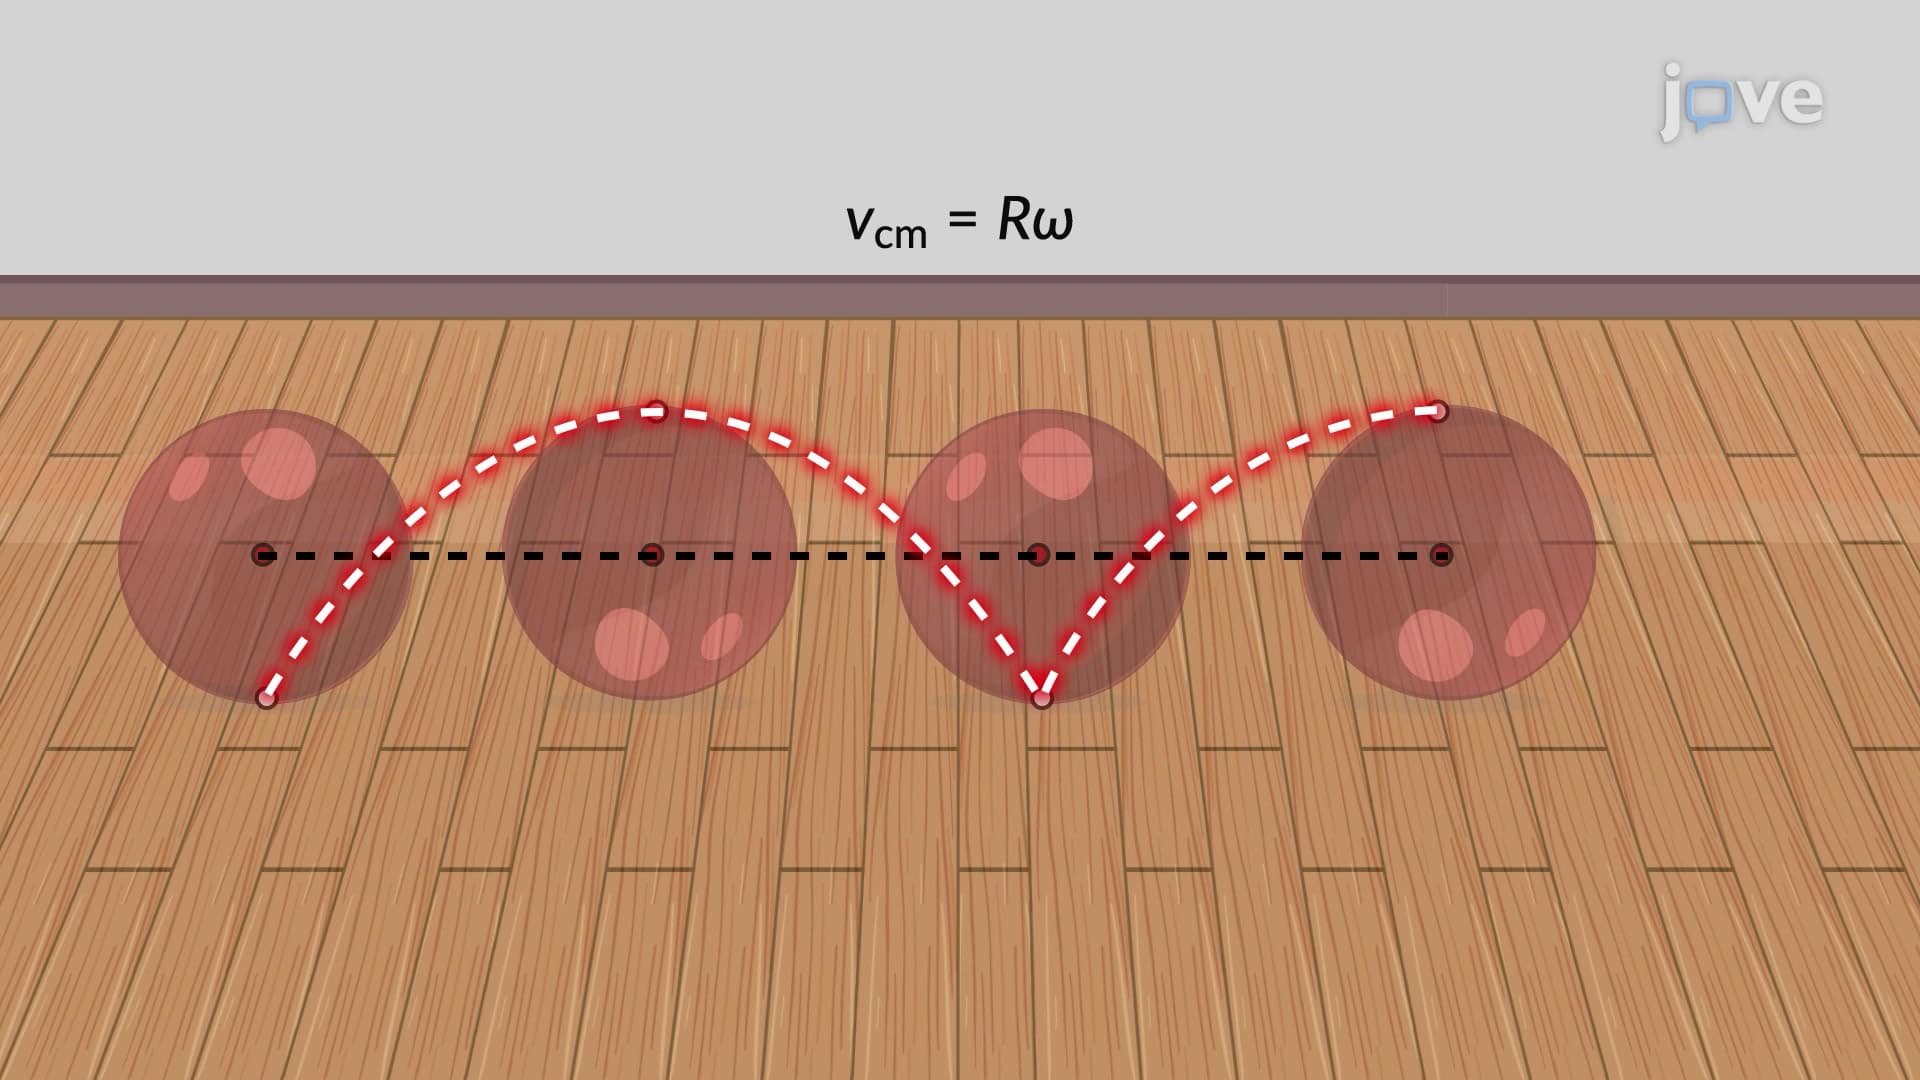
Rolling Without Slipping
 01:20
Instantaneous Center of Zero Velocity
To analyze this, consider two points on the wheel: point A and point B. The absolute velocity of point B can be expressed as the vector sum of the absolute velocity of point A and the relative velocity of point B with respect to point A. To simplify this analysis,...