Related Experiment Video
Updated: Dec 15, 2025

WheelCon: A Wheel Control-Based Gaming Platform for Studying Human Sensorimotor Control
Published on: August 15, 2020
Decentralized adaptive quantized feedback tracking of a class of uncertain interconnected lower-triangular nonlinear
1School of Electrical and Electronics Engineering, Chung-Ang University, 84 Heukseok-Ro, Dongjak-Gu, Seoul, 06974, South Korea.

Abstract:
A decentralized adaptive quantized feedback tracking problem is addressed for uncertain interconnected nonlinear systems in a strict-feedback form. All local state variables for each subsystem are quantized by a hysteresis quantizer. Different from the existing results in the literature, the primary contribution of this study is to establish an adaptive control design and stability analysis strategy using the local quantized state variables in the decentralized tracking field. A novel recursive design approach is presented to deal with unmatched interconnections and nonlinearities in the quantized feedback control framework, without any restrictions on virtual control laws. The total closed-loop stability is analyzed by deriving some technical lemmas on the boundedness of quantization error signals.
More Related Videos
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
 11:54
Real-Time Proxy-Control of Re-Parameterized Peripheral Signals using a Close-Loop Interface
Published on: May 8, 2021
Related Concept Videos
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
 01:23
Root Loci for Positive-Feedback Systems
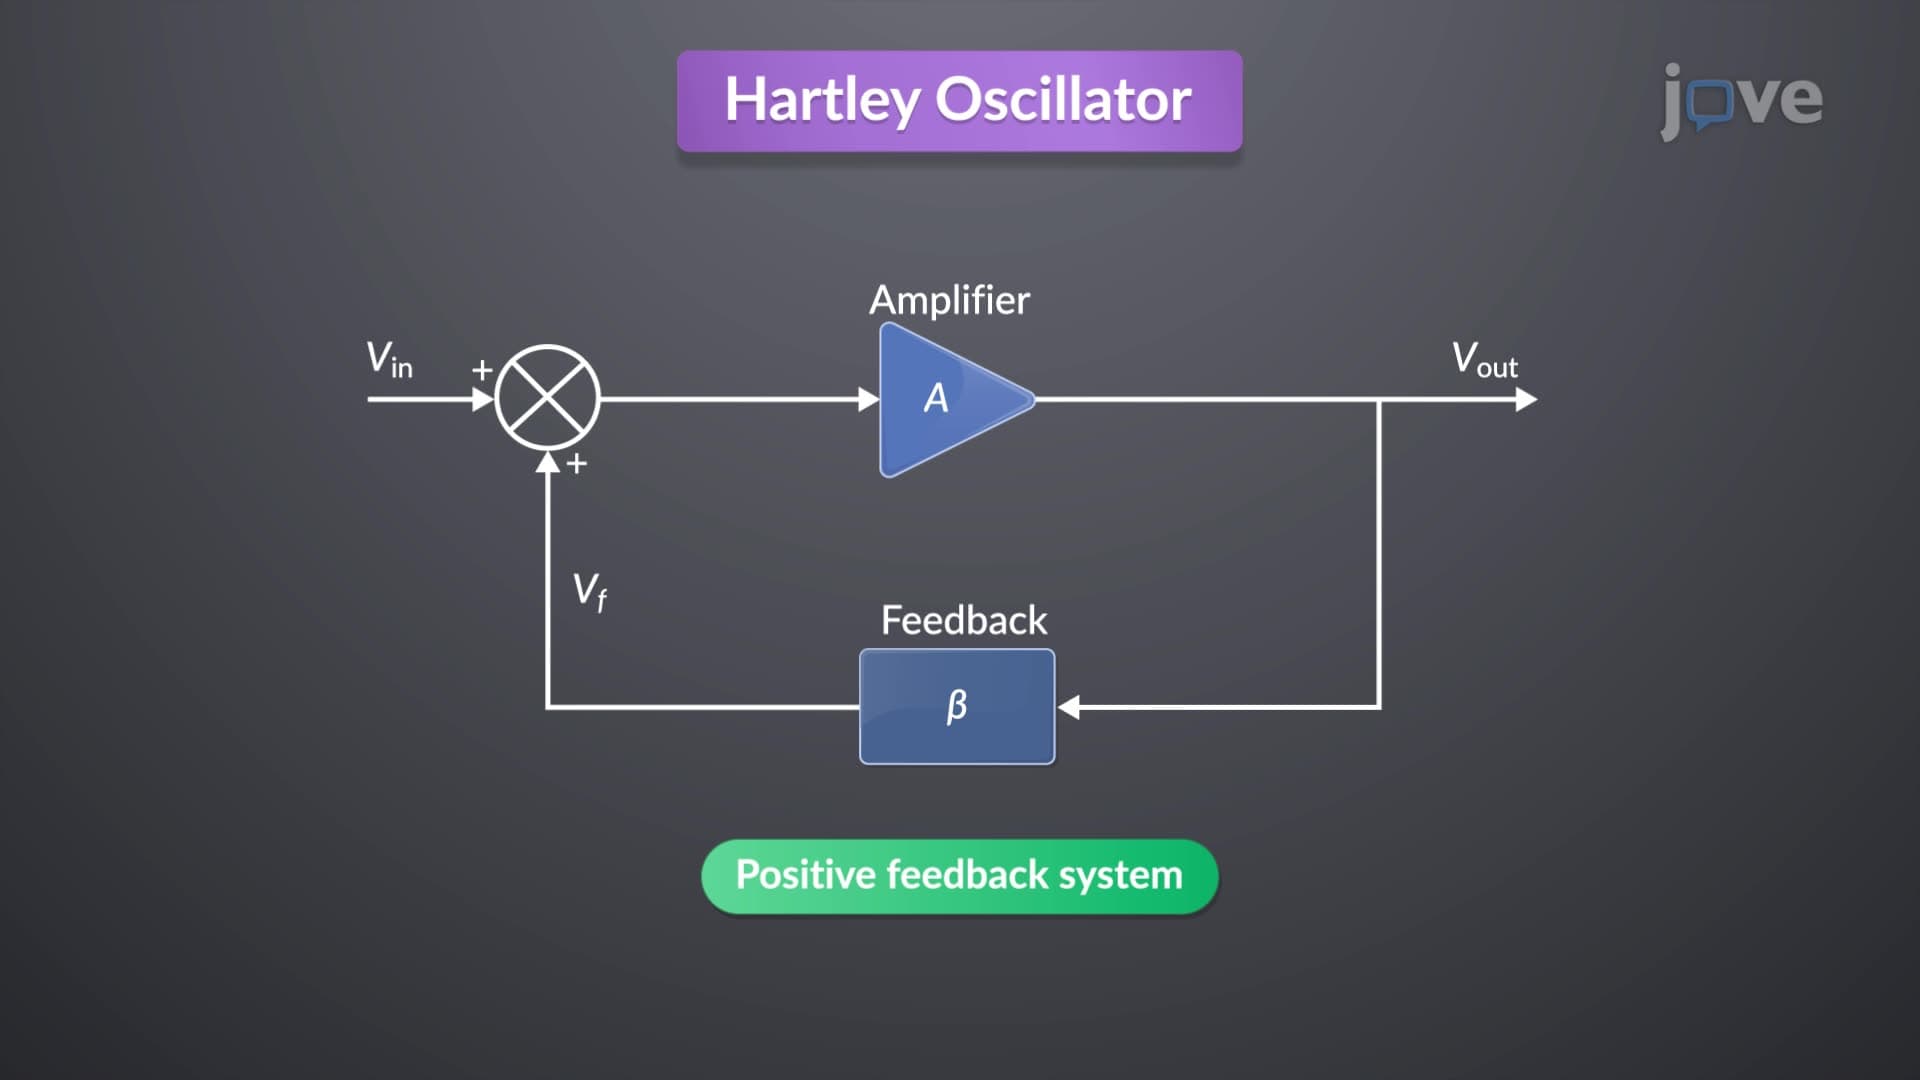
The construction rules for the root locus in positive feedback systems are similar to those in...