Related Experiment Video
Updated: Dec 15, 2025
The Muscle Cuff Regenerative Peripheral Nerve Interface for the Amplification of Intact Peripheral Nerve Signals
Published on: January 13, 2022
Using Person-Specific Muscle Fatigue Characteristics to Optimally Allocate Control in a Hybrid Exoskeleton -
Xuefeng Bao1, Vahidreza Molazadeh2, Albert Dodson3
1Department of Biomedical Engineering, Case Western Reserve University, Cleveland, OH, USA.

Abstract:
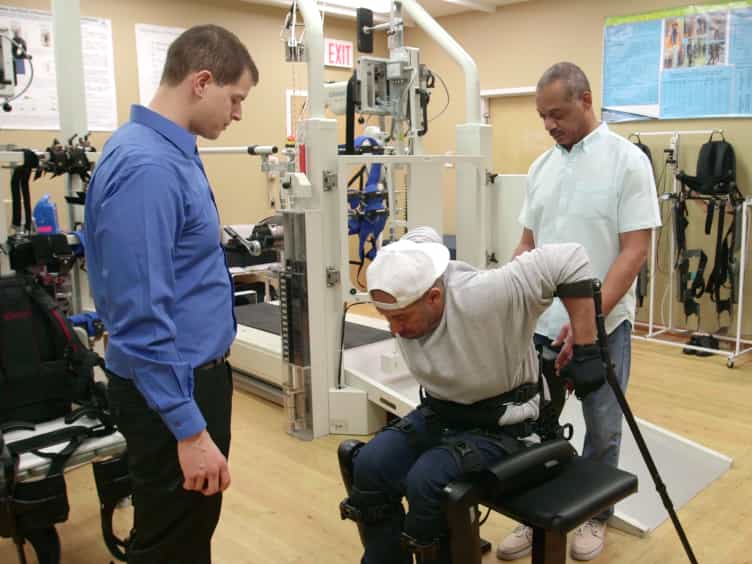
Currently controllers that dynamically modulate functional electrical stimulation (FES) and a powered exoskeleton at the same time during standing-up movements are largely unavailable. In this paper, an optimal shared control of FES and a powered exoskeleton is designed to perform sitting to standing (STS) movements with a hybrid exoskeleton. A hierarchical control design is proposed to overcome the difficulties associated with developing an optimal real-time solution for the highly nonlinear and uncertain STS control model with multiple degrees of freedom. A higher-level robust nonlinear control design is derived to exponentially track a time-invariant desired STS movement profile. Then, a lower-level optimal control allocator is designed to distribute control between FES and the knee electric motors. The allocator uses a person's muscle fatigue and recovery dynamics to determine an optimal ratio between the FES-elicited knee torque and the exoskeleton assist. Experiments were performed on human participants, two persons without disability and one person with spinal cord injury (SCI), to validate the feedback controller and the optimal torque allocator. The muscles of the participant with SCI did not actively contract to FES, so he was only tested with the powered exoskeleton controller. The experimental results show that the proposed hierarchical control design is a promising method to effect shared control in a hybrid exoskeleton.