Related Experiment Video
Updated: Dec 13, 2025


Experimental Methods to Study Human Postural Control
Published on: September 11, 2019
Analysis of Stiffness and Energy Consumption of Nonlinear Elastic Joint Legged Robot
Dongliang Chen1, Jindong Zhang1, Xutao Weng1
1College of Mechanical and Electrical Engineering, Harbin Engineering University, Harbin 150001, China.

Abstract:
In order to reduce the energy consumption of the legged robot in walking, this paper designs a kind of nonlinear elastic joint from the flexible variable-stiffness joint based on the mammal walking on the limb and optimizes the leg structure of the legged robot. The motor is rigidly connected to the articulated lever. When the lever is accelerated or decelerated, the elastic unit is introduced. The system can be considered as a special variable-rate elastic system. This paper will study it from theory and simulation experiments. Based on the dynamic analysis, a functional relationship between the output torque and the torsion spring stiffness and between the energy consumption and the torsion spring stiffness was established. By finding the extremum, the two optimum torsional spring stiffness that can minimize the required output average torque and the energy consumed during one cycle of motion were deduced. The results show that using this design in a reasonable position can effectively reduce the energy consumption of the system and can achieve up to a 50% reduction in energy consumption.


Related Concept Videos
 01:18
Indeterminate Structure
 01:13
Kinetic Energy for a Rigid Body
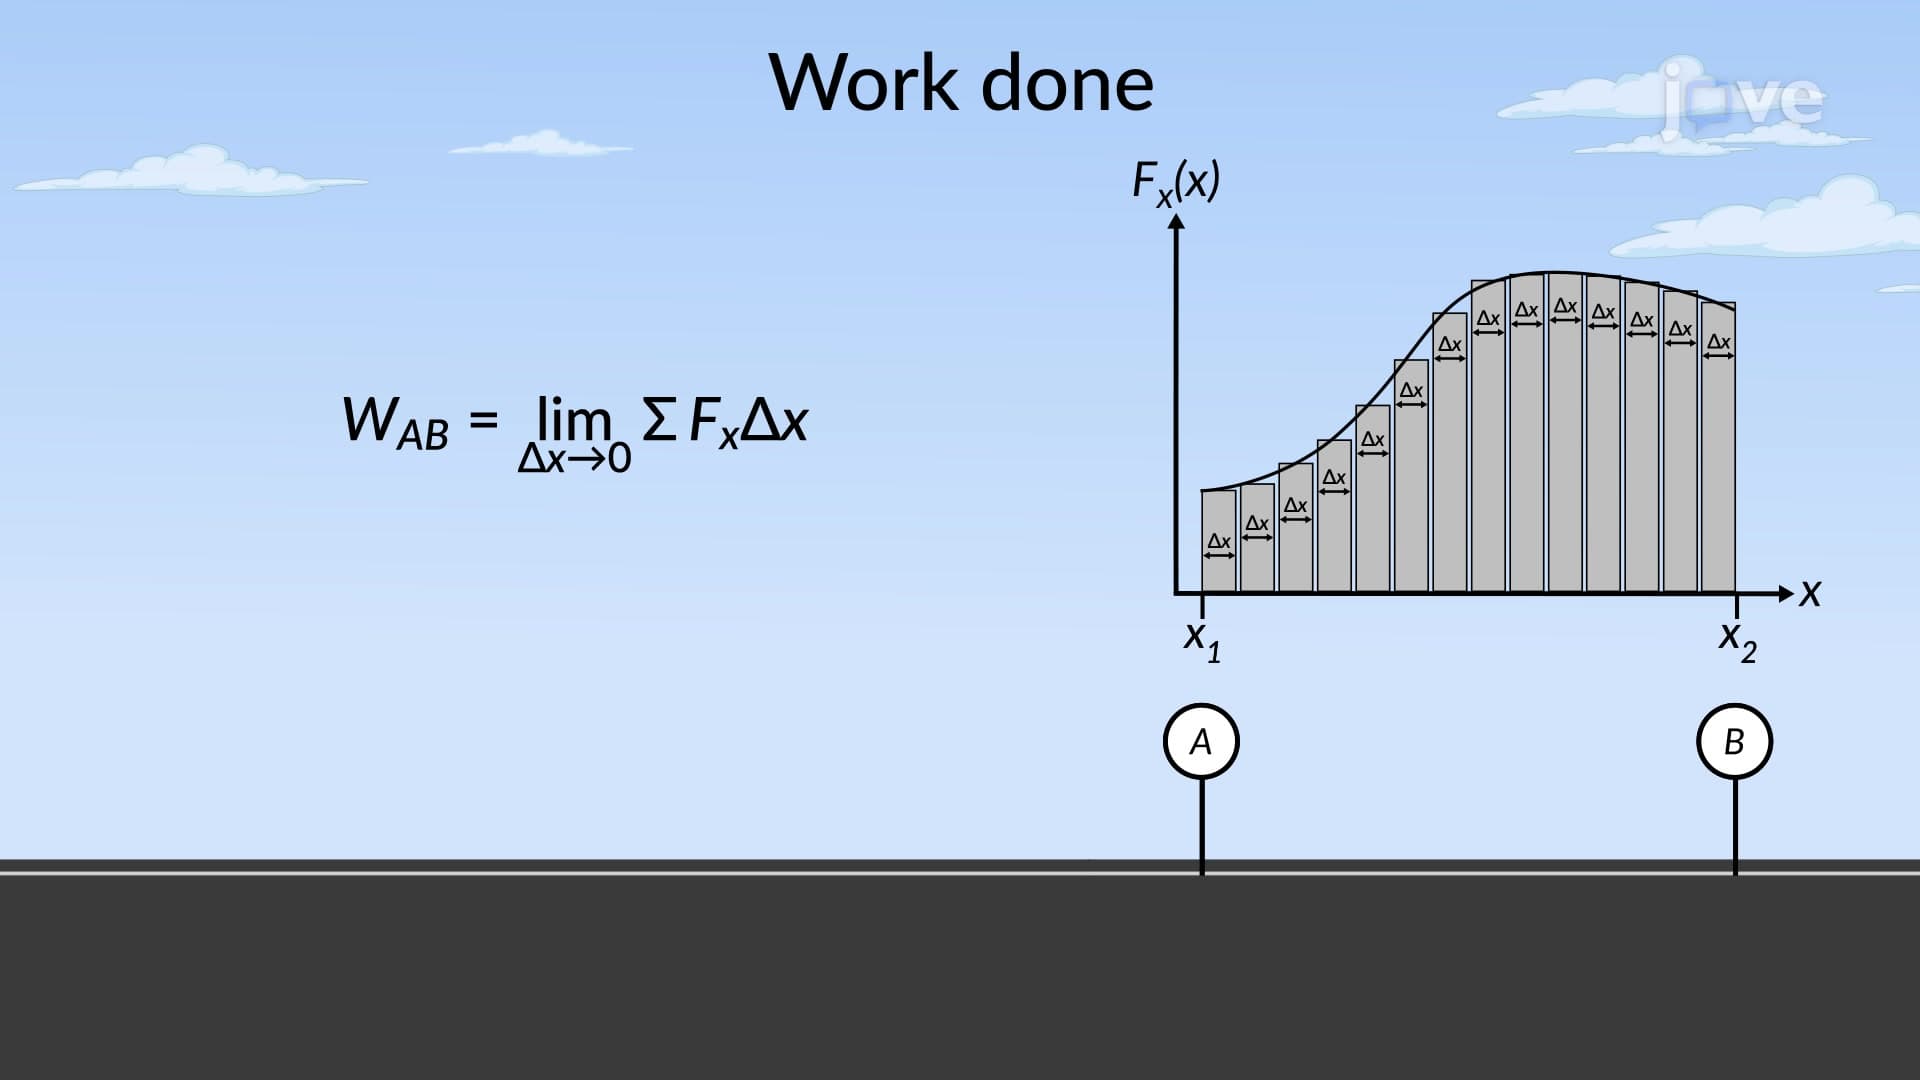 01:10
Work and Energy for Variable Forces
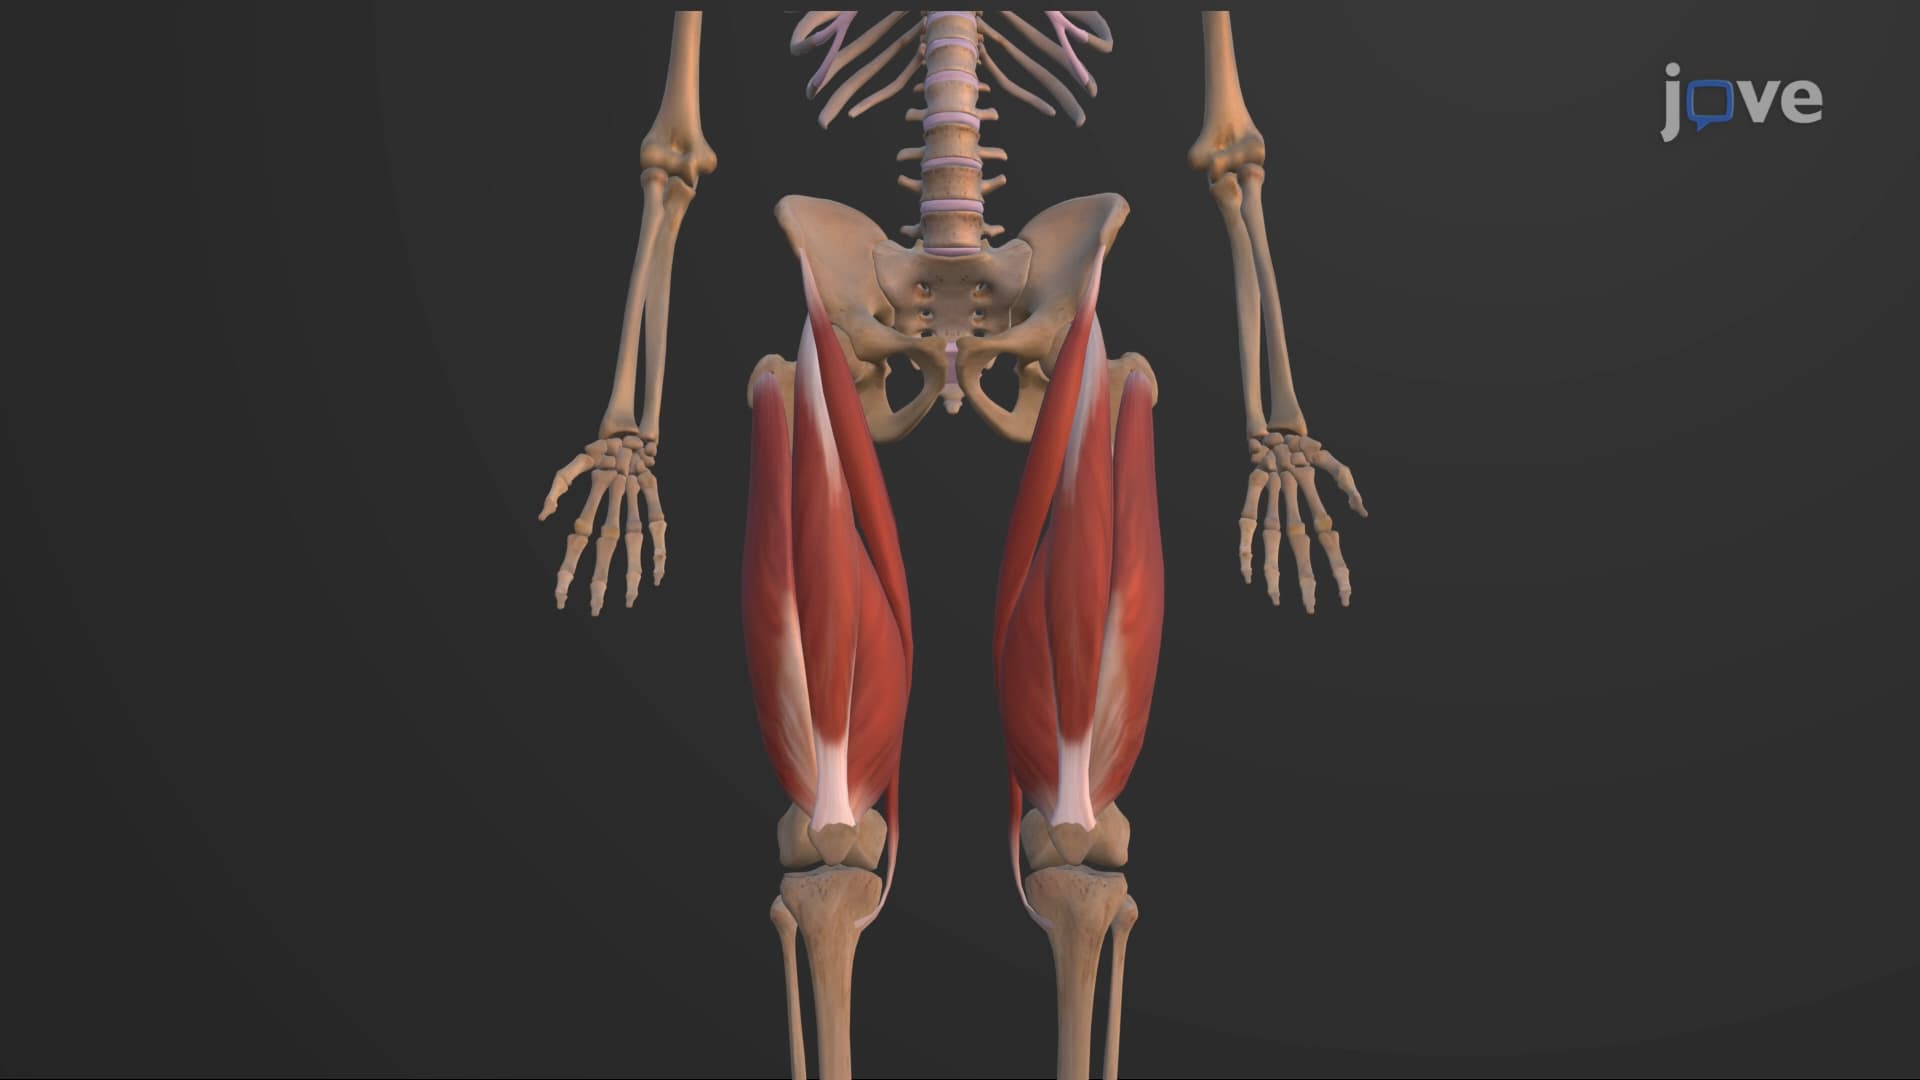 01:23
Muscles that Move the Leg
Anterior Compartment
The quadriceps femoris, the most visible muscle of the anterior compartment, is integral for leg extension and thigh flexion. It is formed by merging four distinct muscles — the vastus lateralis, vastus medialis, vastus intermedius, and rectus femoris. The quadriceps tendon, a shared tendon of the four quadriceps muscles, is affixed...
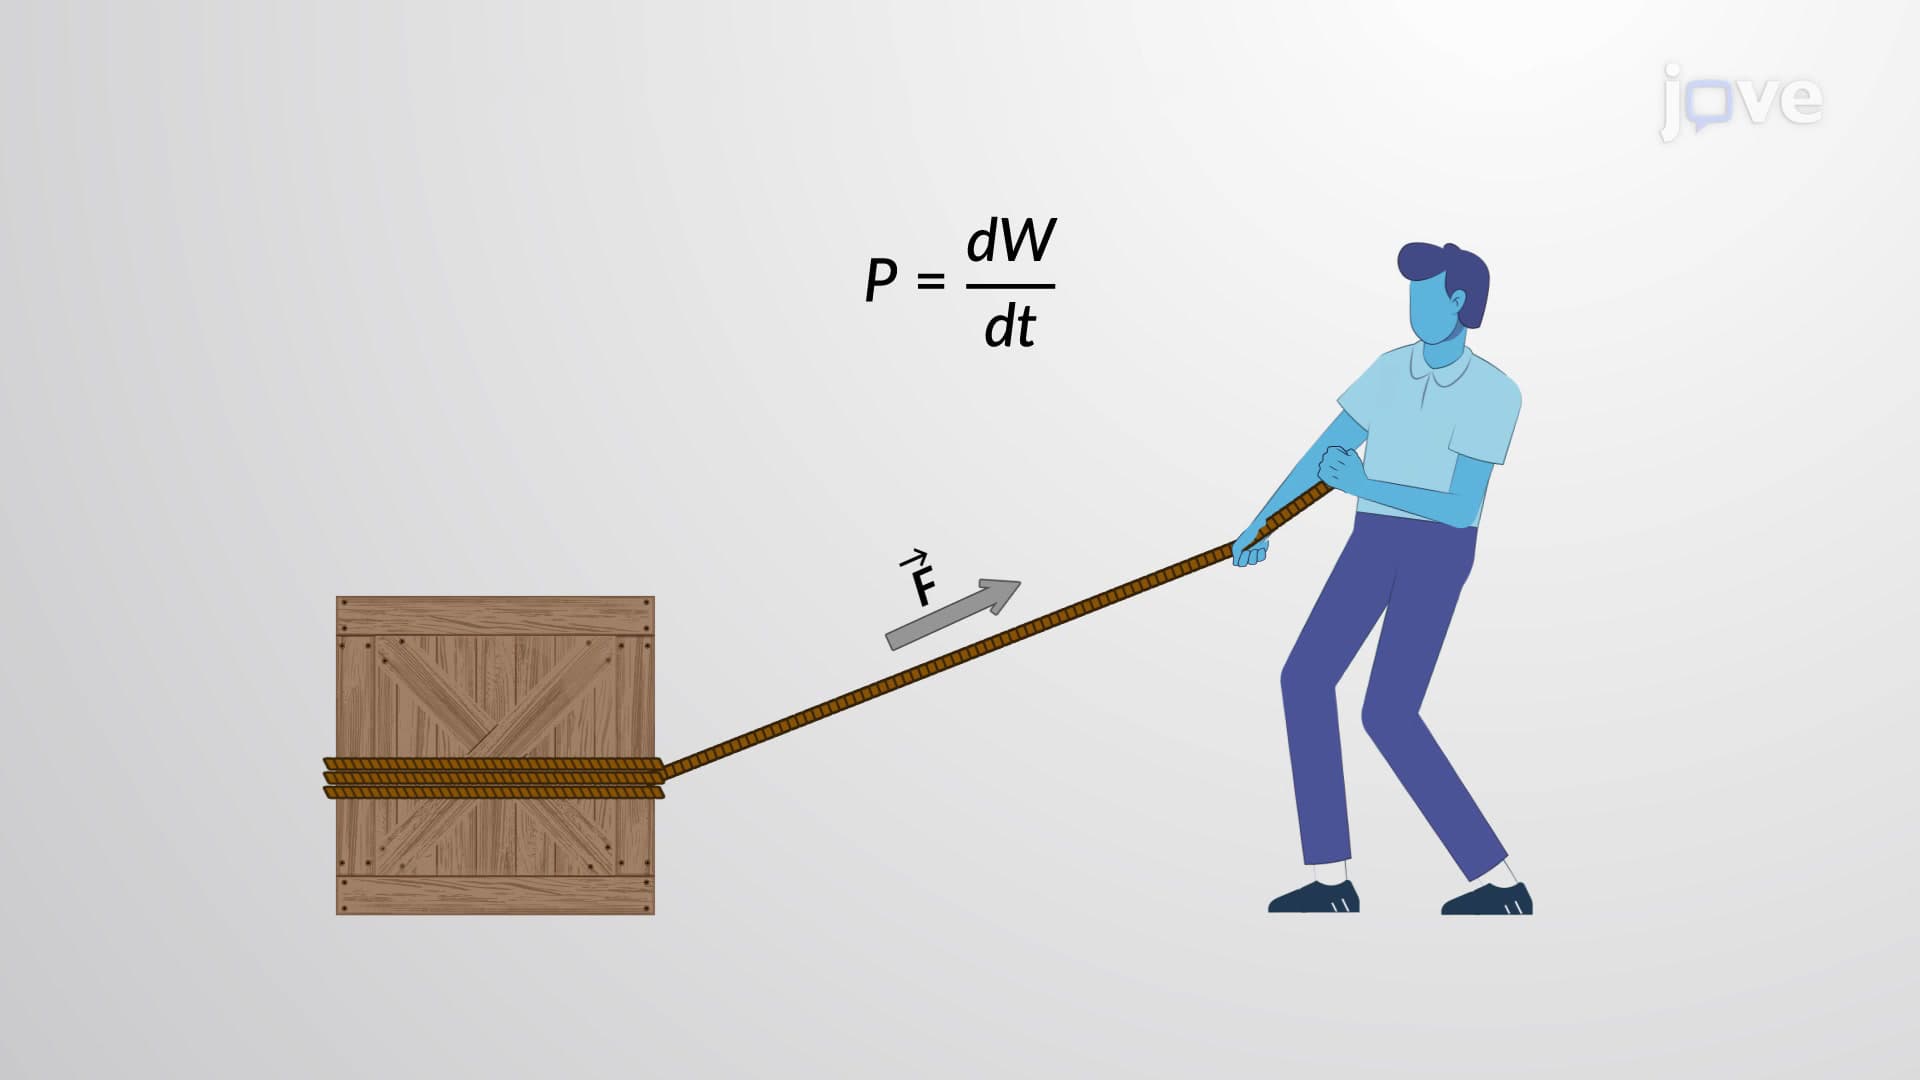 00:57
Power Expended by a Constant Force
 01:05
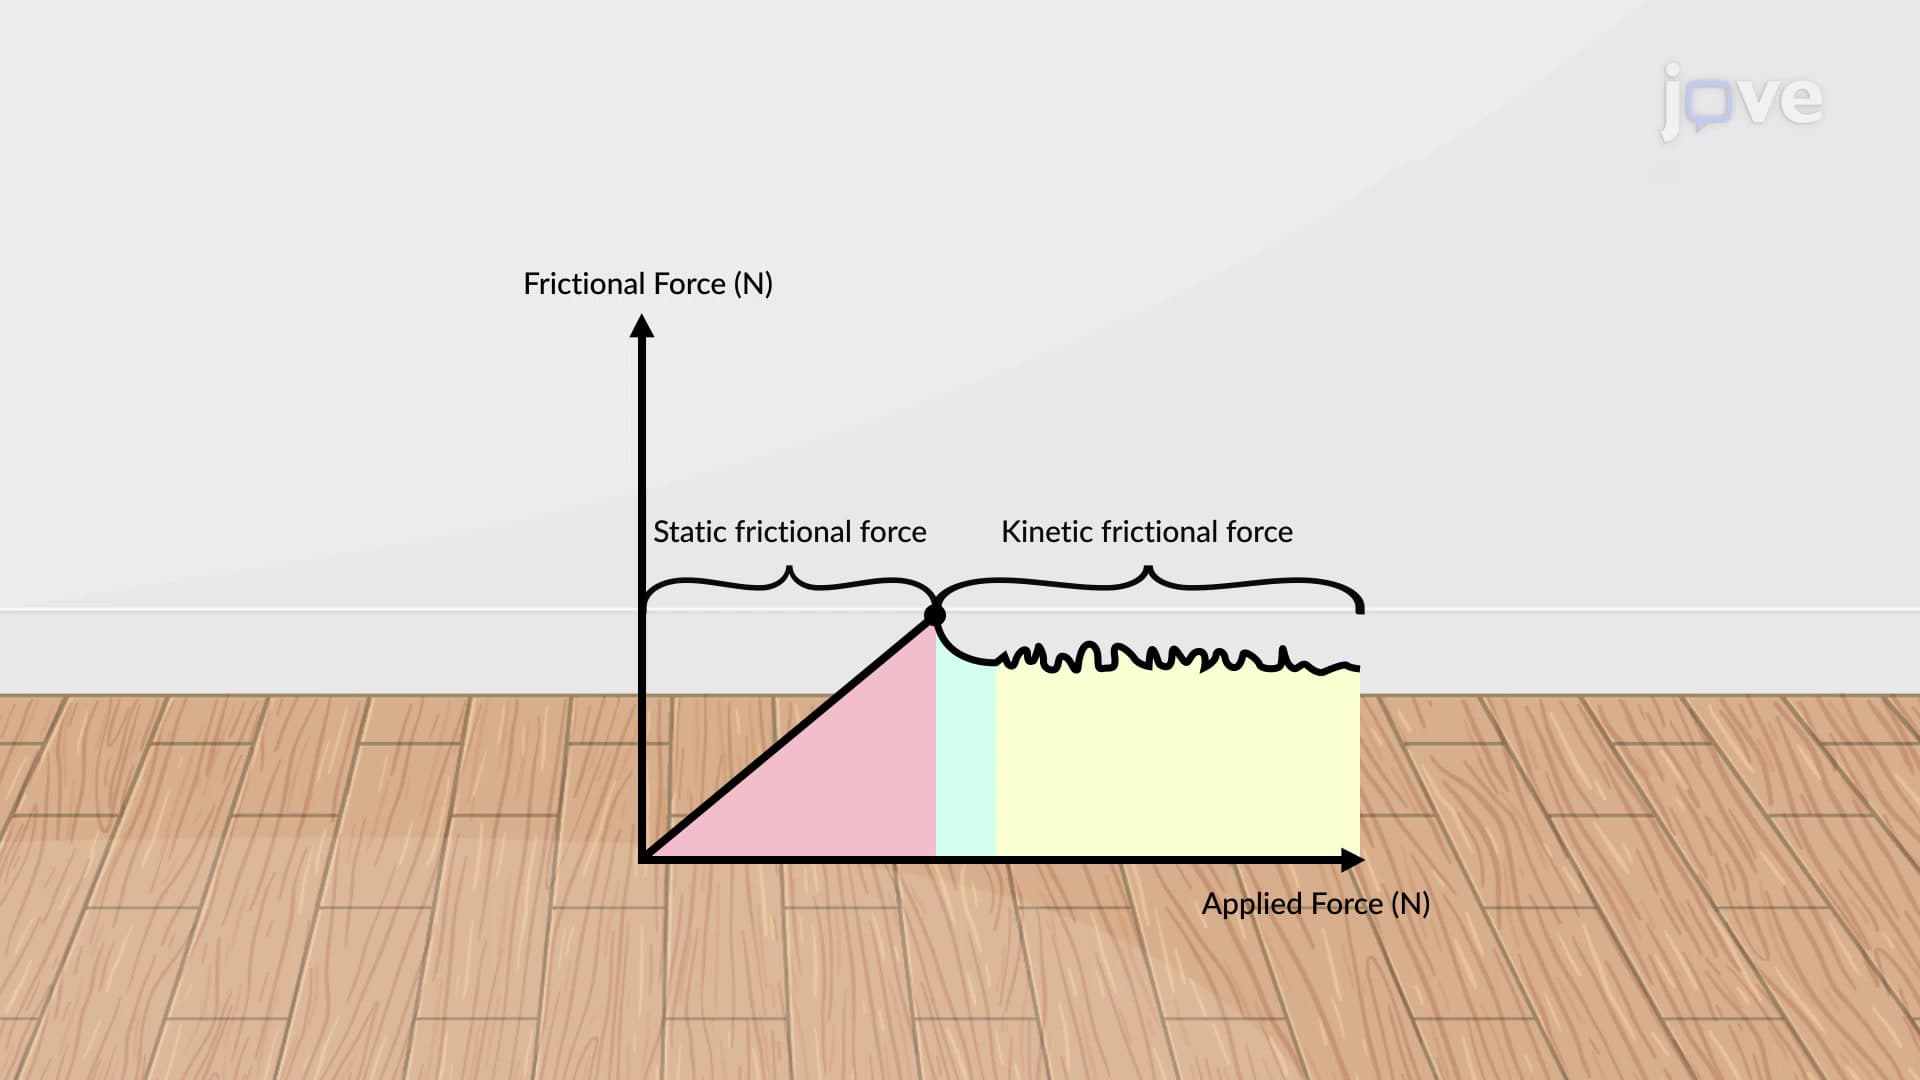
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...