Related Experiment Video
Updated: Dec 13, 2025
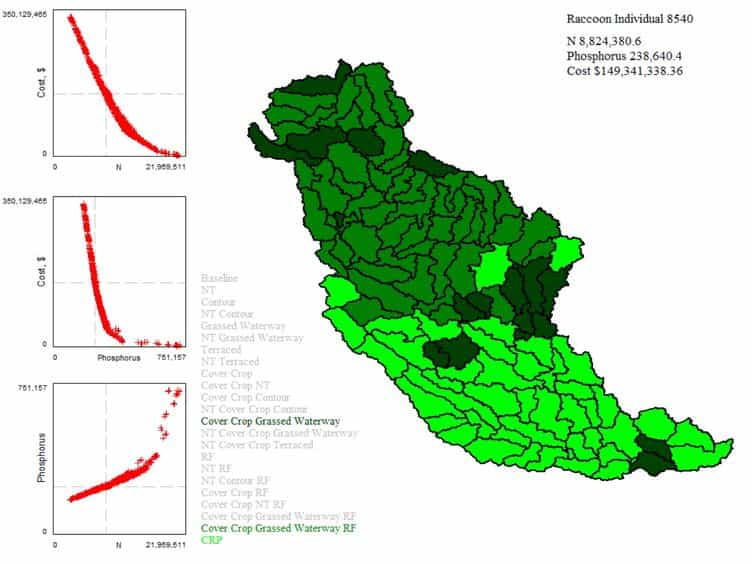
Spatial Multiobjective Optimization of Agricultural Conservation Practices using a SWAT Model and an Evolutionary Algorithm
Published on: December 9, 2012
Consensus tracking of nonlinear multi-agent systems under input saturation with applications: A sector-based approach
Ateeq Ur Rehman1, Muhammad Rehan1, Muhammad Riaz1
1Department of Electrical Engineering, Pakistan Institute of Engineering and Applied Sciences (PIEAS), Islamabad, Pakistan.

Abstract:
This paper focuses on the consensus tracking control of nonlinear multi-agent systems by utilizing the quadratic inner-bounded (QIB) and the one-sided Lipschitz (OSL) conditions in the presence of input saturation constraint under a directed communication topology. A novel sector constraint for the saturation function to formulate consensus control of nonlinear systems under saturating inputs is derived. This sector condition is applied to develop a leader-following consensus of nonlinear agents. A local treatment of the consensus control, ensuring a guaranteed region of stability in the presence of input constraints is provided herein. A computationally simple convex routine-based approach is attained for extraction of the coupling weight and gain of the relative state feedback-based consensus protocol along with the enlargement of the region of stability. Unlike the conventional schemes, the proposed approach can deal with OSL nonlinear agents, effectively employs the information of communication topology in the sector condition, and can be applied to both linear and nonlinear regions of actuators. Moreover, a useful consensus approach for the Lipschitz nonlinear agents is obtained as a particular scenario of the resultant method. Numerical examples to demonstrate the applications and effectiveness of the proposed approach for the input-constrained nonlinear mobile and robotic agents are provided.
Related Concept Videos
 01:22
Multi-input and Multi-variable systems
In the absence of...
 01:59
Solution Equilibrium and Saturation
 01:27
State Space Representation
Consider an RLC circuit, a...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:29
Mechanistic Models: Compartment Models in Algorithms for Numerical Problem Solving
In individual population analyses, different algorithms are employed, such as Cauchy's method, which uses a...
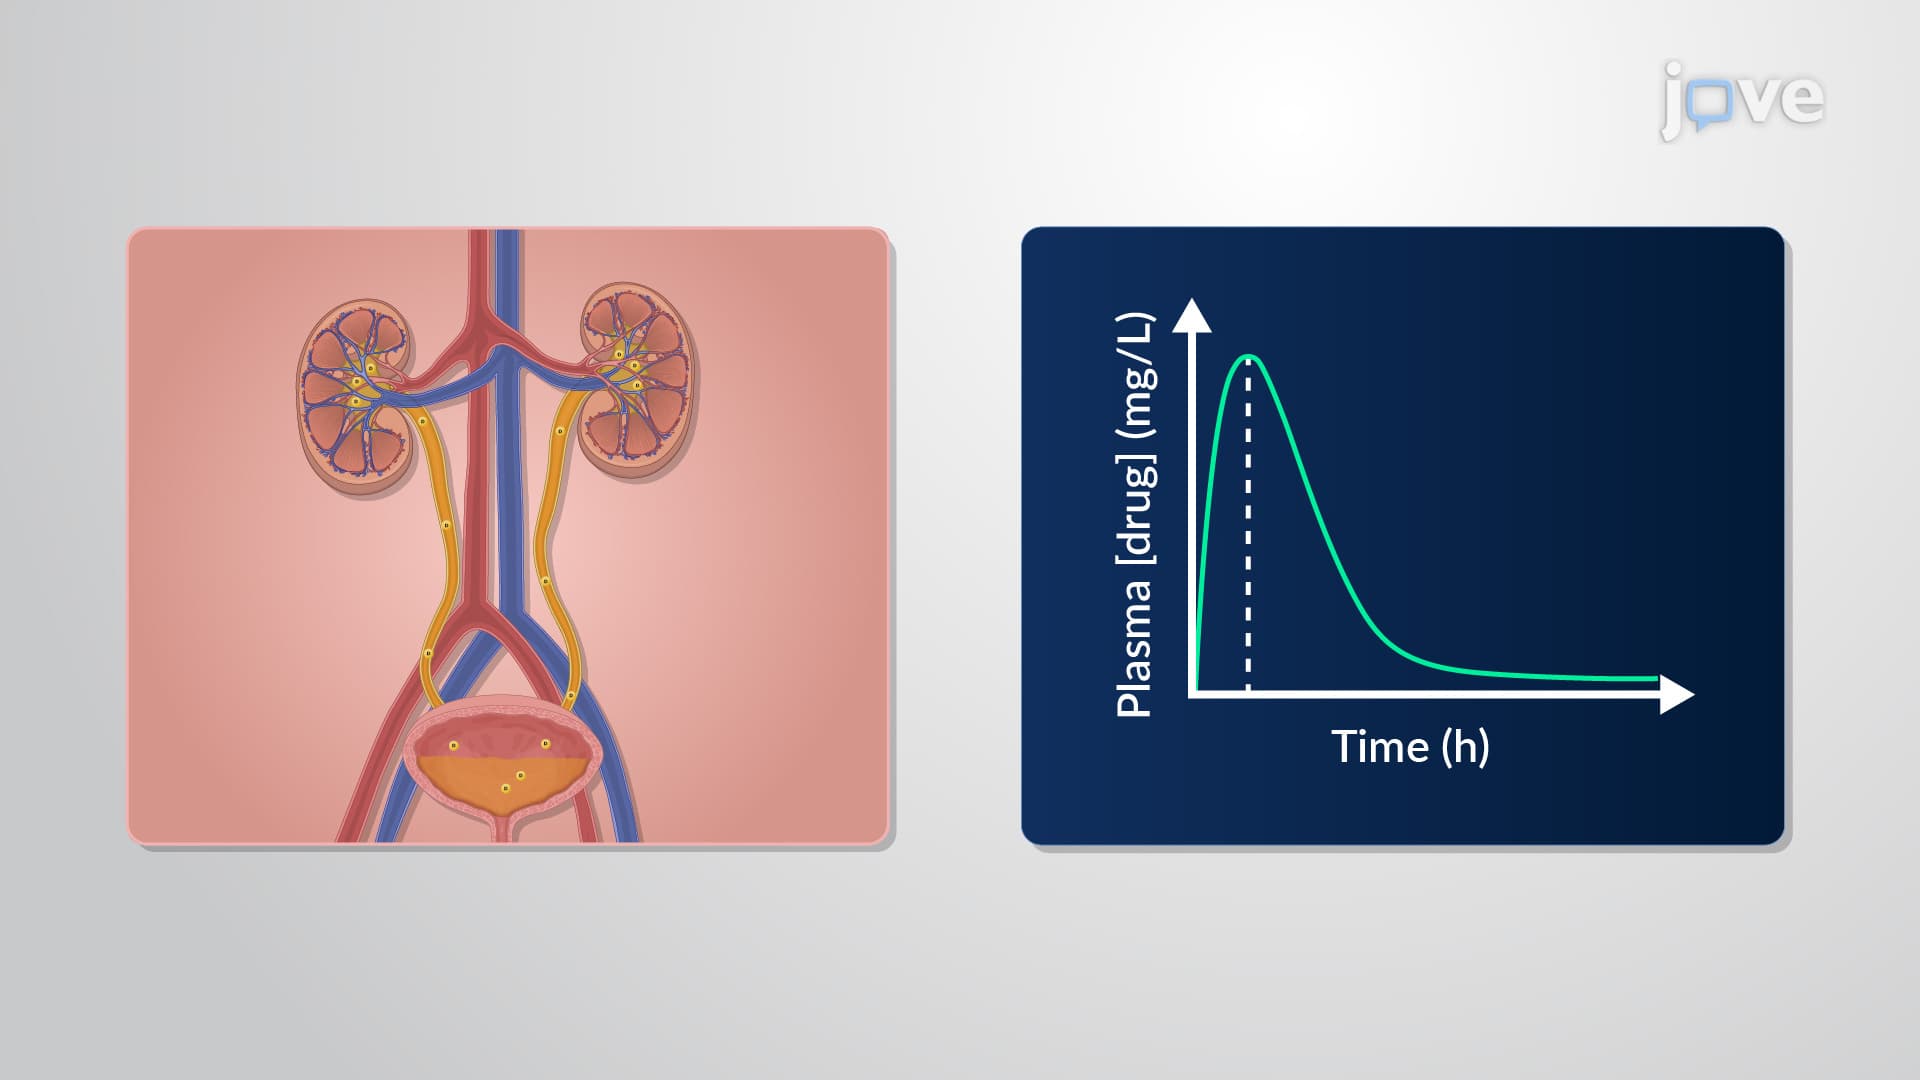 01:13
Parameters Affecting Nonlinear Elimination: Zero-Order Input, First-Order Absorption and Two-Compartment Model
When a drug is administered through a constant intravenous infusion and eliminated via nonlinear pharmacokinetics, it follows zero-order input. For example, oral drugs undergo first-order absorption upon administration and are eliminated through nonlinear pharmacokinetics.
In the case of subcutaneously administered drugs,...