Related Experiment Video
Updated: Dec 11, 2025
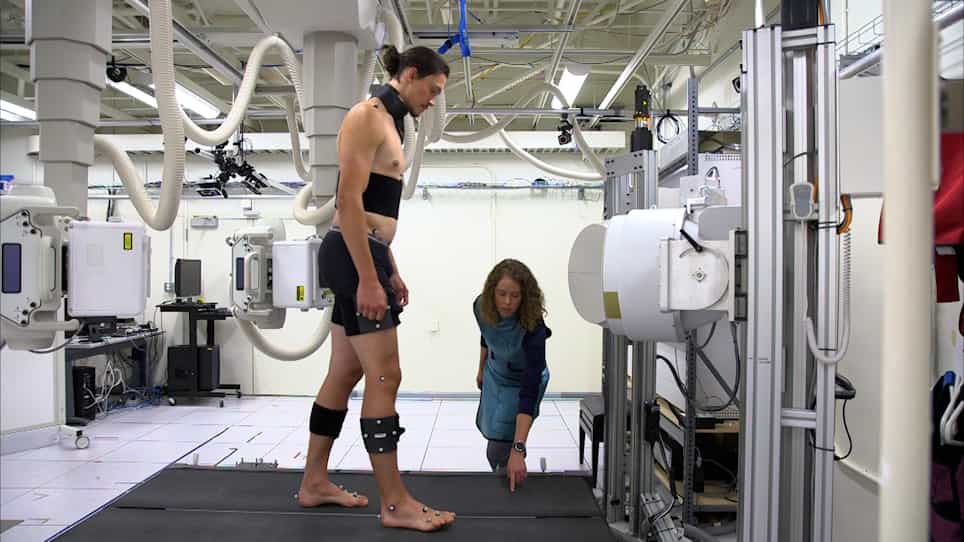
In Vivo Quantification of Hip Arthrokinematics during Dynamic Weight-bearing Activities using Dual Fluoroscopy
Published on: July 2, 2021
Coordinate system requirements to determine motions of the tibiofemoral joint free from kinematic crosstalk errors
1Department of Biomedical Engineering, University of California Davis, Davis, CA 95616, United States; Department of Mechanical Engineering, University of California Davis, Davis, CA 95616, United States; Department of Orthopaedic Surgery, University of California Davis Medical Center, Sacramento, CA 95817, United States.

Abstract:
The relative rigid body motions between the femur and the tibia (termed tibiofemoral kinematics) during flexion activities can provide an objective measure of knee function. Clinically meaningful tibiofemoral kinematics are defined as the six relative rigid body motions expressed in a joint coordinate system where the motions about and along the axes conform to clinical definitions and are free from kinematic crosstalk errors. To obtain clinically meaningful tibiofemoral kinematics, coordinate systems must meet certain requirements which neither have been explicitly stated nor in fact satisfied in any previous publication known to the author. Starting with the joint coordinate system of Grood and Suntay (1983) where motions conform to clinical definitions, the body-fixed axes must correspond to the functional (i.e. actual) axes in flexion-extension and internal-external axial rotation to avoid kinematic crosstalk errors in rotations and both functional axes must be body-fixed throughout knee flexion. To avoid kinematic crosstalk errors in translations, the origins of the femoral and tibial Cartesian coordinate systems, which serve as stepping stones for computing translations, must lie on the functional body-fixed axes. Neither the paper by Grood and Suntay nor the ISB recommendation (Wu et al., 2002) which adopted the joint coordinate system of Grood and Suntay explains these requirements. Indeed meeting these requirements conflicts with the ISB recommendation thus indicating the need for revision to this recommendation. Future studies where clinically meaningful tibiofemoral kinematics are of interest should be guided by the requirements described herein.
Related Concept Videos
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
 01:29
Space Trusses: Problem Solving
Consider a tripod consisting of a tetrahedral space truss with a ball-and-socket joint at C. Suppose the height and lengths of the horizontal and vertical...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
 01:15
Kinematic Equations: Problem Solving
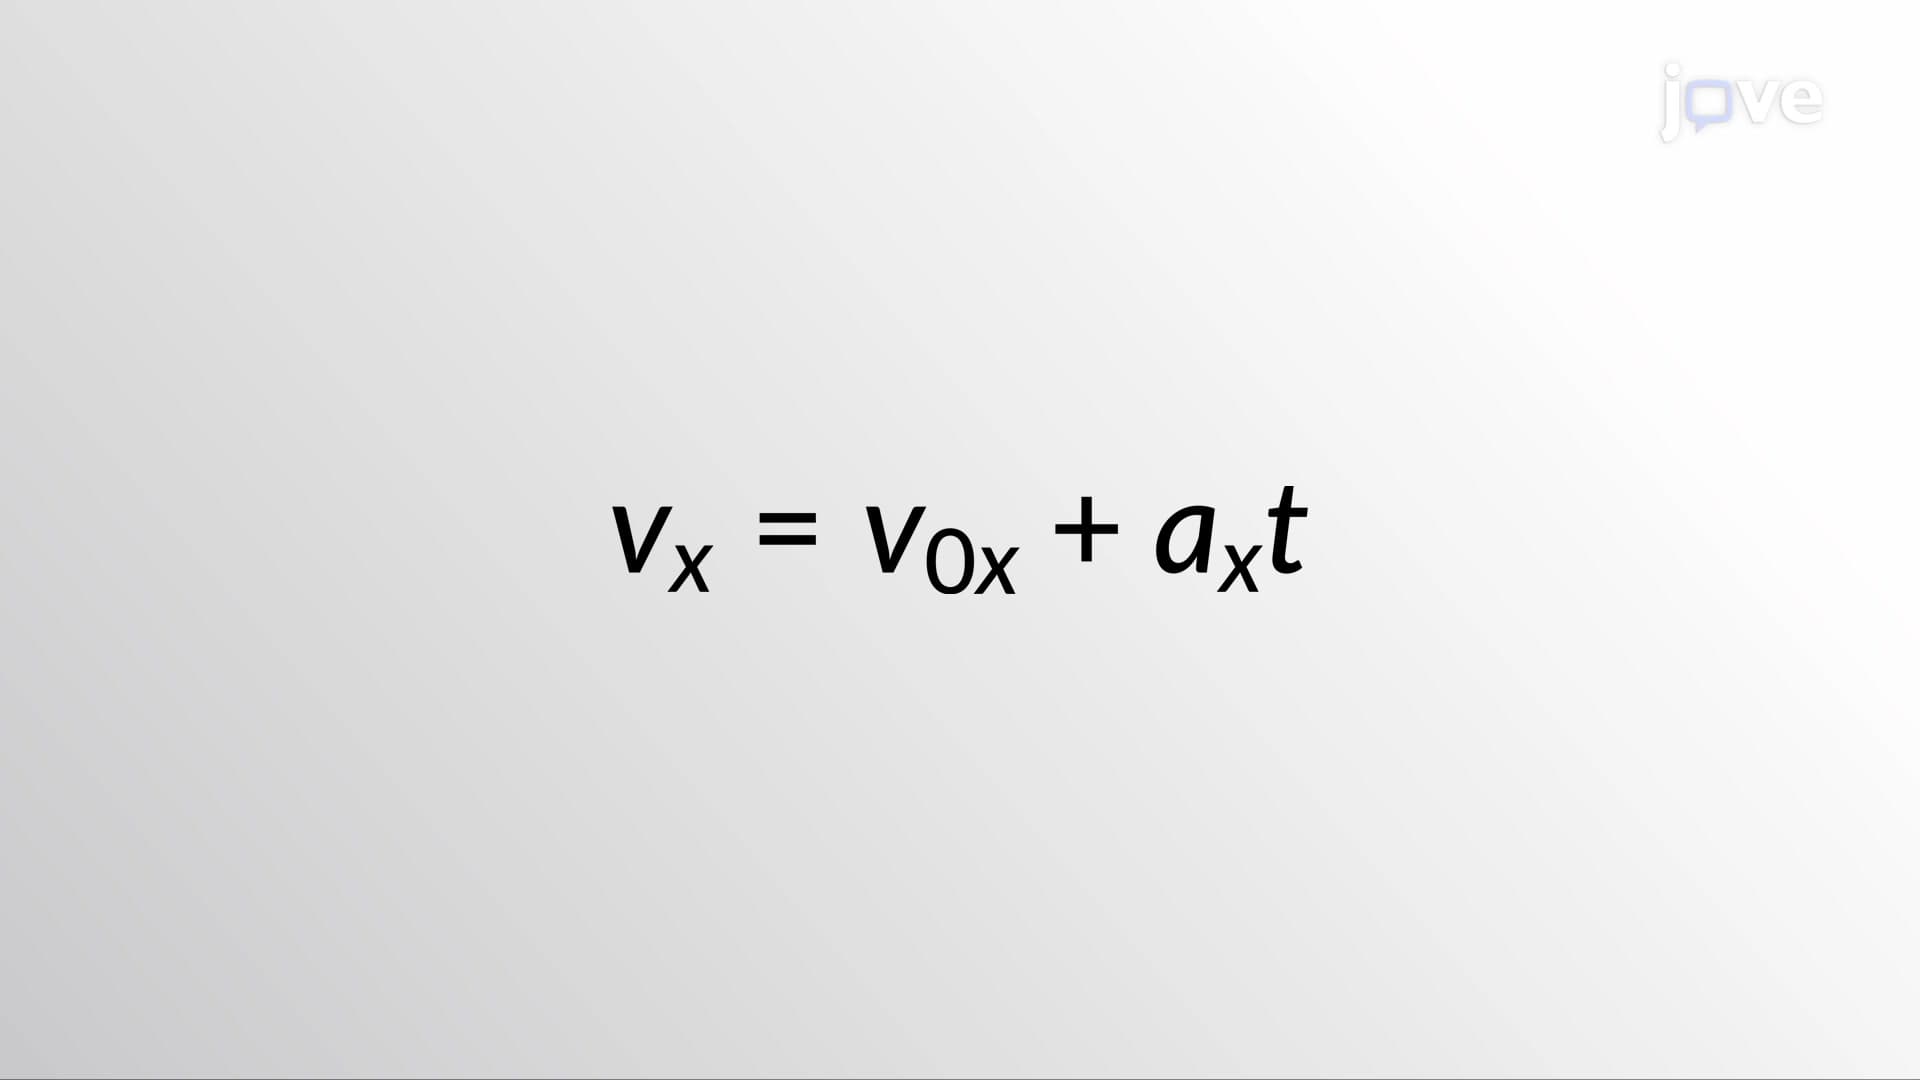 01:26
Kinematic Equations - I