Related Experiment Video
Updated: Dec 9, 2025
Flapping Soft Fin Deformation Modeling using Planar Laser-Induced Fluorescence Imaging
Published on: April 28, 2022
Tunabot Flex: a tuna-inspired robot with body flexibility improves high-performance swimming
Carl H White1, George V Lauder2, Hilary Bart-Smith1
1Bio-Inspired Engineering Research Laboratory (BIERL), Department of Mechanical and Aerospace Engineering, University of Virginia, 122 Engineer's Way, Charlottesville, VA 22903, United States of America.

Abstract:
Tunas are flexible, high-performance open ocean swimmers that operate at high frequencies to achieve high swimming speeds. Most fish-like robotic systems operate at low frequencies (≤3 Hz) resulting in low swim speeds (≤1.5 body lengths per second), and the cost of transport (COT) is often one to four orders of magnitude higher than that of tunas. Furthermore, the impact of body flexibility on high-performance fish swimming remains unknown. Here we design and test a research platform based on yellowfin tuna (Thunnus albacares) to investigate the role of body flexibility and to close the performance gap between robotic and biological systems. This single-motor platform, termed Tunabot Flex, measures 25.5 cm in length. Flexibility is varied through joints in the tail to produce three tested configurations. We find that increasing body flexibility improves self-propelled swimming speeds on average by 0.5 body lengths per second while reducing the minimum COT by 53%. The most flexible configuration swims 4.60 body lengths per second with a tail beat frequency of 8.0 Hz and a COT measuring 18.4 J kg-1m-1. We then compare these results in addition to the midline kinematics, stride length, and Strouhal number with yellowfin tuna data. The COT of Tunabot Flex's most flexible configuration is less than a half-order of magnitude greater than that of yellowfin tuna across all tested speeds. Tunabot Flex provides a new baseline for the development of future bio-inspired underwater vehicles that aim to explore a fish-like, high-performance space and close the gap between engineered robotic systems and fish swimming ability.
Related Concept Videos
 01:11
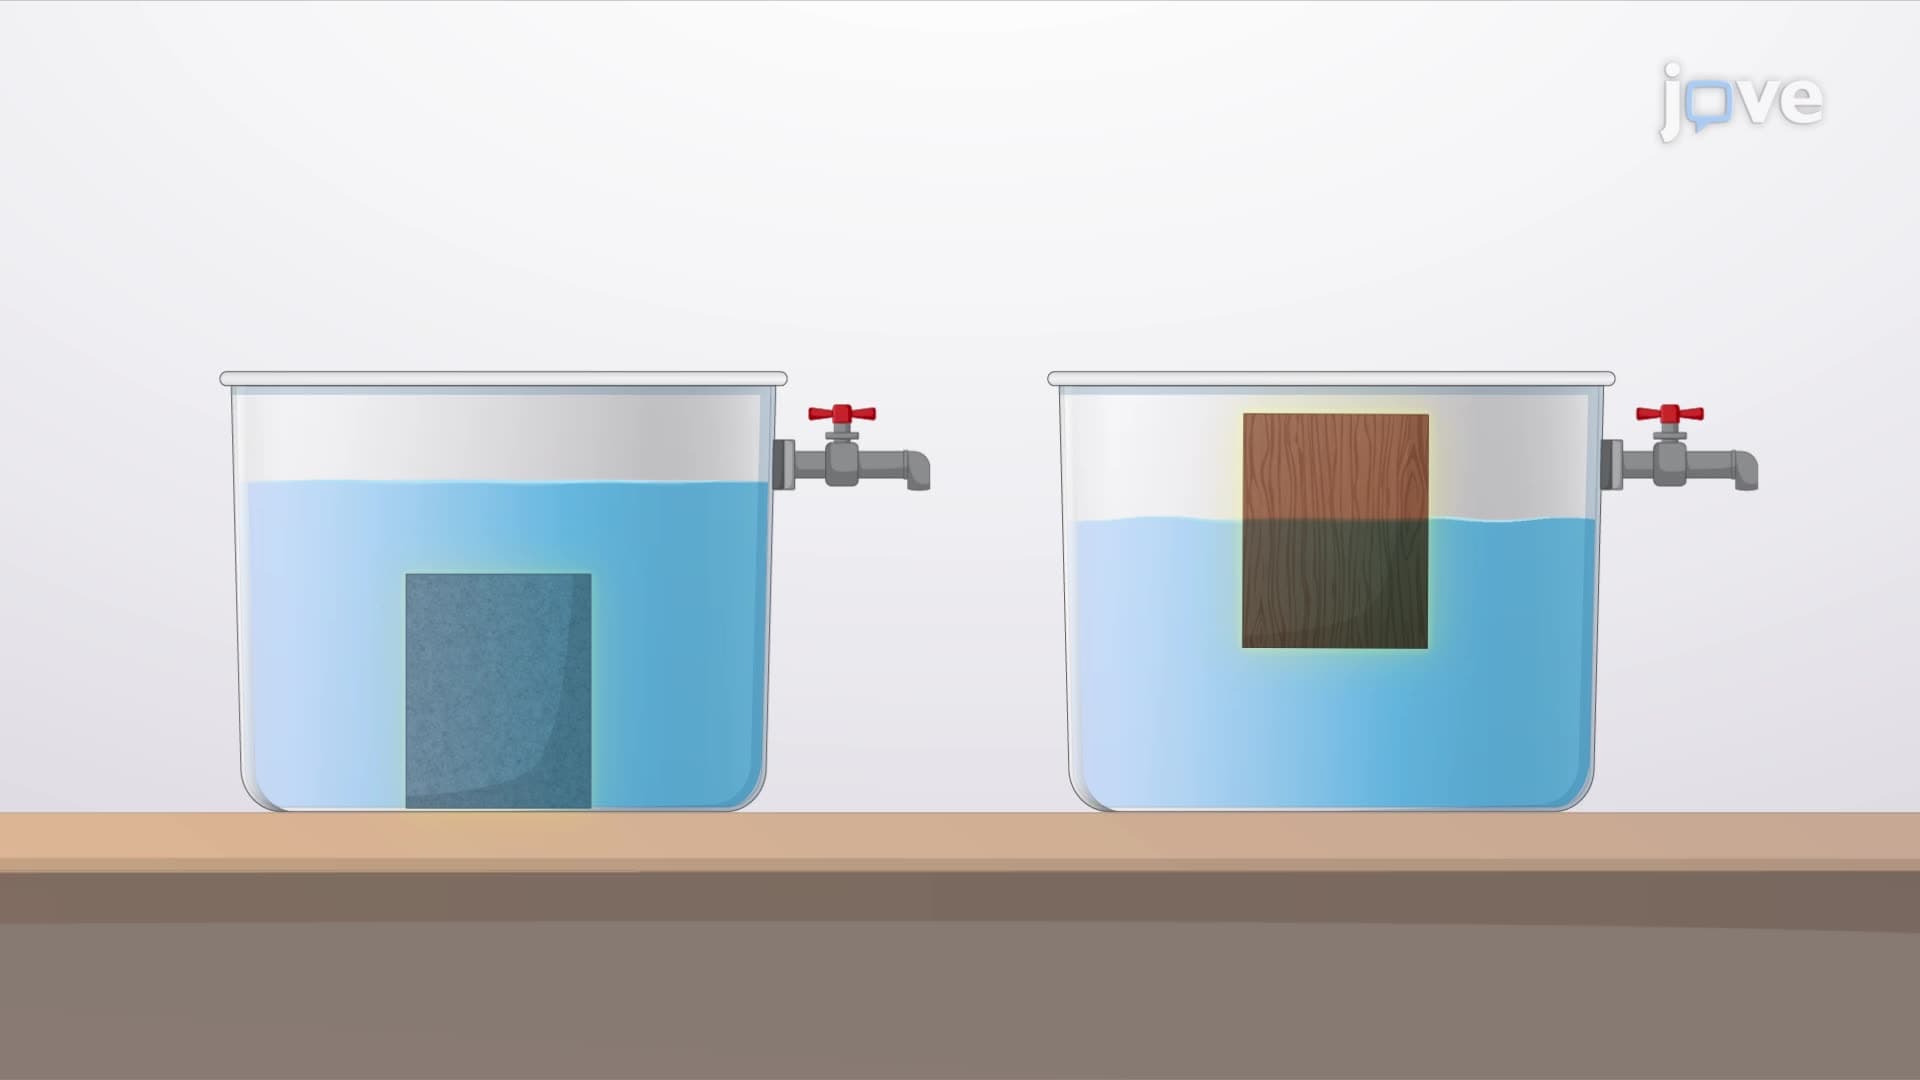
Buoyancy and Stability for Submerged and Floating Bodies
 01:14
Design Example: Frog Muscle Response
When the switch connecting the RL circuit is closed, a brief muscle contraction is observed. This is because, at a steady state, the inductor acts like a short...
 00:59
Buoyancy
 01:15
Torque Free Motion