Related Experiment Video
Updated: Dec 2, 2025


Insect-controlled Robot: A Mobile Robot Platform to Evaluate the Odor-tracking Capability of an Insect
Published on: December 19, 2016
Minimal navigation solution for a swarm of tiny flying robots to explore an unknown environment
K N McGuire1, C De Wagter2, K Tuyls3
1Faculty of Aerospace Engineering, Delft University of Technology, Delft, Netherlands. k.n.mcguire@tudelft.nl g.c.h.e.decroon@tudelft.nl.

Abstract:
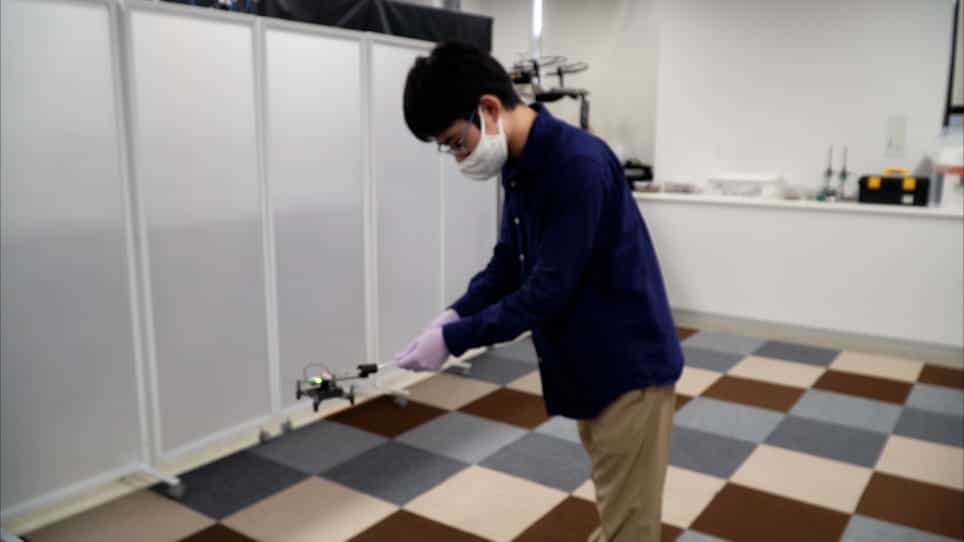
Swarms of tiny flying robots hold great potential for exploring unknown, indoor environments. Their small size allows them to move in narrow spaces, and their light weight makes them safe for operating around humans. Until now, this task has been out of reach due to the lack of adequate navigation strategies. The absence of external infrastructure implies that any positioning attempts must be performed by the robots themselves. State-of-the-art solutions, such as simultaneous localization and mapping, are still too resource demanding. This article presents the swarm gradient bug algorithm (SGBA), a minimal navigation solution that allows a swarm of tiny flying robots to autonomously explore an unknown environment and subsequently come back to the departure point. SGBA maximizes coverage by having robots travel in different directions away from the departure point. The robots navigate the environment and deal with static obstacles on the fly by means of visual odometry and wall-following behaviors. Moreover, they communicate with each other to avoid collisions and maximize search efficiency. To come back to the departure point, the robots perform a gradient search toward a home beacon. We studied the collective aspects of SGBA, demonstrating that it allows a group of 33-g commercial off-the-shelf quadrotors to successfully explore a real-world environment. The application potential is illustrated by a proof-of-concept search-and-rescue mission in which the robots captured images to find "victims" in an office environment. The developed algorithms generalize to other robot types and lay the basis for tackling other similarly complex missions with robot swarms in the future.
Related Concept Videos
 01:24
Absolute Motion Analysis- General Plane Motion
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
 01:21
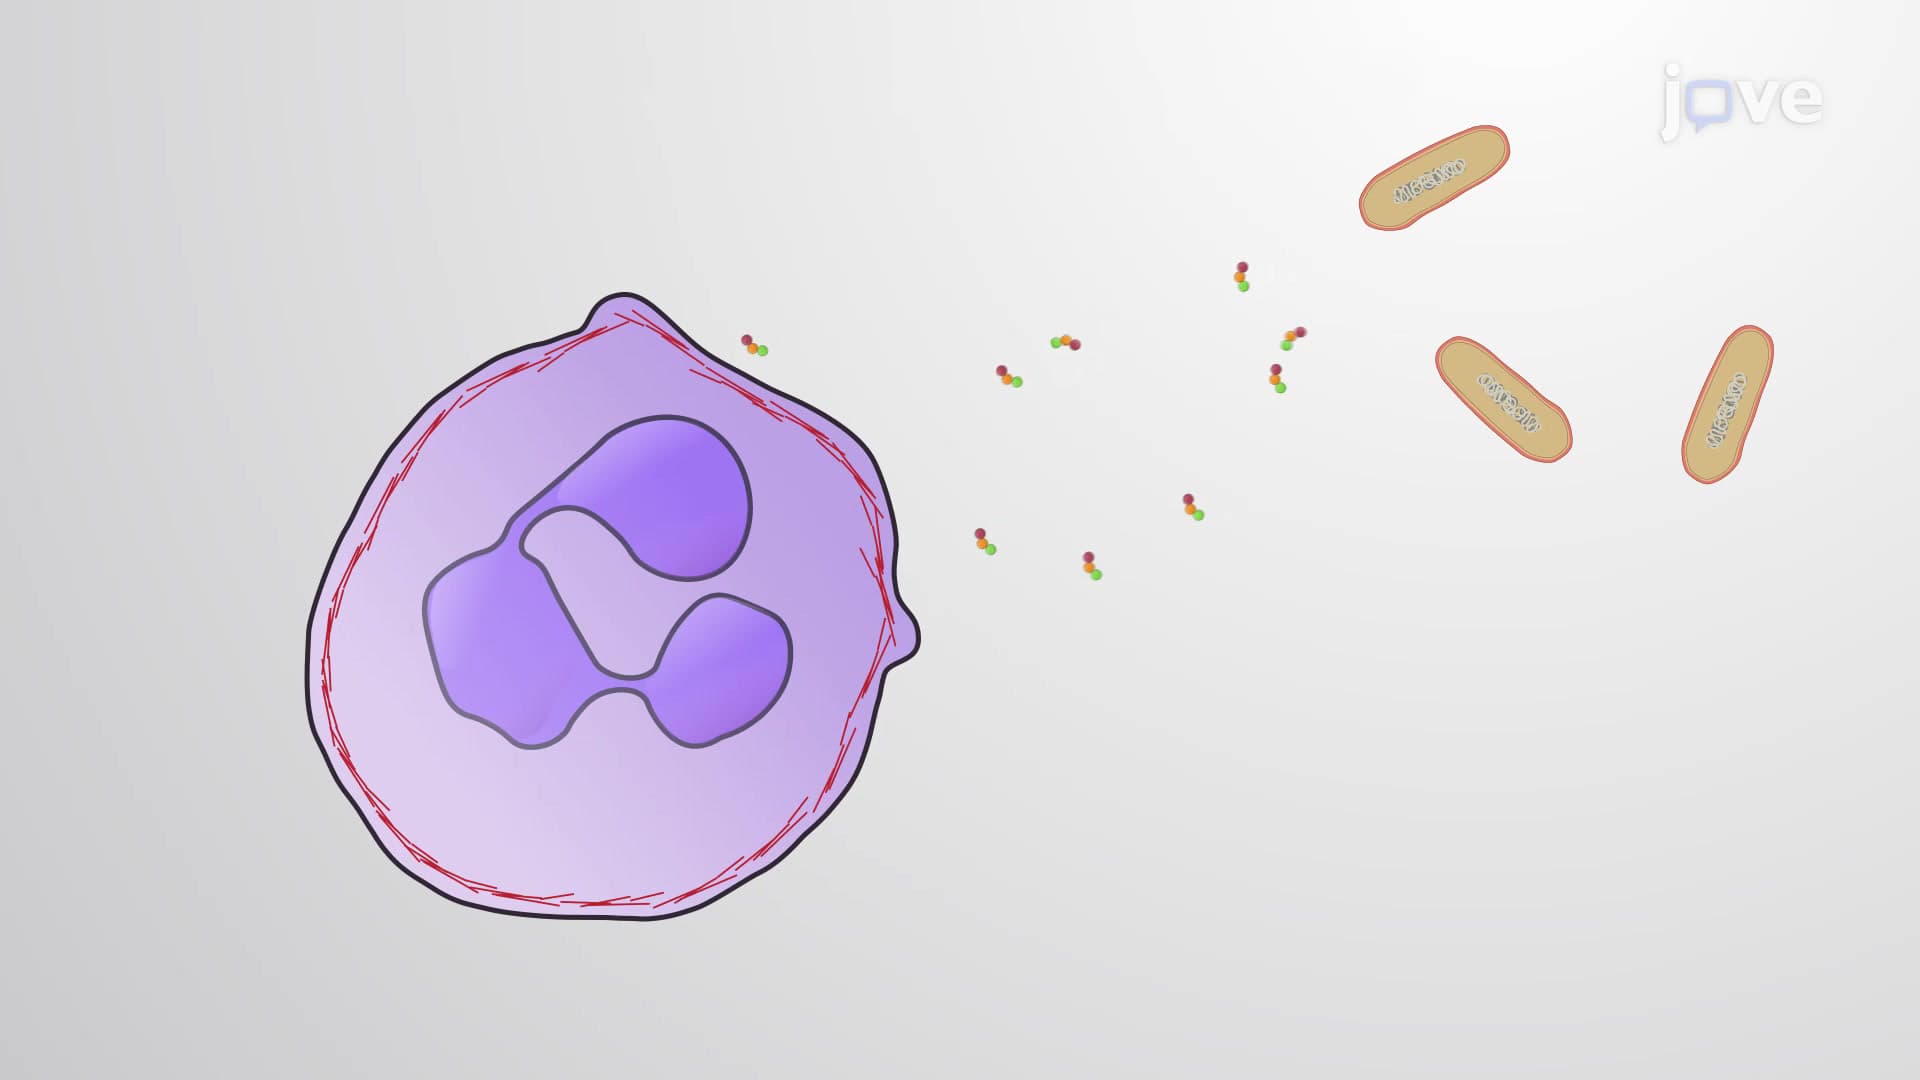
Chemotaxis and Direction of Cell Migration