Influence of path curvature on collision avoidance behaviour between two walkers
Related Experiment Video
Updated: Dec 1, 2025
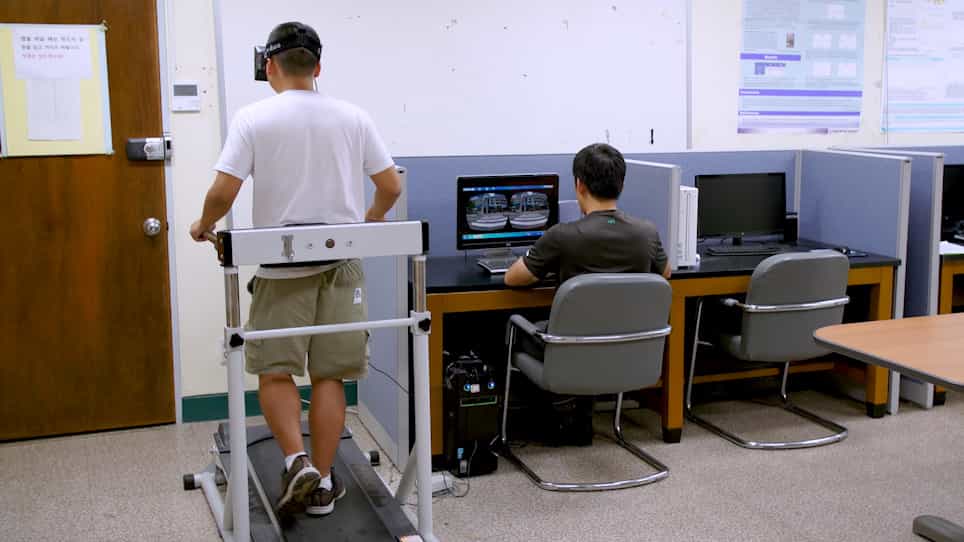
Using a Virtual Reality Walking Simulator to Investigate Pedestrian Behavior
Published on: June 9, 2020
Sean D Lynch1, Richard Kulpa2, Laurentius A Meerhoff2
1Univ Rennes, Inria, M2S-EA 7470, 35000, Rennes, France. sean.lynch3@mcgill.ca.

Abstract:
Navigating crowded community spaces requires interactions with pedestrians that follow rectilinear and curvilinear trajectories. In the case of rectilinear trajectories, it has been shown that the perceived action opportunities of the walkers might be afforded based on a future distance of closest approach. However, little is known about collision avoidance behaviours when avoiding walkers that follow curvilinear trajectories. Twenty-two participants were immersed in a virtual environment and avoided a virtual human (VH) that followed either a rectilinear path or a curvilinear path with a 5 m or 10 m radius curve at various distances of closest approach. Compared to a rectilinear path (control condition), the curvilinear path with a 5 m radius yielded more collisions when the VH approached from behind the participant and more inversions when the VH approached from in-front. During each trial, the evolution of the future distance of closest approach showed similarities between rectilinear paths and curvilinear paths with a 10 m radius curve. Overall, with few collisions and few inversions of crossing order, we can conclude that participants were capable of predicting future distance of closest approach of virtual walkers that followed curvilinear trajectories. The task was solved with similar avoidance adaptations to those observed for rectilinear interactions. These findings should inform future endeavors to further understand collision avoidance strategies and the role of-for example-non-constant velocities.

Related Concept Videos
 01:06
Collisions in Multiple Dimensions: Problem Solving
A small car of mass 1,200 kg traveling east at 60 km/h collides at an intersection with a truck of mass 3,000 kg traveling due north at 40 km/h. The two vehicles are locked together. What is the...
 01:27
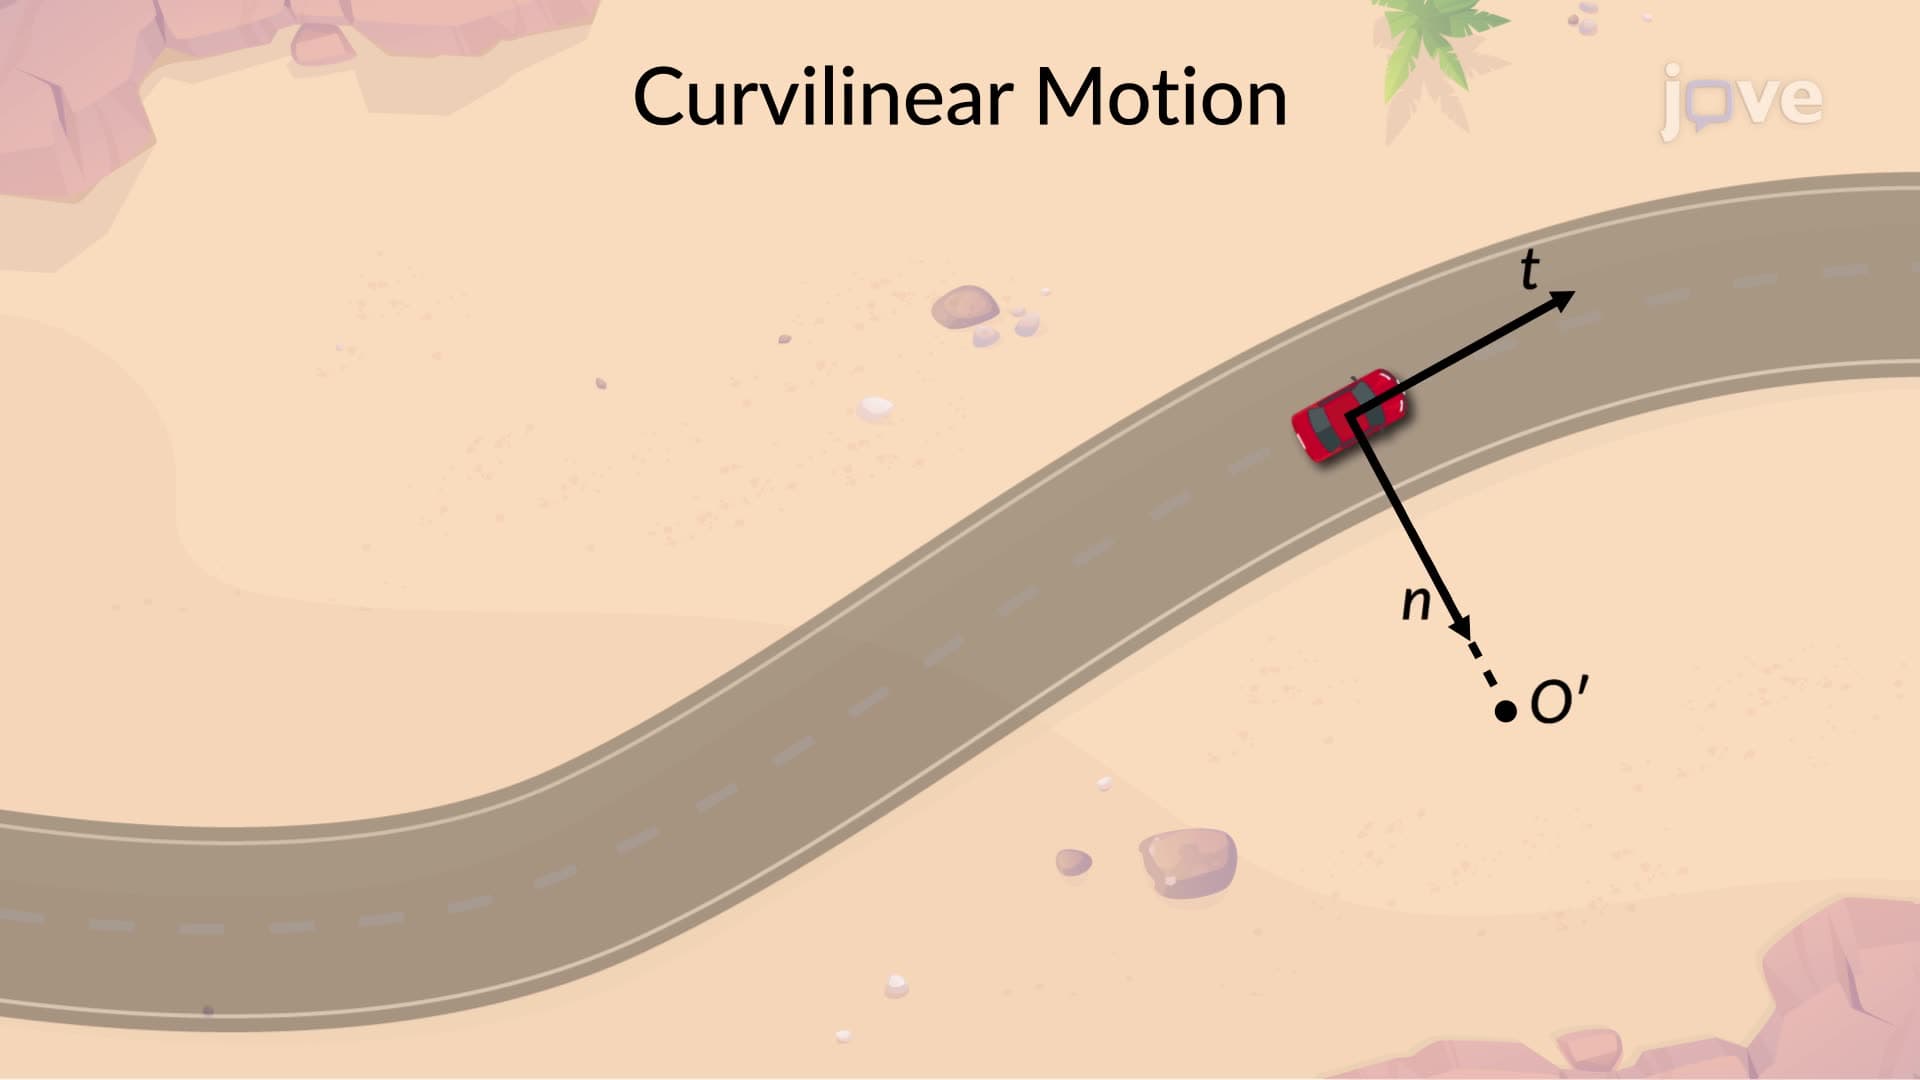
Curvilinear Motion: Normal and Tangential Components
The positive direction of the t-axis aligns with the increasing position of the car along the curved path, denoted by the unit vector ut. Simultaneously, the n-axis, perpendicular to the t-axis, dissects the curved path into differential arc segments, each forming the arc of a circle with a radius of...
 01:15
Elastic Collisions: Case Study
 01:19
Types of Collisions - II
 01:05
Collisions in Multiple Dimensions: Introduction
 01:10
Interference: Path Lengths
Two special sources may be considered when they are in phase. This can be easily achieved by feeding the two sources from the same source. An example would be synchronizing the two speakers by feeding them with the same source, such as the sound waves produced by a tuning fork. This setup ensures that the two sources have the same frequency and are...