Self-Assembled 3D Actuator Using the Resilience of an Elastomeric Material
Related Experiment Video
Updated: Nov 19, 2025
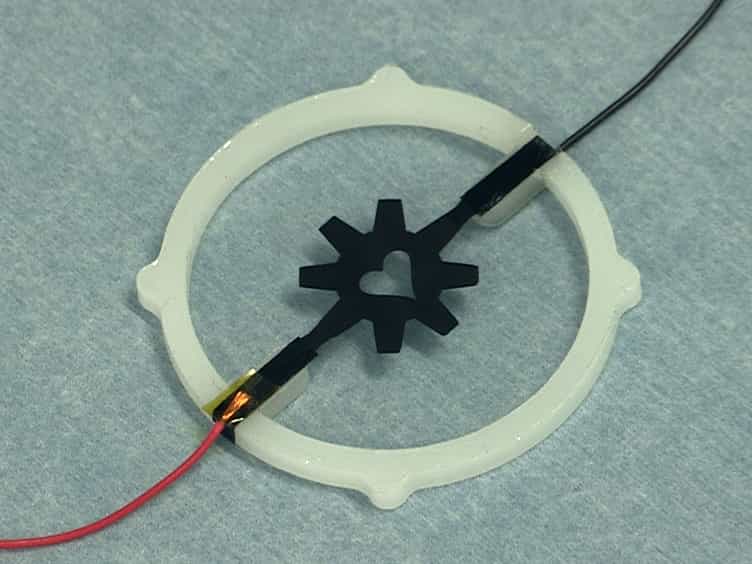
Fabrication Process of Silicone-based Dielectric Elastomer Actuators
Published on: February 1, 2016
Naoki Hashimoto1, Hiroki Shigemune1,2, Ayato Minaminosono2
1Department of Applied Physics, Waseda University, Tokyo, Japan.

Abstract:
Self-folding technologies have been studied by many researchers for applications to various engineering fields. Most of the self-folding methods that use the physical properties of materials require complex preparation, and usually take time to complete. In order to solve these problems, we focus on the elasticity of a material, and propose a model for forming a 3D structure using its characteristics. Our proposed model achieves high-speed and high-precision self-folding with a simple structure, by attaching rigid frames to a stretchable elastomer. The self-folded structure is applied to introduce a self-assembled actuator by exploiting a dielectric elastomer actuator (DEA). We develop the self-assembled actuator driven with the voltage application by attaching stretchable electrodes on the both side of the elastomer. We attempt several experiments to investigate the basic characteristics of the actuator. We also propose an application of the self-assembled actuator as a gripper based on the experimental results. The gripper has three joints with the angle of 120°, and successfully grabs objects by switching the voltage.

Related Concept Videos
 01:19
Members Made of Elastoplastic Material
As the bending moment...
 01:24
Circular Shafts - Elastoplastic Materials
As torque on the...