Structure-Preserving Imitation Learning With Delayed Reward: An Evaluation Within the RoboCup Soccer 2D Simulation Environment
Related Experiment Video
Updated: Nov 19, 2025
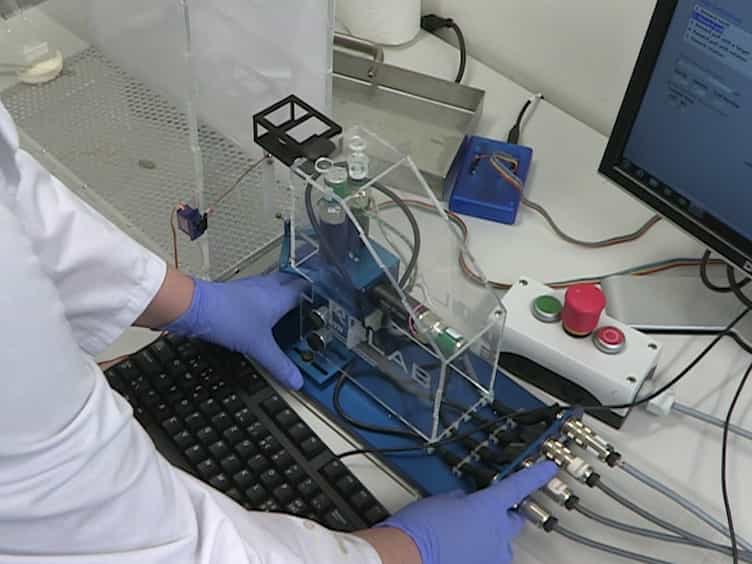
Investigating Motor Skill Learning Processes with a Robotic Manipulandum
Published on: February 12, 2017
Quang Dang Nguyen1, Mikhail Prokopenko1
1Centre for Complex Systems, Faculty of Engineering, University of Sydney, Sydney, NSW, Australia.

Abstract:
We describe and evaluate a neural network-based architecture aimed to imitate and improve the performance of a fully autonomous soccer team in RoboCup Soccer 2D Simulation environment. The approach utilizes deep Q-network architecture for action determination and a deep neural network for parameter learning. The proposed solution is shown to be feasible for replacing a selected behavioral module in a well-established RoboCup base team, Gliders2d, in which behavioral modules have been evolved with human experts in the loop. Furthermore, we introduce an additional performance-correlated signal (a delayed reward signal), enabling a search for local maxima during a training phase. The extension is compared against a known benchmark. Finally, we investigate the extent to which preserving the structure of expert-designed behaviors affects the performance of a neural network-based solution.
Related Concept Videos
 01:12
Observational Learning
 01:24
Reinforcement Schedules
Once a behavior is learned,...
 01:14
Avoidance Learning and Learned Helplessness
Avoidance learning occurs when an organism learns that a specific behavior can prevent an unpleasant outcome. For example, a student who receives a bad grade may start studying harder to avoid future poor grades. This behavior persists even when the negative outcome is no longer present. Avoidance learning is powerful because it maintains behavior in the absence of the...