Related Experiment Video
Updated: Nov 17, 2025


Design and Fabrication of an Elastomeric Unit for Soft Modular Robots in Minimally Invasive Surgery
Published on: November 14, 2015
Variable Stiffness Devices Using Fiber Jamming for Application in Soft Robotics and Wearable Haptics
Saurabh Jadhav1, Mohamad Ramzi Abdul Majit1, Benjamin Shih1
1Department of Mechanical and Aerospace Engineering, University of California, San Diego, La Jolla, California, USA.

Abstract:
Variable stiffness actuation has applications in a wide range of fields, including wearable haptics, soft robots, and minimally invasive surgical devices. There have been numerous design approaches to control and tune stiffness and rigidity; however, most have relatively low specific load-carrying capacities (especially for flexural loads) in the most rigid state that restricts their use in small or slender devices. In this article, we present an approach to the design of slender, high flexural stiffness modules based on the principle of fiber jamming. The proposed fiber jamming modules (FJMs) consist of axially packed fibers in an airtight envelope that transition from a flexible to a rigid beam when a vacuum is created inside the envelope. This FJM can provide the flexural stiffness of up to eight times that of a particle jamming module in the rigid state. Unlike layer jamming modules, the design of FJMs further allows them to control stiffness while bending in space. We present an analytical model to guide the parameter choices for the design of fiber jamming devices. Finally, we demonstrate applications of FJMs, including as a versatile tool, as part of a kinesthetic force feedback haptic glove and as a programmable structure.


Related Concept Videos
 01:05
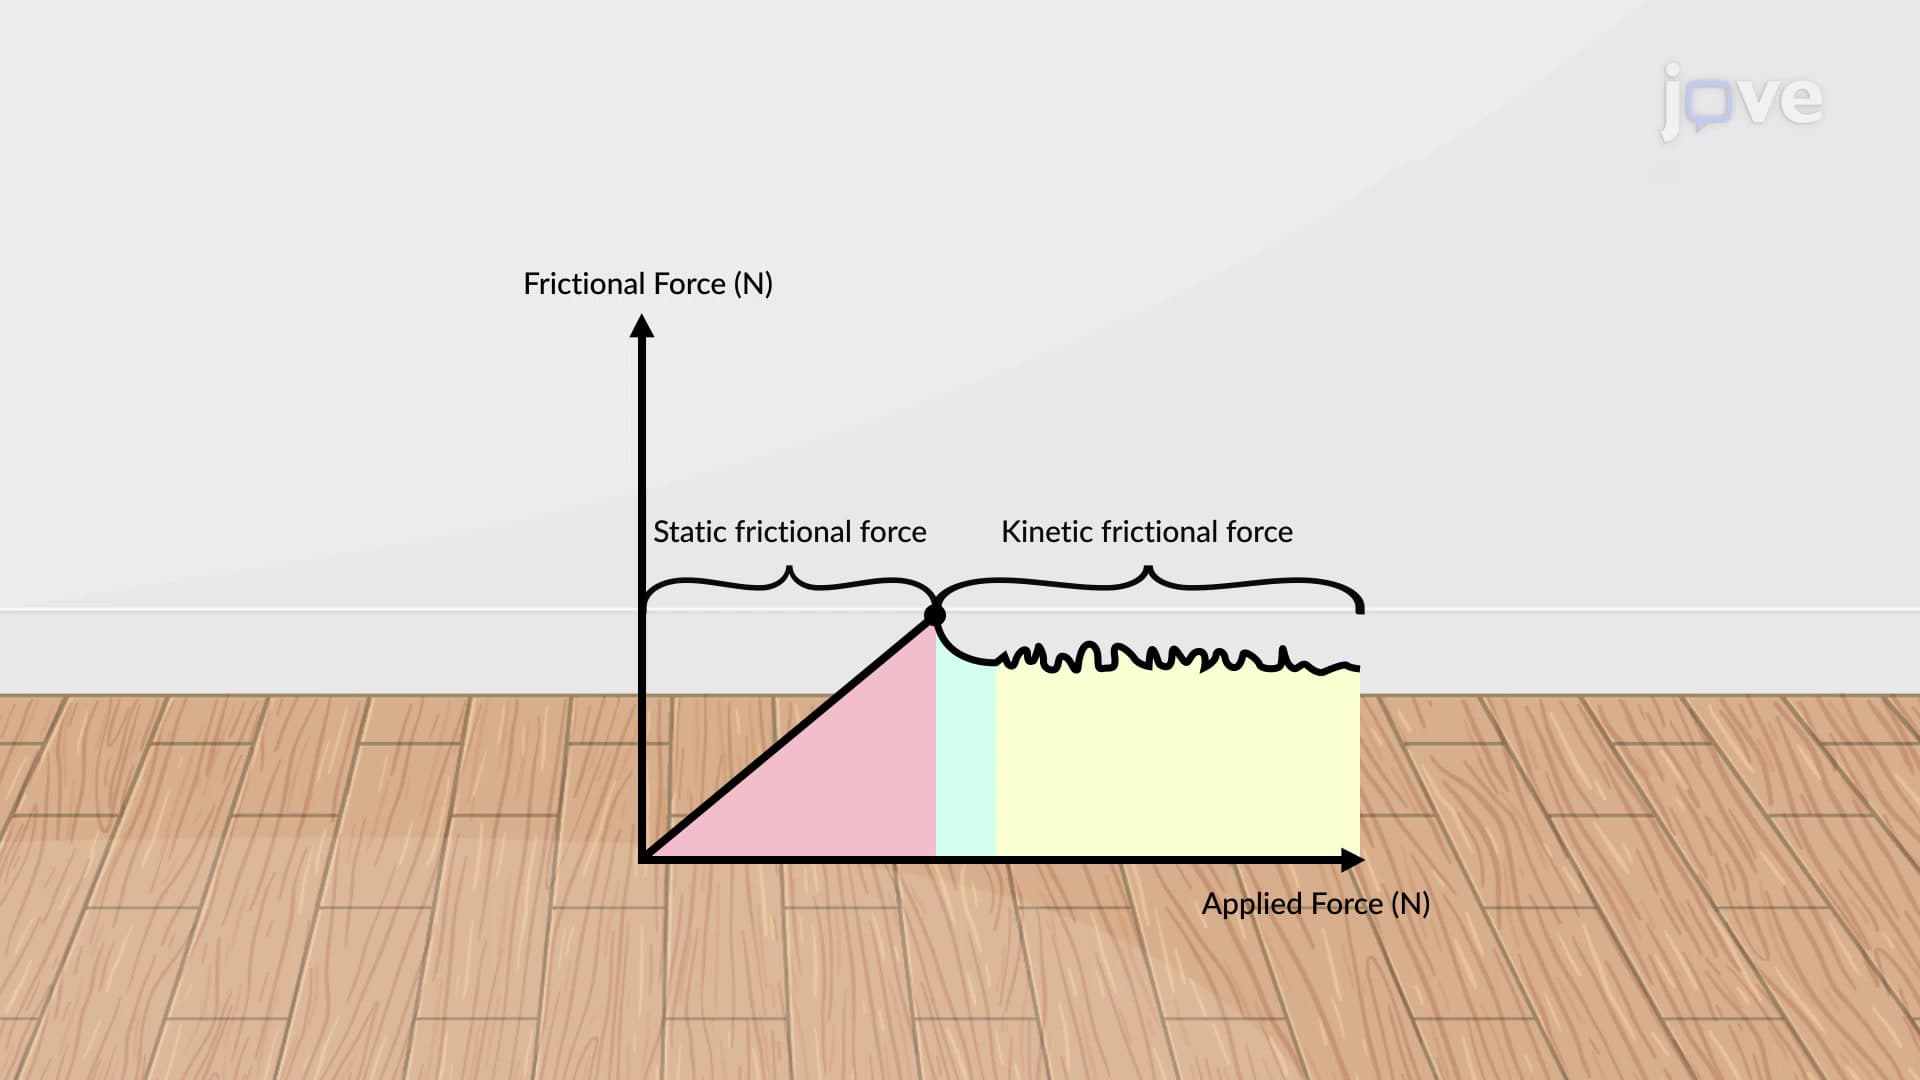
Static and Kinetic Frictional Force
However, if two systems are in contact and are stationary relative to one...
 01:17
Magnetic Damping
If, however, the bob is a slotted metal plate, the magnet produces a much smaller effect. When a slotted metal plate enters the field, an emf is induced by the change in flux; however, it is less effective because the slots limit the...
 01:26
Kinetic Friction