Related Experiment Video
Updated: Nov 12, 2025
Real-Time DC-dynamic Biasing Method for Switching Time Improvement in Severely Underdamped Fringing-field Electrostatic MEMS Actuators
Published on: August 15, 2014
Dynamic event-triggered sliding mode control for interval Type-2 fuzzy systems with fading channels
Yekai Yang1, Yugang Niu1, Zhina Zhang1
1Key Laboratory of Advanced Control and Optimization for Chemical Process (East China University of Science and Technology), Ministry of Education, Shanghai, 200237, China.

Abstract:
This paper addresses the issue of sliding mode control(SMC) for a class of interval type-2(IT2) fuzzy system subject to the fading channel. For relieving the transmission burden, a dynamic event-triggered mechanism is introduced to determine the transmission of the measurement signals via the sensor-to-controller(S/C) channel. In the communication channel, the transmitted signal may suffer from fading in wireless communication networks. By means of known bounds of the membership functions (MFs) in IT2 fuzzy model, both the fuzzy state observer and the fuzzy SMC law are designed to ensure the reachability of the sliding mode dynamics. Meanwhile, stability conditions involving the fading parameter are obtained to guarantee that the input-to-state practical stability in mean square of the closed-loop systems. Finally, the proposed control scheme under the fading communication is verified by virtue of the numerical simulation and the tunnel diode circuit.
Related Concept Videos
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:21
Time and frequency -Domain Interpretation of Phase-lag Control
Phase-lag controllers do not place a pole at zero, but instead influence the steady-state error by amplifying any...
 01:18
Second Order systems II
 01:21
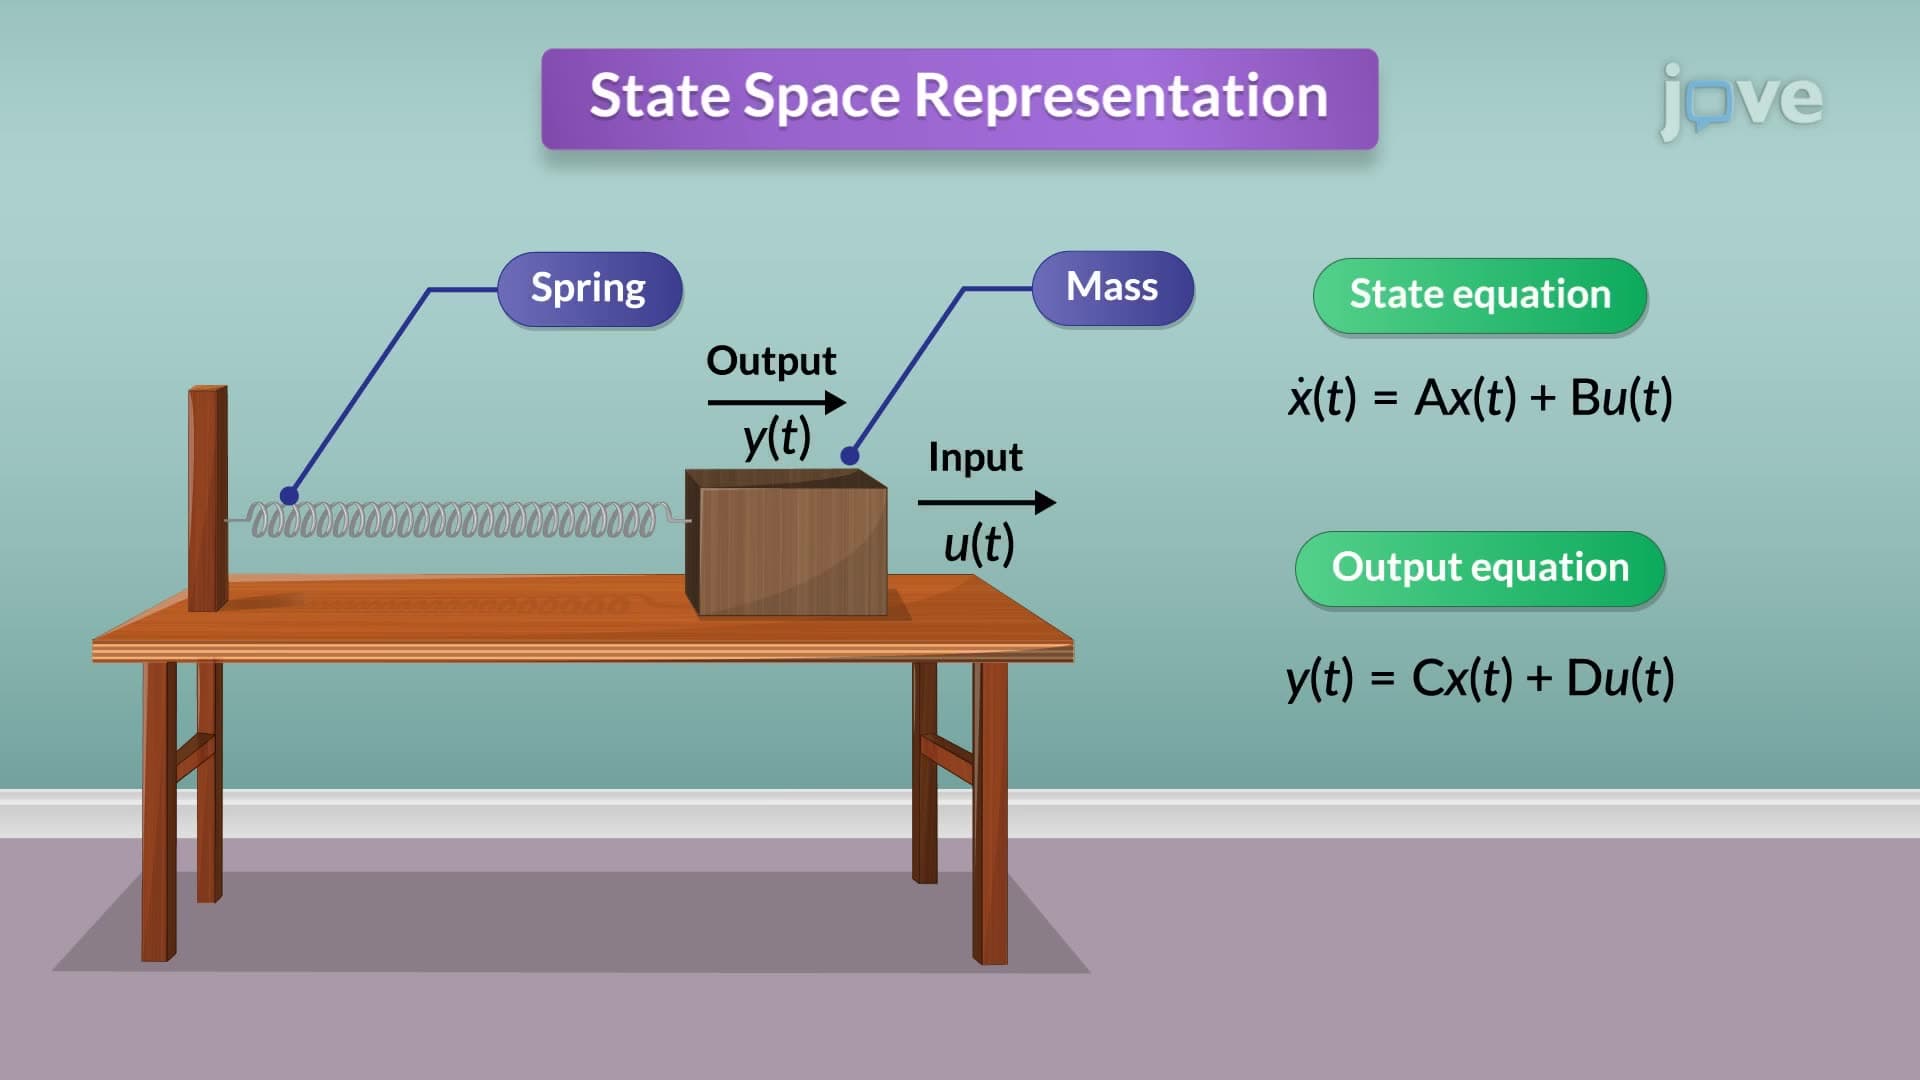
State Space to Transfer Function
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
 01:21
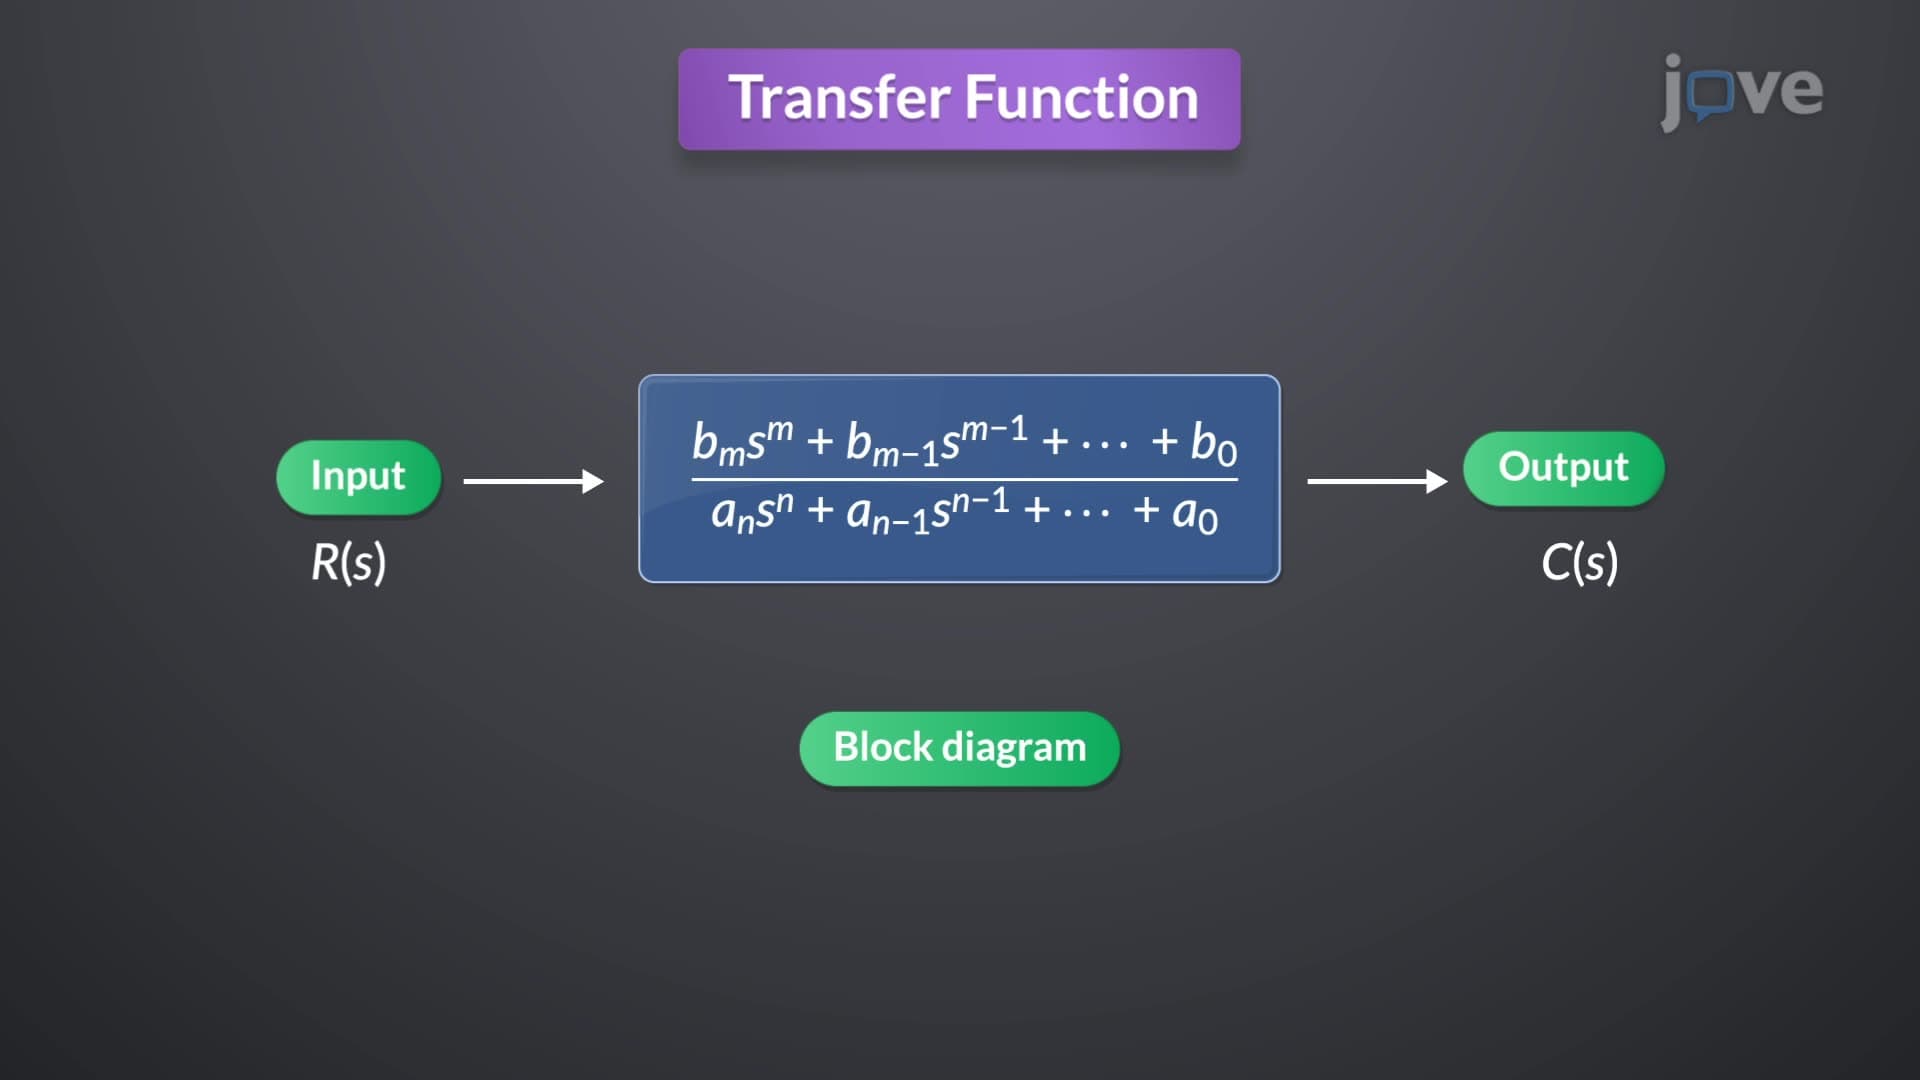
Transfer Function in Control Systems
To derive the transfer function, consider a general nth-order linear time-invariant...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...